Related Experiment Video
Updated: Jan 27, 2026
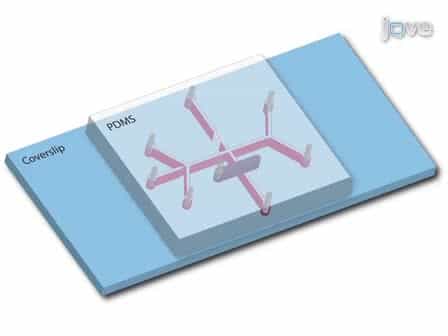

A Microfluidic-based Hydrodynamic Trap for Single Particles
Published on: January 21, 2011
Indirect optical trapping using light driven micro-rotors for reconfigurable hydrodynamic manipulation
Unė G Būtaitė1, Graham M Gibson2, Ying-Lung D Ho3
1School of Physics and Astronomy, University of Glasgow, Glasgow, G12 8QQ, UK. u.butaite.1@research.gla.ac.uk.

Abstract:
Optical tweezers are a highly versatile tool for exploration of the mesoscopic world, permitting non-contact manipulation of nanoscale objects. However, direct illumination with intense lasers restricts their use with live biological specimens, and limits the types of materials that can be trapped. Here we demonstrate an indirect optical trapping platform which circumvents these limitations by using hydrodynamic forces to exert nanoscale-precision control over aqueous particles, without directly illuminating them. Our concept is based on optically actuated micro-robotics: closed-loop control enables highly localised flow-fields to be sculpted by precisely piloting the motion of optically-trapped micro-rotors. We demonstrate 2D trapping of absorbing particles which cannot be directly optically trapped, stabilise the position and orientation of yeast cells, and demonstrate independent control over multiple objects simultaneously. Our work expands the capabilities of optical tweezers platforms, and represents a new paradigm for manipulation of aqueous mesoscopic systems.
Related Concept Videos
 01:41
Social Traps
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:23
EDTA: Indirect and Alkalimetric Titration
 01:21
Manipulation and Analysis
 01:27
ATP Driven Pumps I: An Overview
There are four main types of ATP-driven pumps - P-type, V-type, F-type, and ABC transporter. All these pumps are of varying complexities and...
 02:16
Light Acquisition