RBF-ARX model-based fast robust MPC approach to an inverted pendulum
Related Experiment Video
Updated: Jan 27, 2026
Author Spotlight: Developing a Tool for Using Inverted Confocal Microscopes for In Vivo Intravital Imaging
Published on: June 30, 2023
Xiaoying Tian1, Hui Peng1, Feng Zhou2
1School of Automation, Central South University, Changsha, Hunan 410083, China.

Abstract:
In general, the online computation burden of robust model predictive control (RMPC) is very heavy, and the mechanical model of a plant, which is used in RMPC, is hard to obtain precisely in real industry. These issues may largely restrict the applicability of RMPC in real applications. This paper proposes a RBF-ARX (state-dependent Auto-Regressive model with eXogenous input and Radial Basis Function network type coefficients) model-based efficient robust predictive control (RBF-ARX-ERPC) approach to an inverted pendulum system, which is a complete and systematic method for designing robust MPC controller because it integrates the RBF-ARX modeling method and a fast RMPC approach. First, based on the offline identified RBF-ARX model without offset term, two convex polytopic sets are constructed to wrap the globally nonlinear behavior of the system. Then, the optimization problem of implementing a quasi-min-max MPC algorithm including several linear matrix inequalities (LMIs) is formulated, and it is solved offline to synthesize a sequence of explicit control laws that correspond to a sequence of asymptotically stable invariant ellipsoids, of which all the optimization results are stored in a look-up table. During the online real-time control, the controller only needs to carry out a simple state-vector computation and bisection search. The proposed approach is applied to an actual linear one-stage inverted pendulum (LOSIP), which is a fast-responding and nonlinear plant. The real-time control experiments demonstrate the effectiveness of the proposed RBF-ARX model-based efficient RMPC approach.
Related Concept Videos
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:20
Inverting and Non-inverting OpAmps
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:09
Torsional Pendulum
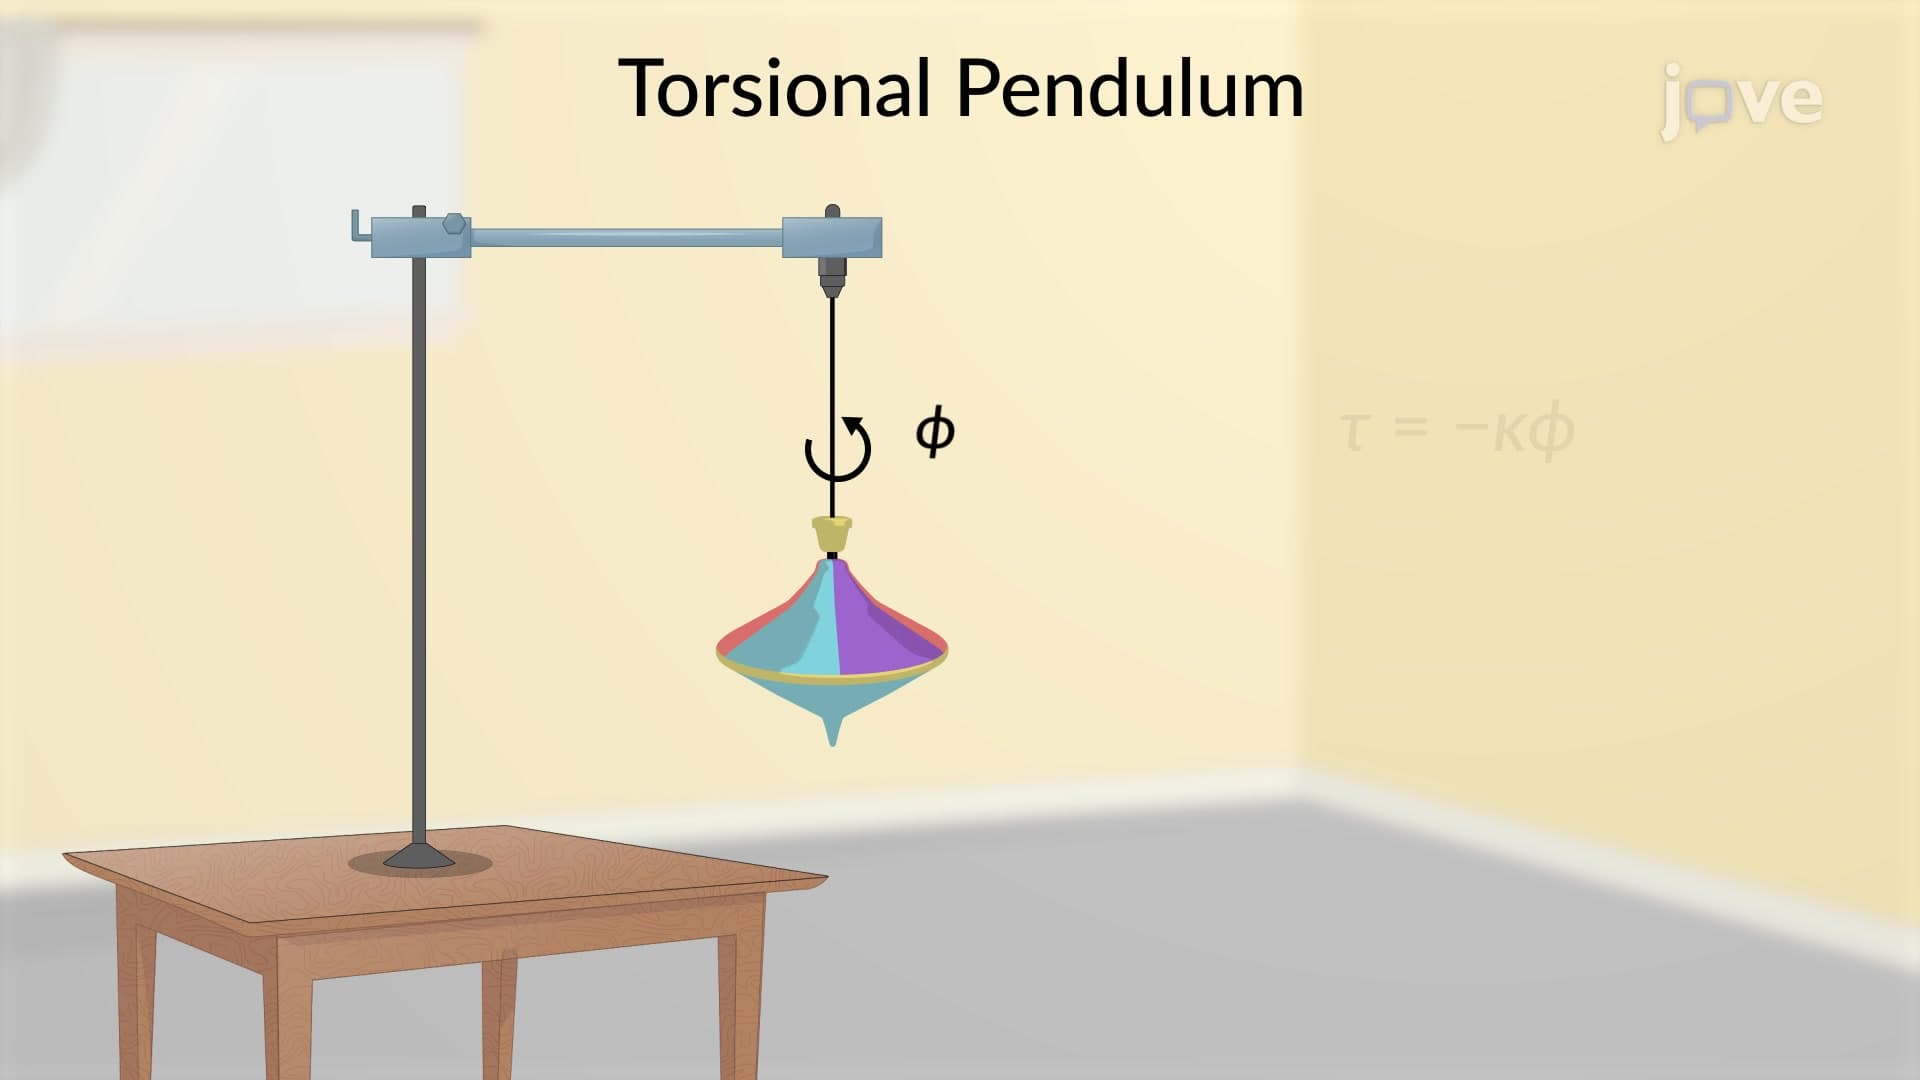
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:15
Model Approaches for Pharmacokinetic Data: Physiological Models
 01:14
Model Approaches for Pharmacokinetic Data: Compartment Models
Two primary types of compartment models are recognized: mammillary and catenary. The more...