Related Experiment Video
Updated: Jan 27, 2026
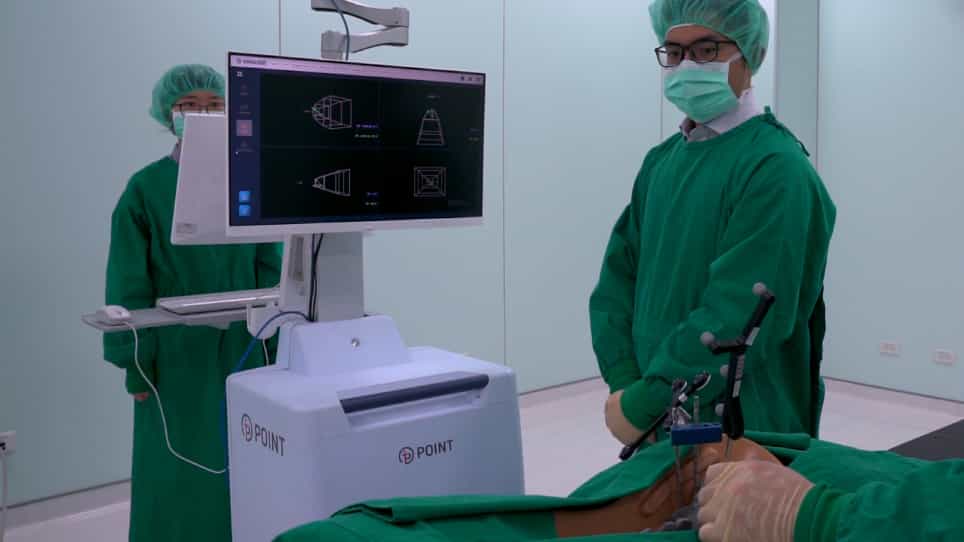

A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Machine learning for automated 3-dimensional segmentation of the spine and suggested placement of pedicle screws
Gustav Burström1,2, Christian Buerger3, Jurgen Hoppenbrouwers4
11Department of Clinical Neuroscience, Karolinska Institutet.

Objective:
The goal of this study was to develop and validate a system for automatic segmentation of the spine, pedicle identification, and screw path suggestion for use with an intraoperative 3D surgical navigation system.
Methods:
Cone-beam CT (CBCT) images of the spines of 21 cadavers were obtained. An automated model-based approach was used for segmentation. Using machine learning methodology, the algorithm was trained and validated on the image data sets. For measuring accuracy, surface area errors of the automatic segmentation were compared to the manually outlined reference surface on CBCT. To further test both technical and clinical accuracy, the algorithm was applied to a set of 20 clinical cases. The authors evaluated the system's accuracy in pedicle identification by measuring the distance between the user-defined midpoint of each pedicle and the automatically segmented midpoint. Finally, 2 independent surgeons performed a qualitative evaluation of the segmentation to judge whether it was adequate to guide surgical navigation and whether it would have resulted in a clinically acceptable pedicle screw placement.
Results:
The clinically relevant pedicle identification and automatic pedicle screw planning accuracy was 86.1%. By excluding patients with severe spinal deformities (i.e., Cobb angle > 75° and severe spinal degeneration) and previous surgeries, a success rate of 95.4% was achieved. The mean time (± SD) for automatic segmentation and screw planning in 5 vertebrae was 11 ± 4 seconds.
Conclusions:
The technology investigated has the potential to aid surgeons in navigational planning and improve surgical navigation workflow while maintaining patient safety.
More Related Videos
Related Concept Videos
 01:16
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.
 01:21
Screw: Problem Solving
To evaluate the...
 01:30
Beams
Based on geometry, beams can be straight, tapered, or curved. Straight beams are the most common type and have a constant cross-section throughout their length. Tapered beams, on the other hand, have a varying cross-section along...
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:19
Machines
A free-body diagram of the...
 03:40
Dimensional Analysis
Conversion Factors and Dimensional Analysis
The unit...