Related Experiment Video
Updated: Jan 27, 2026

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Finite-horizon tracking control for a class of stochastic systems subject to input constraints and hybrid cyber
Xia Zhao1, Chunsheng Liu1, Engang Tian2
1School of Automation Engineering, Nanjing University of Aeronautics and Astronautics, Nanjing 2111106, China.

Abstract:
This paper is concerned with the probabilistic-constrained finite-horizon tracking control problem for a class of stochastic systems subject to randomly occurring hybrid cyber attacks and input constraints. Both the randomly occurring denial-of-service (DOS) attacks and randomly occurring deception attacks are considered in an unified framework. The purpose of the current study is to design an observer-based tracking controller such that: over a finite horizon, (1) the variance of the estimation error is less than certain bound at each time step, (2) the probability of the tracking error falling in certain region should larger than a specified value and the region is minimized at each time step. To achieve those purposes, an improved multi-dimensional Chebyshev inequality method is first utilized to convert the probabilistic constraint to a deterministic one. Then an observer-based tracking control method is designed to estimate the state and design the tracking controller, which are realized through solving a set of recursive linear matrix inequalities. By using the proposed algorithm, the observer and tracking controller gains can be solved out in terms of the solution to a convex optimization problem. A simulation example is finally given to demonstrate the effectiveness and applicability of the proposed method.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
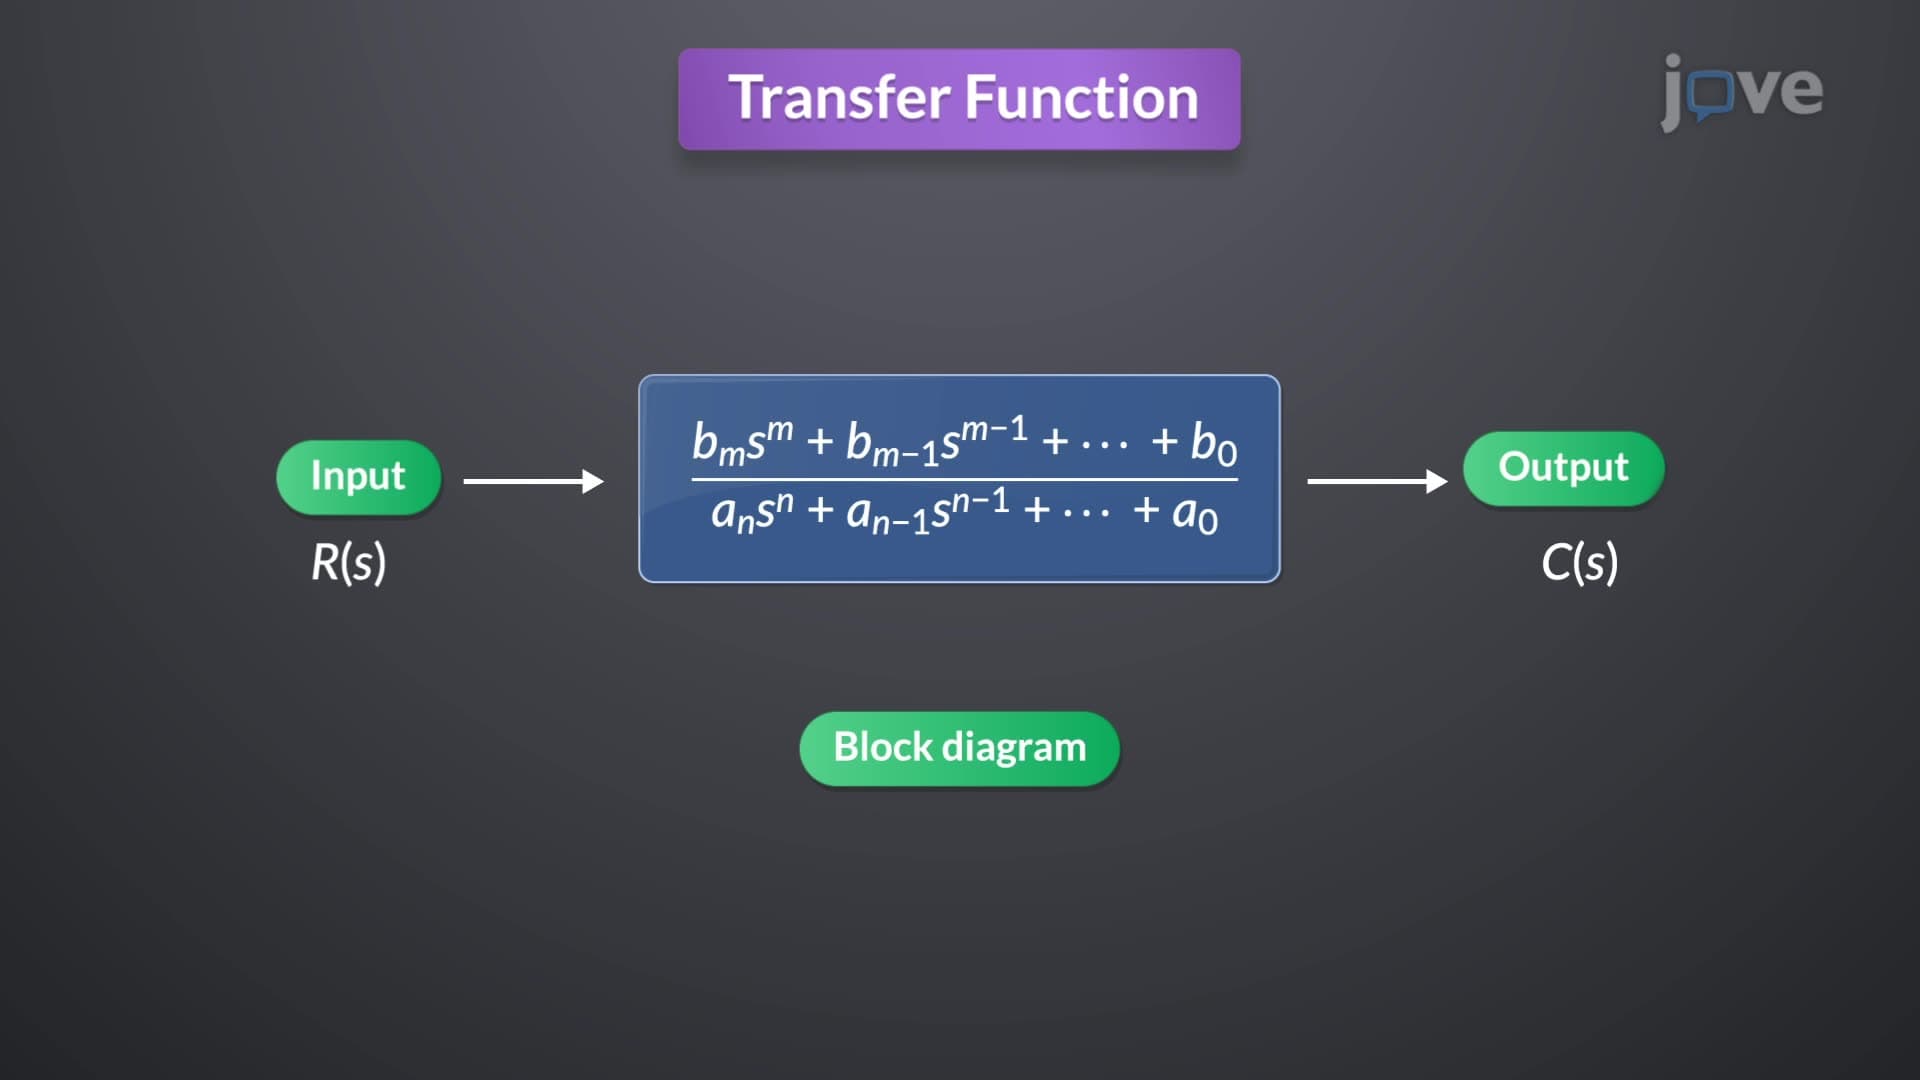
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...