Related Experiment Video
Updated: Jan 27, 2026
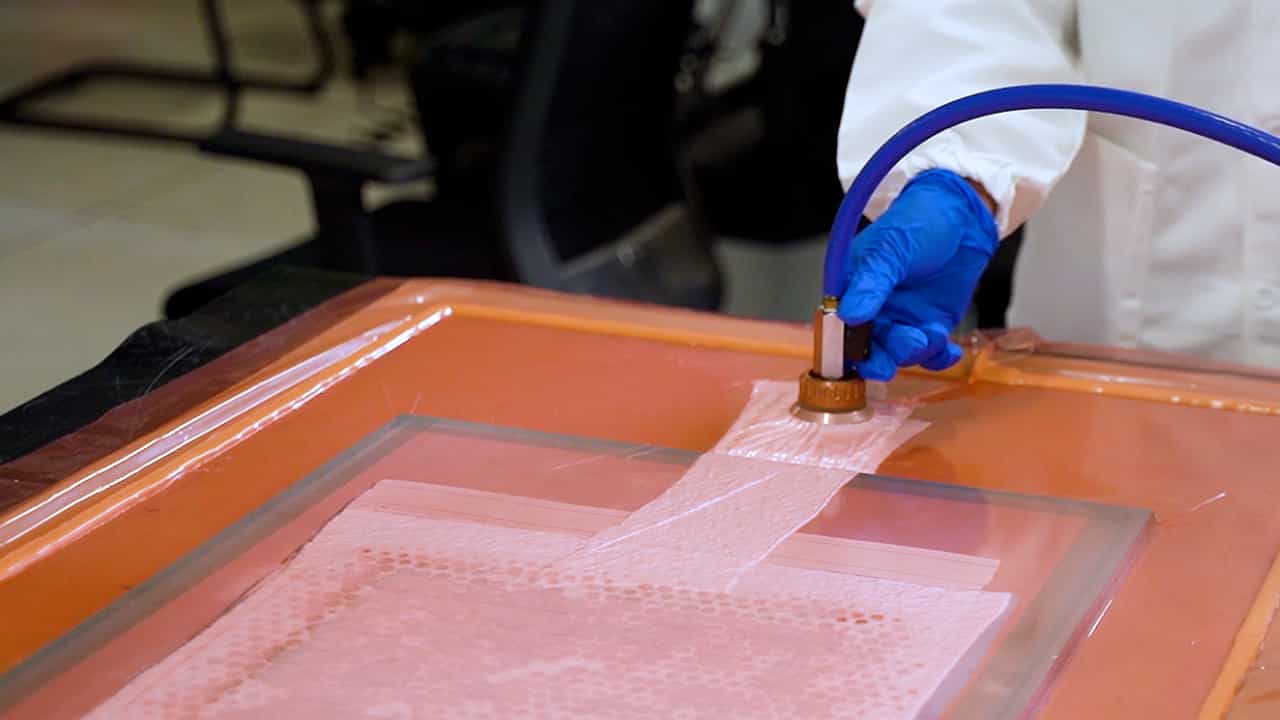

Author Spotlight: Enhancing Fiber Composite Laminate Quality with the Wet Hand Lay-Up/Vacuum Bag Process
Published on: June 30, 2023
Dynamic Modeling of Fiber-Reinforced Soft Manipulator: A Visco-Hyperelastic Material-Based Continuum Mechanics
Seri Mastura Mustaza1,2, Yahya Elsayed3, Constantina Lekakou3
11 Department of Electronic Engineering, Faculty of Engineering and Physical Sciences, University of Surrey, Guildford, United Kingdom.

Abstract:
Robot-assisted surgery is gaining popularity worldwide and there is increasing scientific interest to explore the potential of soft continuum robots for minimally invasive surgery. However, the remote control of soft robots is much more challenging compared with their rigid counterparts. Accurate modeling of manipulator dynamics is vital to remotely control the diverse movement configurations and is particularly important for safe interaction with the operating environment. However, current dynamic models applied to soft manipulator systems are simplistic and empirical, which restricts the full potential of the new soft robots technology. Therefore, this article provides a new insight into the development of a nonlinear dynamic model for a soft continuum manipulator based on a material model. The continuum manipulator used in this study is treated as a composite material and a modified nonlinear Kelvin-Voigt material model is utilized to embody the visco-hyperelastic dynamics of soft silicone. The Lagrangian approach is applied to derive the equation of motion of the manipulator. Simulation and experimental results prove that this material modeling approach sufficiently captures the nonlinear time- and rate-dependent behavior of a soft manipulator. Material model-based closed-loop trajectory control was implemented to further validate the feasibility of the derived model and increase the performance of the overall system.
Related Concept Videos
 01:22
Fiber Reinforced Concrete
 02:45
The Quantum-Mechanical Model of an Atom
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example:
 01:27
Corrosion of Reinforcement
However, over time and under certain conditions like carbonation, chloride ingress, and cracking this protective state can be compromised. Steel has areas with...
 01:24
Reinforcement Schedules
Once a behavior is learned,...
 01:25
Reinforcements in Concrete