Rigid helical-like assemblies from a self-aggregating tripeptide
Related Experiment Video
Updated: Jan 26, 2026
Self-assembling Morphologies Obtained from Helical Polycarbodiimide Copolymers and Their Triazole Derivatives
Published on: February 7, 2017
Santu Bera1, Sudipta Mondal1, Bin Xue2
1Department of Molecular Microbiology and Biotechnology, George S. Wise Faculty of Life Sciences, Tel Aviv University, Ramat Aviv, Israel.

Abstract:
The structural versatility, biocompatibility and dynamic range of the mechanical properties of protein materials have been explored in functional biomaterials for a wide array of biotechnology applications. Typically, such materials are made from self-assembled peptides with a predominant β-sheet structure, a common structural motif in silk and amyloid fibrils. However, collagen, the most abundant protein in mammals, is based on a helical arrangement. Here we show that Pro-Phe-Phe, the most aggregation-prone tripeptide of natural amino acids, assembles into a helical-like sheet that is stabilized by the dry hydrophobic interfaces of Phe residues. This architecture resembles that of the functional PSMα3 amyloid, highlighting the role of dry helical interfaces as a core structural motif in amyloids. Proline replacement by hydroxyproline, a major constituent of collagen, generates minimal helical-like assemblies with enhanced mechanical rigidity. These results establish a framework for designing functional biomaterials based on ultrashort helical protein elements.
Related Concept Videos
 00:49
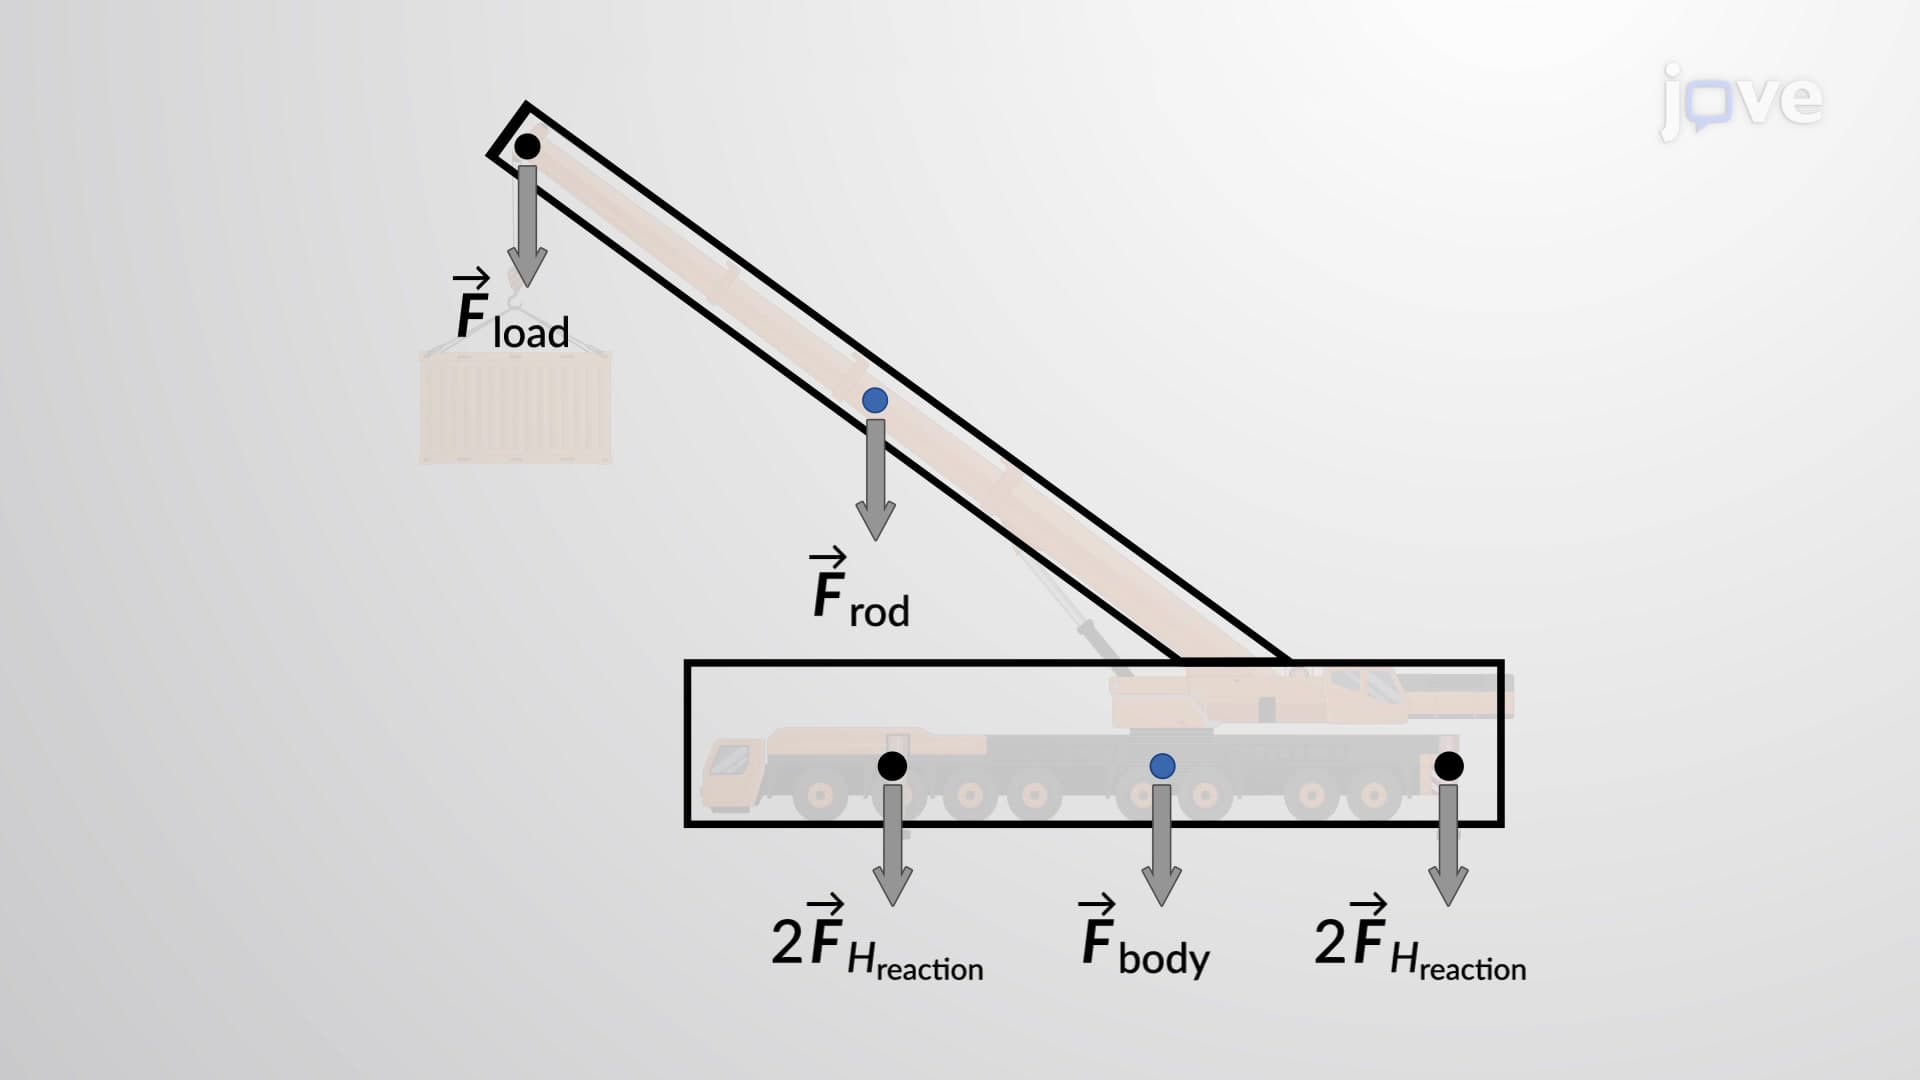
Rigid Body Equilibrium Problems - I
 02:41
Protein Complex Assembly
Many viruses self-assemble into a fully functional unit using the infected host cell to...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:13
Kinetic Energy for a Rigid Body
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...