Related Experiment Video
Updated: Jan 26, 2026


A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
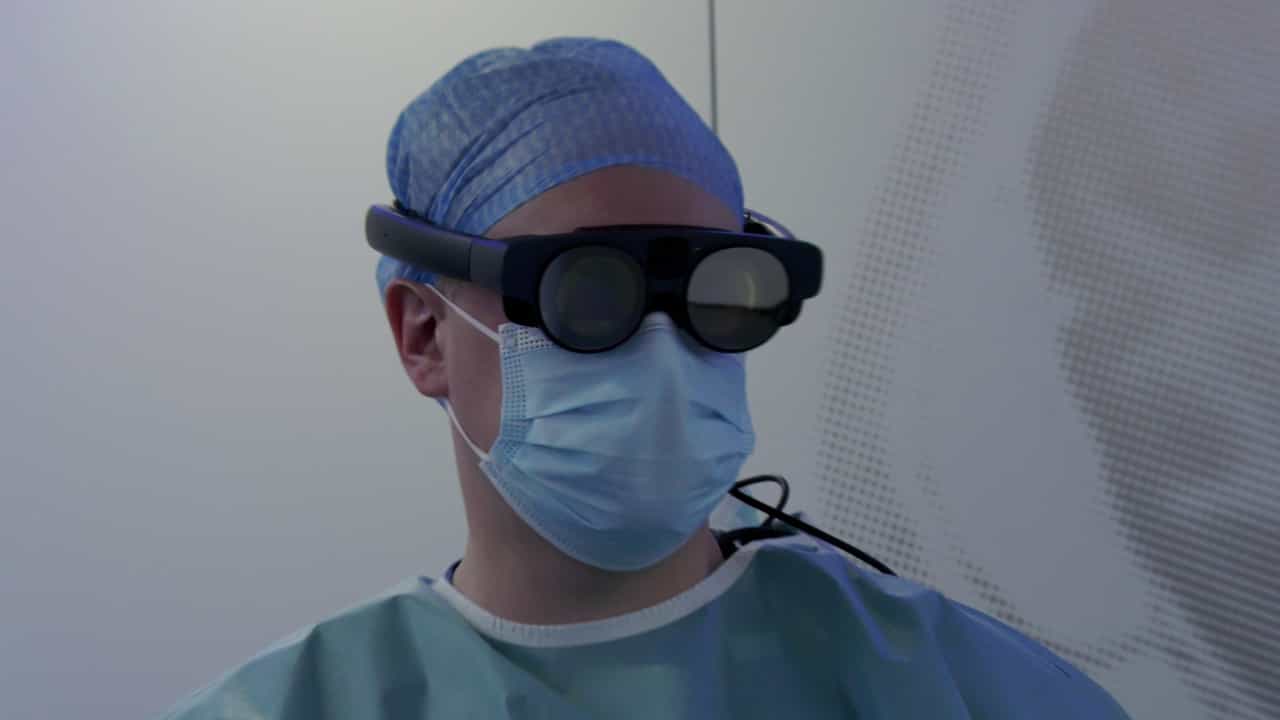
Pedicle screw navigation using surface digitization on the Microsoft HoloLens
Florentin Liebmann1,2, Simon Roner3,4, Marco von Atzigen3,5
1Computer Assisted Research and Development Group, Balgrist University Hospital, University of Zurich, Forchstrasse 340, 8008, Zurich, Switzerland. florentin.liebmann@balgrist.ch.

Purpose:
In spinal fusion surgery, imprecise placement of pedicle screws can result in poor surgical outcome or may seriously harm a patient. Patient-specific instruments and optical systems have been proposed for improving precision through surgical navigation compared to freehand insertion. However, existing solutions are expensive and cannot provide in situ visualizations. Recent technological advancement enabled the production of more powerful and precise optical see-through head-mounted displays for the mass market. The purpose of this laboratory study was to evaluate whether such a device is sufficiently precise for the navigation of lumbar pedicle screw placement.
Methods:
A novel navigation method, tailored to run on the Microsoft HoloLens, was developed. It comprises capturing of the intraoperatively reachable surface of vertebrae to achieve registration and tool tracking with real-time visualizations without the need of intraoperative imaging. For both surface sampling and navigation, 3D printable parts, equipped with fiducial markers, were employed. Accuracy was evaluated within a self-built setup based on two phantoms of the lumbar spine. Computed tomography (CT) scans of the phantoms were acquired to carry out preoperative planning of screw trajectories in 3D. A surgeon placed the guiding wire for the pedicle screw bilaterally on ten vertebrae guided by the navigation method. Postoperative CT scans were acquired to compare trajectory orientation (3D angle) and screw insertion points (3D distance) with respect to the planning.
Results:
The mean errors between planned and executed screw insertion were [Formula: see text] for the screw trajectory orientation and 2.77±1.46 mm for the insertion points. The mean time required for surface digitization was 125±27 s.
Conclusions:
First promising results under laboratory conditions indicate that precise lumbar pedicle screw insertion can be achieved by combining HoloLens with our proposed navigation method. As a next step, cadaver experiments need to be performed to confirm the precision on real patient anatomy.
Related Concept Videos
 01:16
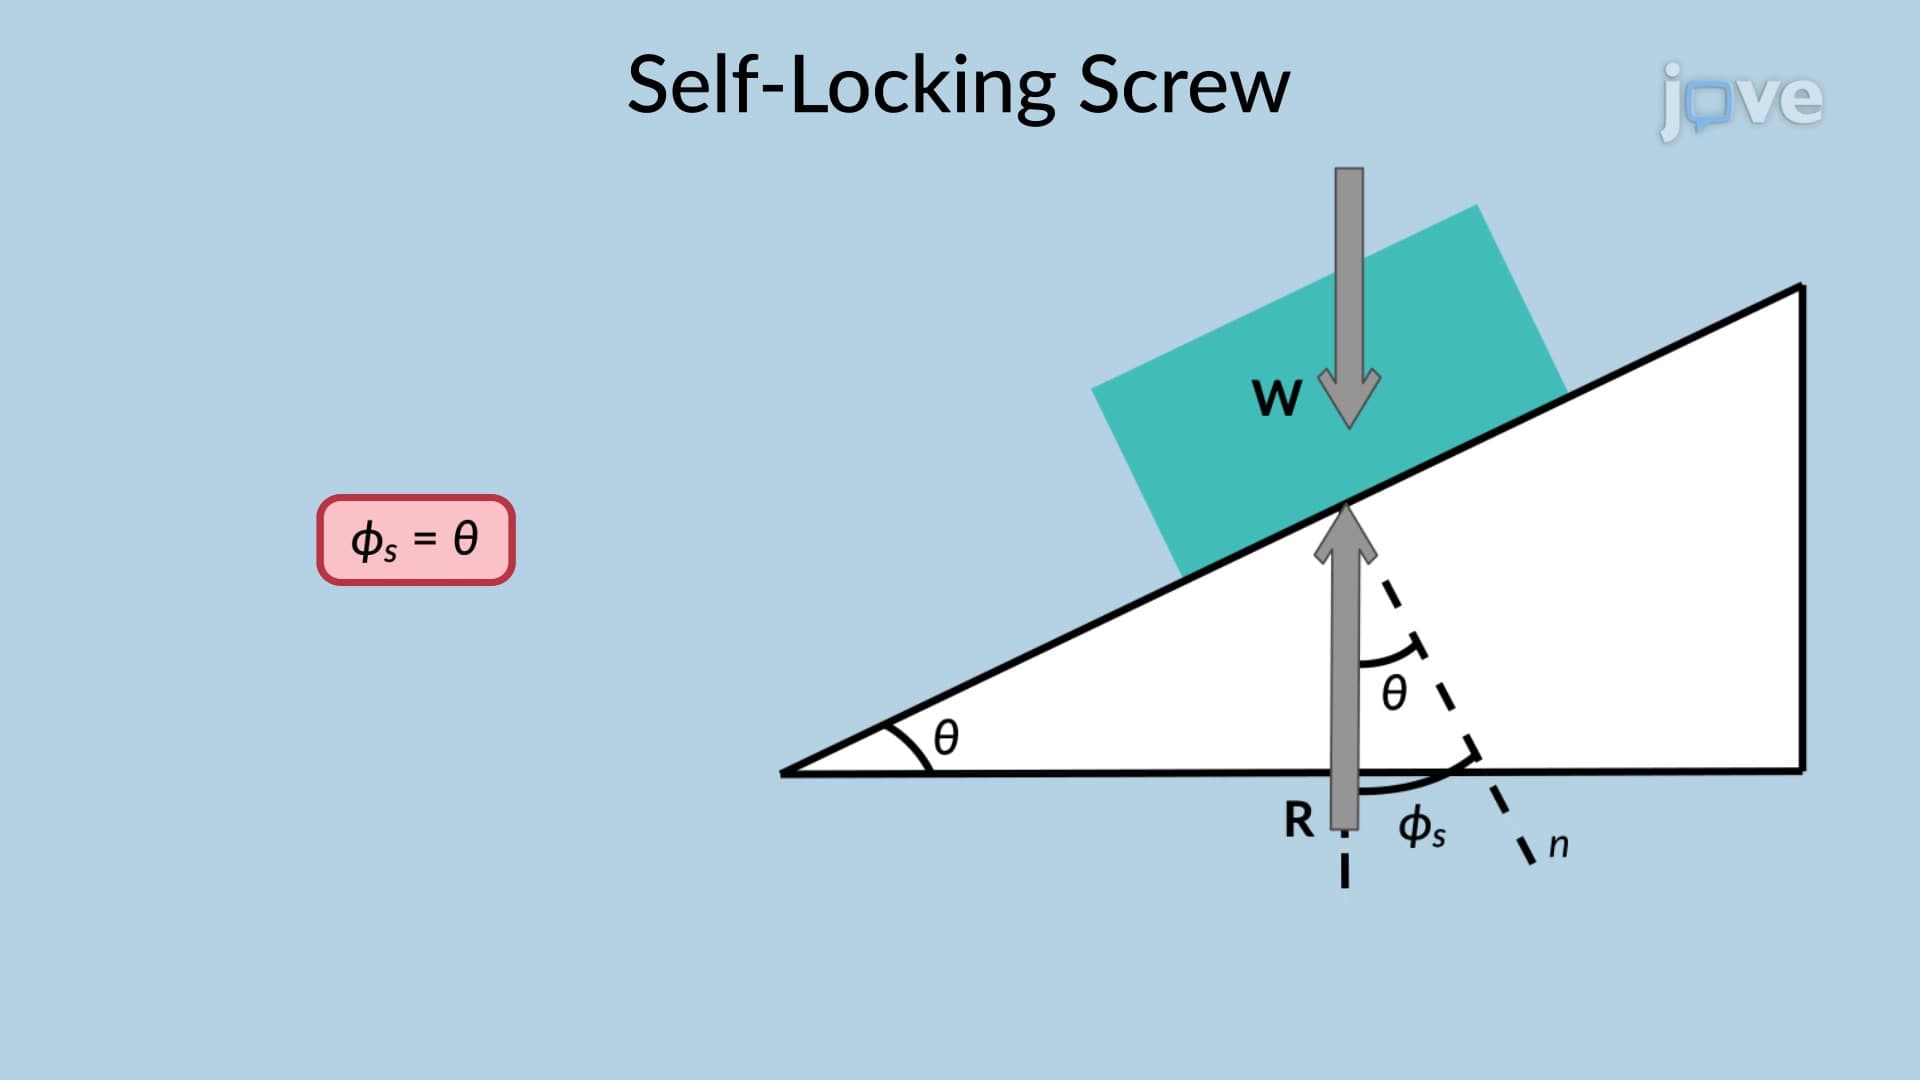
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.
 01:21
Screw: Problem Solving
To evaluate the...
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:16
Surface Tension and Surface Energy
Consider a beaker filled with liquid. The bulk molecules in the liquid experience equal attractive forces on all sides with the surrounding molecules. However, the surface molecules experience a net attractive force downward due to the bulk molecules. The surface of the liquid behaves like a stretched membrane,...
 01:14
Wood Surfacing
The equipment used in the surfacing process is a plane equipped with rotating blades. This tool efficiently smoothens the wood surface and can...
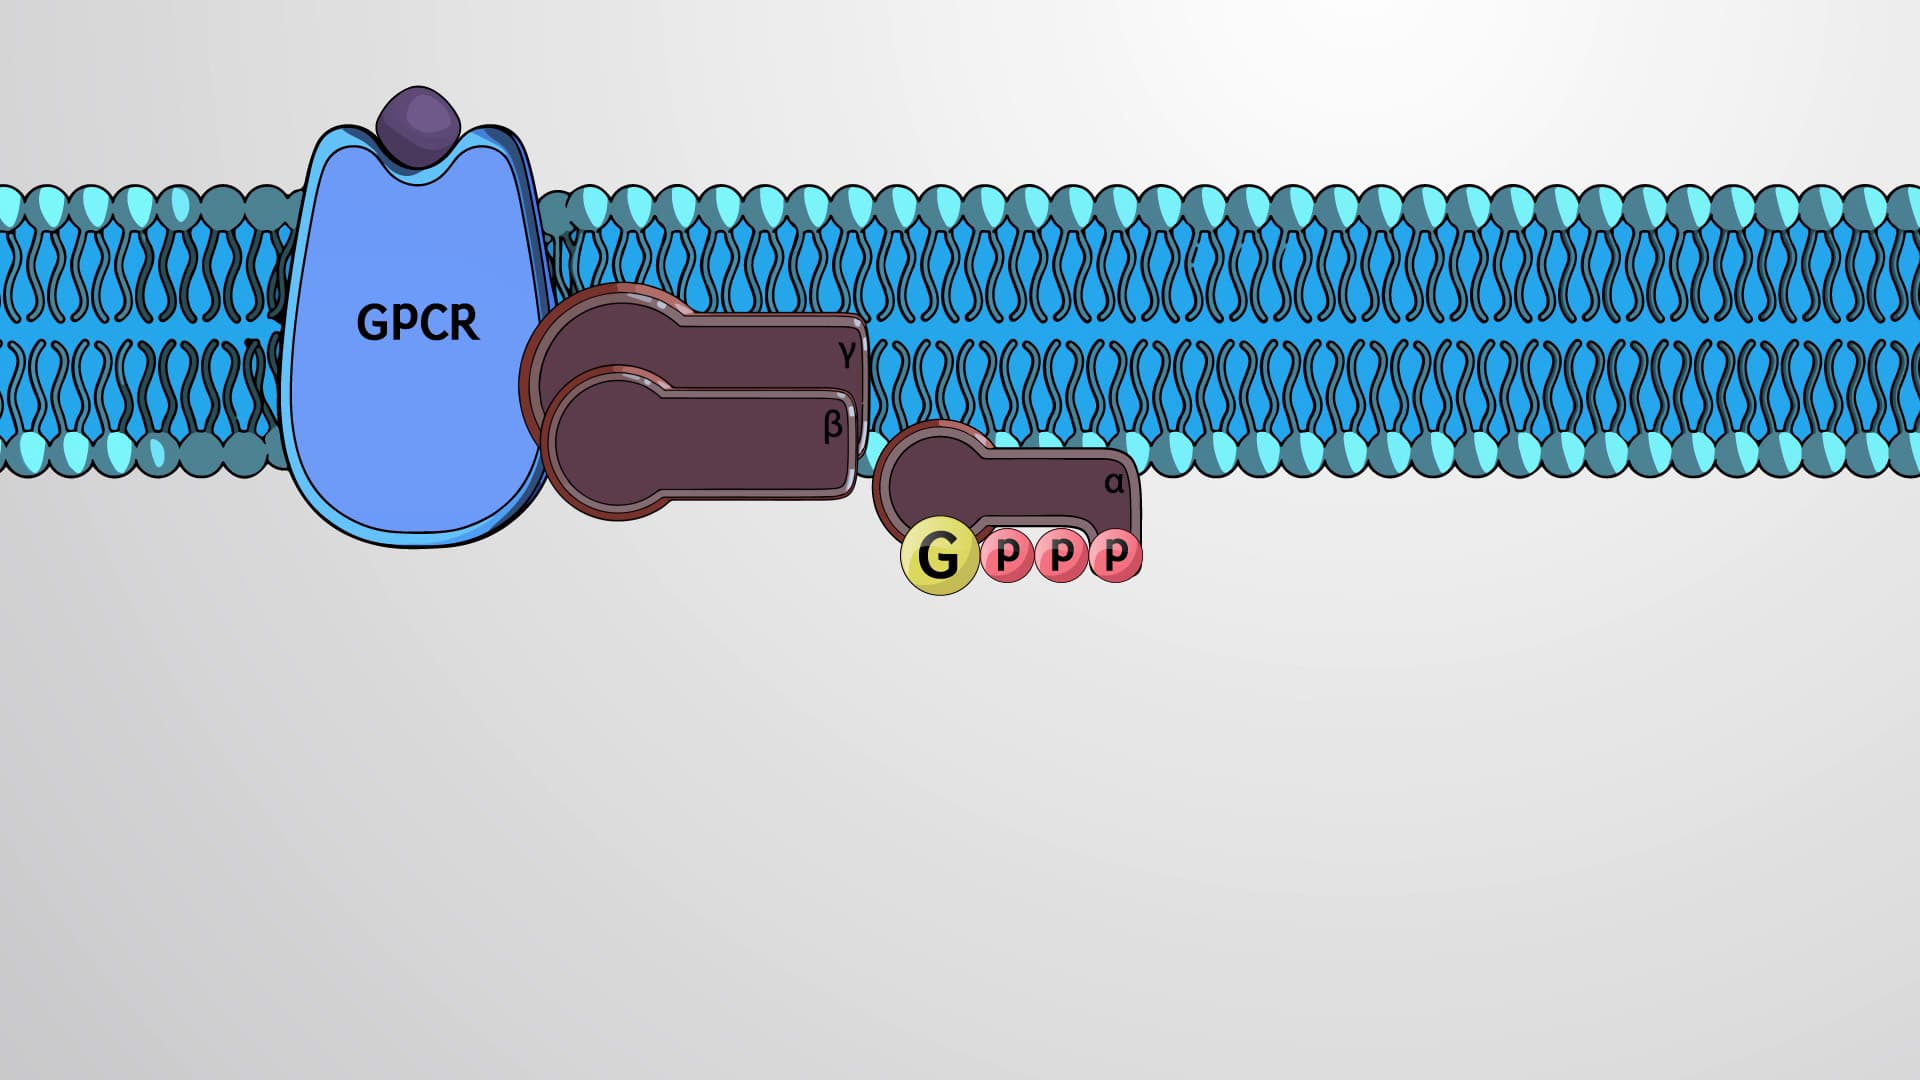 01:21
Cell-surface Signaling