Related Experiment Video
Updated: Jan 24, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Dynamic Parameter Identification for a Manipulator with Joint Torque Sensors Based on an Improved Experimental Design
Jidong Jia1,2, Minglu Zhang3, Xizhe Zang4
1School of Mechanical Engineering, Hebei University of Technology, Tianjin 300130, China. jiajidong.0724@163.com.

Abstract:
As the foundation of model control, robot dynamics is crucial. However, a robot is a complex multi-input-multi-output system. System noise seriously affects parameter identification results, thereby inevitably requiring us to conduct signal processing to extract useful signals from chaotic noise. In this research, the dynamic parameters were identified on the basis of the proposed multi-criteria embedded optimization design method, to obtain the optimal excitation signal and then use maximum likelihood estimation for parameter identification. Considering the movement coupling characteristics of the multi-axis, experiments were based on a two degrees-of-freedom manipulator with joint torque sensors. Simulation and experimental results showed that the proposed method can reasonably resolve the problem of mutual opposition within a single criterion and improve the identification robustness in comparison with other optimization criteria. The mean relative standard deviation was 0.04 and 0.3 lower in the identified parameters than in F1 and F3, respectively, thus signifying that noise is effectively alleviated. In addition, validation experimental curves were close to the estimation model, and the average of root mean square (RMS) is 0.038, thereby confirming the accuracy of the proposed method.
Related Concept Videos
 01:28
Design Example: Joints in Concrete Pavements
Contraction joints are typically formed by sawing a groove into the concrete shortly after it has hardened. This creates a weakened vertical plane, deliberately encouraging cracking at...
 01:16
Experimental Designs
 01:10
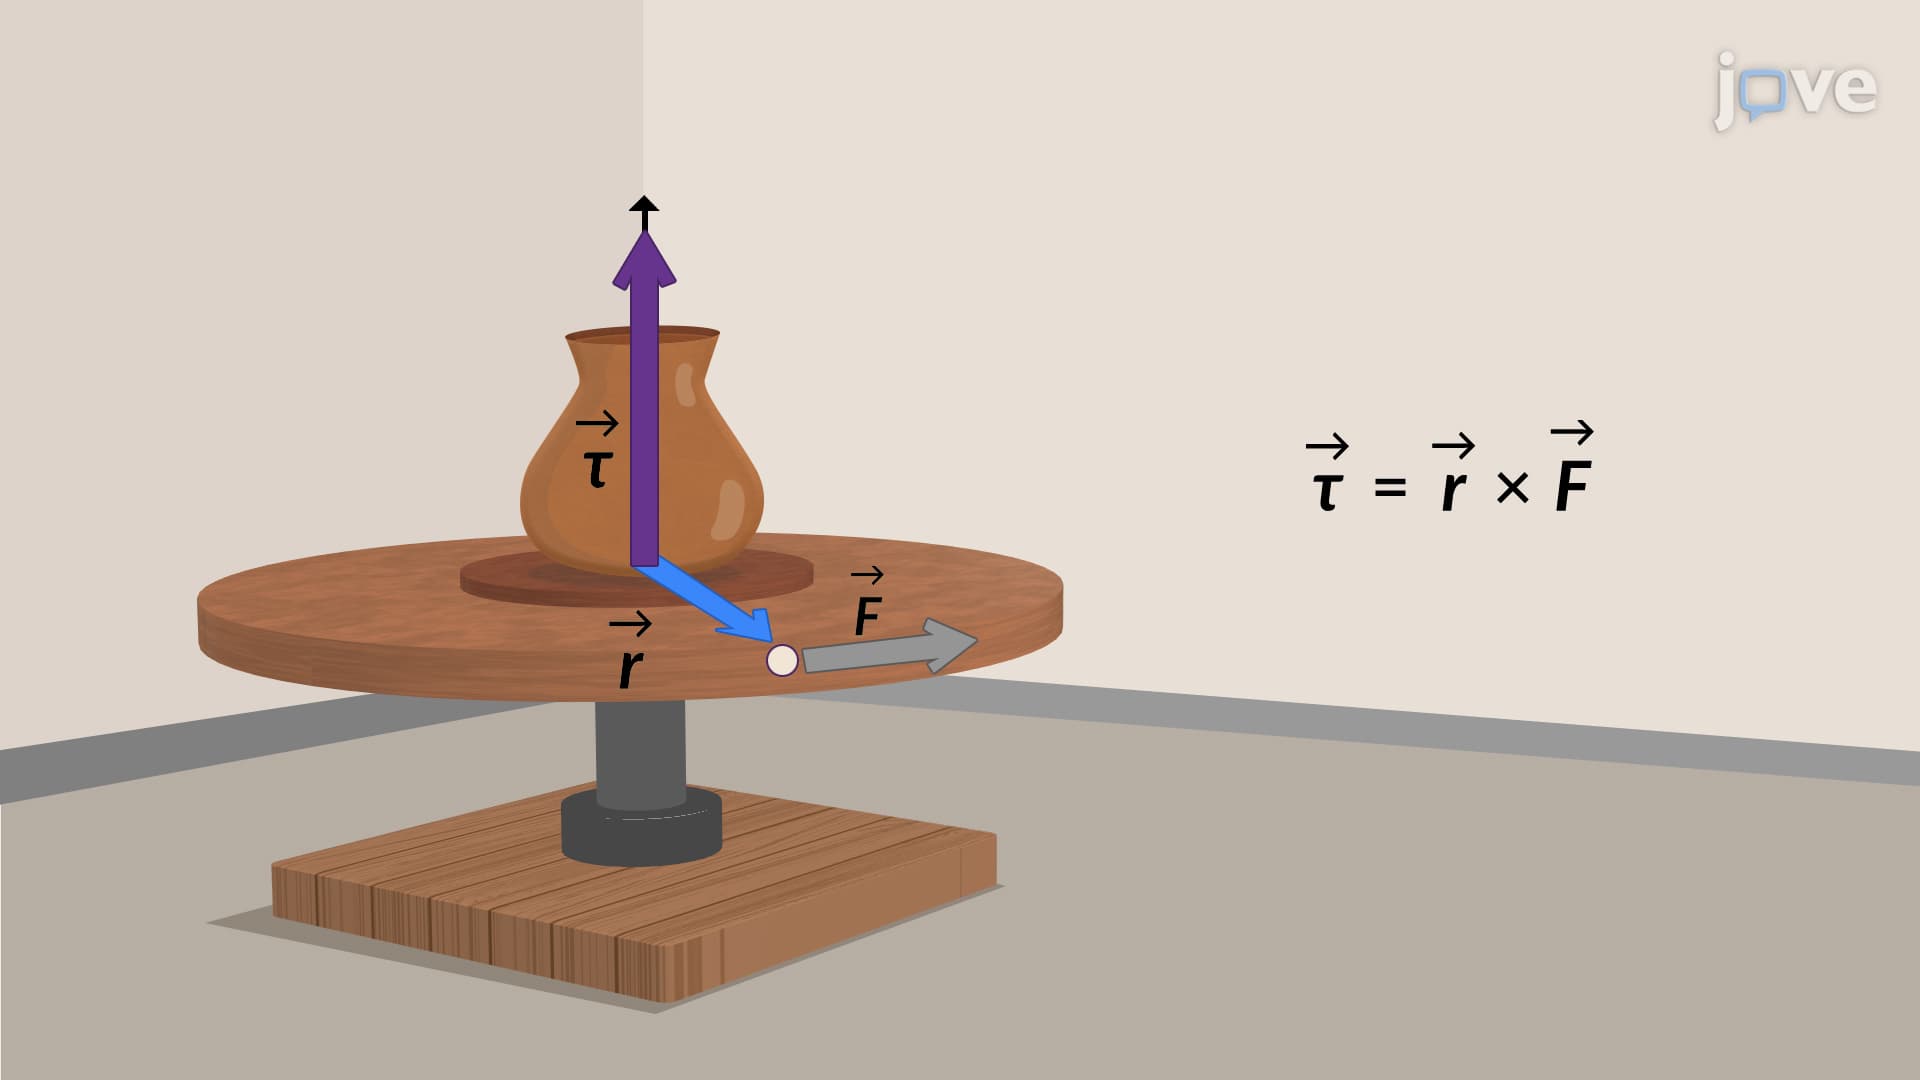
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:15
Torque Free Motion
 01:19
Net Torque Calculations
 01:20
Bioequivalence Experimental Study Designs: Completely Randomized and Randomized Block Designs