Modular Continuum Manipulator: Analysis and Characterization of Its Basic Module
Related Experiment Video
Updated: Jan 24, 2026
Characterization of Anisotropic Leaky Mode Modulators for Holovideo
Published on: March 19, 2016
Anand Kumar Mishra1,2, Alessio Mondini3, Emanuela Del Dottore4,5
1Center for Micro-BioRobotics, Istituto Italiano di Tecnologia, 56025 Pontedera, Italy. anand.mishra@iit.it.

Abstract:
We present the basic module of a modular continuum arm (soft compliant manipulator for broad applications (SIMBA)). SIMBA is a robotic arm with a hybrid structure, namely a combination of rigid and soft components, which makes the arm highly versatile, dexterous, and robust. These key features are due to the design of its basic module, which is characterized by a three-dimensional workspace with a constant radius around its rotation axis, large and highly repeatable bending, complete rotation, and passive stiffness. We present an extensive analysis and characterization of the basic module of the SIMBA arm in terms of design, fabrication, kinematic model, stiffness, and bending behavior. All the theoretical models presented were validated with empirical results. Our findings show a positional typical error of less than ≈6% in module diameter (highly repeatable) with a passive stiffness of 0.8 N/mm (≈1 kg load). Our aim is to demonstrate that this kind of robotic element can be exploited as an elementary module of a more complex structure, which can be used in any application requiring high directional stiffness but without the need for an active stiffness mechanism, as is the case in daily activities (e.g., door opening, water pouring, obstacle avoidance, and manipulation tasks).
Related Concept Videos
 01:21
Manipulation and Analysis
 02:27
Energy Basics
 01:22
Basic Operations on Signals
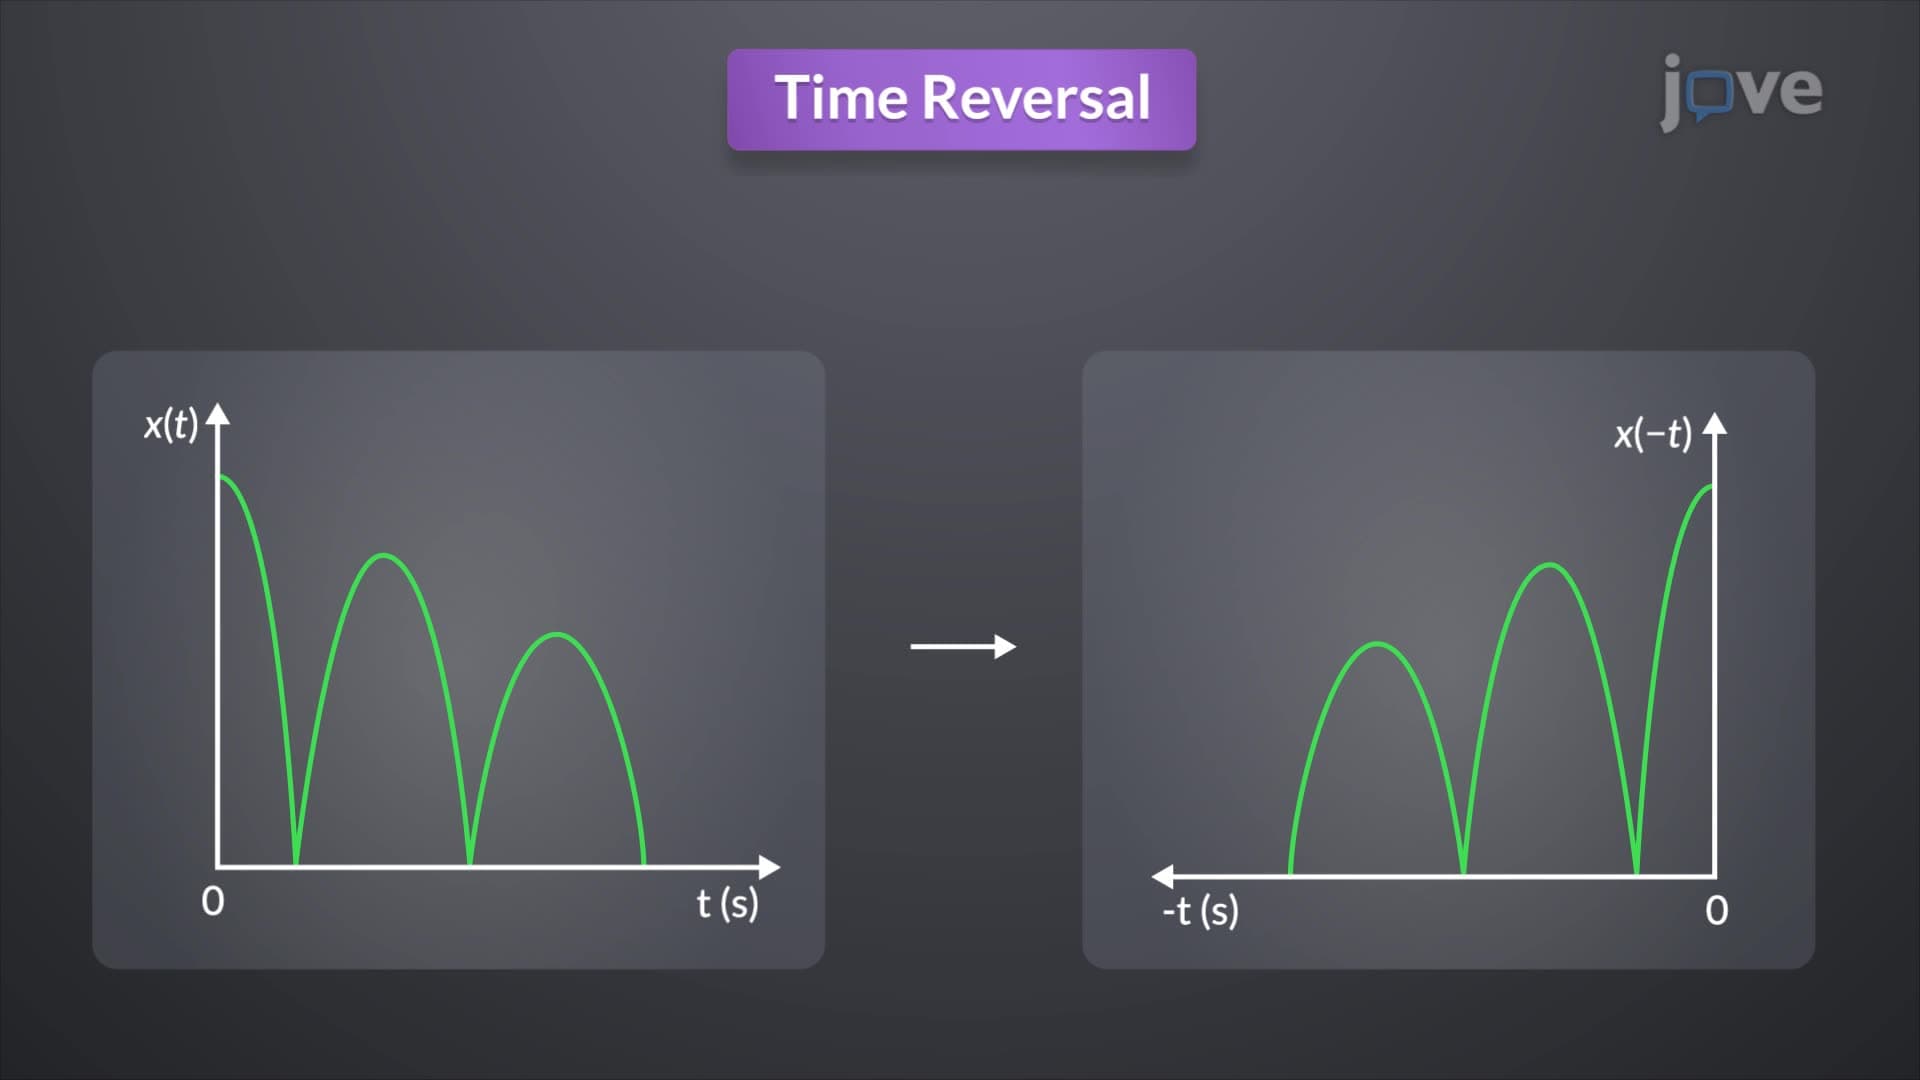
Time Reversal mirrors a continuous-time signal about the vertical axis at t=0. This is achieved by substituting t with −t. For example, if a signal x(t) is considered, the time-reversed signal is x(−t). This operation can be graphically represented, showing the mirrored signal.
 01:21
Basicity of Aliphatic Amines
To measure the basicity of amines, two conventions are generally used. The first defines Kb as the basicity constant for the deprotonation reaction of water by the amine, as presented in Figure 1. Conventionally, lower Kb indicates higher...
 02:52
VSEPR Theory and the Basic Shapes
 01:28
Basic Concept
Length, which measures the distance traveled by an object, is a fundamental concept in engineering mechanics. We use coordinates relative to a reference point to describe the distance. Length not only helps to describe the...