Related Experiment Video
Updated: Jan 24, 2026

Three-Dimensional Imaging of Tumor-Bearing Tissue Using the Iterative Bleaching Extends Multiplexity Approach
Published on: April 25, 2025
Georeferencing of Laser Scanner-Based Kinematic Multi-Sensor Systems in the Context of Iterated Extended Kalman
Sören Vogel1, Hamza Alkhatib2, Johannes Bureick3
1Geodetic Institute, Leibniz Universität Hannover, Nienburger Str. 1, 30167 Hannover, Germany. vogel@gih.uni-hannover.de.

Abstract:
Georeferencing is an indispensable necessity regarding operating with kinematic multi-sensor systems (MSS) in various indoor and outdoor areas. Information from object space combined with various types of prior information (e.g., geometrical constraints) are beneficial especially in challenging environments where common solutions for pose estimation (e.g., global navigation satellite system or external tracking by a total station) are inapplicable, unreliable or inaccurate. Consequently, an iterated extended Kalman filter is used and a general georeferencing approach by means of recursive state estimation is introduced. This approach is open to several types of observation inputs and can deal with (non)linear systems and measurement models. The capability of using both explicit and implicit formulations of the relation between states and observations, and the consideration of (non)linear equality and inequality state constraints is a special feature. The framework presented is evaluated by an indoor kinematic MSS based on a terrestrial laser scanner. The focus here is on the impact of several different combinations of applied state constraints and the dependencies of two classes of inertial measurement units (IMU). The results presented are based on real measurement data combined with simulated IMU measurements.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:15
Geometric Mean
In cases of multiplicative data, the geometric mean is used for statistical analysis. First, the product of all the elements is taken. Then, if there are n elements in the...
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:30
Self Within Cultural Contexts
 01:26
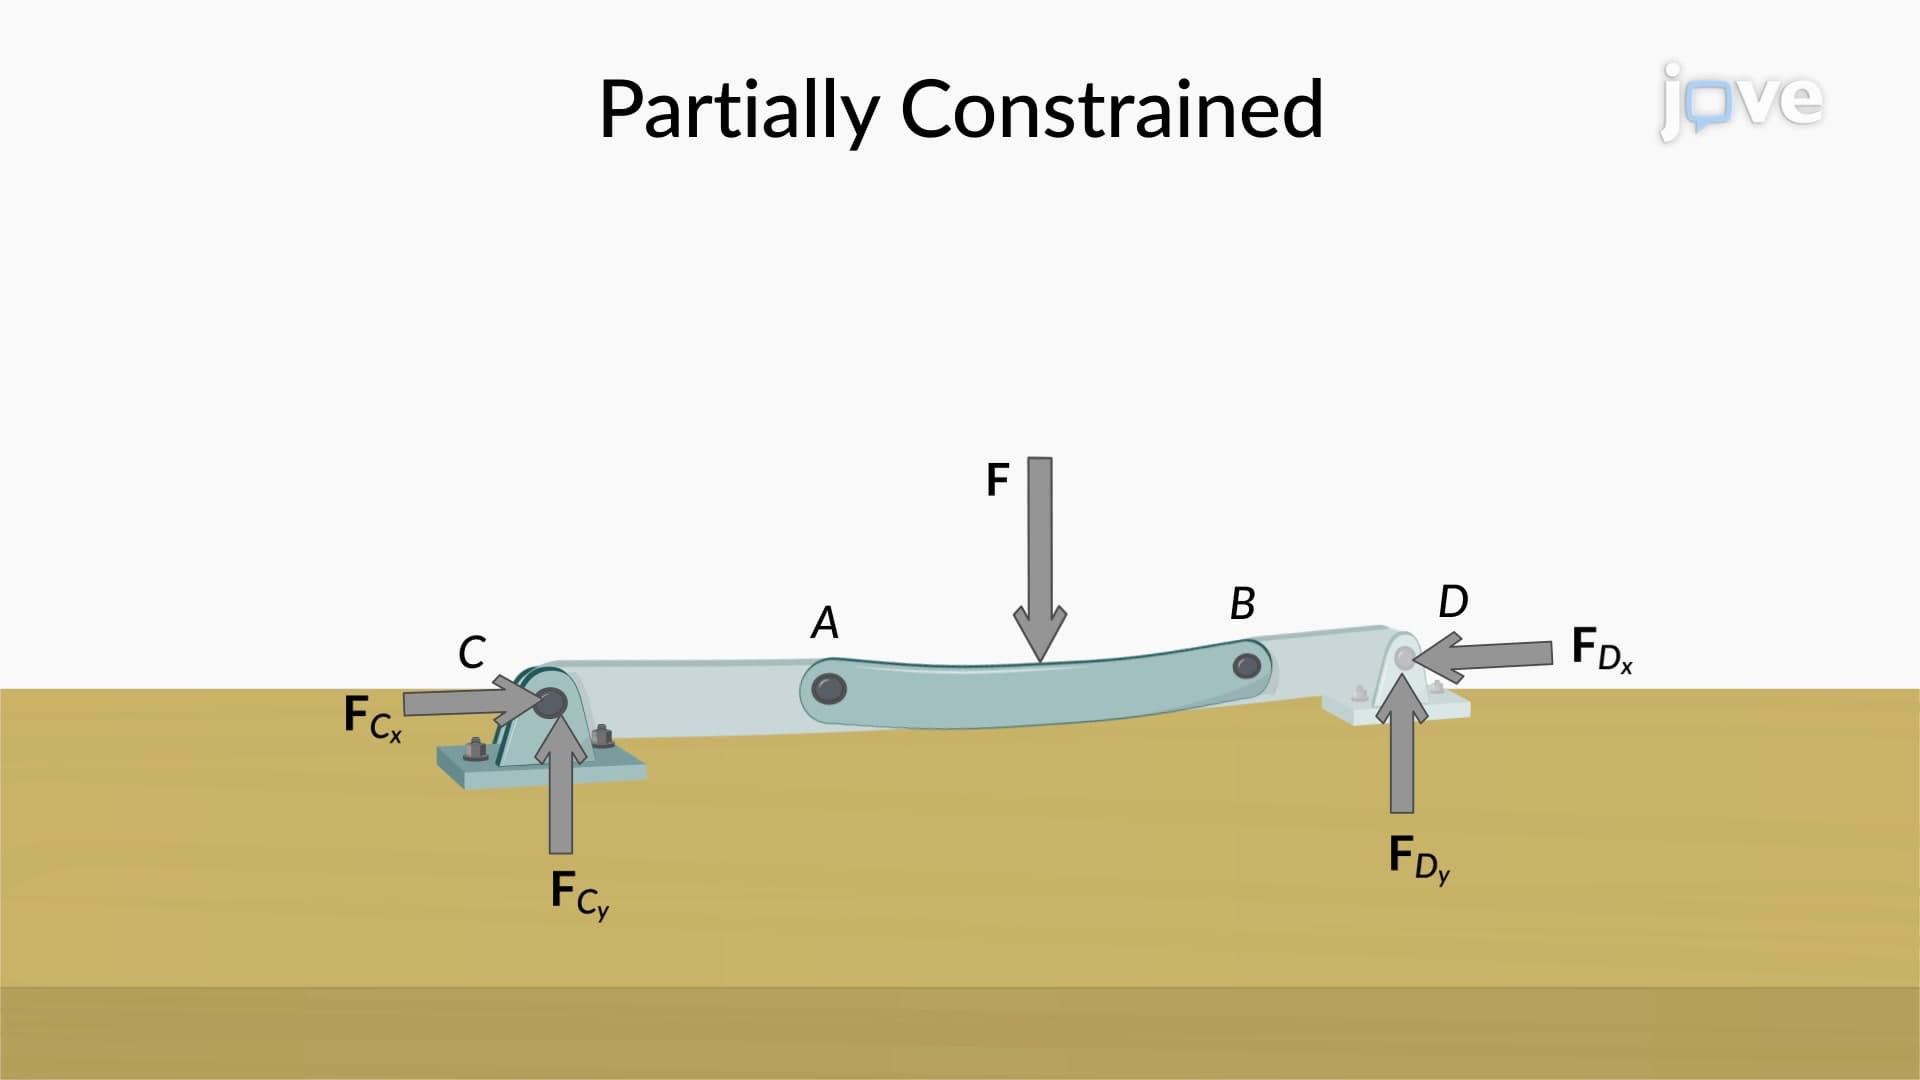
Constraints and Statical Determinacy
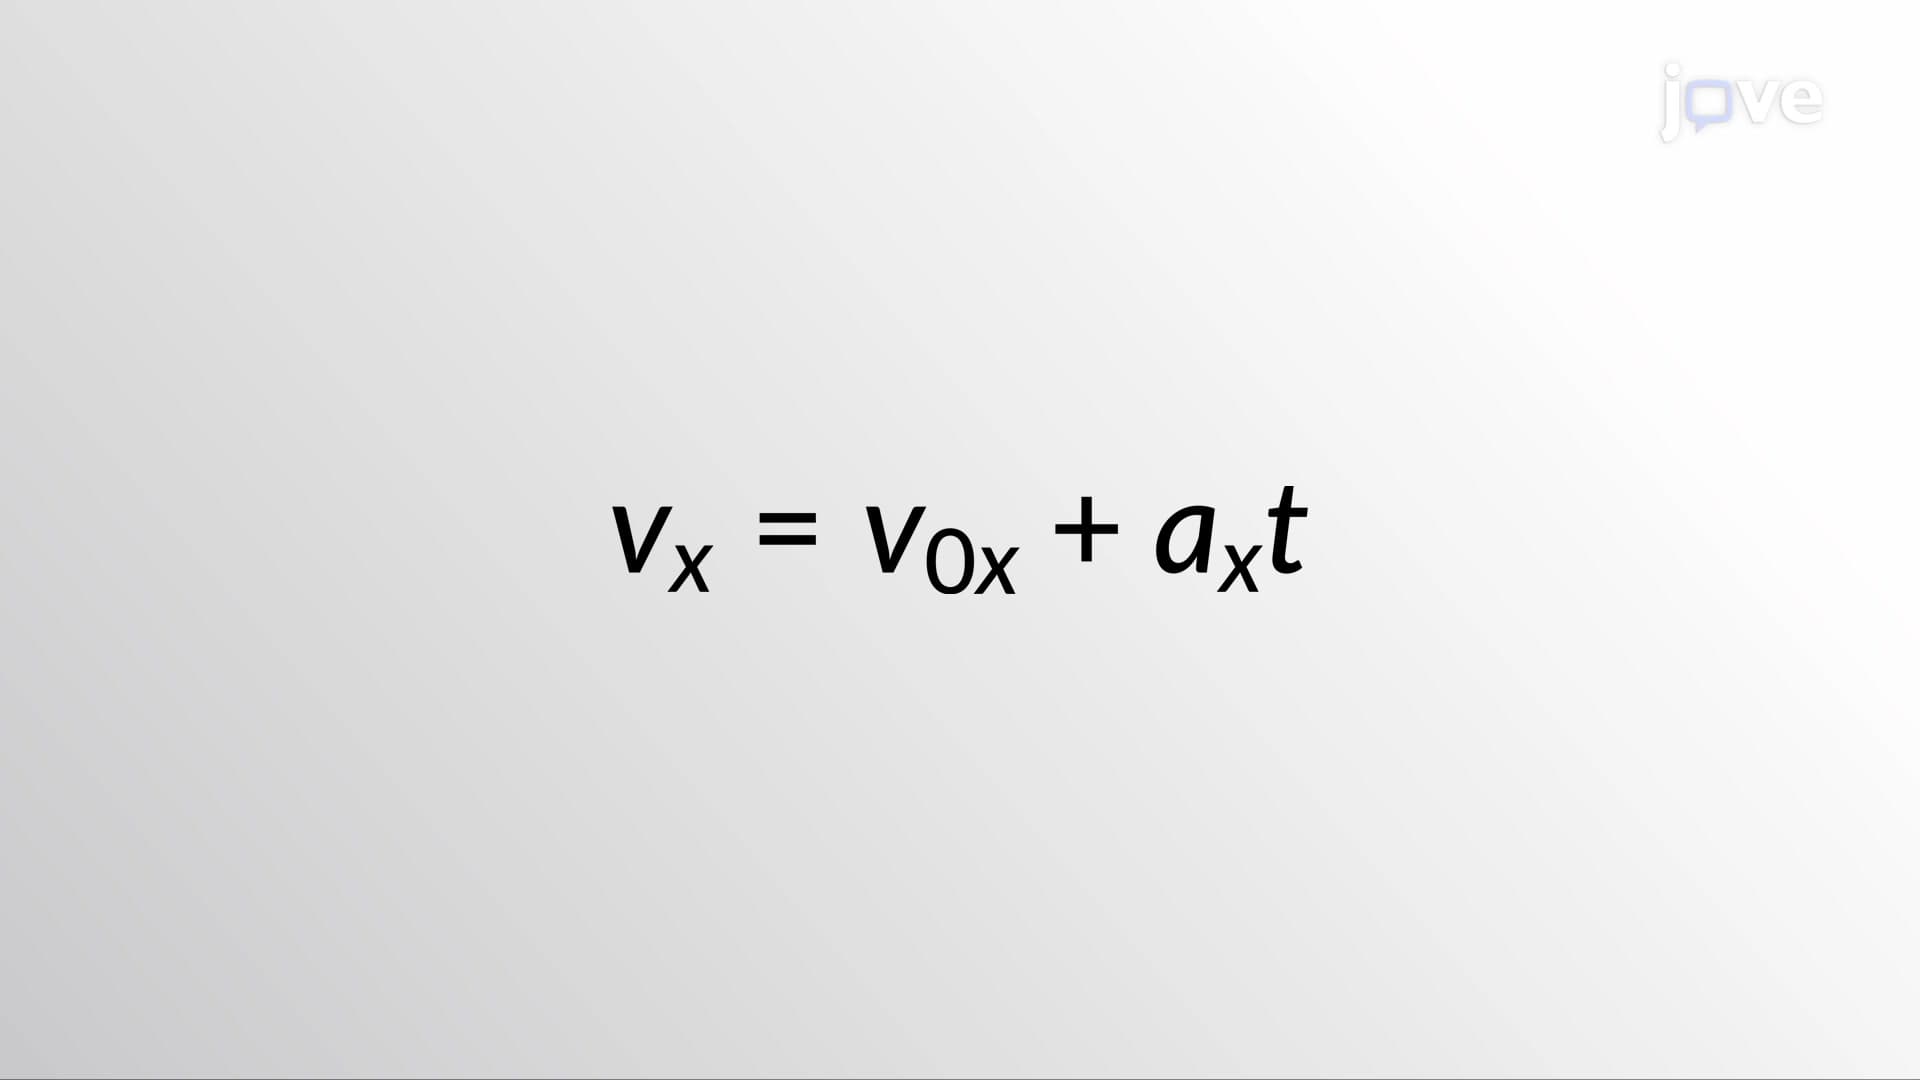 01:26
Kinematic Equations - I