Related Experiment Video
Updated: Jan 24, 2026

A Mouse Model of Lumbar Spine Instability
Published on: April 23, 2021
Kinematics Following 3-Screw Integrated Interbody Spacers in the Lumbar Spine
Robert F Heary1, Nitin Agarwal2, Naresh K Parvathreddy1
1Department of Neurological Surgery, Rutgers New Jersey Medical School, Newark, New Jersey.

Background:
"Stand-alone" fusion implants attempt to alleviate the need for supplemental posterior instrumentation.
Objective:
A biomechanical study was conducted to assess the stability of an integrated 3- screw interbody cage with, and without, supplemental posterior fixation.
Methods:
Nondestructive biomechanical testing was performed on 19 healthy cadaver spine segments. Specimens were tested in 6 degrees of motion and a maximum pure bending moment of 10 Nm was applied. Specimens were evaluated in the following sequence: Intact, cage, cage ± facet bolts, and cage ± pedicle screws. Nonconstrained motion was measured at both the index and adjacent levels.
Results:
The index levels were L2-L3 and L5-S1. The cage alone provided a significant decrease in motion at the L2-L3 level but not at L5-S1. At L2-L3, cage + pedicle screws decreased motion more effectively than cage + facet bolts, however, both the supplemented constructs outperformed intact (P < .05). At L5-S1, both posterior fixation systems appeared to have smaller degree of displacement compared to intact; however, no significant differences were observed at L5-S1 among the various constructs. Furthermore, the adjacent segments for each level (L1-L2 and L4-L5) had no significantly increased motion, compared to intact, for all 6 degrees of motion tested.
Conclusion:
The stand-alone cage was more effective at L2-L3, than at L5-S1, in limiting motion. At L5-S1, supplemental fixation may need to be considered. No abnormal motion was identified at the adjacent, normal segments, for the stand-alone, or the circumferential constructs at either level tested.
More Related Videos
Related Concept Videos
 01:16
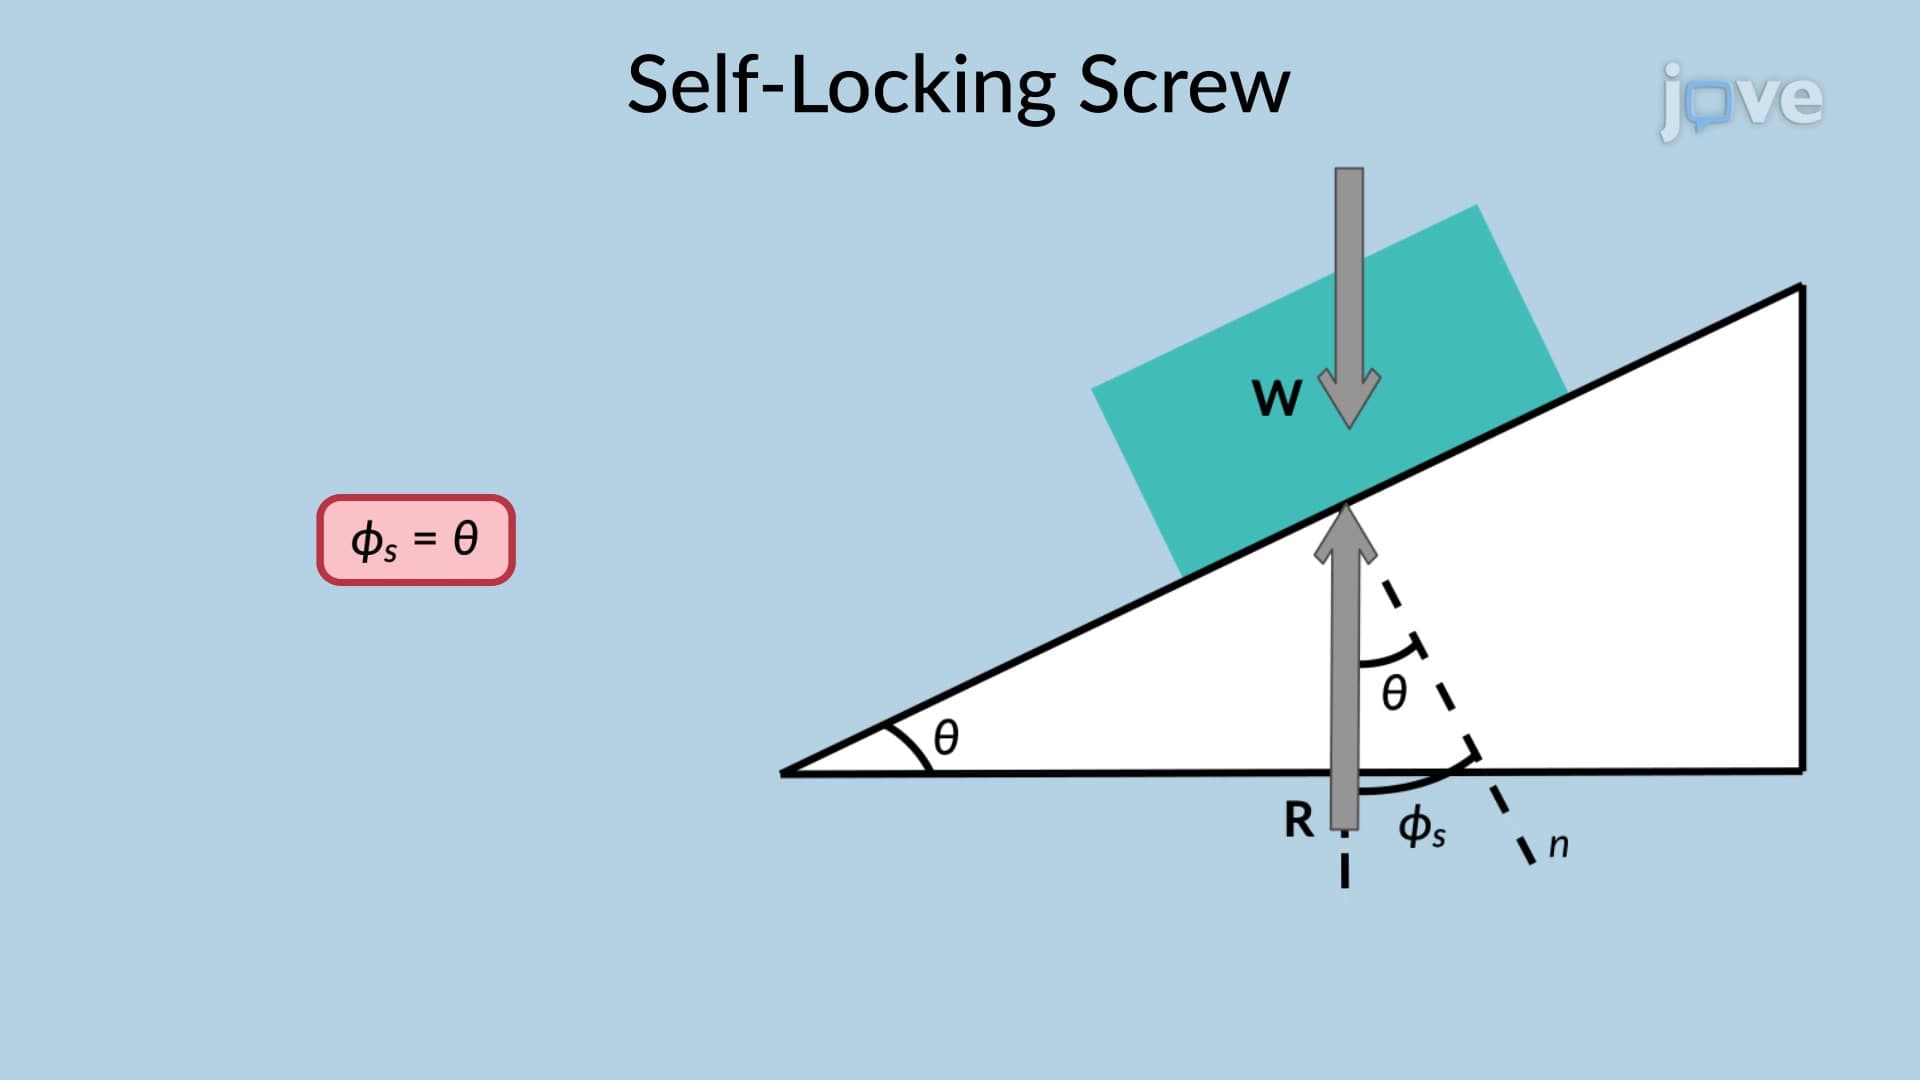
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.
 01:21
Screw: Problem Solving
To evaluate the...
 01:26
Kinematic Equations - I
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...