Related Experiment Video
Updated: Jan 24, 2026

Author Spotlight: Developing a Point-of-Care Hemoglobin Estimation Method for Anemia Management
Published on: January 19, 2024
Research on Low-Cost Attitude Estimation for MINS/Dual-Antenna GNSS Integrated Navigation Method
Hailu Wang1, Ning Liu2, Zhong Su3,4
1University of Beijing Information Science & Technology Beijing Key Laboratory of High Dynamic Navigation Technology, Beijing 100101, China. whl41017@163.com.

Abstract:
A high-precision navigation system is required for an unmanned vehicle, and the high-precision sensor is expensive. A low-cost, high-precision, dual-antenna Global Navigation Satellite System/Micro-electromechanical Systems-Inertial Navigation System (GNSS/MINS) combination method is proposed. The GNSS with dual antennas provides velocity, position, and attitude angle information as the measurement information is combined with the MINS. By increasing the heading angle, pitch angle, velocity, the accuracy of the integrated system is improved. The Extended Kalman Filtering (EKF) integrated algorithm simulation is designed to verify the feasibility and is realized based on the Field Programmable Gate Array and Advanced RISC Machine (ARM+FPGA) system. Static and dynamic tests were performed using the Synchronous Position, Attitude and Navigation (SPAN-CPT) as a reference system. The results show that the velocity, position, and attitude angle accuracy were improved. The yaw angle and pitch angle accuracy were 0.2° Root Mean Square (RMS) and 0.3° RMS, respectively. The method can be used as a navigation system for the unmanned vehicle.
Related Concept Videos
 01:54
Attitudes
 01:15
The Antenna Complex
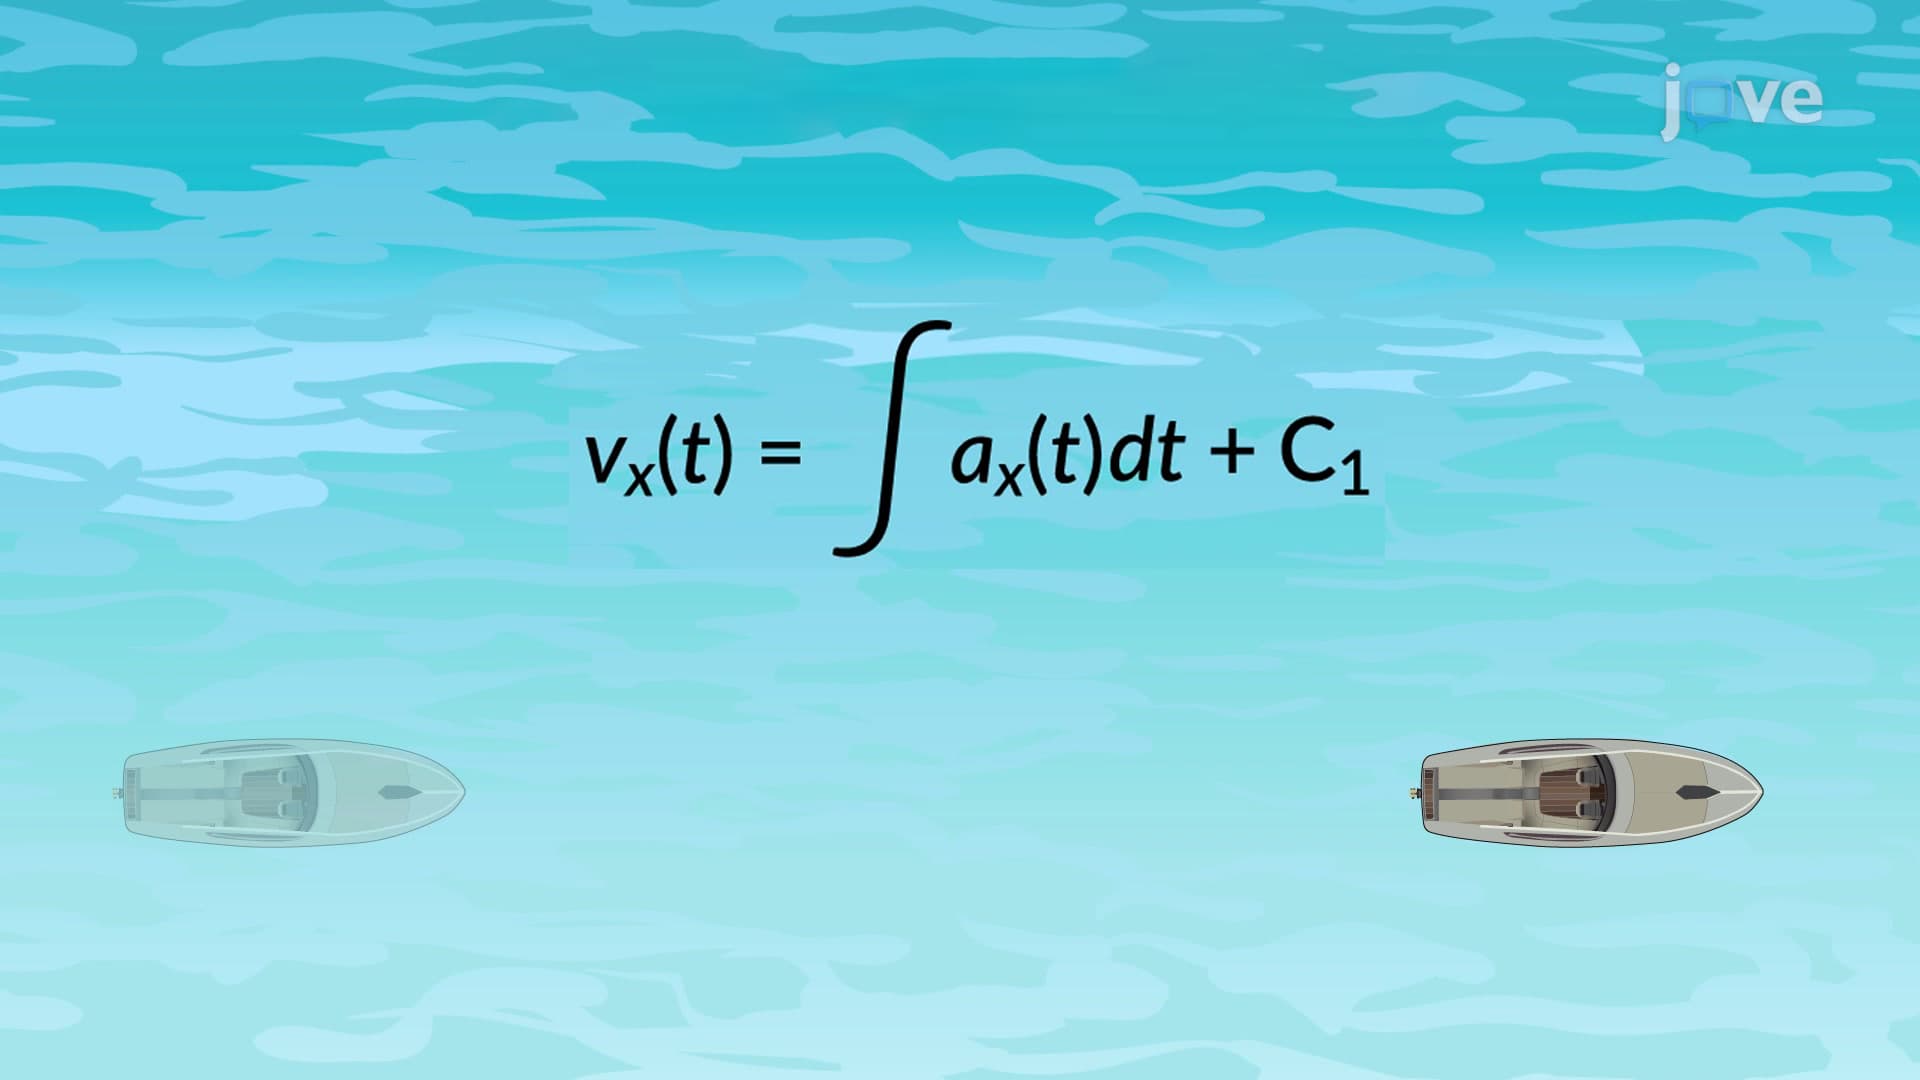 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 01:24
One-Compartment Open Model: Wagner-Nelson and Loo Riegelman Method for ka Estimation
On...
 01:20
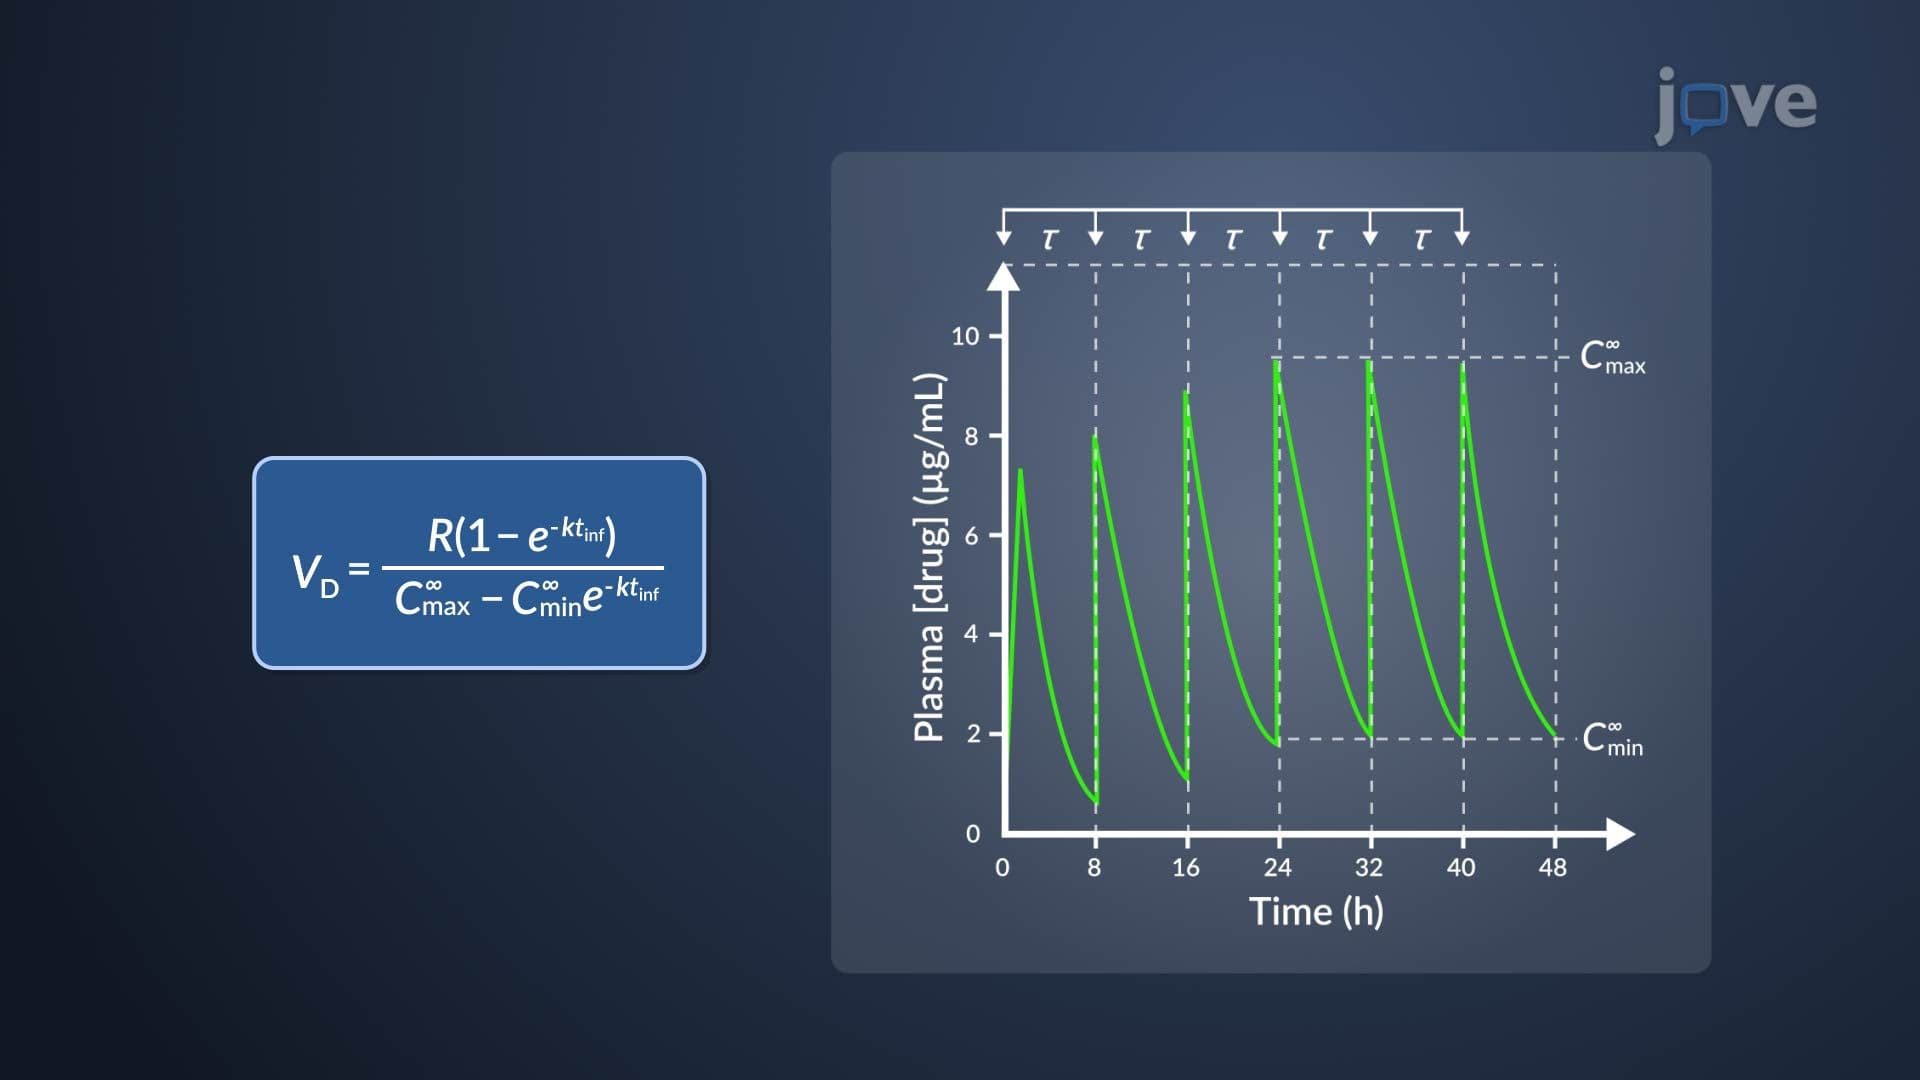
Estimation of k and VD of Aminoglycosides