A general framework for solving inverse dynamics problems in multi-axis motion control
Related Experiment Video
Updated: Jan 24, 2026

Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
1Department of Mechanical and Aerospace Engineering, University of California, Davis, CA 95616, USA.

Abstract:
An inverse dynamics compensation (IDC) scheme for the execution of curvilinear paths by multi-axis motion controllers is proposed. For a path specified by a parametric curve r(ξ), the IDC scheme computes a real-time path correction Δr(ξ) that (theoretically) eliminates path deviations incurred by the inertia and damping of the machine axes. To exploit the linear time-invariant nature of the dynamic equations, the correction term is computed as a function of elapsed time t, and the corresponding curve parameter values ξ are only determined as the final step of the IDC scheme, through a real-time interpolator algorithm. It is shown that, in general, the correction term for P, PI, and PID controllers consists of derivative, natural, and integral terms (the integrand of the latter involving only the path r(ξ), and not its derivatives). The use of lead segments to minimize transient effects associated with the initial conditions is also discussed, and the performance of the method is illustrated by simulation results. The IDC scheme is expressed in terms of a linear differential operator formalism to provide a clear, general, and systematic development, amenable to further adaptations and extensions.
Related Concept Videos
 01:26
Rotational Motion about a Fixed Axis
 01:30
Hyperbolic and Inverse Hyperbolic Functions: Problem Solving
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:30
Dynamics of Circular Motion
Any acceleration must be produced by some force. Therefore, any force or combination of forces can cause centripetal acceleration. A few examples include the tension in the rope on a...
 01:17
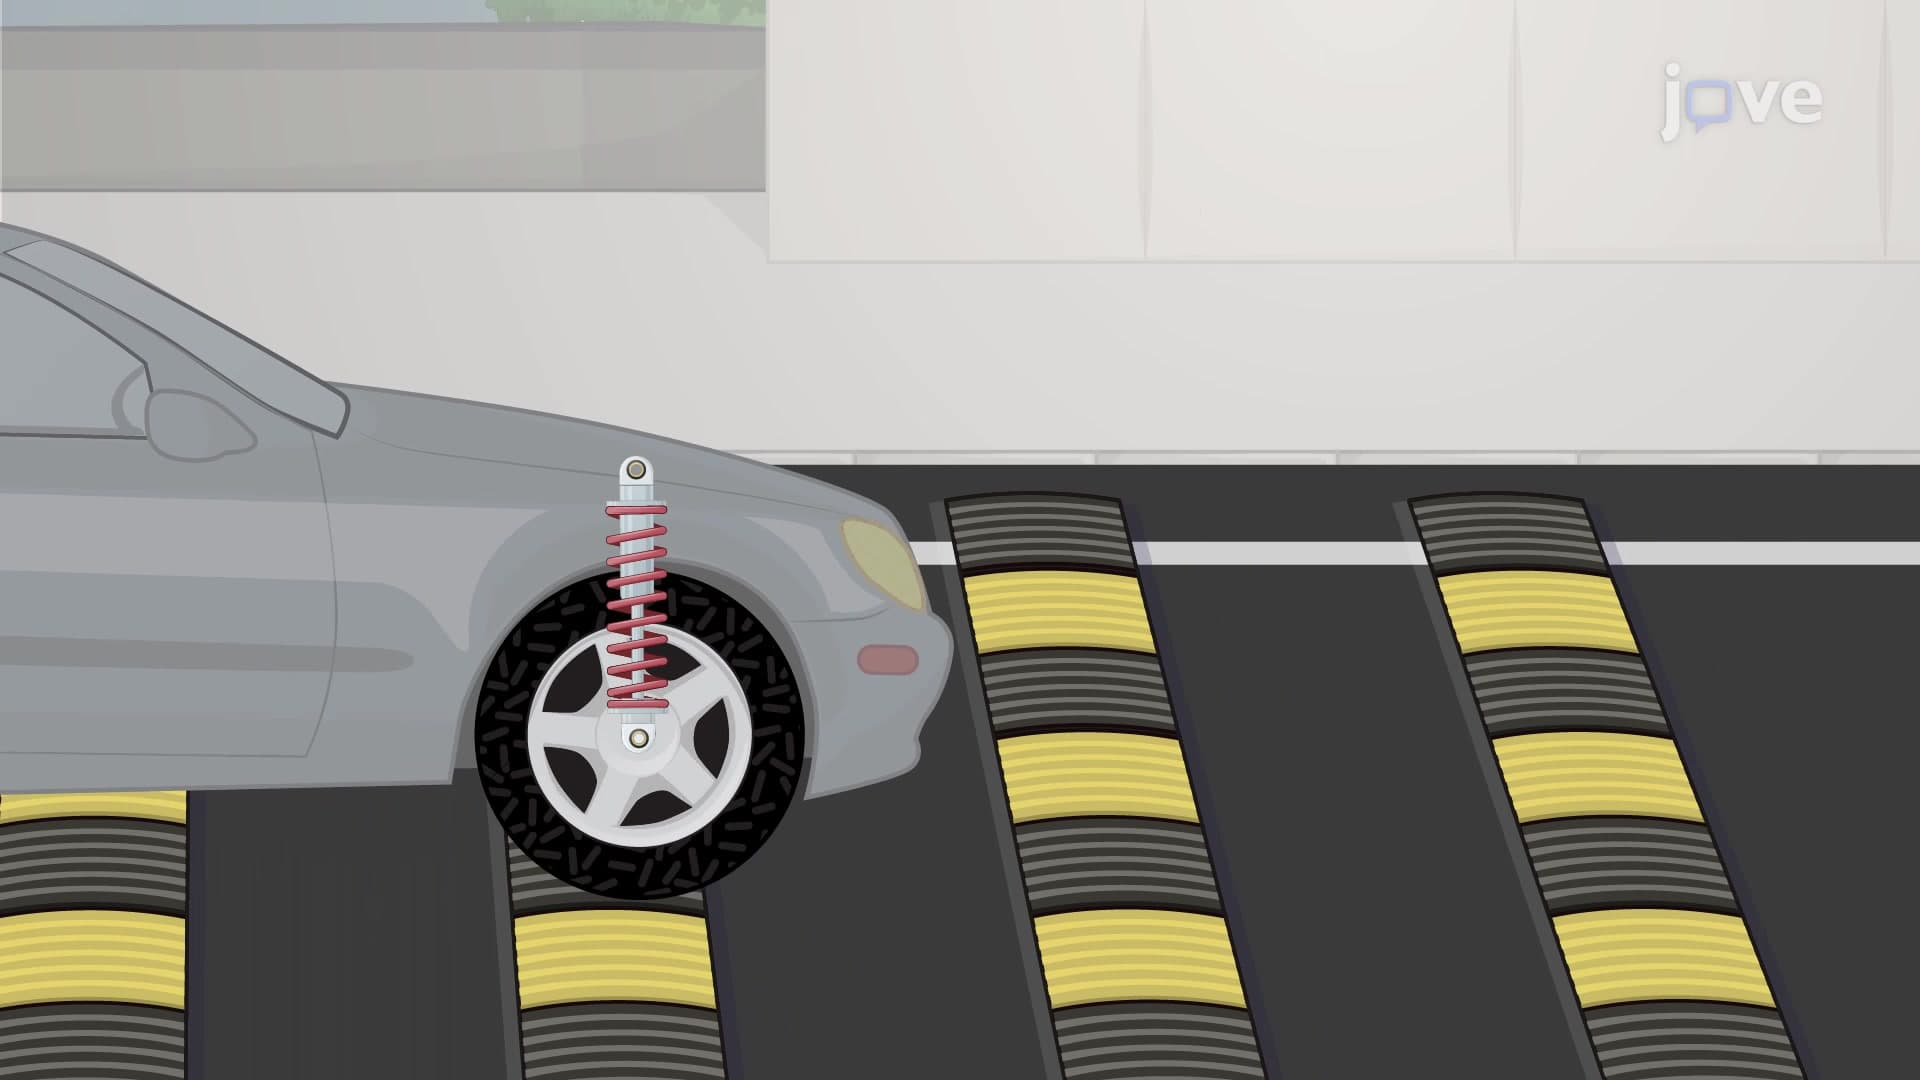
Problem Solving: Energy in Simple Harmonic Motion
Consider the spring in a shock absorber of a car. The spring attached to the wheel executes simple harmonic motion while the car is moving on a bumpy road. The force on the...