2-Degree-of-freedom Robot Path Planning using Cooperative Neural Fields
Related Experiment Video
Updated: Jan 23, 2026
Estimating Vestibular Perceptual Thresholds Using a Six-Degree-Of-Freedom Motion Platform
Published on: August 4, 2022
1Department of Electrical Engineering, University of Notre Dame, Notre Dame, IN 46556 USA.

Abstract:
This paper proposes a neural network solution to path planning by two degree-of-freedom (DOF) robots. The proposed network is a two-dimensional sheet of neurons forming a distributed representation of the robot's workspace. Lateral interconnections between neurons are "cooperative," so that the field exhibits oscillatory behavior. This paper shows how that oscillatory behavior can be used to solve the path-planning problem. The results reported show that the proposed neural network finds the variational solution of Bellman's dynamic programming equation.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:02
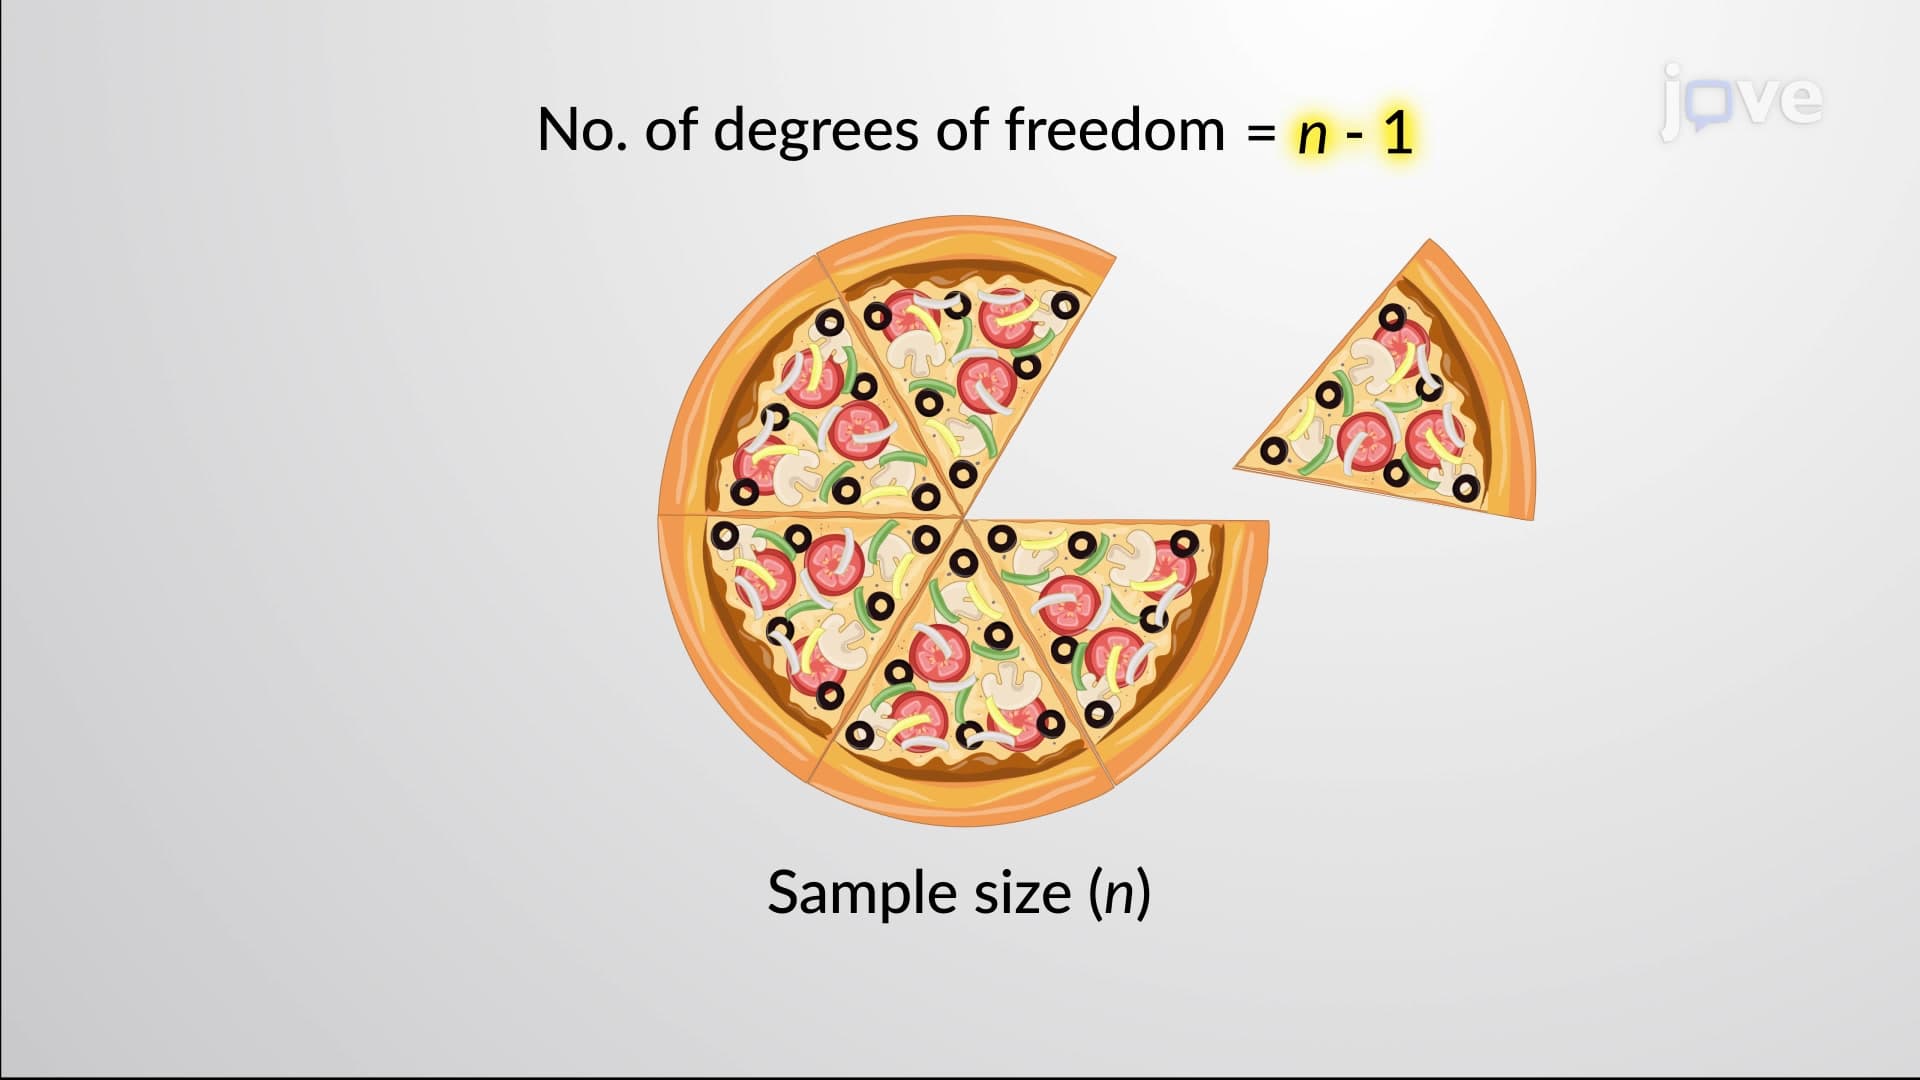
Degrees of Freedom
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily assigned.
 01:02
Degrees of Freedom
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily...
 01:58
Cooperative Allosteric Transitions
01:58Cooperative Allosteric Transitions
 02:13
Cooperative Binding of Transcription Regulators