Related Experiment Video
Updated: Jan 23, 2026
Movement Retraining using Real-time Feedback of Performance
Published on: January 17, 2013
Transferability of real-time safety performance functions for signalized intersections
Mohamed Essa1, Tarek Sayed1, Passant Reyad1
1Department of Civil Engineering, University of British Columbia, 6250 Applied Science Lane, Vancouver, BC, V6T 1Z4, Canada.

Abstract:
Optimizing traffic signals in real-time for safety performance can be executable in the era of Connected Vehicles (CVs) when real-time information on vehicle positions and trajectories is available. To achieve this, real-time safety models are needed to understand how changes in signal controllers affect safety in real-time. Recently, several real-time safety models were developed for signalized intersections that relate various dynamic traffic parameters to the number of rear-end traffic conflicts at the signal cycle level. The traffic parameters included: traffic volume, maximum queue length, shock wave speed and area, and platoon ratio. For wider application of these models to other jurisdictions, the transferability of these models needs to be examined. Therefore, this paper aims to investigate the transferability of several signalized intersections real-time safety models to new jurisdictions. Two corridors of signalized intersections in California and Atlanta were used in the analysis as destination jurisdictions. Detailed vehicle trajectories for these corridors were obtained from the Next Generation Simulation (NGSIM) data. Various transferability analysis approaches were applied. The transferability of the real-time safety models was evaluated with and without a local calibration for the model parameters at the new jurisdictions. Several goodness-of-fit measures were examined to assess the ability of the developed models to predict traffic conflicts. Overall, the results showed that the real-time safety models are transferable, which confirms the validity of using them for real-time safety evaluation of signalized intersections.

Related Concept Videos
 01:23
Transfer Function to State Space
In an RLC...
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
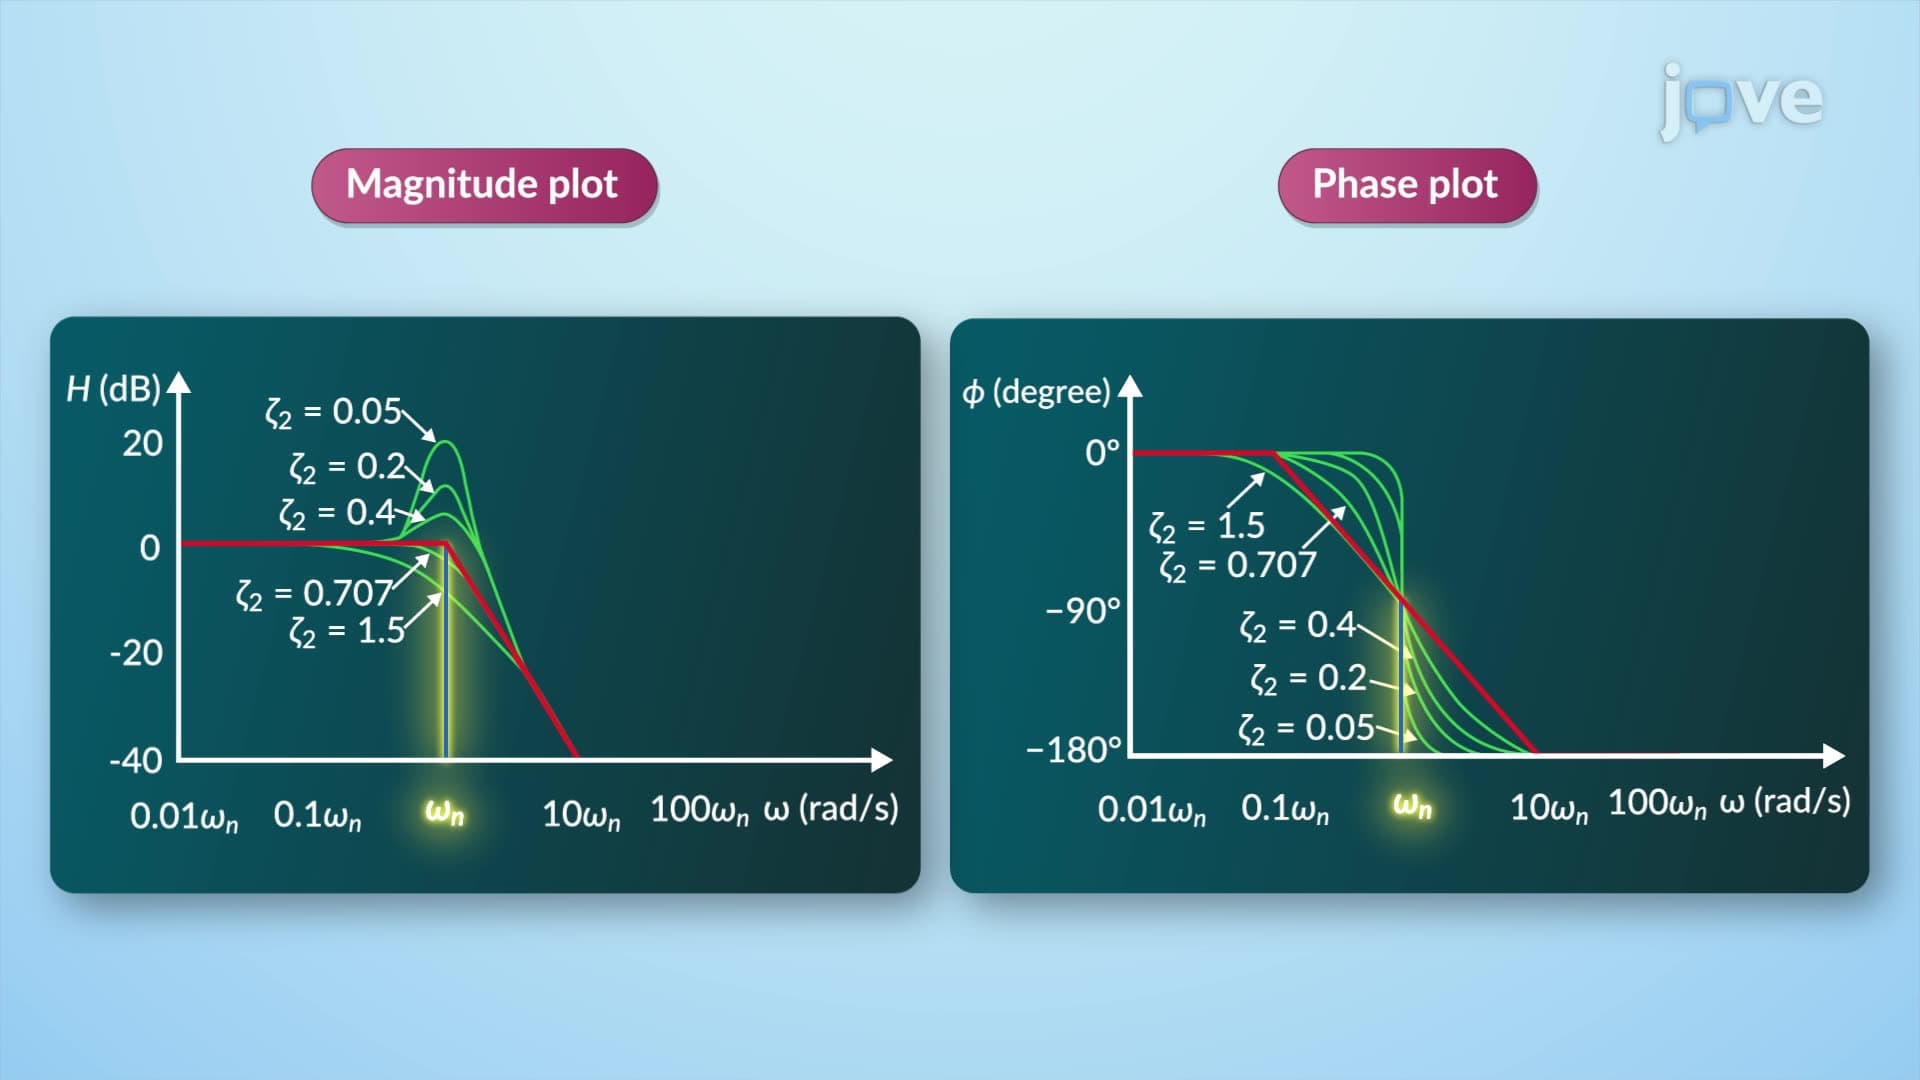
Transfer function and Bode Plots-II
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:16
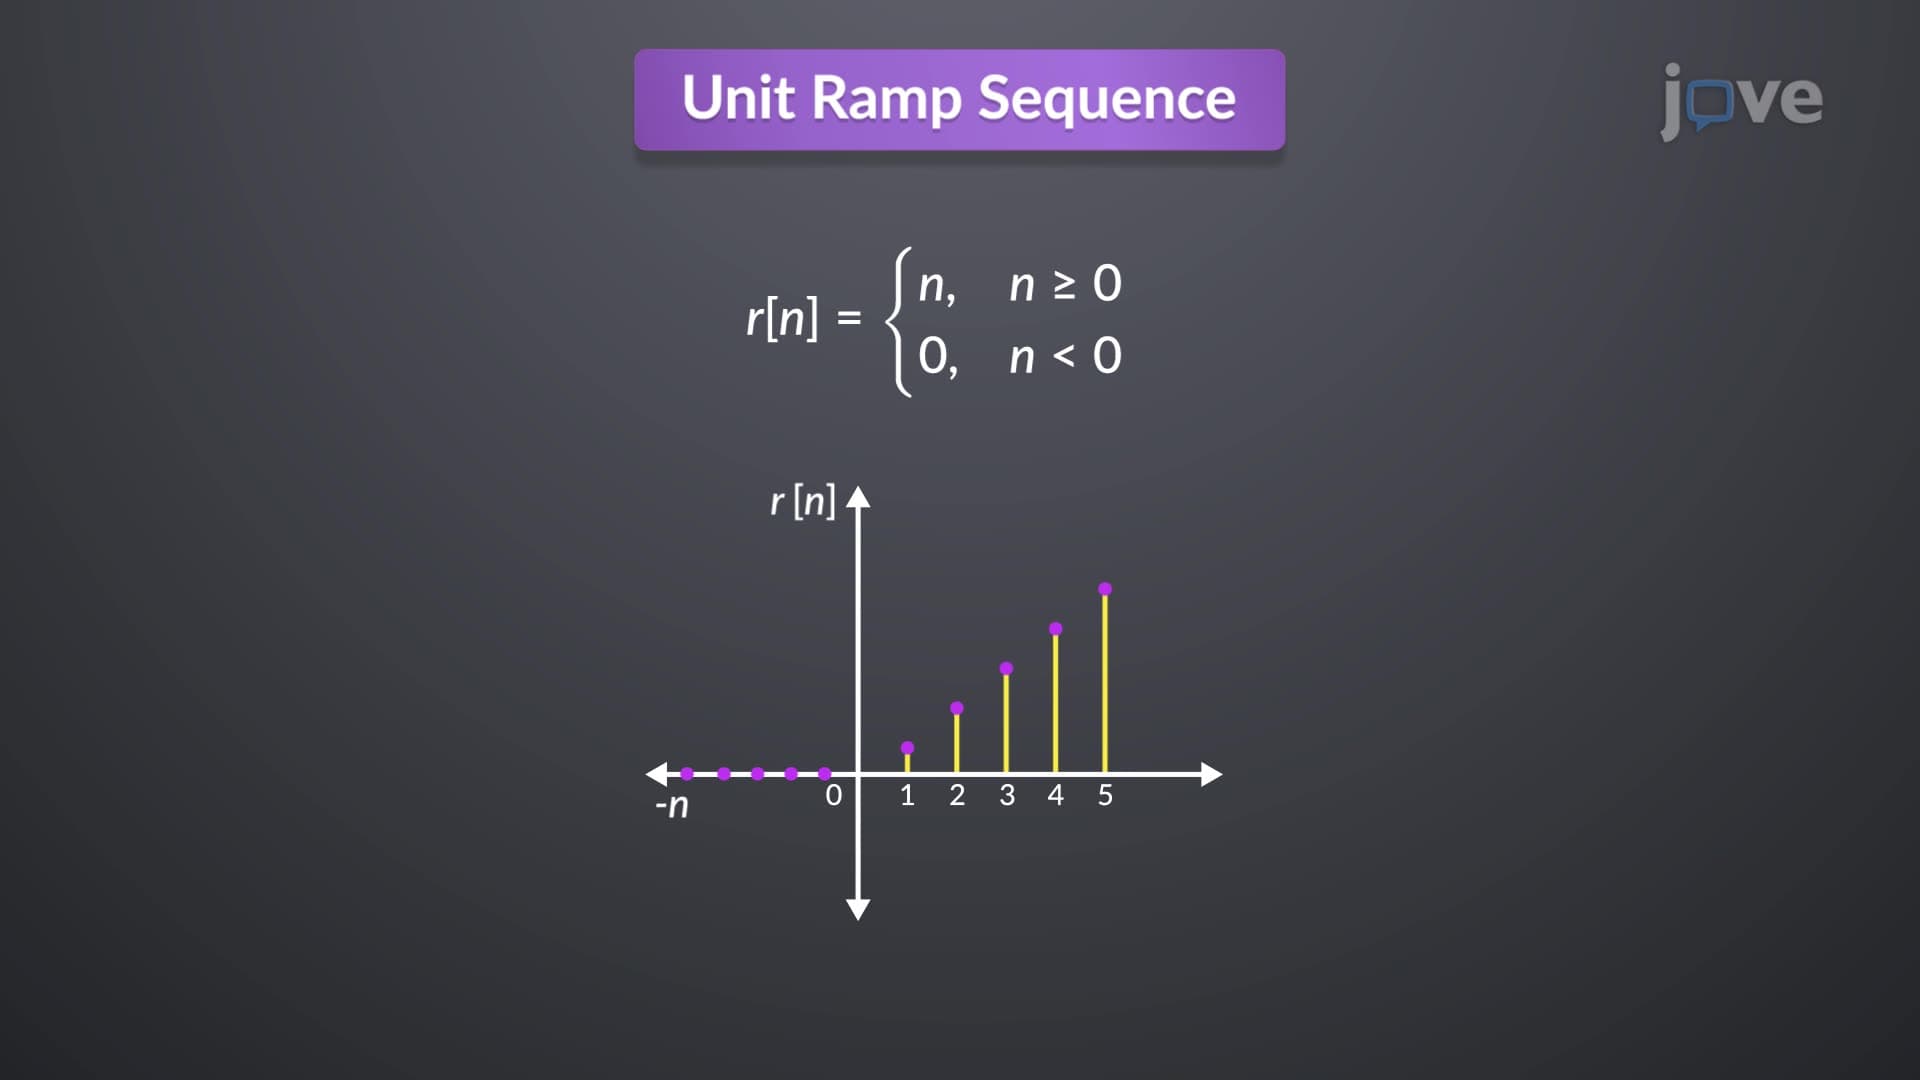
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:11
Sampling Continuous Time Signal
In the...