Related Experiment Video
Updated: Jan 23, 2026

Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Mobile Robot Path Planning Using Ant Colony Algorithm and Improved Potential Field Method
1School of Mechanical and Electronic Engineering, Wuhan University of Technology, Wuhan 430070, Hubei, China.

Abstract:
For the problem of mobile robot's path planning under the known environment, a path planning method of mixed artificial potential field (APF) and ant colony optimization (ACO) based on grid map is proposed. First, based on the grid model, APF is improved in three ways: the attraction field, the direction of resultant force, and jumping out the infinite loop. Then, the hybrid strategy combined global updating with local updating is developed to design updating method of the ACO pheromone. The process of optimization of ACO is divided into two phases. In the prophase, the direction of the resultant force obtained by the improved APF is used as the inspired factors, which leads ant colony to move in a directional manner. In the anaphase, the inspired factors are canceled, and ant colony transition is completely based on pheromone updating, which can overcome the inertia of the ant colony and force them to explore a new and better path. Finally, some simulation experiments and mobile robot environment experiments are done. The experiment results verify that the method has stronger stability and environmental adaptability.
Related Concept Videos
 01:22
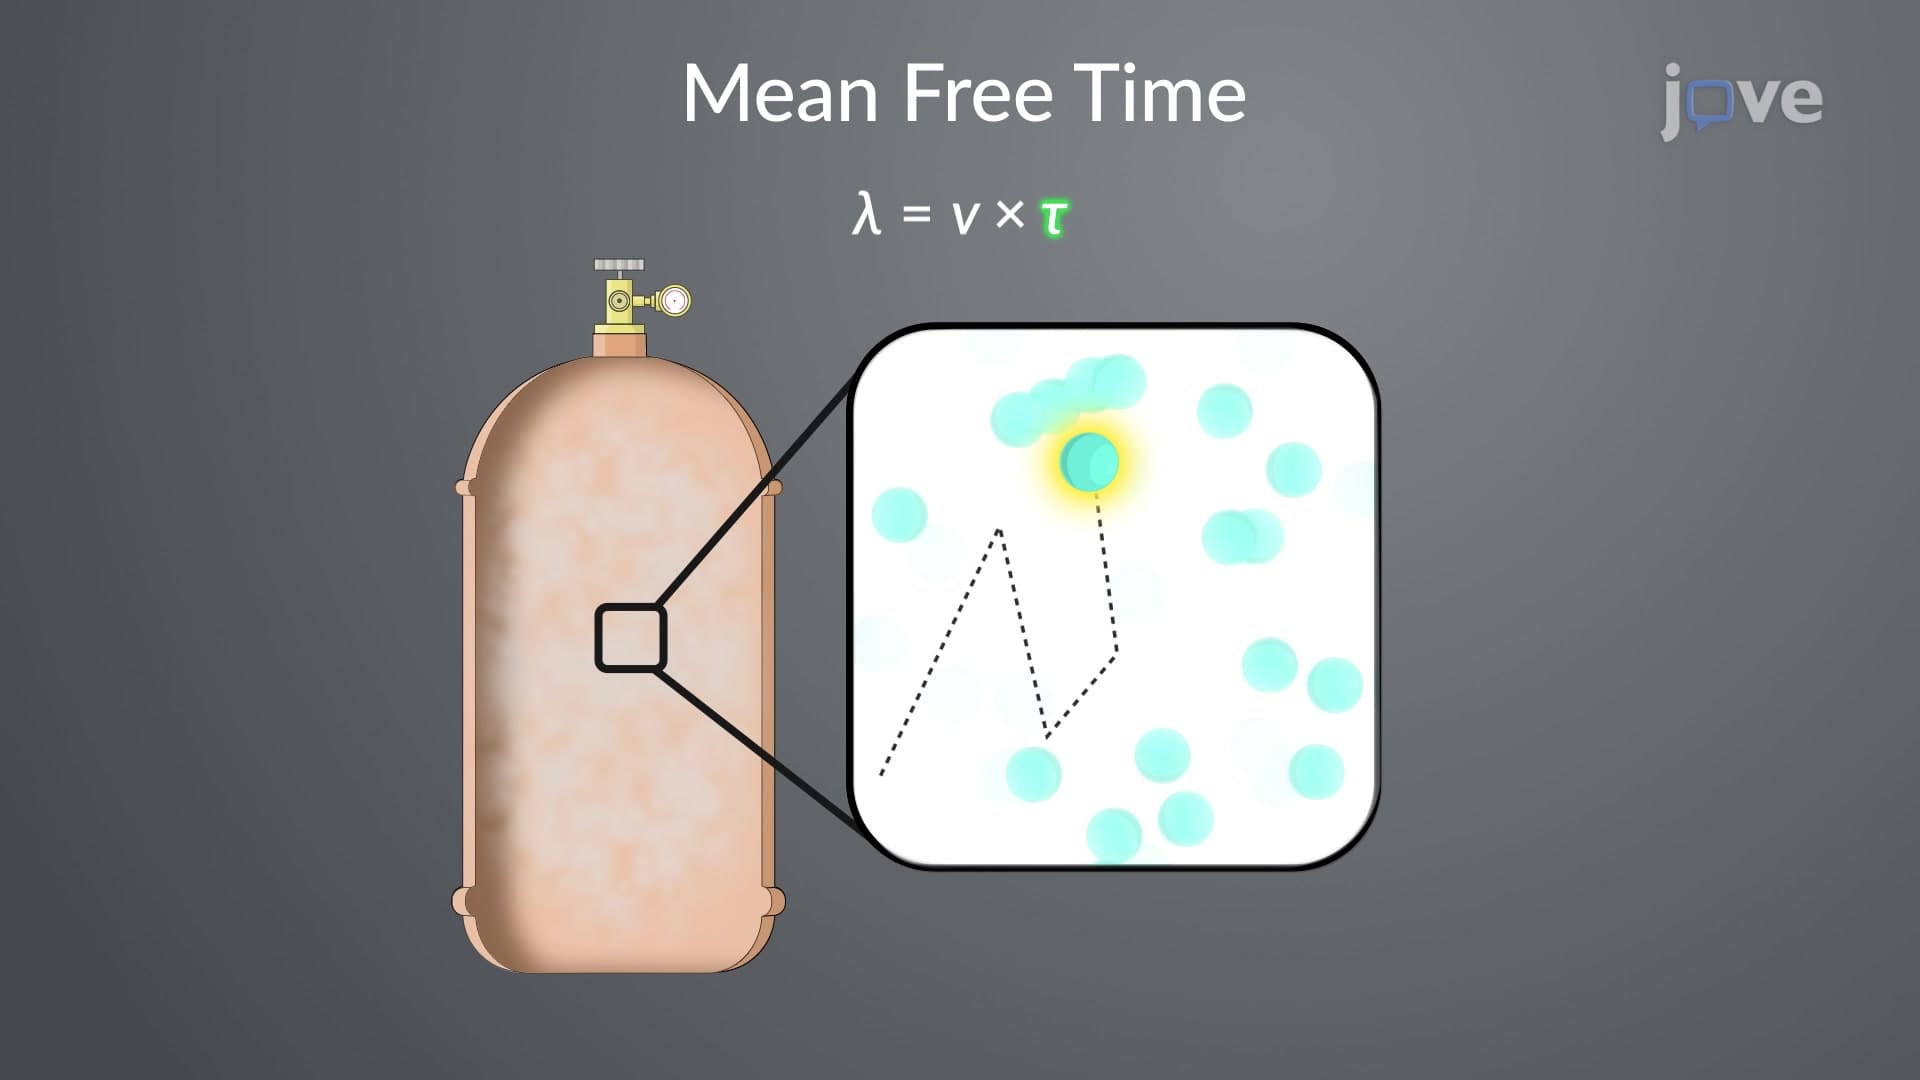
Mean free path and Mean free time
 01:21
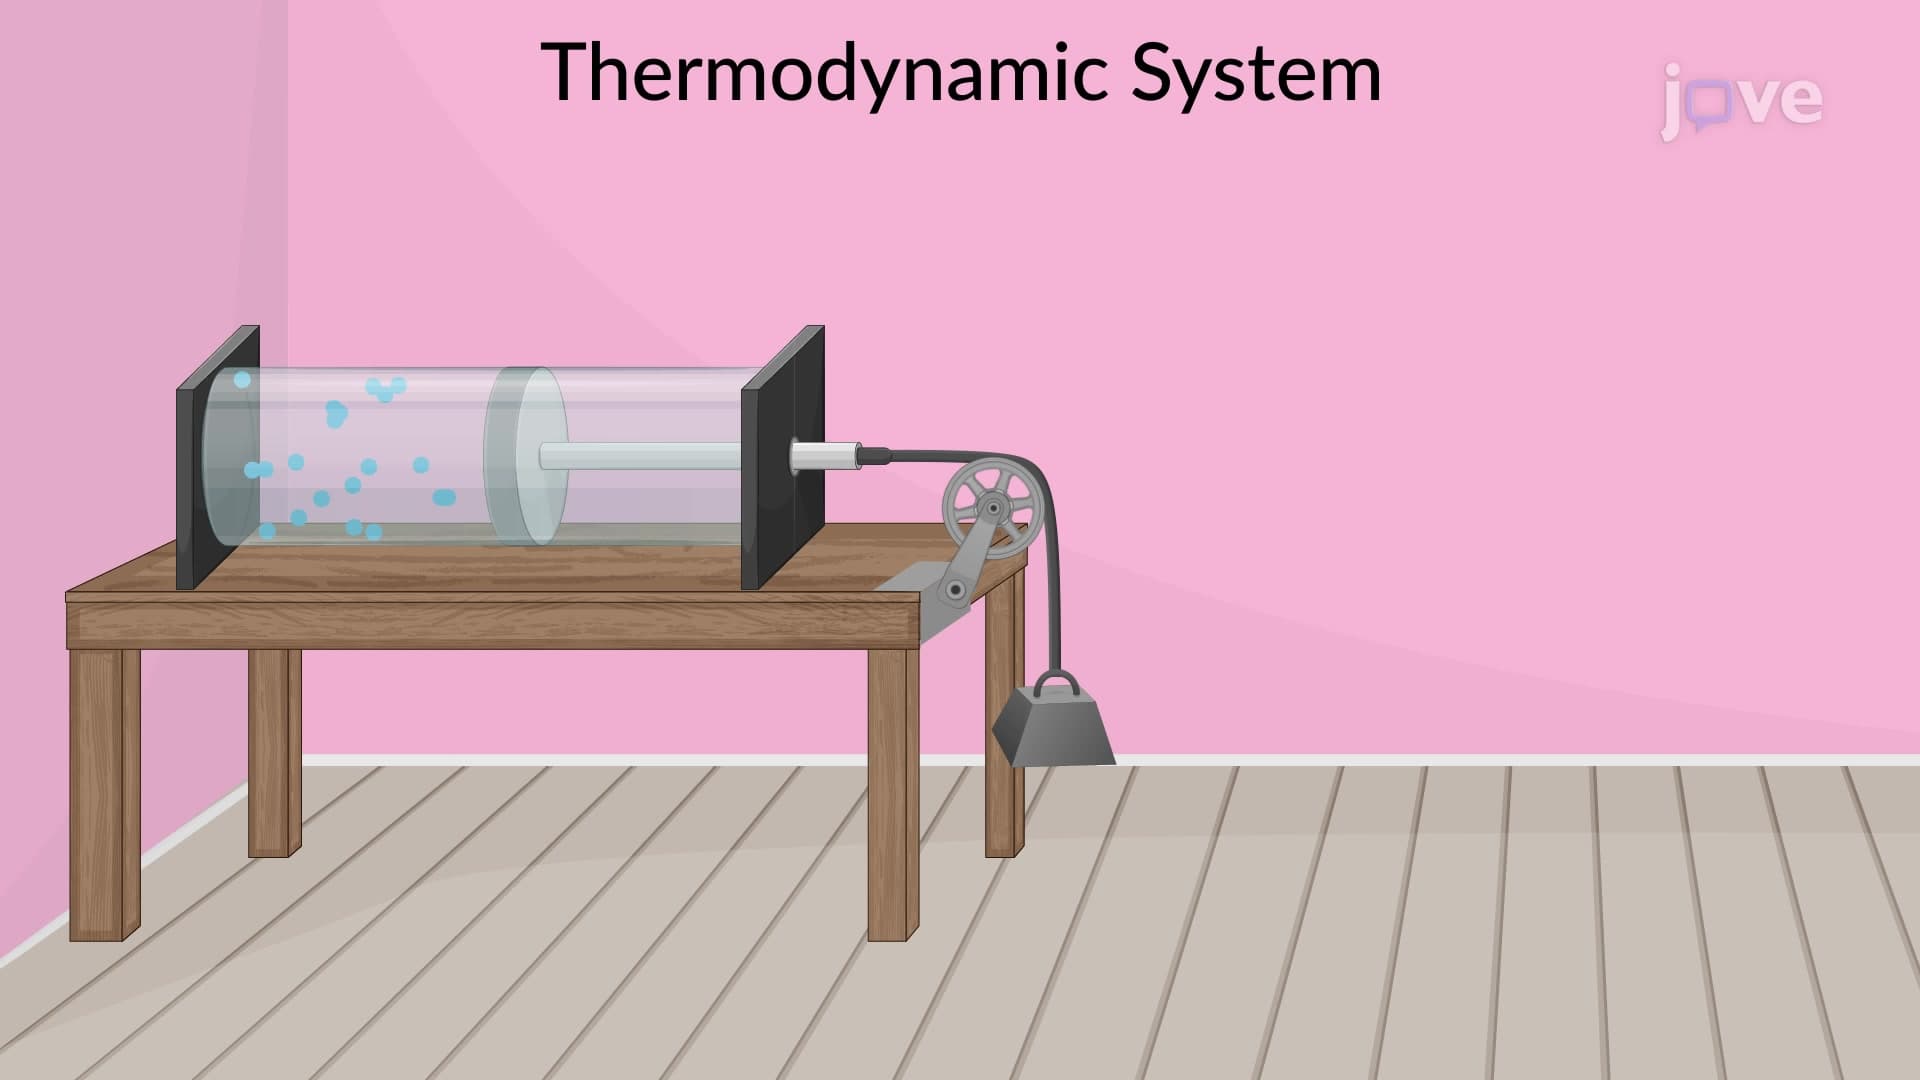
Path Between Thermodynamics States
 01:13
Finding Electric Potential From Electric Field
 01:12
Determining Electric Field From Electric Potential
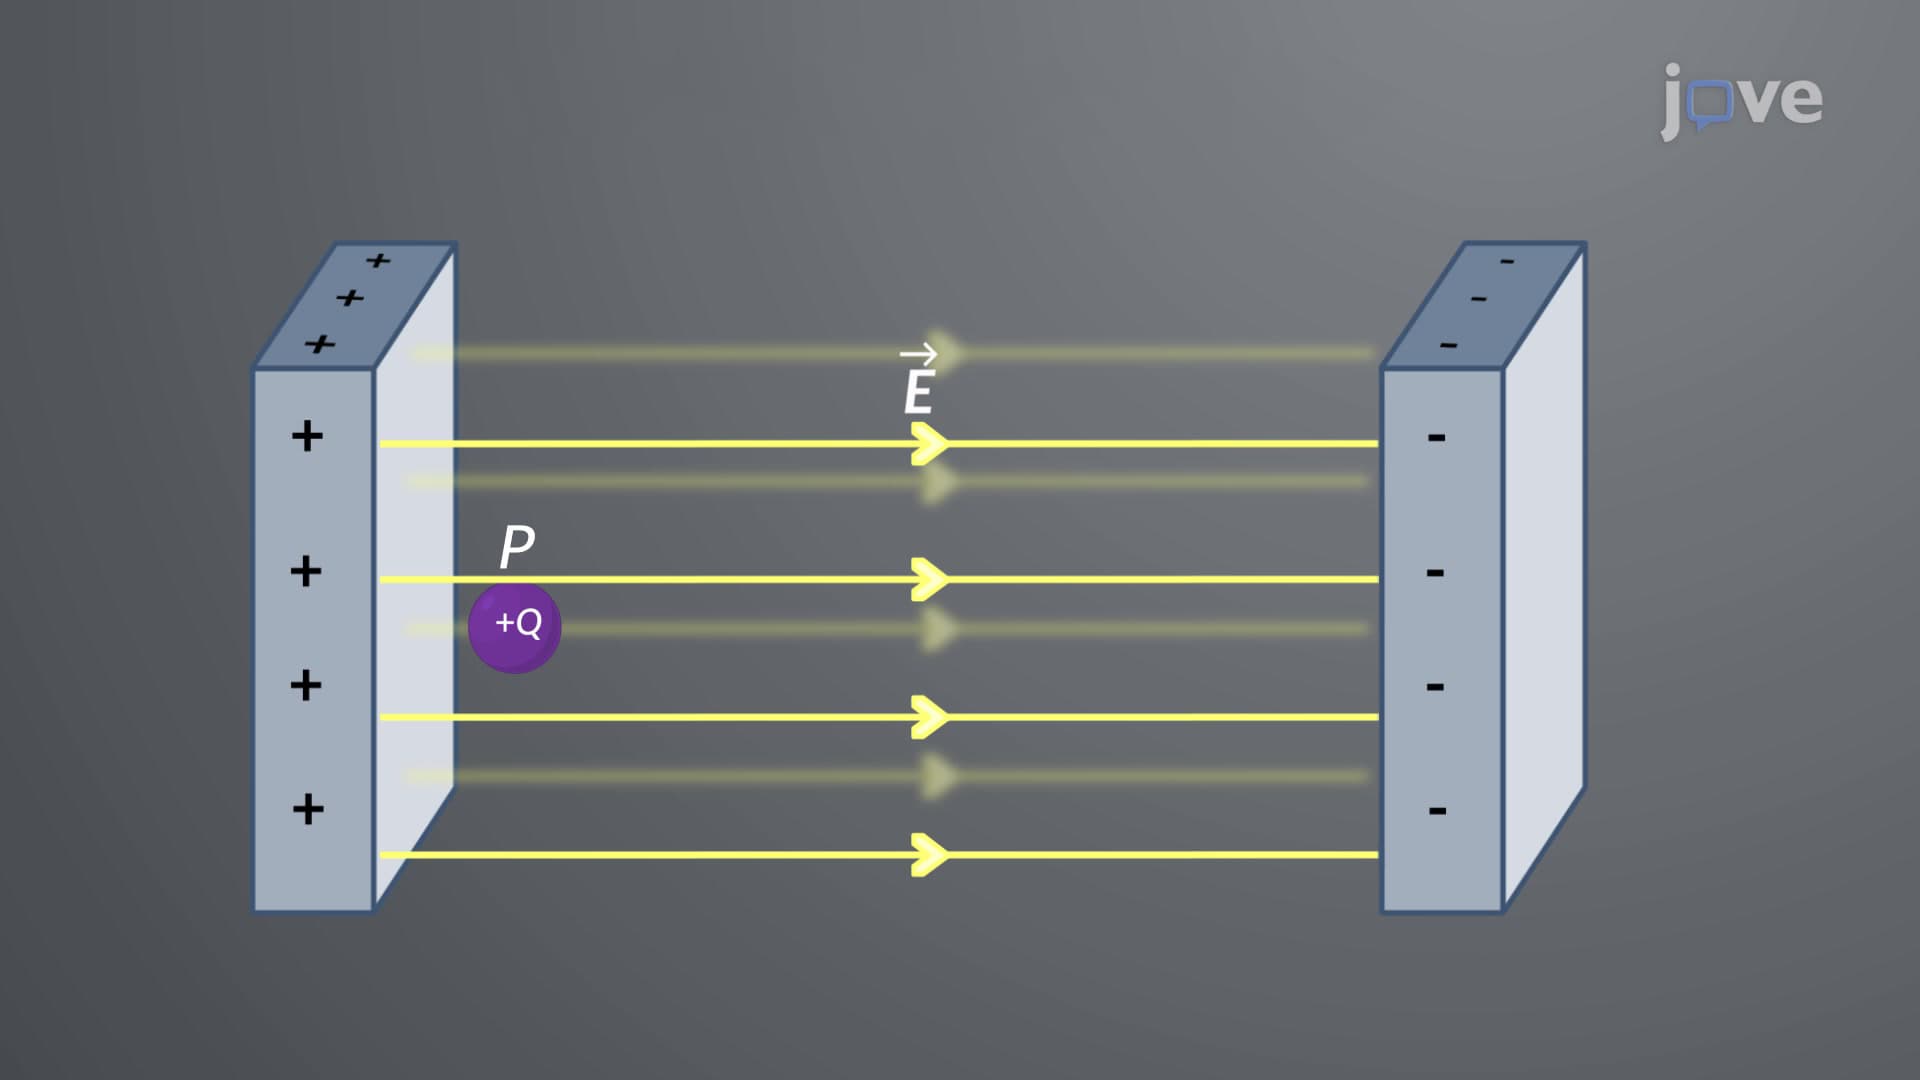
In general, regardless of whether the electric field is uniform, it points in the direction of decreasing potential because the force on a positive...
 01:09
Electric Potential Energy in a Uniform Electric Field
 01:10
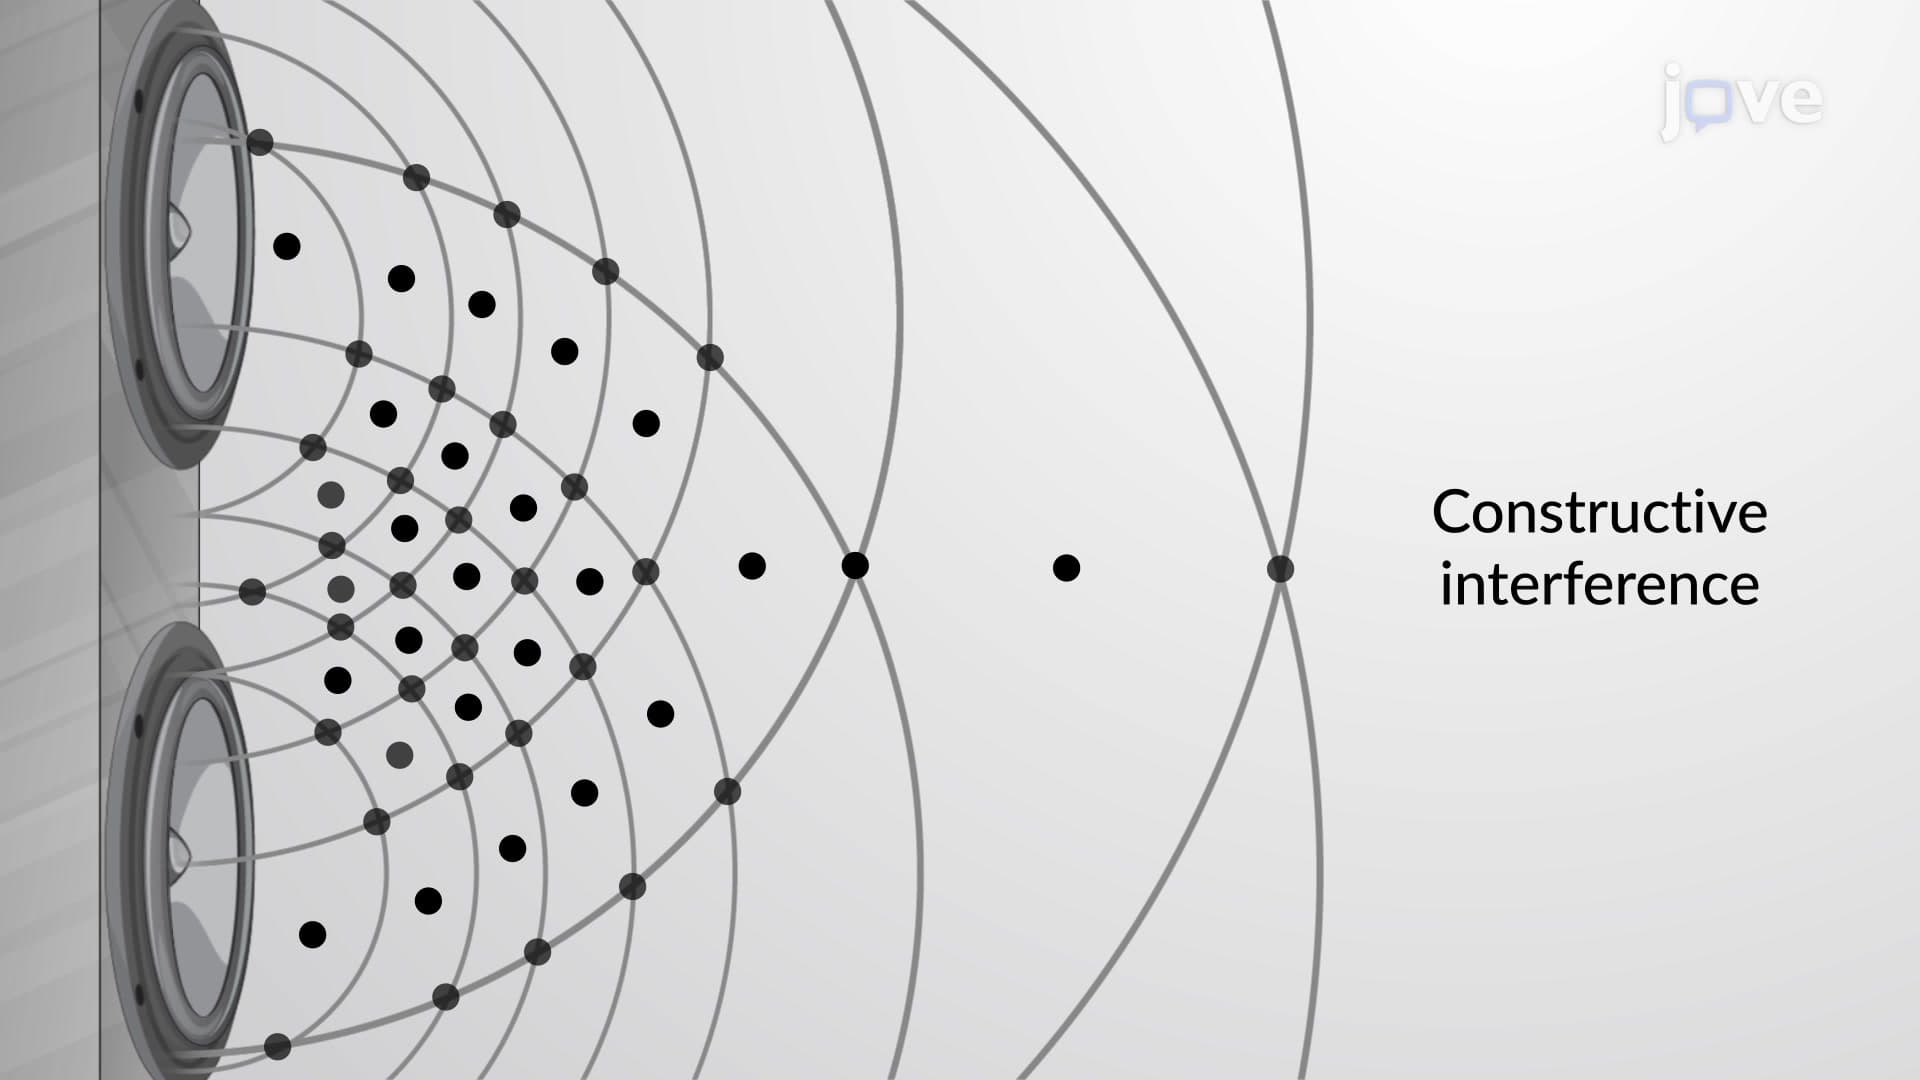
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...