Related Experiment Video
Updated: Jan 22, 2026


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Type-2 Fuzzy Hybrid Controller Network for Robotic Systems

Abstract:
Dynamic control, including robotic control, faces both the theoretical challenge of obtaining accurate system models and the practical difficulty of defining uncertain system bounds. To facilitate such challenges, this paper proposes a control system consisting of a novel type of fuzzy neural network and a robust compensator controller. The new fuzzy neural network is implemented by integrating a number of key components embedded in a Type-2 fuzzy cerebellar model articulation controller (CMAC) and a brain emotional learning controller (BELC) network, thereby mimicking an ideal sliding mode controller. The system inputs are fed into the neural network through a Type-2 fuzzy inference system (T2FIS), with the results subsequently piped into sensory and emotional channels which jointly produce the final outputs of the network. That is, the proposed network estimates the nonlinear equations representing the ideal sliding mode controllers using a powerful compensator controller with the support of T2FIS and BELC, guaranteeing robust tracking of the dynamics of the controlled systems. The adaptive dynamic tuning laws of the network are developed by exploiting the popular brain emotional learning rule and the Lyapunov function. The proposed system was applied to a robot manipulator and a mobile robot, demonstrating its efficacy and potential; and a comparative study with alternatives indicates a significant improvement by the proposed system in performing the intelligent dynamic control.


Related Concept Videos
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
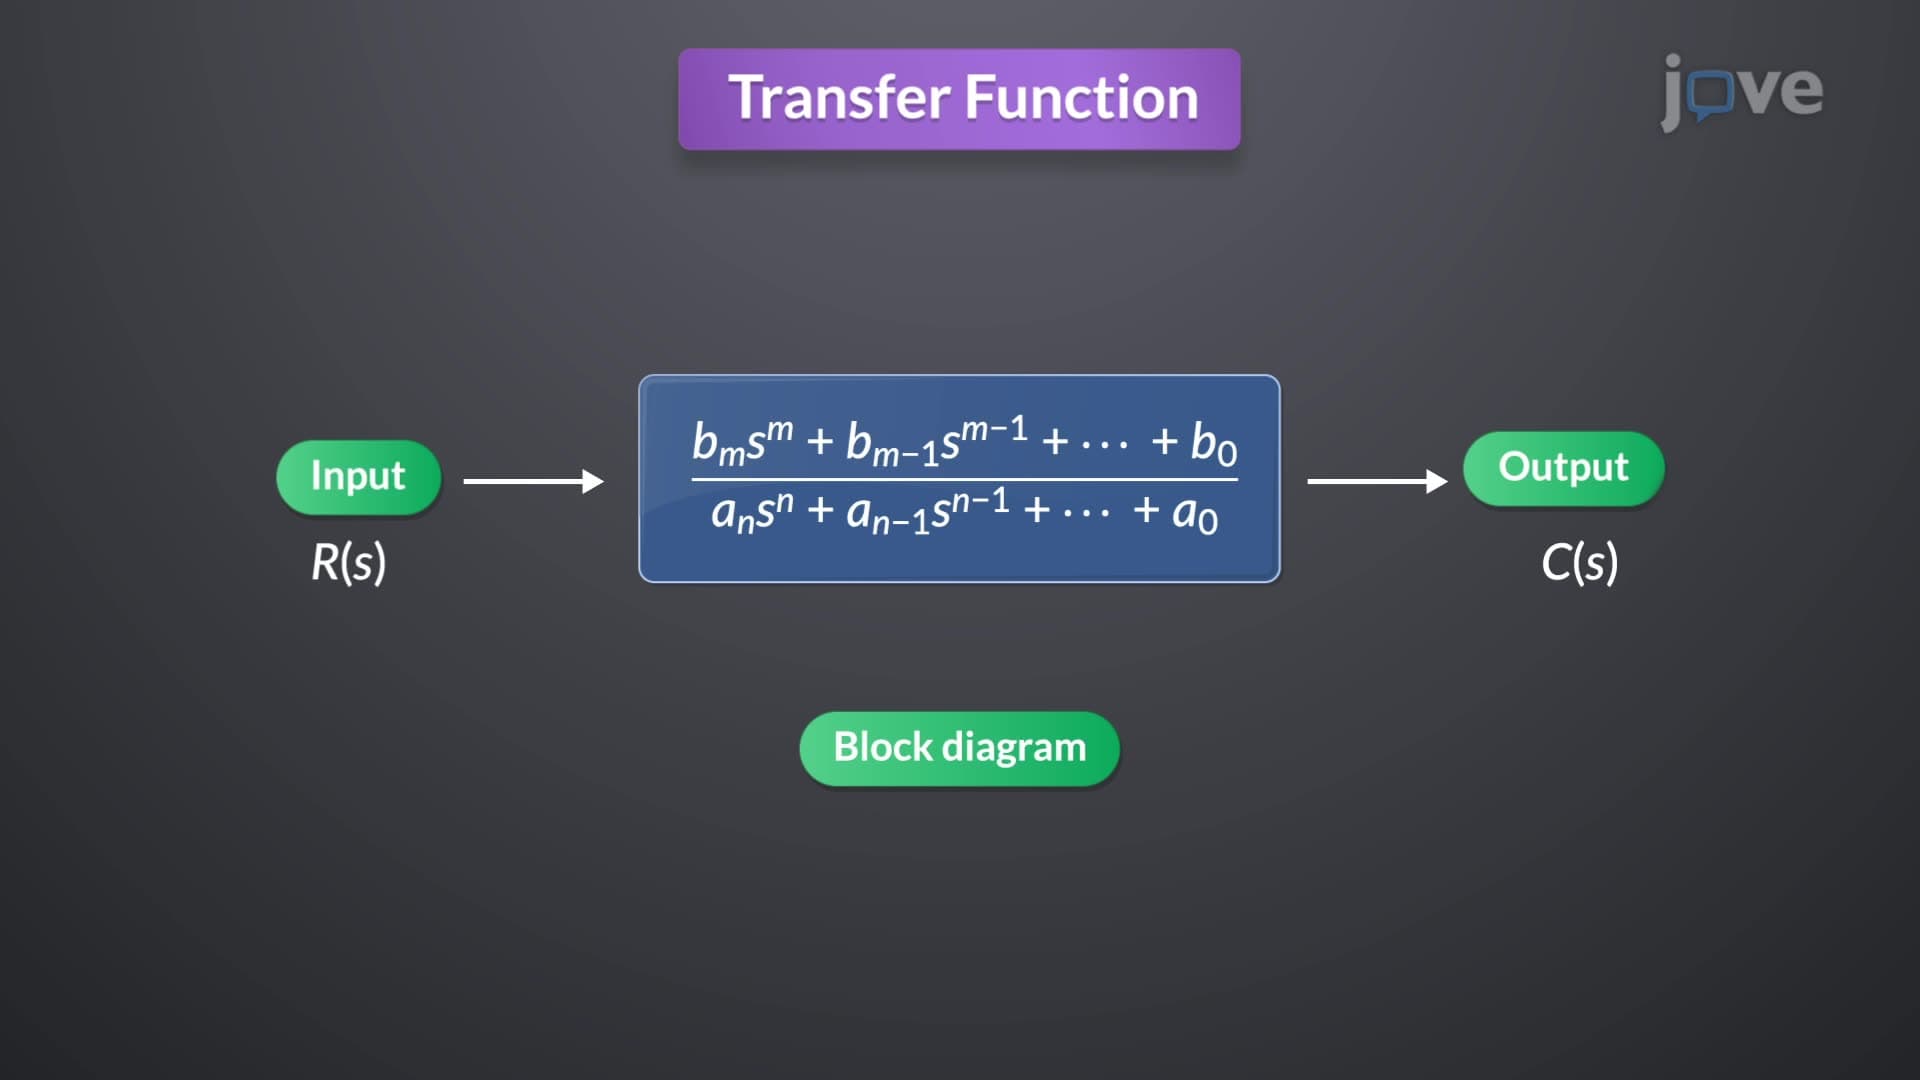
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 02:18
Network Covalent Solids
To break or to melt a covalent network solid, covalent bonds must be broken. Because covalent bonds are relatively strong, covalent network solids are typically...