Related Experiment Video
Updated: Jan 22, 2026
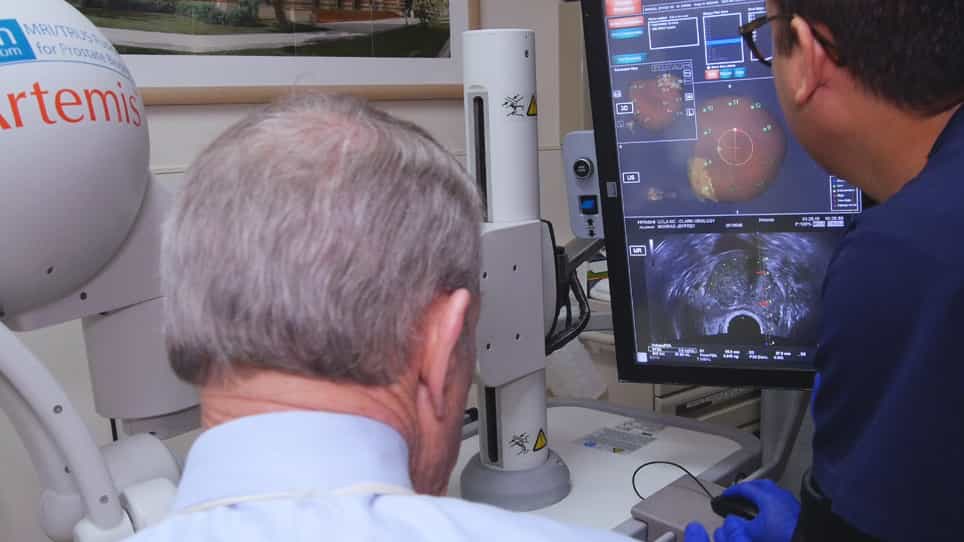

Use of MRI-ultrasound Fusion to Achieve Targeted Prostate Biopsy
Published on: April 9, 2019
Radiomics and machine learning of multisequence multiparametric prostate MRI: Towards improved non-invasive prostate
Jussi Toivonen1,2, Ileana Montoya Perez1,2, Parisa Movahedi1,2
1Dept. of Diagnostic Radiology, University of Turku, Turku, Finland.

Purpose:
To develop and validate a classifier system for prediction of prostate cancer (PCa) Gleason score (GS) using radiomics and texture features of T2-weighted imaging (T2w), diffusion weighted imaging (DWI) acquired using high b values, and T2-mapping (T2).
Methods:
T2w, DWI (12 b values, 0-2000 s/mm2), and T2 data sets of 62 patients with histologically confirmed PCa were acquired at 3T using surface array coils. The DWI data sets were post-processed using monoexponential and kurtosis models, while T2w was standardized to a common scale. Local statistics and 8 different radiomics/texture descriptors were utilized at different configurations to extract a total of 7105 unique per-tumor features. Regularized logistic regression with implicit feature selection and leave pair out cross validation was used to discriminate tumors with 3+3 vs >3+3 GS.
Results:
In total, 100 PCa lesions were analysed, of those 20 and 80 had GS of 3+3 and >3+3, respectively. The best model performance was obtained by selecting the top 1% features of T2w, ADCm and K with ROC AUC of 0.88 (95% CI of 0.82-0.95). Features from T2 mapping provided little added value. The most useful texture features were based on the gray-level co-occurrence matrix, Gabor transform, and Zernike moments.
Conclusion:
Texture feature analysis of DWI, post-processed using monoexponential and kurtosis models, and T2w demonstrated good classification performance for GS of PCa. In multisequence setting, the optimal radiomics based texture extraction methods and parameters differed between different image types.
More Related Videos
Related Concept Videos
 01:19
Machines
A free-body diagram of the...
 01:30
Machines: Problem Solving II
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:30
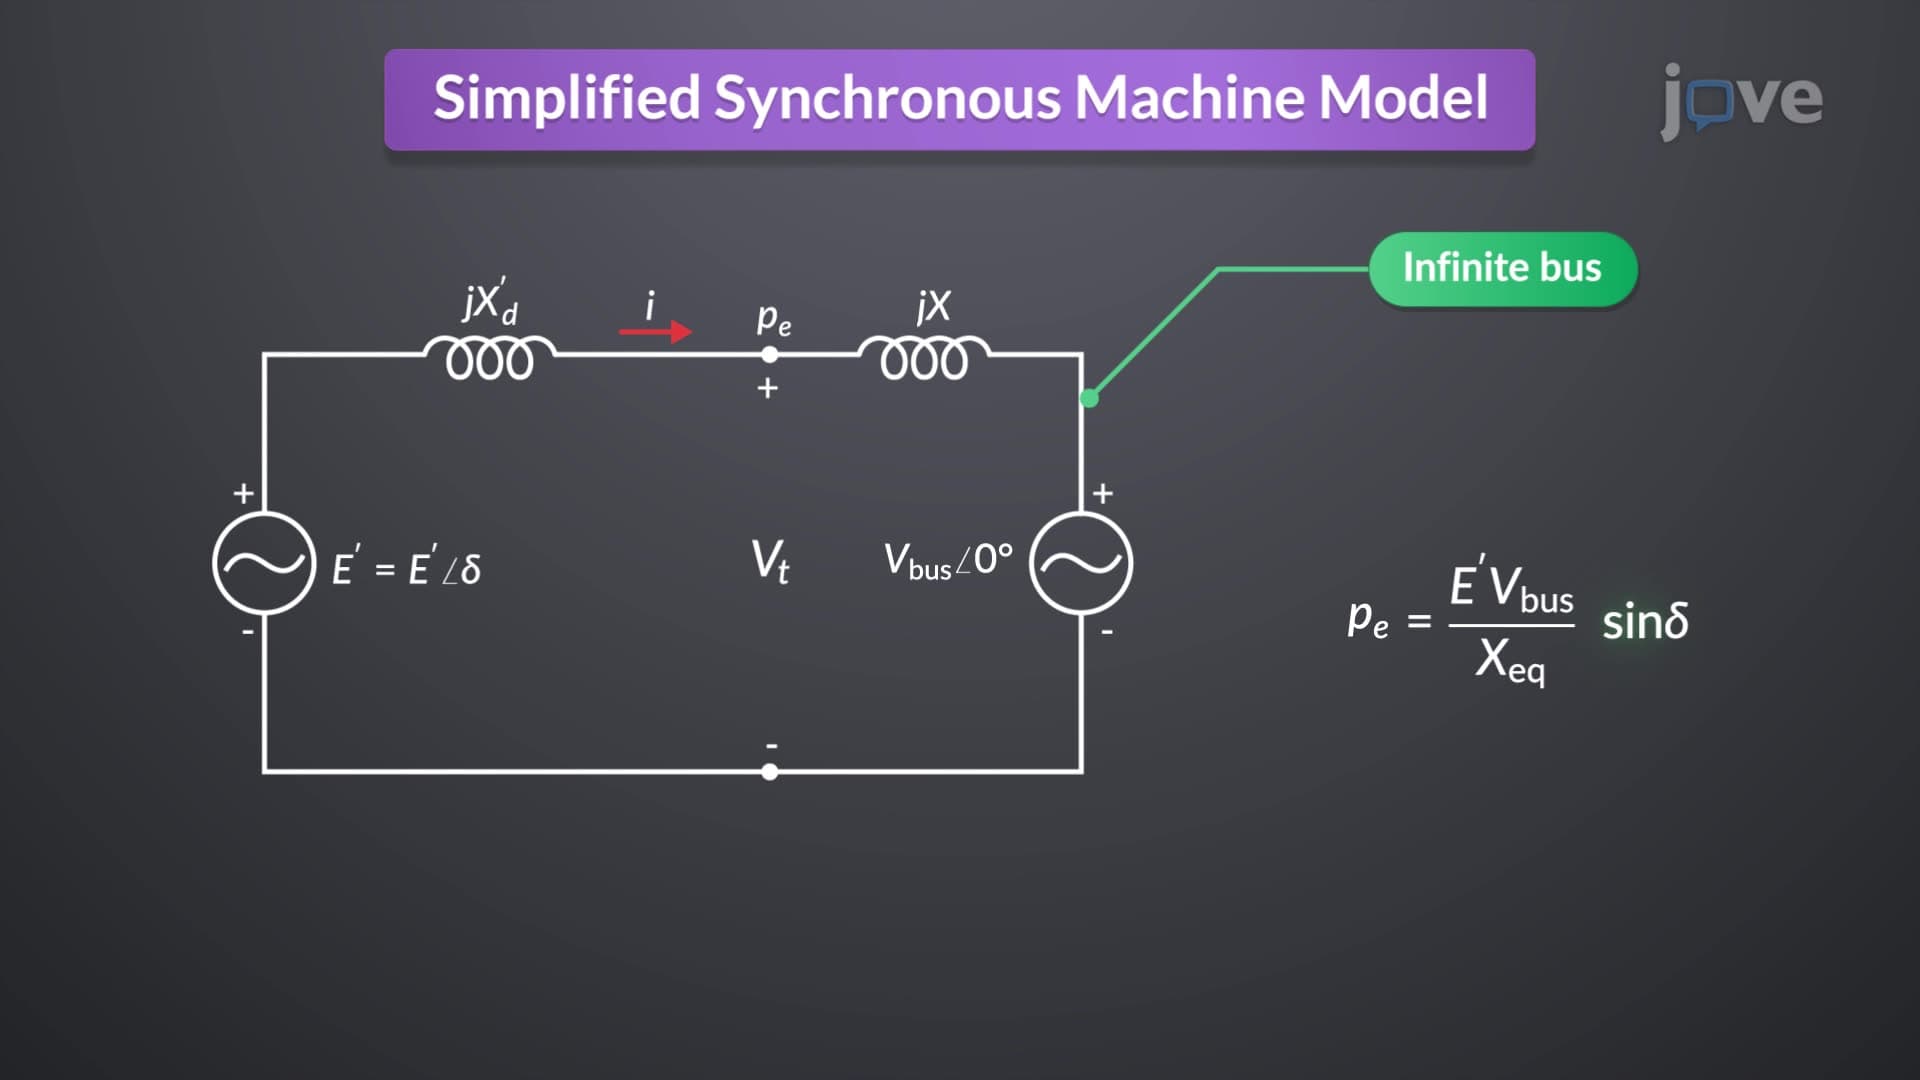
Simplified Synchronous Machine Model
In this model, each generator is connected to a...