Related Experiment Video
Updated: Jan 22, 2026
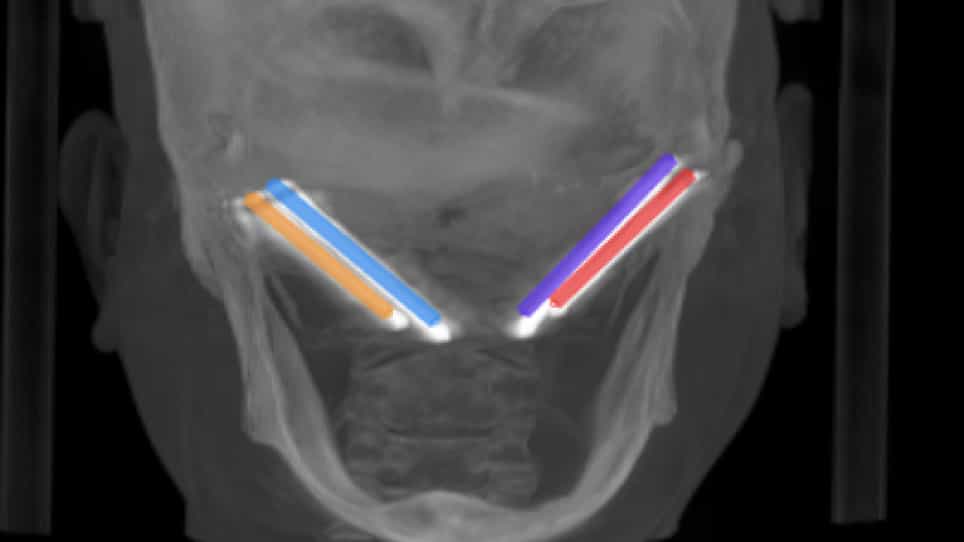

Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
The development of non-contact user interface of a surgical navigation system based on multi-LSTM and a phantom
Chunxia Qin1,2, Xingchen Ran3, Yiqun Wu4
1School of Biomedical Engineering, Shanghai Jiao Tong University, Shanghai, China.

Purpose:
Image-guided surgical navigation system (SNS) has proved to be an increasingly important assistance tool for mini-invasive surgery. However, using standard devices such as keyboard and mouse as human-computer interaction (HCI) is a latent vector of infectious medium, causing risks to patients and surgeons. To solve the human-computer interaction problem, we proposed an optimized structure of LSTM based on a depth camera to recognize gestures and applied it to an in-house oral and maxillofacial surgical navigation system (Qin et al. in Int J Comput Assist Radiol Surg 14(2):281-289, 2019).
Methods:
The proposed optimized structure of LSTM named multi-LSTM allows multiple input layers and takes into account the relationships between inputs. To combine the gesture recognition with the SNS, four left-hand signs waving along four directions were designed to correspond to four operations of the mouse, and the motion of right hand was used to control the movement of the cursor. Finally, a phantom study for zygomatic implant placement was conducted to evaluate the feasibility of multi-LSTM as HCI. RESULTS: 3D hand trajectories of both wrist and elbow from 10 participants were collected to train the recognition network. Then tenfold cross-validation was performed for judging signs, and the mean accuracy was 96% ± 3%. In the phantom study, four implants were successfully placed, and the average deviations of planned-placed implants were 1.22 mm and 1.70 mm for the entry and end points, respectively, while the angular deviation ranged from 0.4° to 2.9°.
Conclusion:
The results showed that this non-contact user interface based on multi-LSTM could be used as a promising tool to eliminate the disinfection problem in operation room and alleviate manipulation complexity of surgical navigation system.

Related Concept Videos
 01:30
Socioemotional Experience and Gender Development
 01:17
Transmission-based Precautions I: Contact, Enteric, and Droplets
Contact Precautions:
Contact precautions are the measures taken to prevent the transmission of infectious agents, especially epidemiologically important microorganisms such as MRSA or influenza, primarily transmitted through direct or indirect contact with an...
 02:04
Protein-protein Interfaces
02:04Protein-Protein Interfaces
 01:19
Contact-dependent Signaling
Gap Junctions
In animal cells, gap junctions are formed...
 01:13
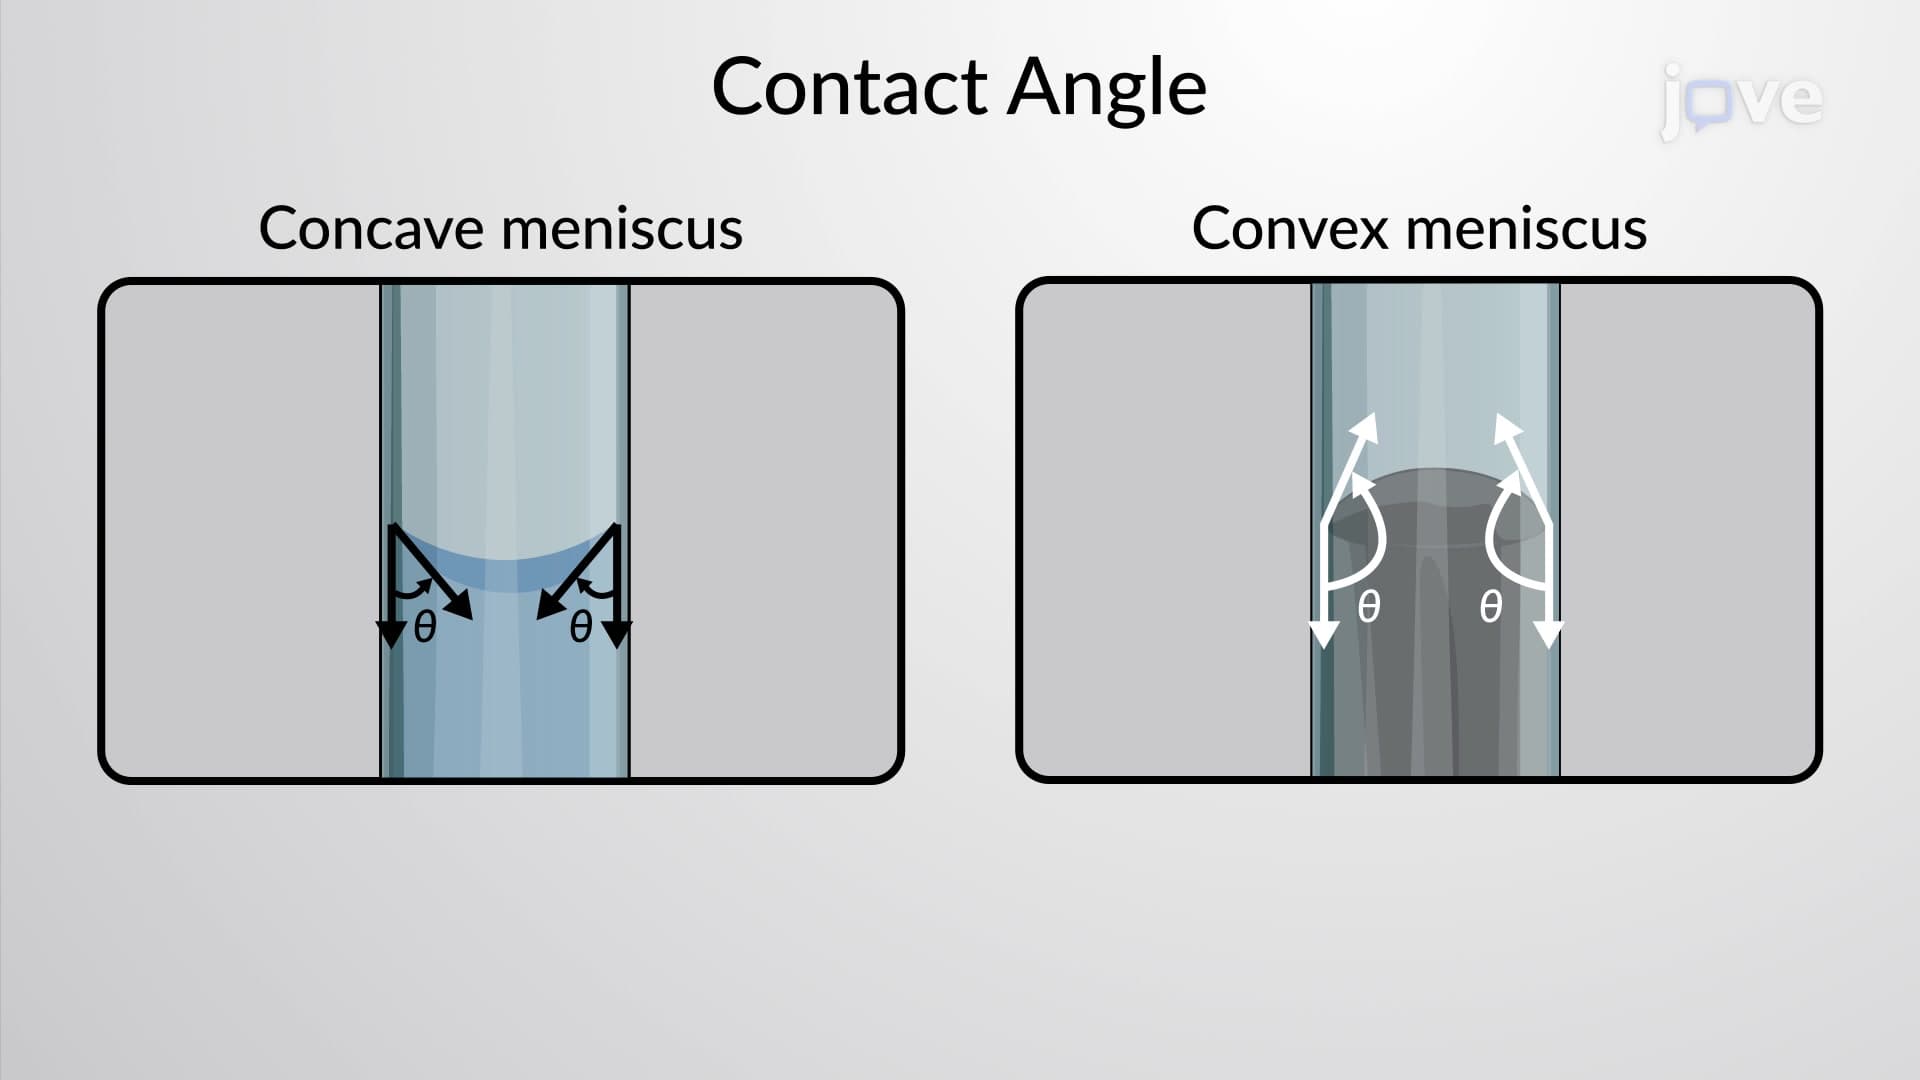
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...