Related Experiment Video
Updated: Jan 22, 2026

Using a Split-belt Treadmill to Evaluate Generalization of Human Locomotor Adaptation
Published on: August 23, 2017
Cutaneous sensory feedback from paw pads affects lateral balance control during split-belt locomotion in the cat
Hangue Park1,2, Elizaveta M Latash3, Yaroslav I Molkov3
1School of Electrical and Computer Engineering, Georgia Institute of Technology, Atlanta, GA 30318, USA.

Abstract:
Cutaneous sensory feedback from the paw pads plays an important role in regulating body balance, especially in challenging environments like ladder or slope walking. Here, we investigated the contribution of cutaneous sensory feedback from the paw pads to balance control in cats stepping on a split-belt treadmill. Forepaws and hindpaws were anesthetized unilaterally using lidocaine injections. We evaluated body balance in intact and compromised cutaneous feedback conditions during split-belt locomotion with belt-speed ratios of 0.5, 1.0, 1.5 and 2.0. Measures of body balance included step width, relative duration of limb support phases, lateral bias of center of mass (CoM) and margins of static and dynamic stability. In the intact condition, static and dynamic balance declined with increasing belt-speed ratio as a result of a lateral shift of the CoM toward the borders of support on the slower moving belt. Anesthesia of the ipsilateral paws improved locomotor balance with increasing belt-speed ratios by reversing the CoM shift, decreasing the relative duration of the two-limb support phase, increasing the duration of four- or three-limb support phases, and increasing the hindlimb step width and static stability. We observed no changes in most balance measures in anesthetized conditions during tied-belt locomotion at 0.4 m s-1 CoM lateral displacements closely resembled those of the inverted pendulum and of human walking. We propose that unilaterally compromised cutaneous feedback from the paw pads is compensated for by improving lateral balance and by shifting the body toward the anesthetized paws to increase tactile sensation during the stance phase.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:31
What is a Sensory System?
 00:46
Feedback Inhibition
 01:28
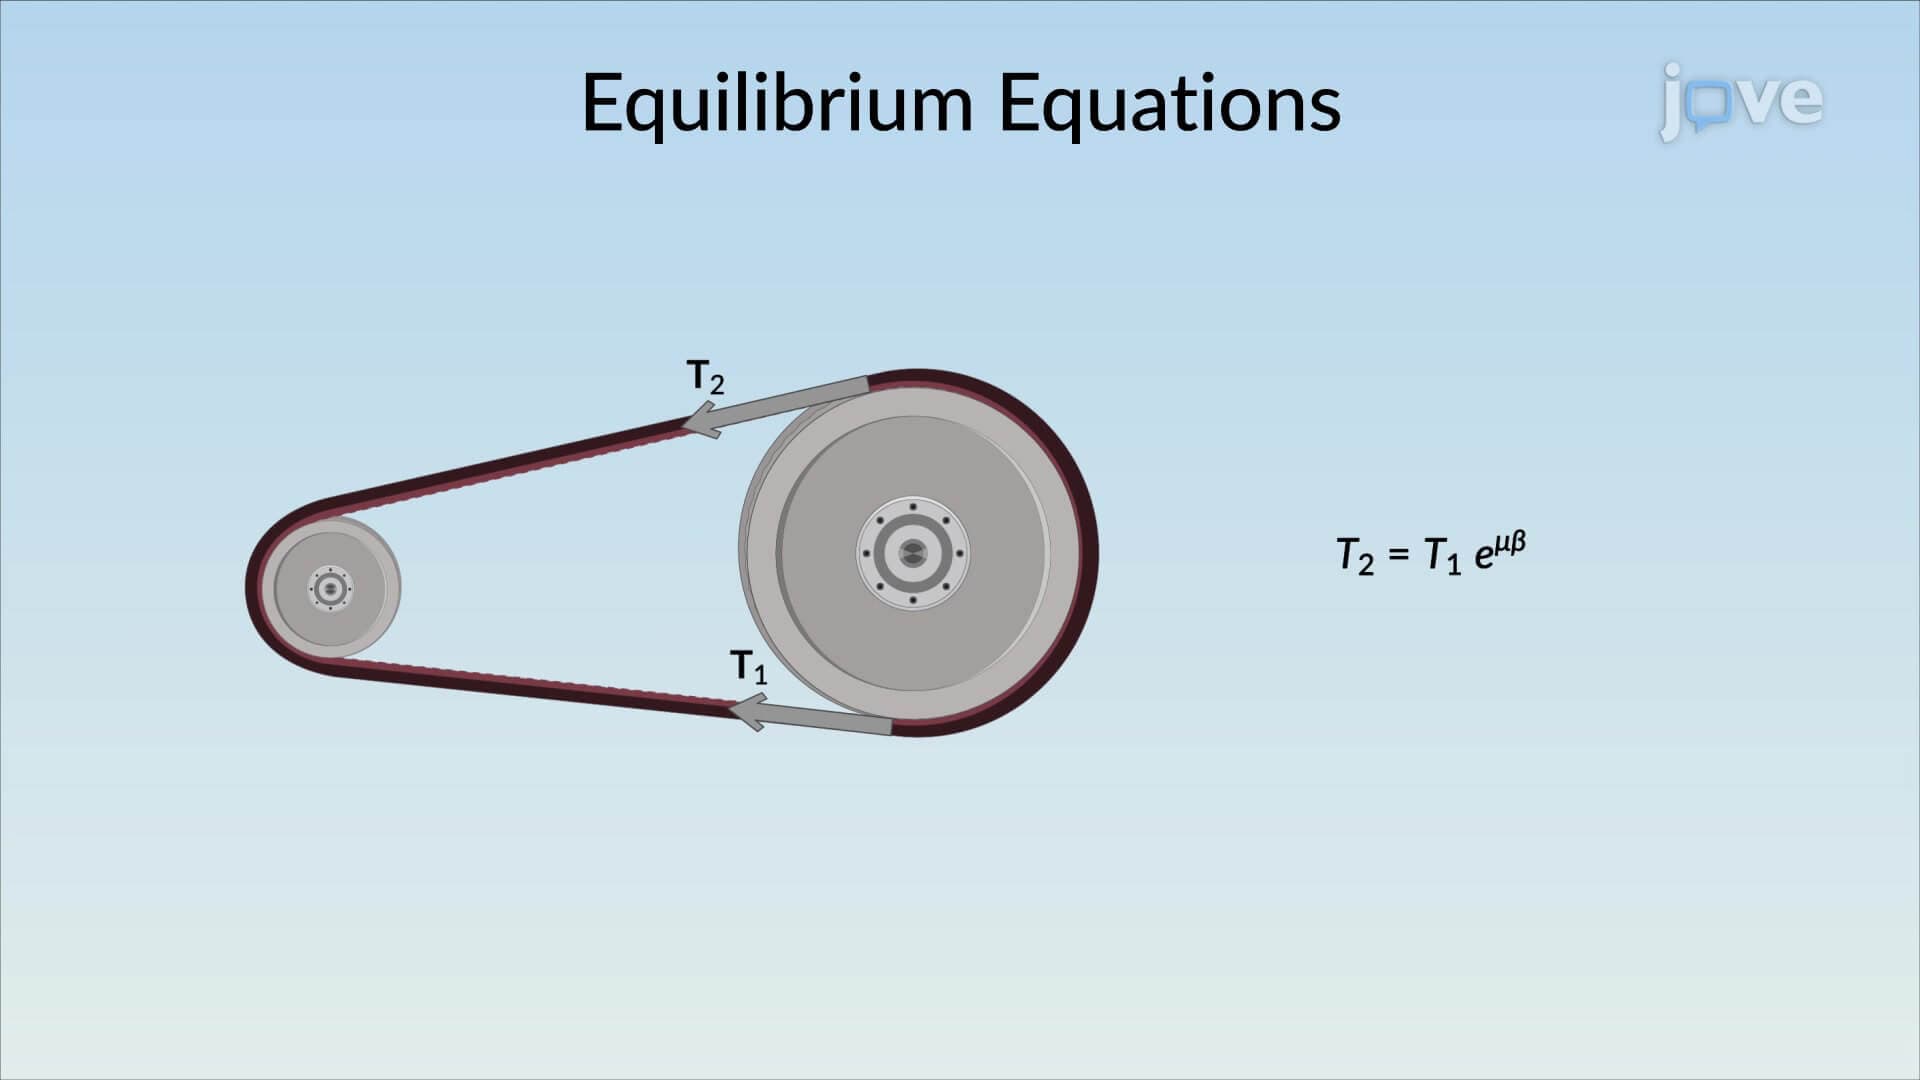
Frictional Forces on Flat Belts
 02:58
Balancing Redox Equations
 01:01
Feedback Loops