

A Novel Fault Feature Recognition Method for Time-Varying Signals and Its Application to Planetary Gearbox Fault
Yong Lv1,2, Bingqi Pan3,4, Cancan Yi5,6
1The Key Laboratory of Metallurgical Equipment and Control of Education Ministry, Wuhan University of Science and Technology, Wuhan 430081, China.

Abstract:
The existing time-frequency analysis (TFA) methods mainly highlight the time-frequency ridges of the interested components by optimizing the time-frequency plane to facilitate the extraction of the relevant components. Generalized demodulation (GD), order tracking (OT), and other methods are generally used in conjunction with the TFA methods to realize the transition from a time-varying signal to a stationary signal, and finally identify the fault feature through a time-frequency plane. Generally, it is necessary to clarify the accuracy of the estimated components such as the rotational frequency or the fault characteristic frequency (FCF) during the operation of the GD or OT methods. Unfortunately, it is not only difficult to extract and locate rotational frequency or FCF, but also complicated in the whole estimation process. In this paper, a simple yet readable method is proposed to reveal the fault feature of time-varying signals. First, the method only needs to extract an arbitrary instantaneous frequency (IF). This is different from the GD method which needs to estimate and locate all phase functions. Then, it converts all variable frequency curves into corresponding lines parallel to the frequency axis based on the extracted IF to determine the proportional relationship between the components. Finally, to further improve the readability of the final results, we reduce the dimension of the transformed time-frequency representation to generate a two-dimensional (2D) energy-frequency map with high resolution and the same proportion. Subsequently, the performance is validated by simulated and experimental data.
Related Concept Videos
 01:18
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:15
Real-World Application of Classical Conditioning
Higher-order, or second-order, conditioning occurs when a neutral stimulus becomes associated with an already established conditioned stimulus through repeated pairings. For instance, if a dog has been...
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:16
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:11
Sampling Continuous Time Signal
In the...
 01:18
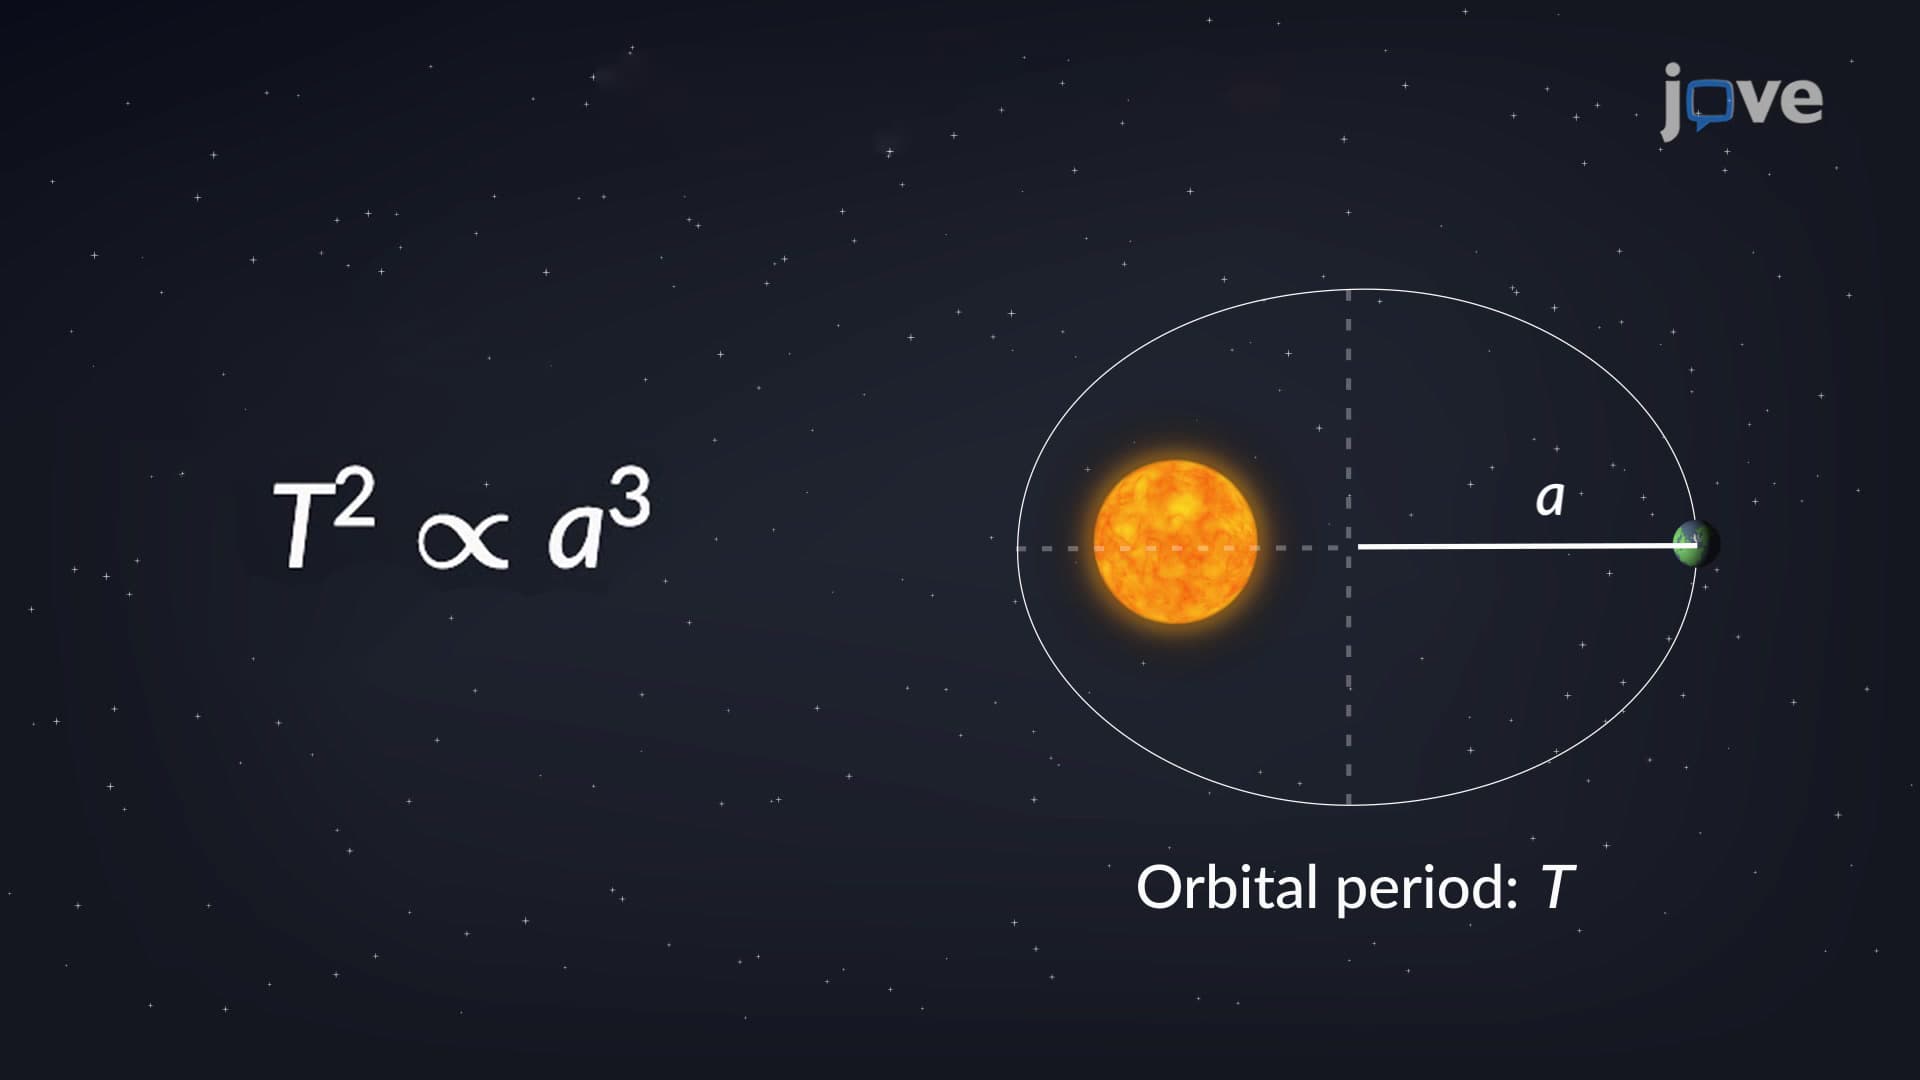
Kepler's Third Law of Planetary Motion