Related Experiment Video
Updated: Jan 21, 2026
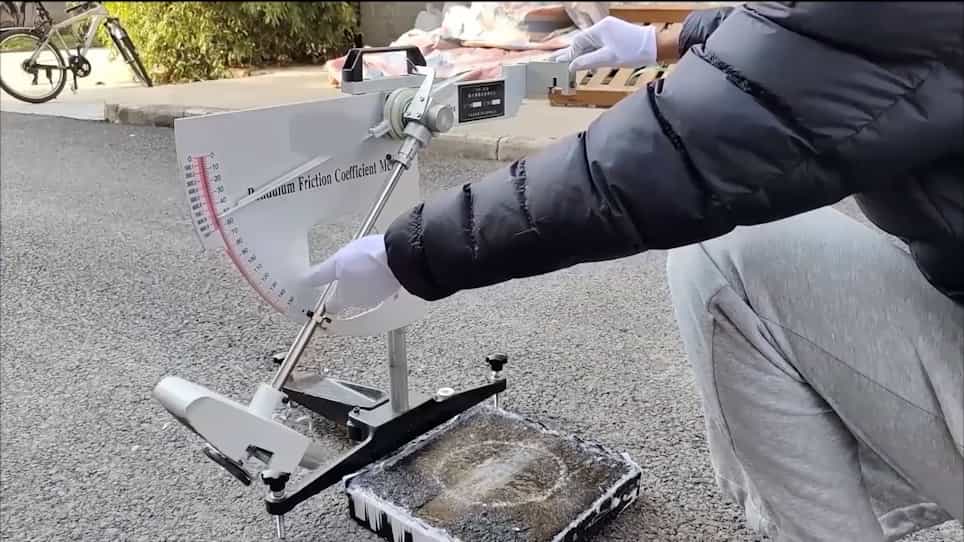

Determination of the Friction Coefficients of Icy Pavements Under Different Amounts of Snowfall
Published on: January 6, 2023
Efficient sliding locomotion with isotropic friction
1Department of Mathematics, University of Michigan, Ann Arbor, Michigan 48109, USA.

Abstract:
Snakes' bodies are covered in scales that make it easier to slide in some directions than in others. This frictional anisotropy allows for sliding locomotion with an undulatory gait, one of the most common for snakes. Isotropic friction is a simpler situation (that arises with snake robots, for example) but is less understood. In this work we regularize a model for sliding locomotion to allow for static friction. We then propose a robust iterative numerical method to study the efficiency of a wide range of motions under isotropic Coulomb friction. We find that simple undulatory motions give little net locomotion in the isotropic regime. We compute general time-harmonic motions of three-link bodies and find three local optima for efficiency. The top two involve static friction to some extent. We then propose a class of smooth body motions that have similarities to concertina locomotion (including the involvement of static friction) and can achieve optimal efficiency for both isotropic and anisotropic friction.
Related Concept Videos
 01:26
Kinetic Friction
 01:27
Types of Friction Problems
The first type of dry friction problem involves situations where there is no apparent impending motion....
 01:21
Friction: Problem Solving
Initially, a visual representation of the...
 01:21
Characteristics of Dry Friction
Before the wheelbarrow starts moving, the static frictional force acts tangentially to the contact surface, opposing the force that is about to induce the motion. This frictional force prevents the...
 01:07
Frictional Force
 01:30
Dry Friction
To illustrate this concept, imagine a wooden crate resting on a rough, non-uniform horizontal surface. When an external force is applied to...