Related Experiment Video
Updated: Jan 21, 2026

Sample Preparation Method of Scanning and Transmission Electron Microscope for the Appendages of Woodboring Beetle
Published on: February 3, 2020
Comprehensive analysis of efficient swimming using articulated legs fringed with flexible appendages inspired by a
Bokeon Kwak1, Dongyoung Lee, Joonbum Bae
1Bio-Robotics and Control (BiRC) Laboratory, Department of Mechanical Engineering, UNIST, Ulsan, Republic of Korea.

Abstract:
Drag-based swimming is usually accompanied with the shape change of rowing appendages to generate asymmetric force during the power stroke and recovery stroke. To implement this in an aquatic robot, one may actively control the surface area of its legs during the swimming. However, a small sized robot with a limited number of actuators should adjust the surface area of legs in passive manner. For this reason, we proposed a novel articulated leg with flexible appendages inspired by a water beetle. These leg structures were designed to implement an efficient recovery stroke with less resistive force during the recovery stroke, while its surface area was increased again if suitable relaxation time was applied to perform improved power stroke. To identify an optimal leg design, 36 different types were fabricated by changing the passive joint thickness, appendage materials, length, and morphology. Several correlations and dominant parameters were identified, and it was shown that the swimming leg with fixed joint and appendage stiffness cannot always generate the largest torque in all the swimming frequency. Also, a two-dimensional dynamic model was proposed based on an underactuated manipulator, and the model validation was proceeded by comparing with two selected leg designs. In addition, a 5.5 cm long robot with one pair of legs was built to further investigate their locomotory performance. By varying the beating frequency and relaxation time, thorough analysis was addressed in terms of the position, velocity, non-dimensional traveled distance, Strouhal number, and quasi-propulsive efficiency. Here, some important relationships between dimensionless numbers were established. Furthermore, it was found that introducing a relaxation phase between the power stroke and recovery stroke can increase the traveled distance per stroke with slight expense of propulsive efficiency.
Related Concept Videos
 01:28
Articulations of the Vertebral Column
 01:23
Surface Appendages of Archaea
 01:23
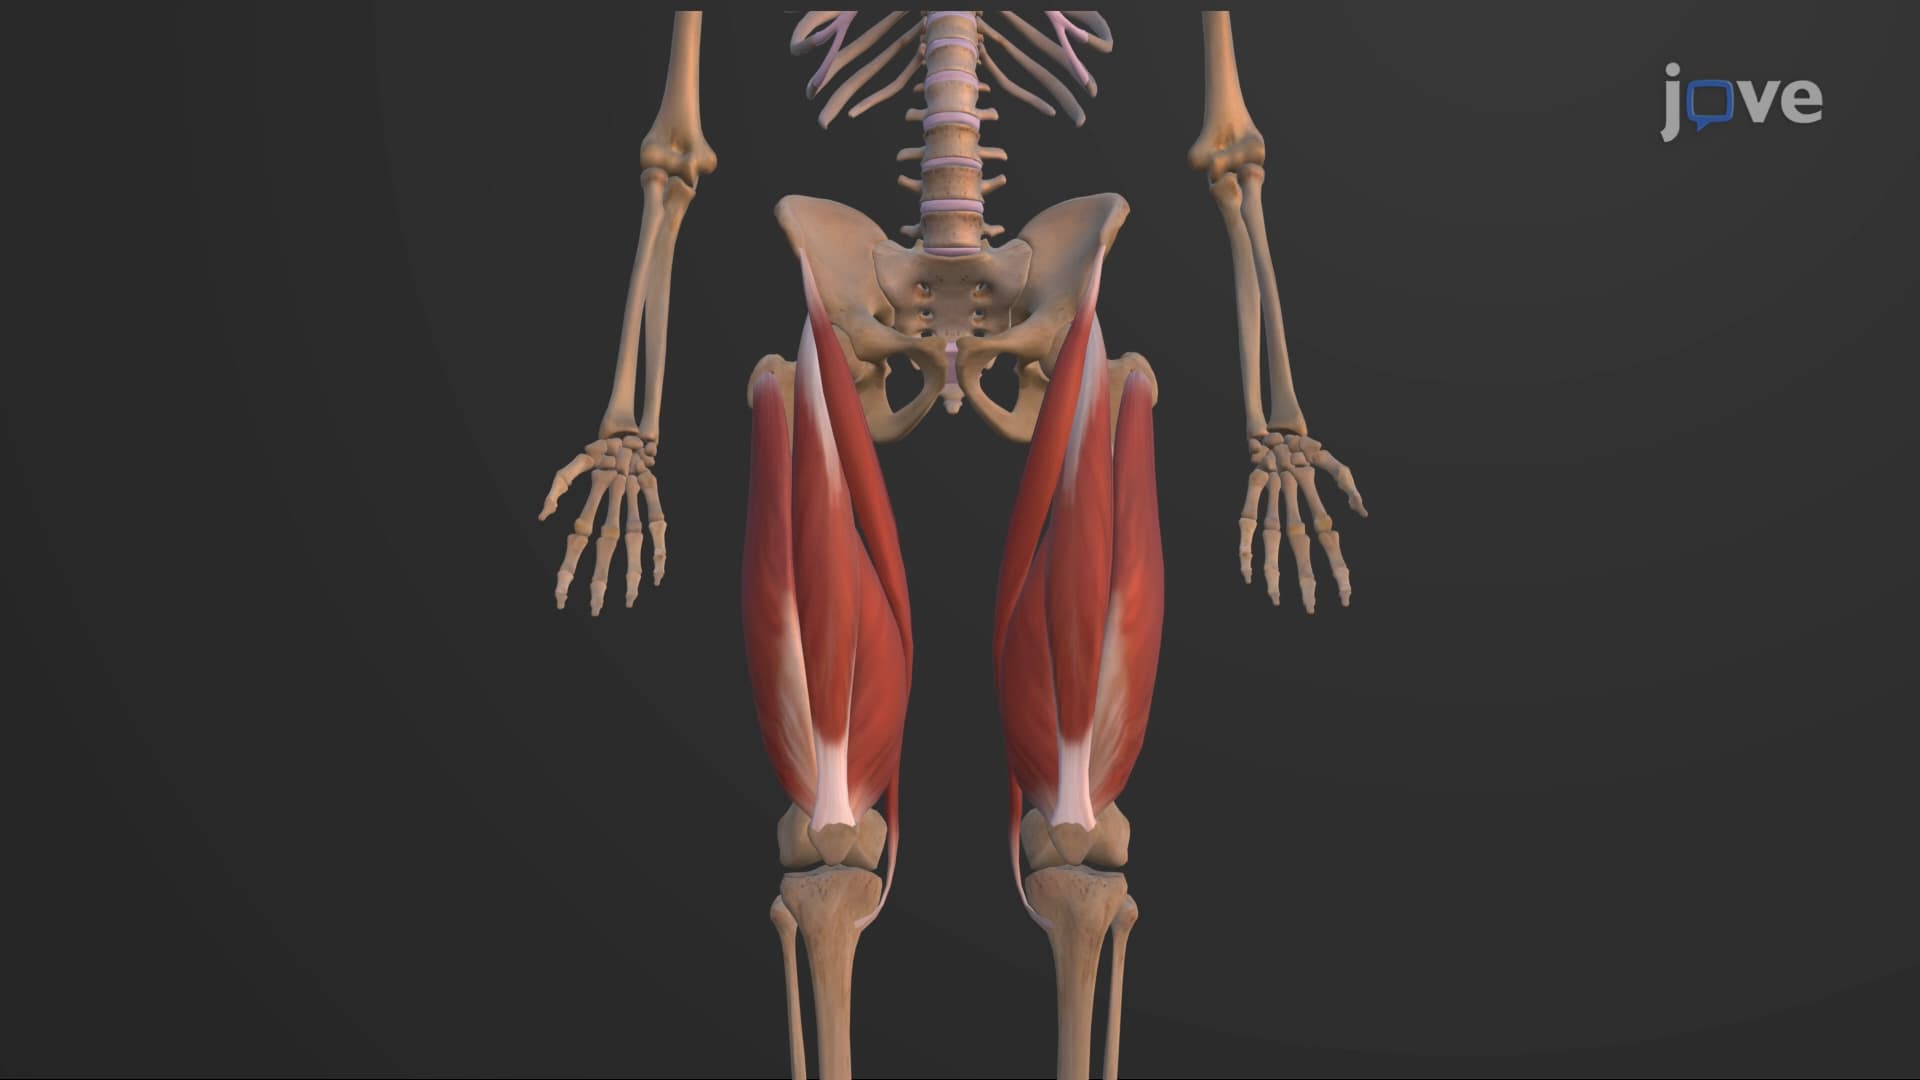
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:30
Mechanism of Breathing I: Inspiration
The respiratory system, an essential network for breathing, comprises the conducting and respiratory zones, each playing a crucial role in the overall process of respiration. Let us explore the detailed mechanism of inspiration, or inhalation, which is the first phase of the respiratory cycle.
Pathway of Air during Inspiration
During inspiration, air enters our body through the nose or mouth and moves through the conducting zone,...
 02:34
Water and Mineral Acquisition
 01:28
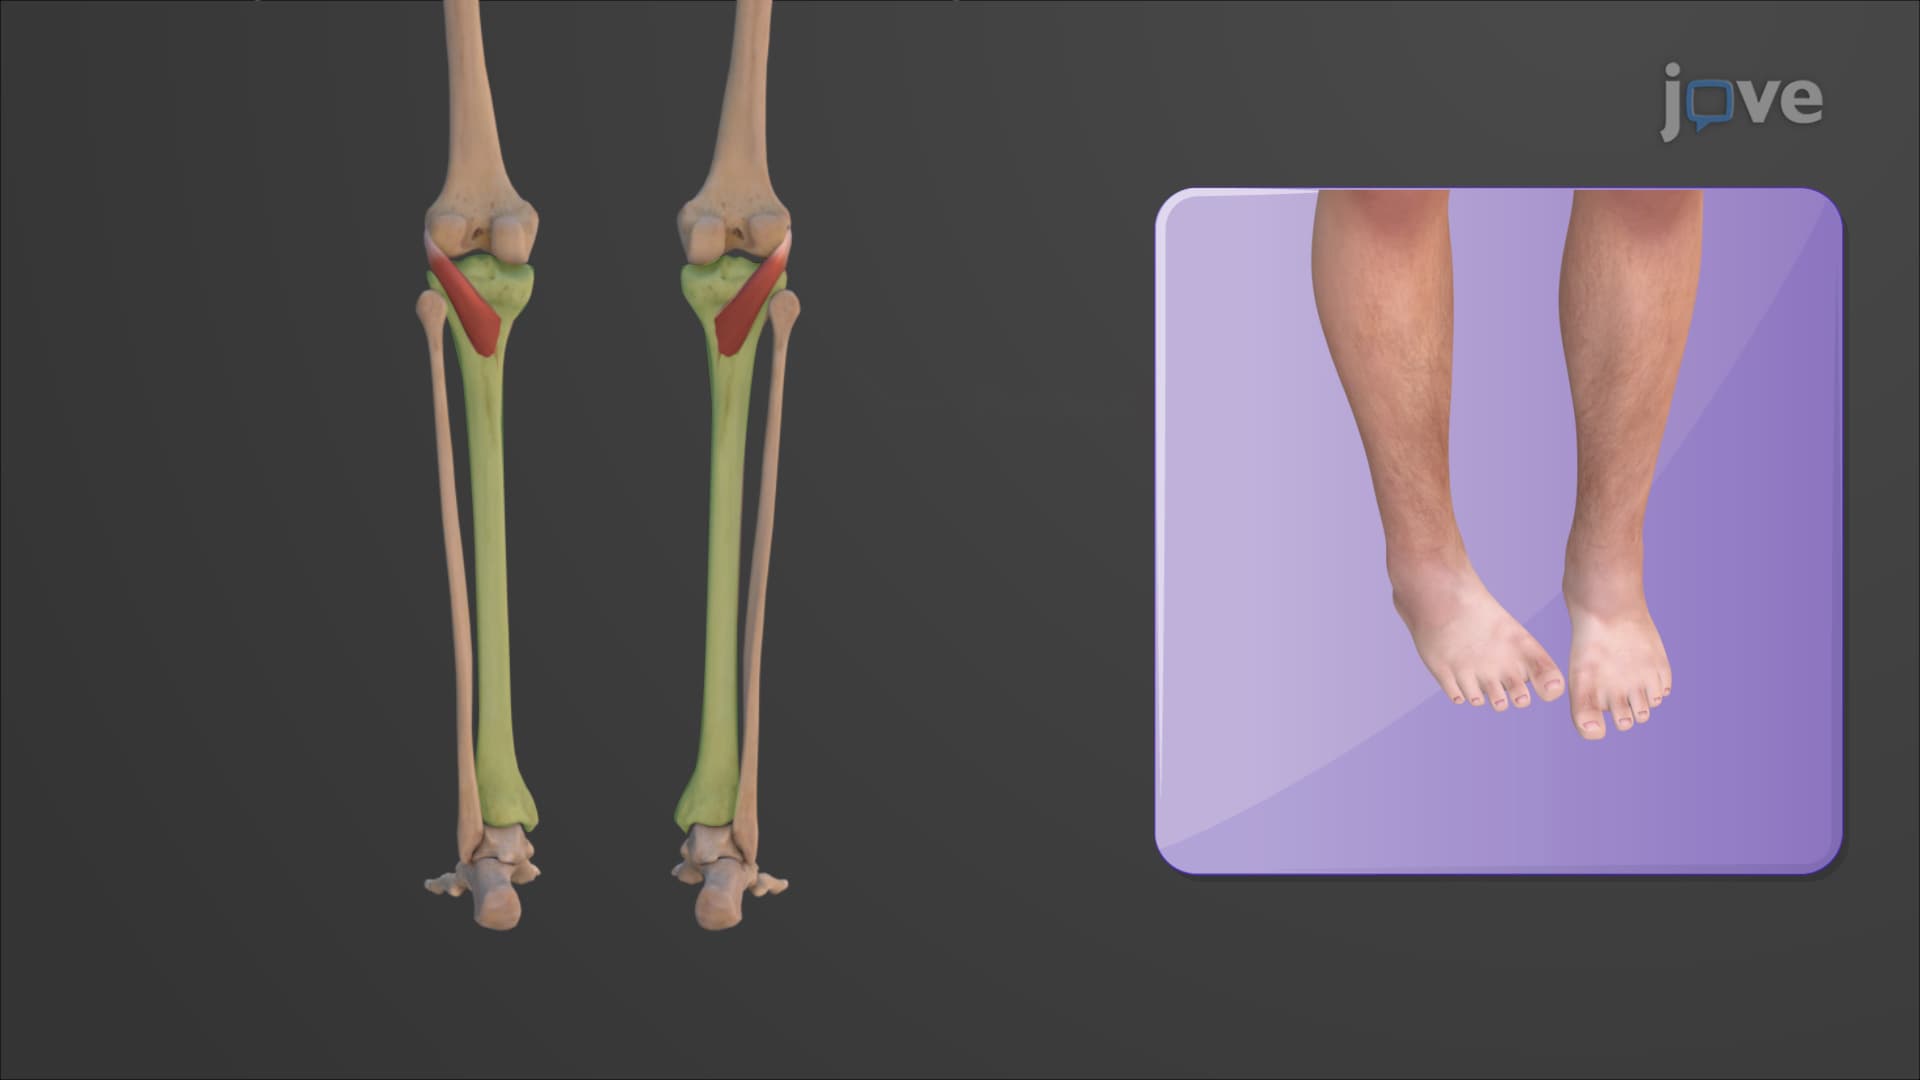
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....