Making space for escape
Related Experiment Video
Updated: Jan 21, 2026
08:03
Optogenetic Stimulation of Escape Behavior in Drosophila melanogaster
Published on: January 25, 2013
18.0K
The Veterinary Record
|August 10, 2019

Abstract:
Getting away from the daily grind is central to wellbeing, but is it possible to find a place to which to escape during the working day? At Willows Veterinary Centre and Referral Service, there has been a conscious effort to ensure the answer to that question is yes. Claire Read reports.
Related Concept Videos
 01:26
Escape Velocity
8.3K
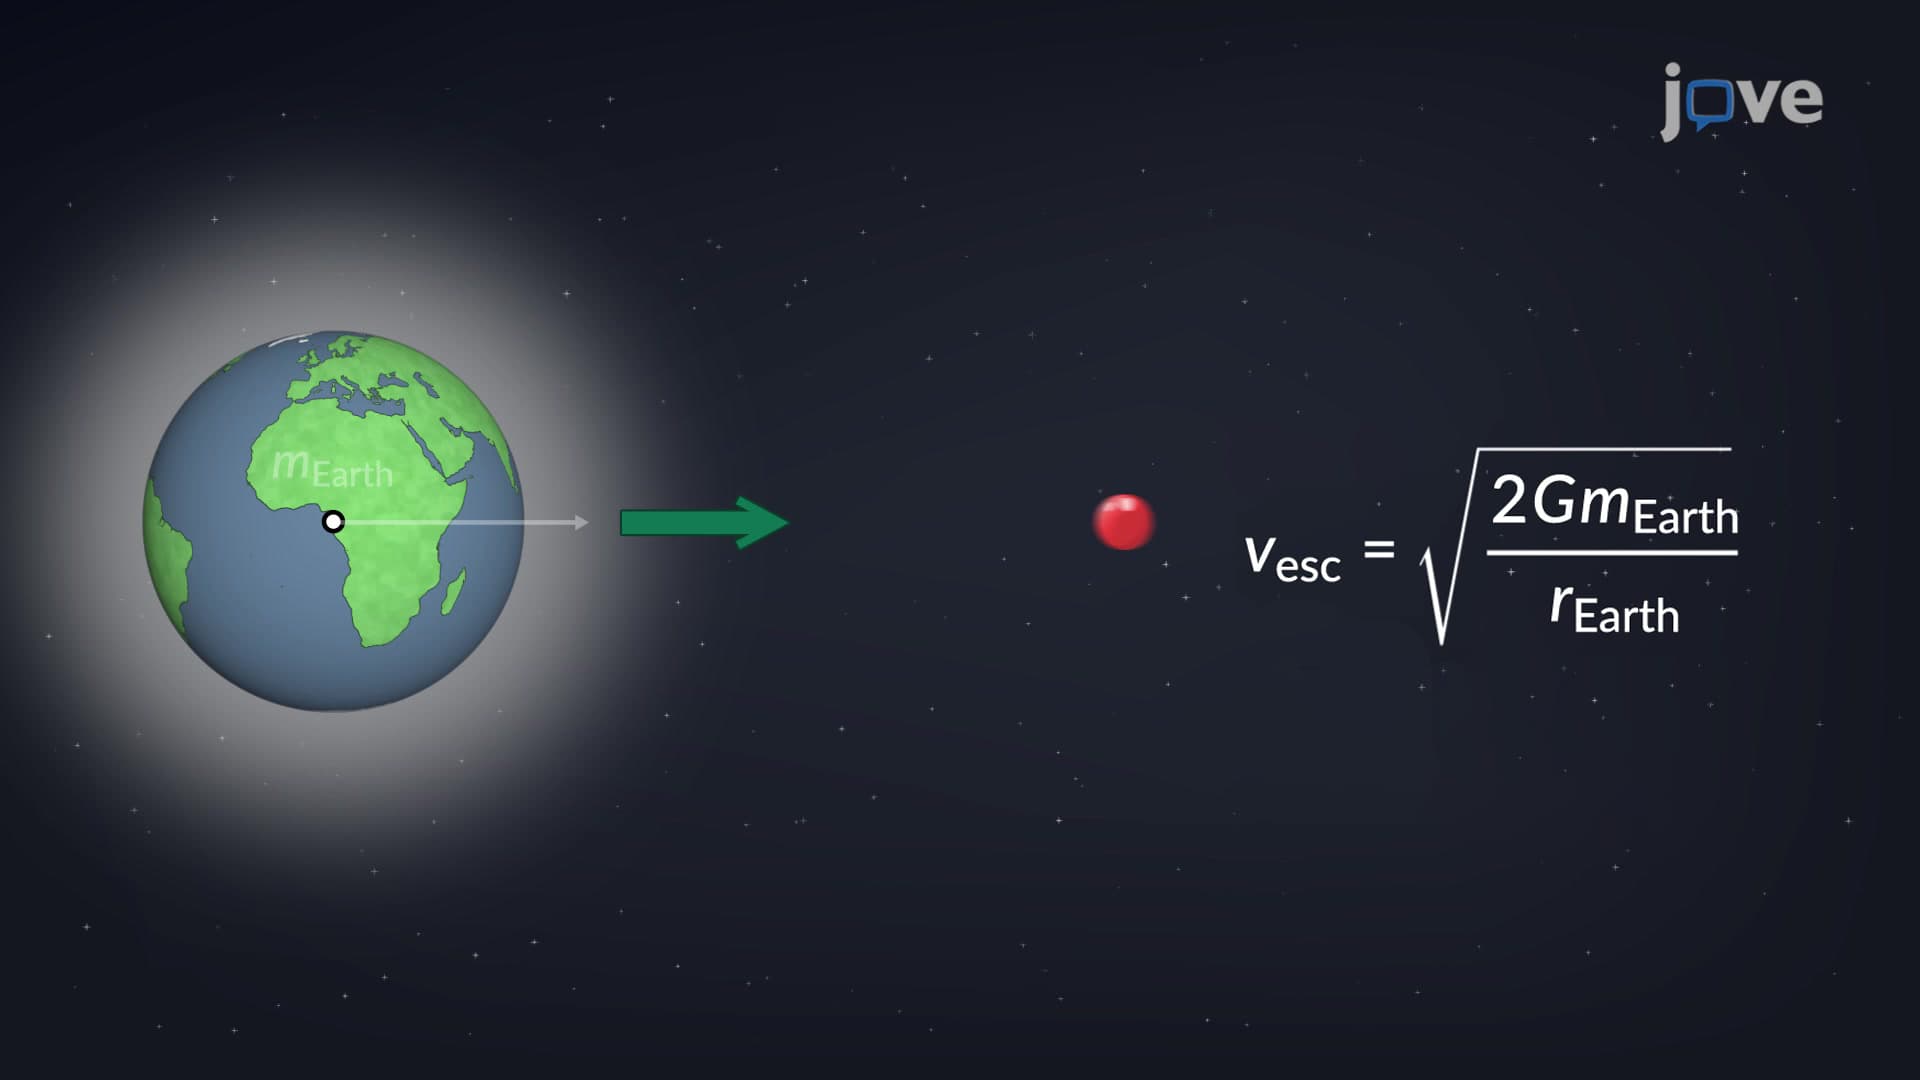
The escape velocity of an object is defined as the minimum initial velocity that it requires to escape the surface of another object to which it is gravitationally bound and never to return. For example, what would be the minimum velocity at which a satellite should be launched from the Earth's surface such that it just escapes the Earth's gravitational field?
To calculate the escape velocity, it is assumed that no energy is lost to any frictional forces. In practice, a satellite...
To calculate the escape velocity, it is assumed that no energy is lost to any frictional forces. In practice, a satellite...
8.3K
 01:19
Escape Velocities of Gases
1.3K
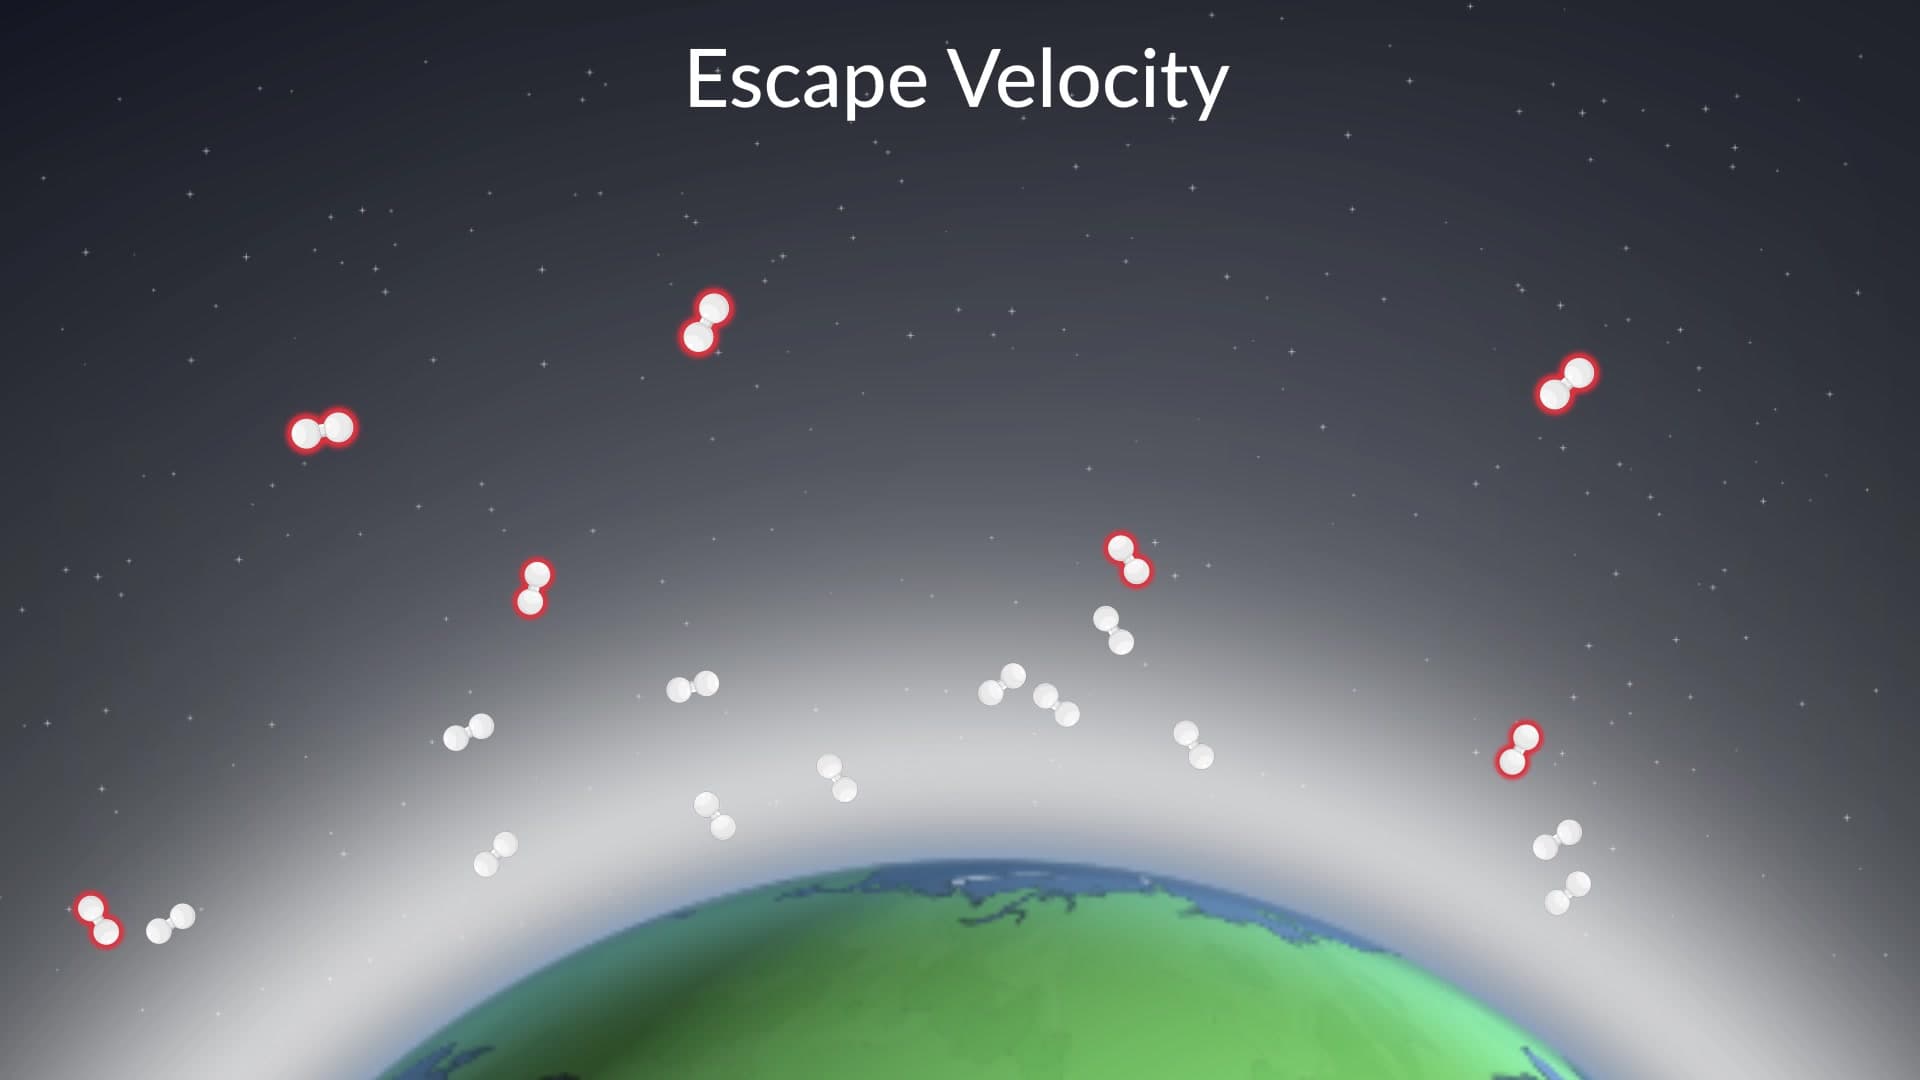
To escape the Earth's gravity, an object near the top of the atmosphere at an altitude of 100 km must travel away from Earth at 11.1 km/s. This speed is called the escape velocity. The temperature at which gas molecules attain the rms speed, which is equal to the escape velocity, can be estimated by using the equation for the average kinetic energy of the gas molecules. According to the kinetic theory of gas, the average kinetic energy of the gas molecules is proportional to its...
1.3K
 01:27
State Space Representation
536
The frequency-domain technique, commonly used in analyzing and designing feedback control systems, is effective for linear, time-invariant systems. However, it falls short when dealing with nonlinear, time-varying, and multiple-input multiple-output systems. The time-domain or state-space approach addresses these limitations by utilizing state variables to construct simultaneous, first-order differential equations, known as state equations, for an nth-order system.
Consider an RLC circuit, a...
Consider an RLC circuit, a...
536
 01:25
Space Trusses
1.3K
A space truss is a three-dimensional counterpart of a planar truss. These structures consist of members connected at their ends, often utilizing ball-and-socket joints to create a stable and versatile framework. The space truss is widely used in various construction projects due to its adaptability and capacity to withstand complex loads.
At the core of a space truss lies the fundamental unit known as the tetrahedron. This structure is composed of six members that form a three-dimensional shape...
At the core of a space truss lies the fundamental unit known as the tetrahedron. This structure is composed of six members that form a three-dimensional shape...
1.3K
 01:23
Transfer Function to State Space
773
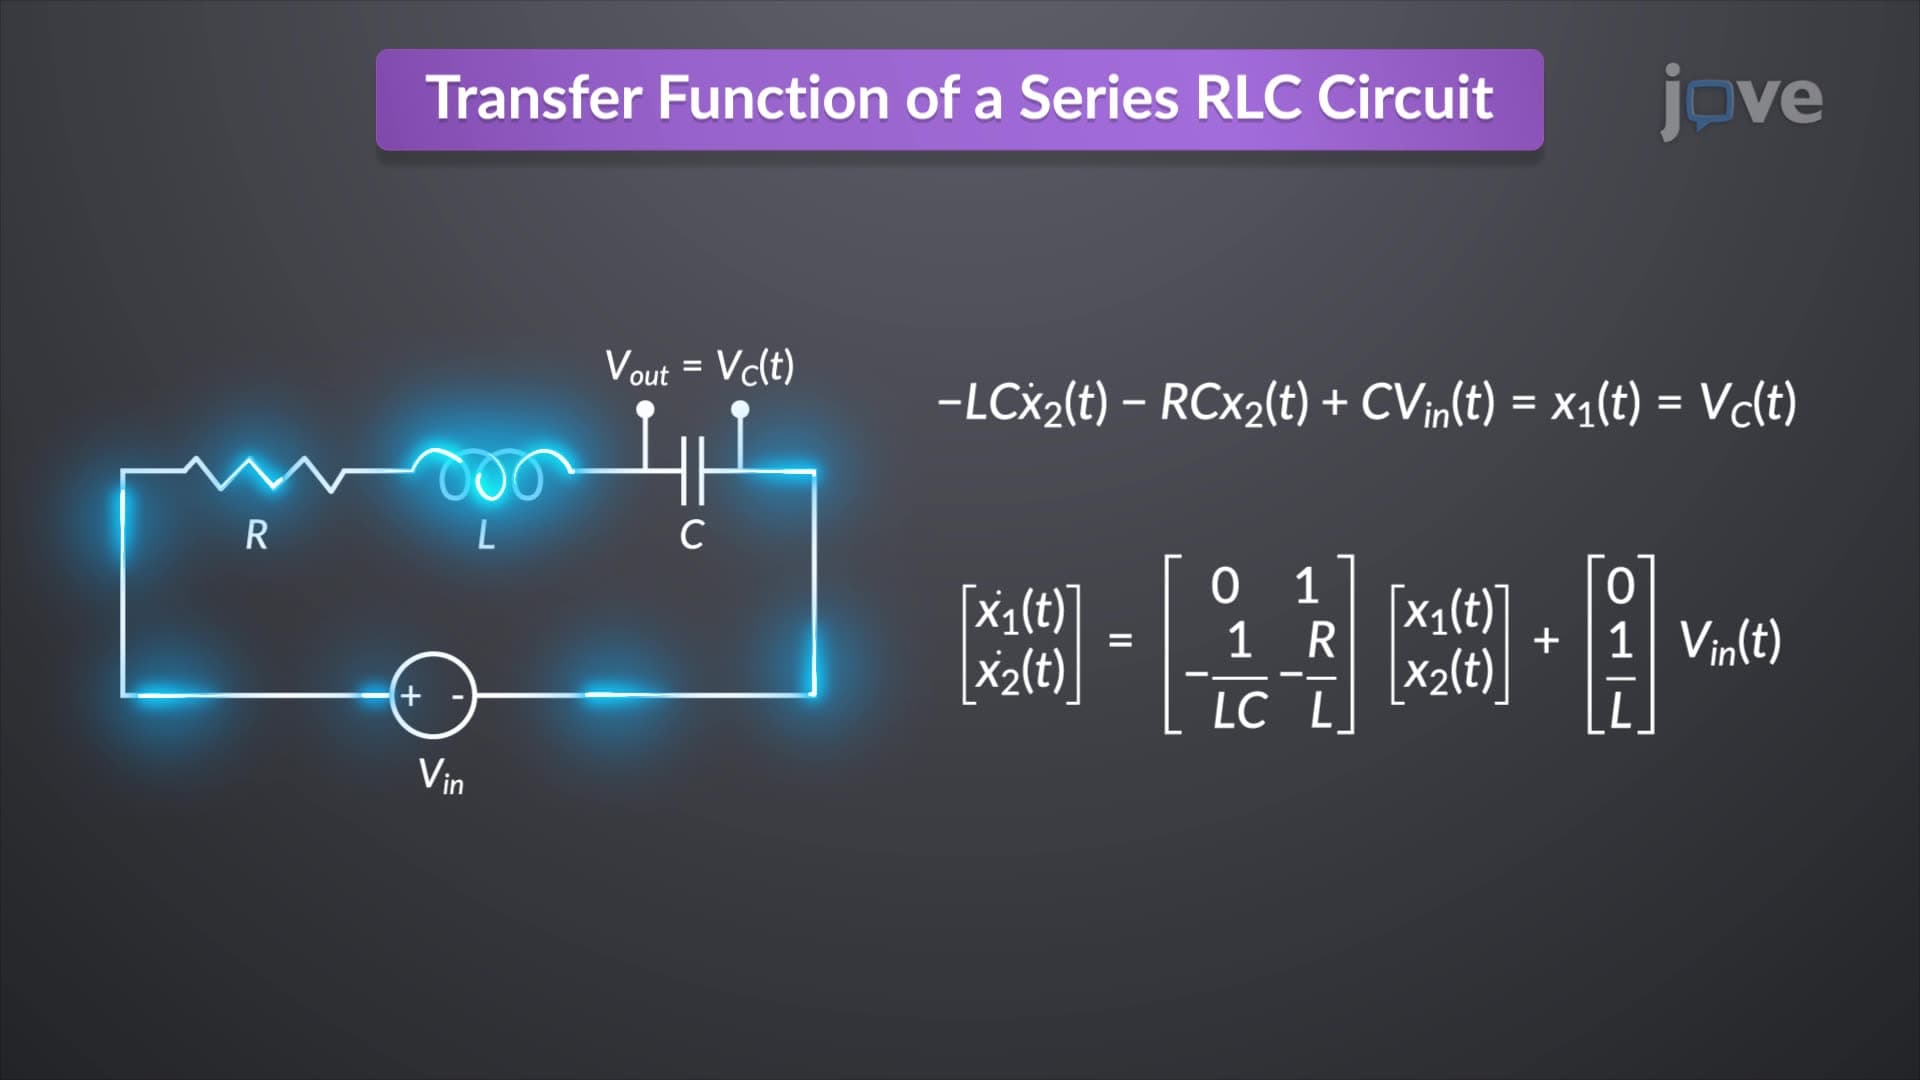
State-space representation is a powerful tool for simulating physical systems on digital computers, necessitating the conversion of the transfer function into state-space form. Consider an nth-order linear differential equation with constant coefficients, like those encountered in an RLC circuit. The state variables are selected as the output and its n−1 derivatives. Differentiating these variables and substituting them back into the original equation produces the state equations.
In an RLC...
In an RLC...
773
 01:21
State Space to Transfer Function
560
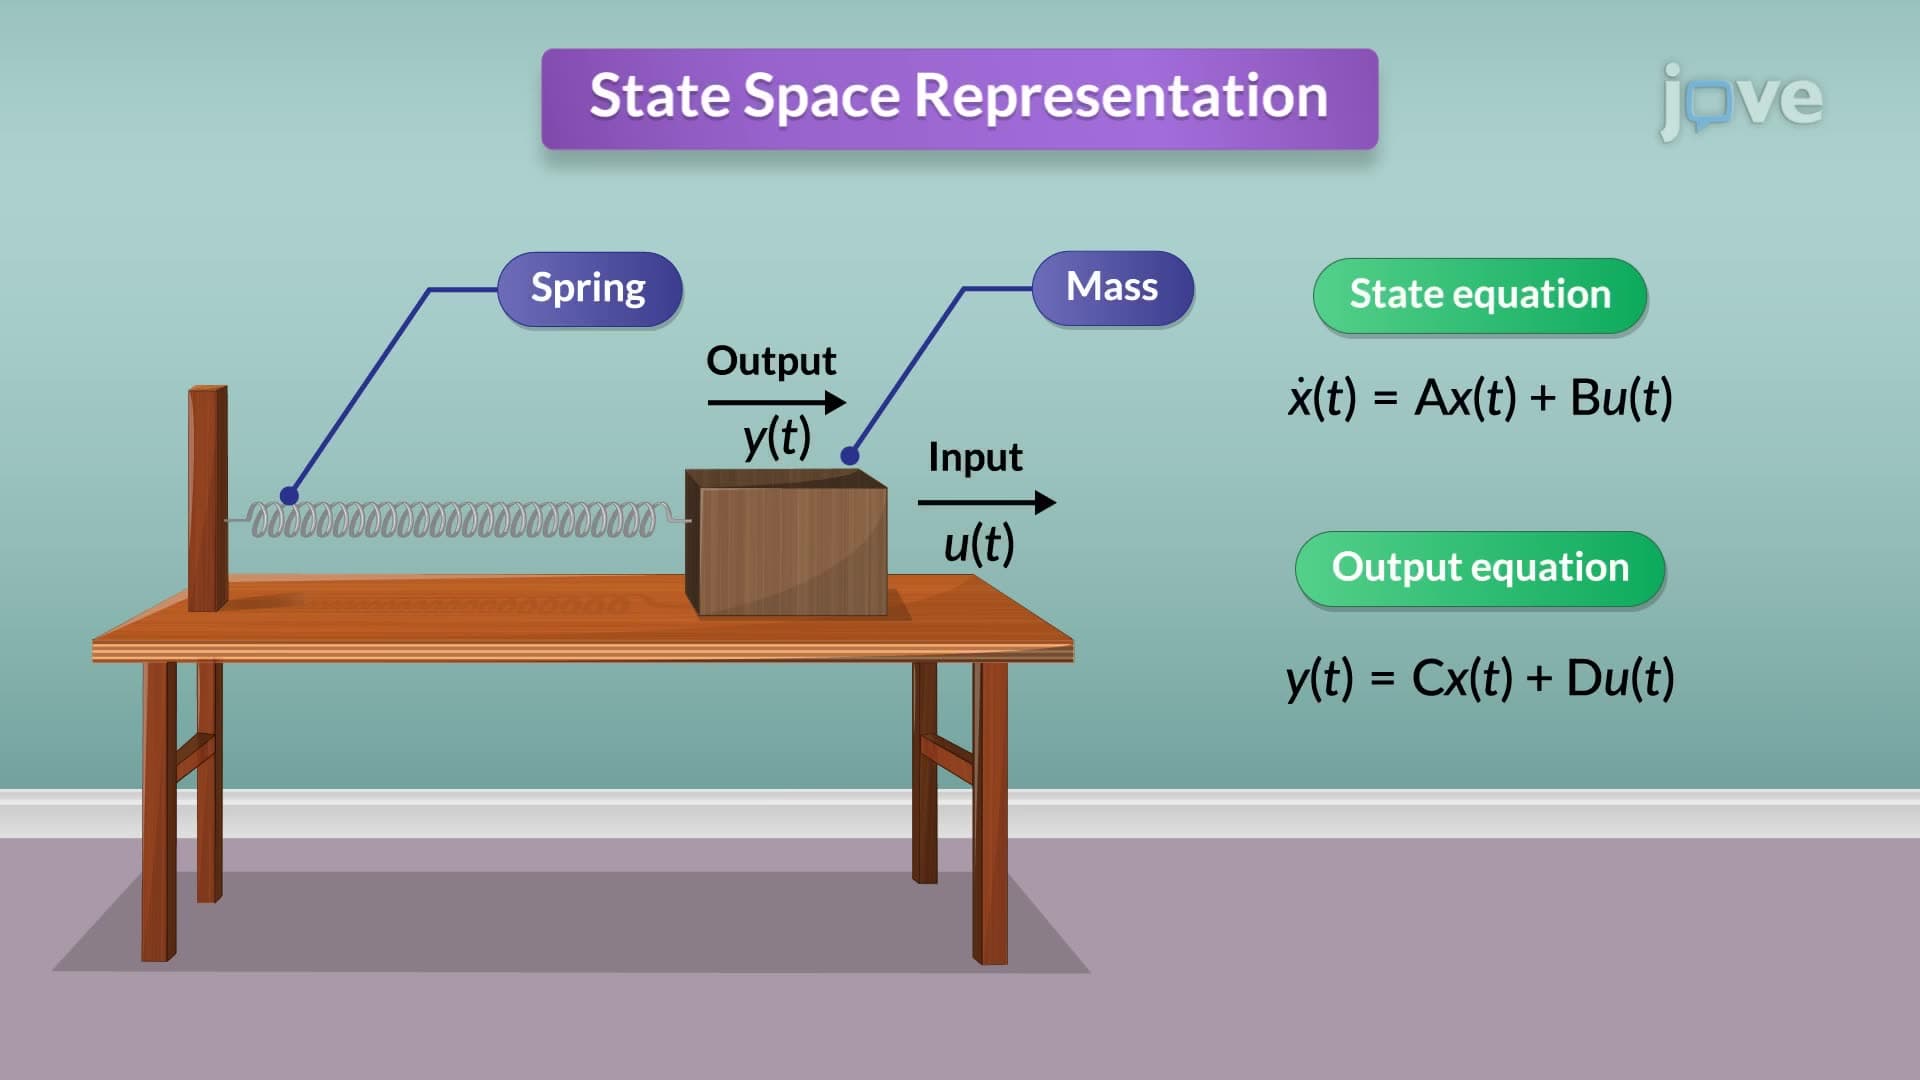
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
560