Terrestrial Hot Spring Systems: Introduction
Related Experiment Video
Updated: Jan 20, 2026
Isolation and Identification of Bacterial Strains from Skin of Terrestrial Amphibians
Published on: June 17, 2025
David J Des Marais1, Malcolm R Walter2
1Exobiology Branch, NASA Ames Research Center, Moffett Field, California, USA.

Abstract:
This report reviews how terrestrial hot spring systems can sustain diverse and abundant microbial communities and preserve their fossil records. Hot springs are dependable water sources, even in arid environments. They deliver reduced chemical species and other solutes to more oxidized surface environments, thereby providing redox energy and nutrients. Spring waters have diverse chemical compositions, and their outflows create thermal gradients and chemical precipitates that sustain diverse microbial communities and entomb their remnants. These environments probably were important habitats for ancient benthic microbial ecosystems, and it has even been postulated that life arose in hydrothermal systems. Thermal spring communities are fossilized in deposits of travertine, siliceous sinter, and iron minerals (among others) that are found throughout the geological record back to the oldest known well-preserved rocks at 3.48 Ga. Very few are known before the Cenozoic, but it is likely that there are many more to be found. They preserve fossils ranging from microbes to trees and macroscopic animals. Features on Mars whose morphological and spectroscopic attributes resemble spring deposits on Earth have been detected in regions where geologic context is consistent with the presence of thermal springs. Such features represent targets in the search for evidence of past life on that planet.
Related Concept Videos
 01:17
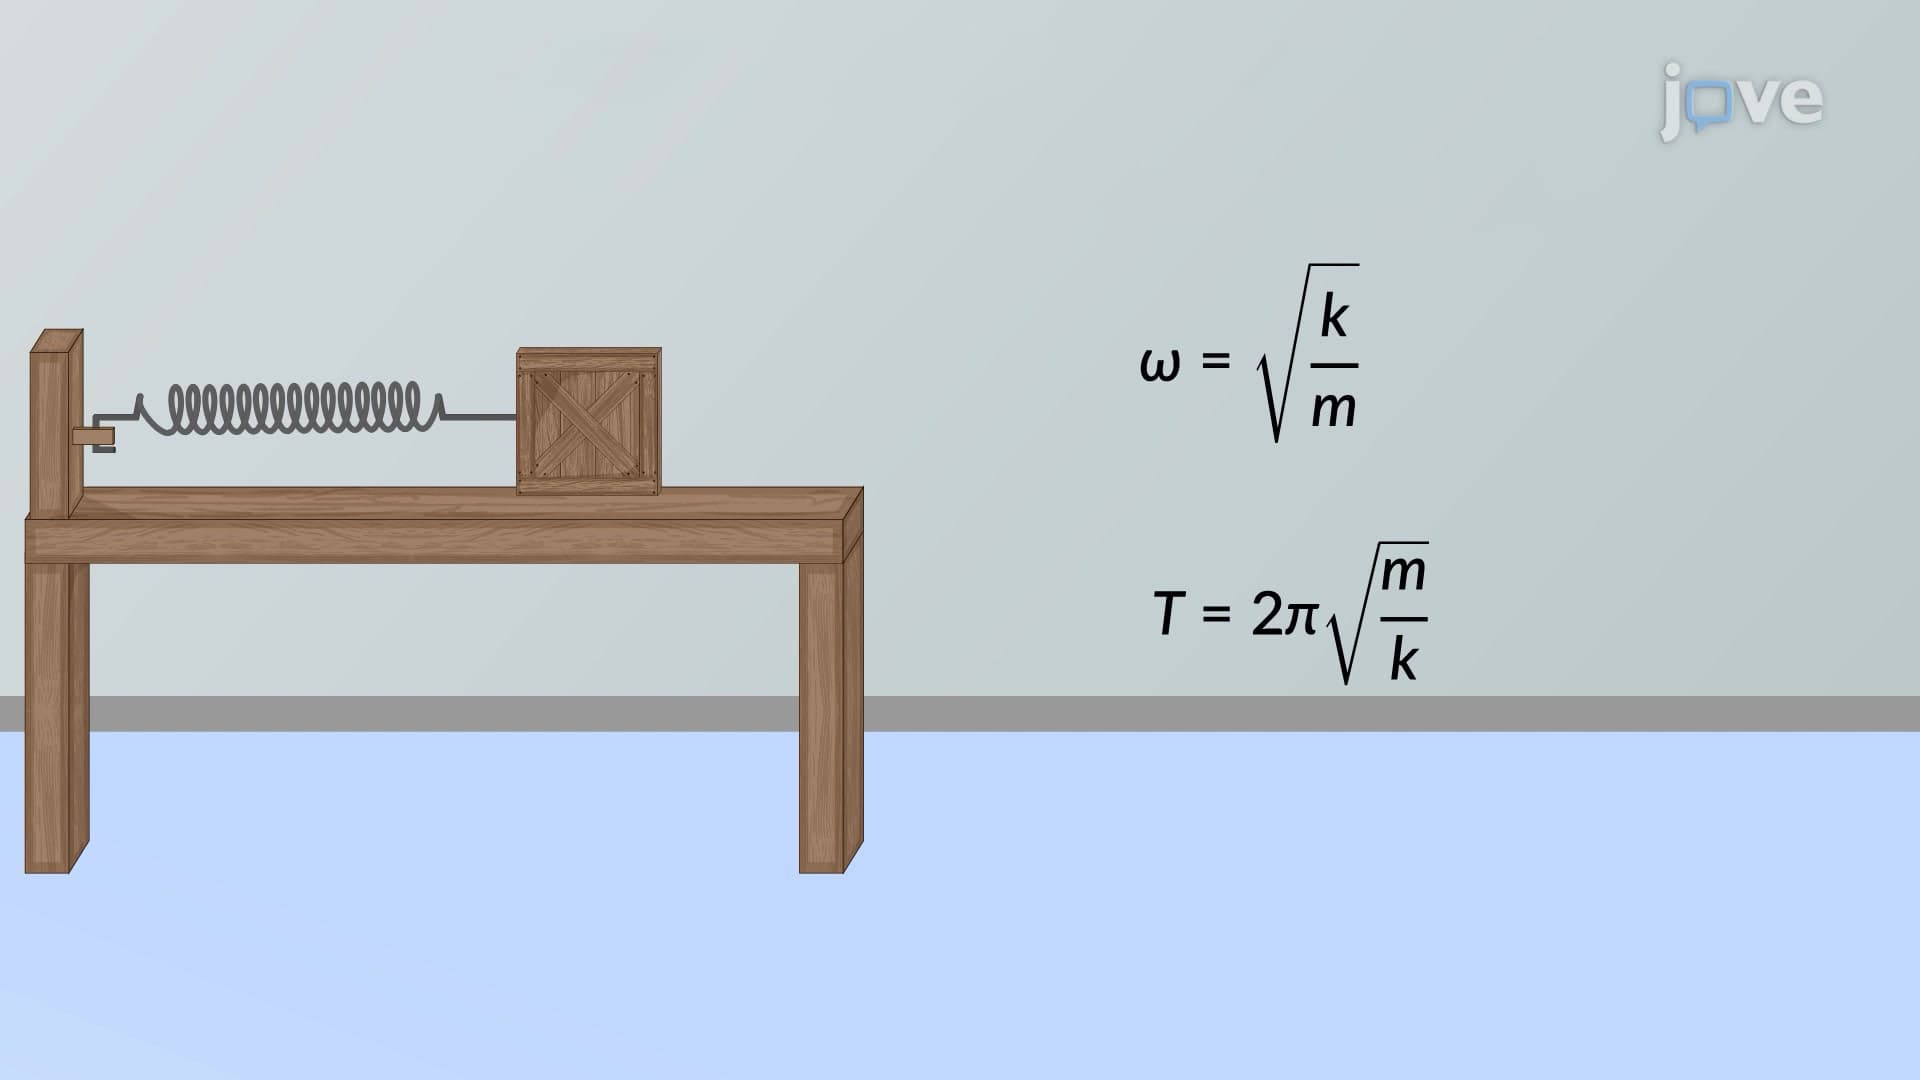
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 01:20
Hot Weather Concreting
Mitigating the heat increase in concrete can be economically achieved by shading aggregate stockpiles to prevent heating from solar radiation,...
 01:21
Masonry in Cold and Hot Weather Conditions
Other key practices include keeping masonry units...
 01:18
Second Order systems II
 01:21
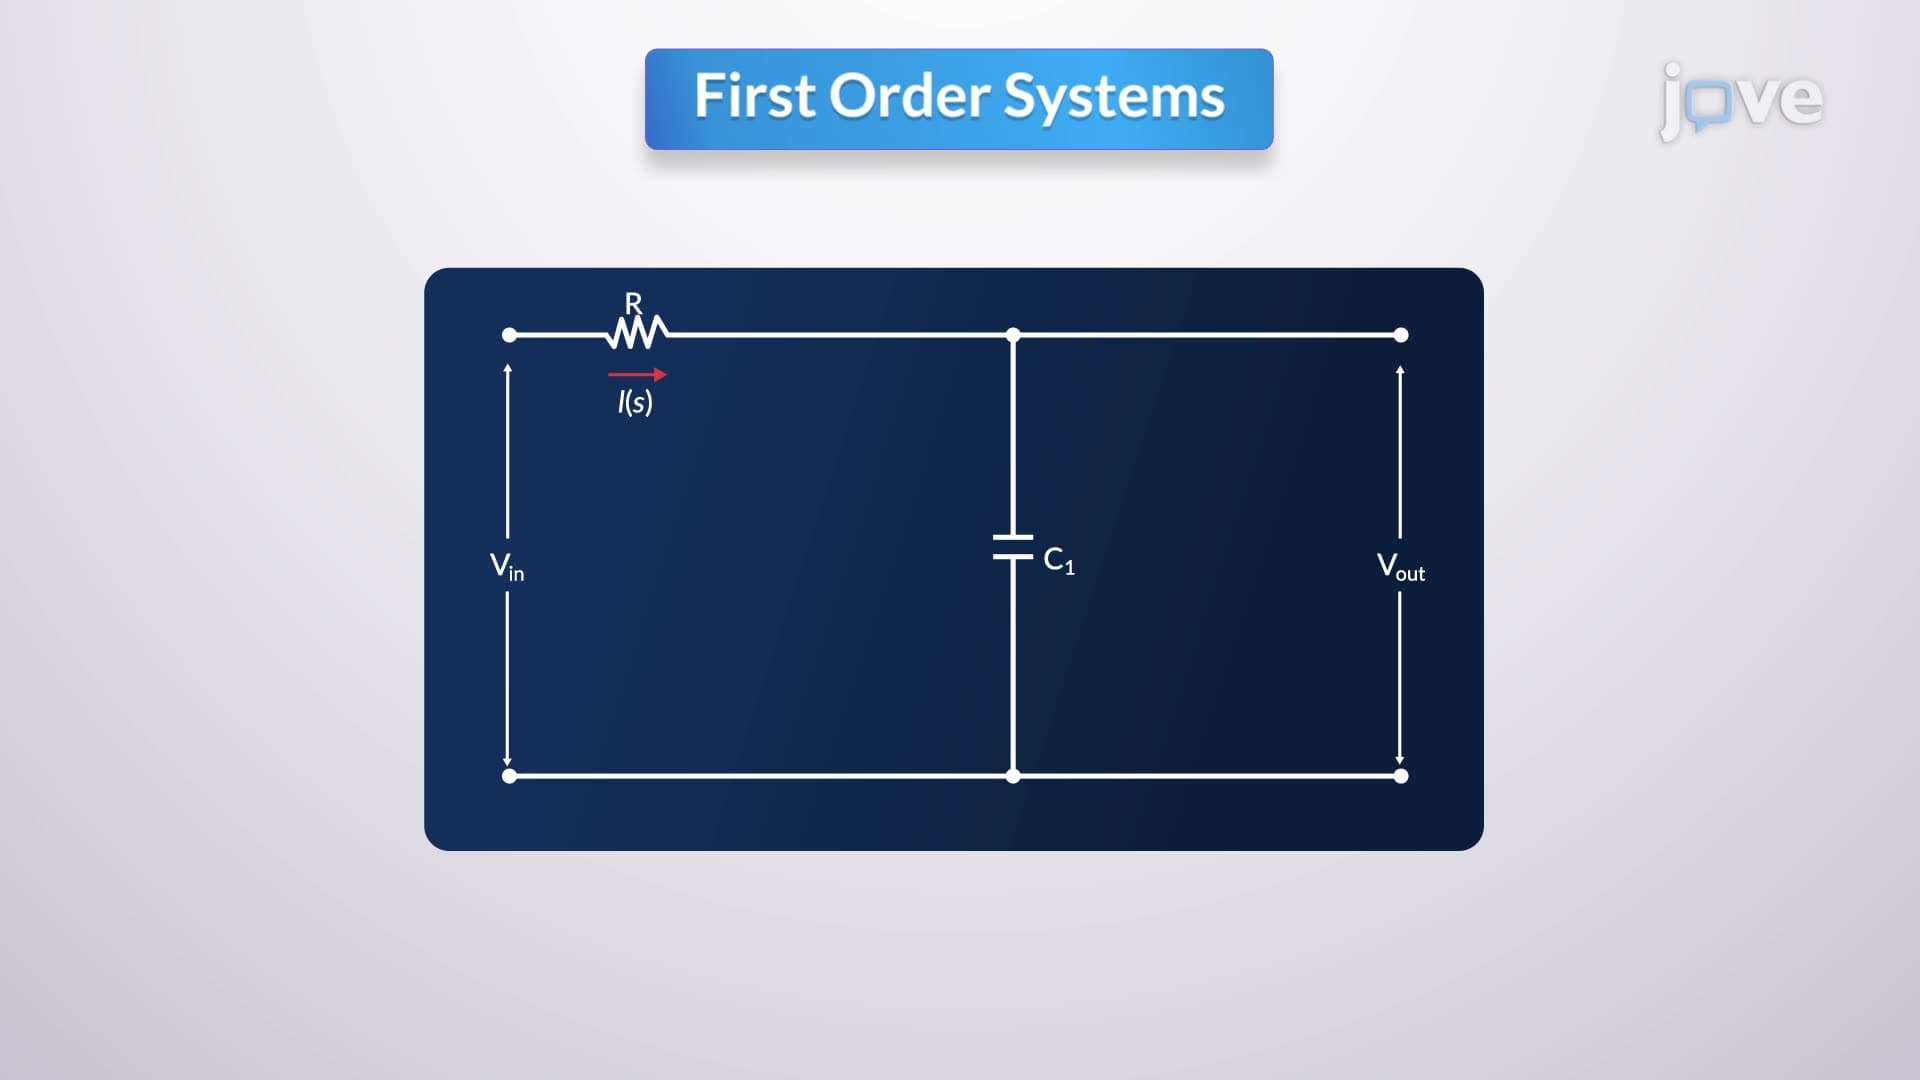
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
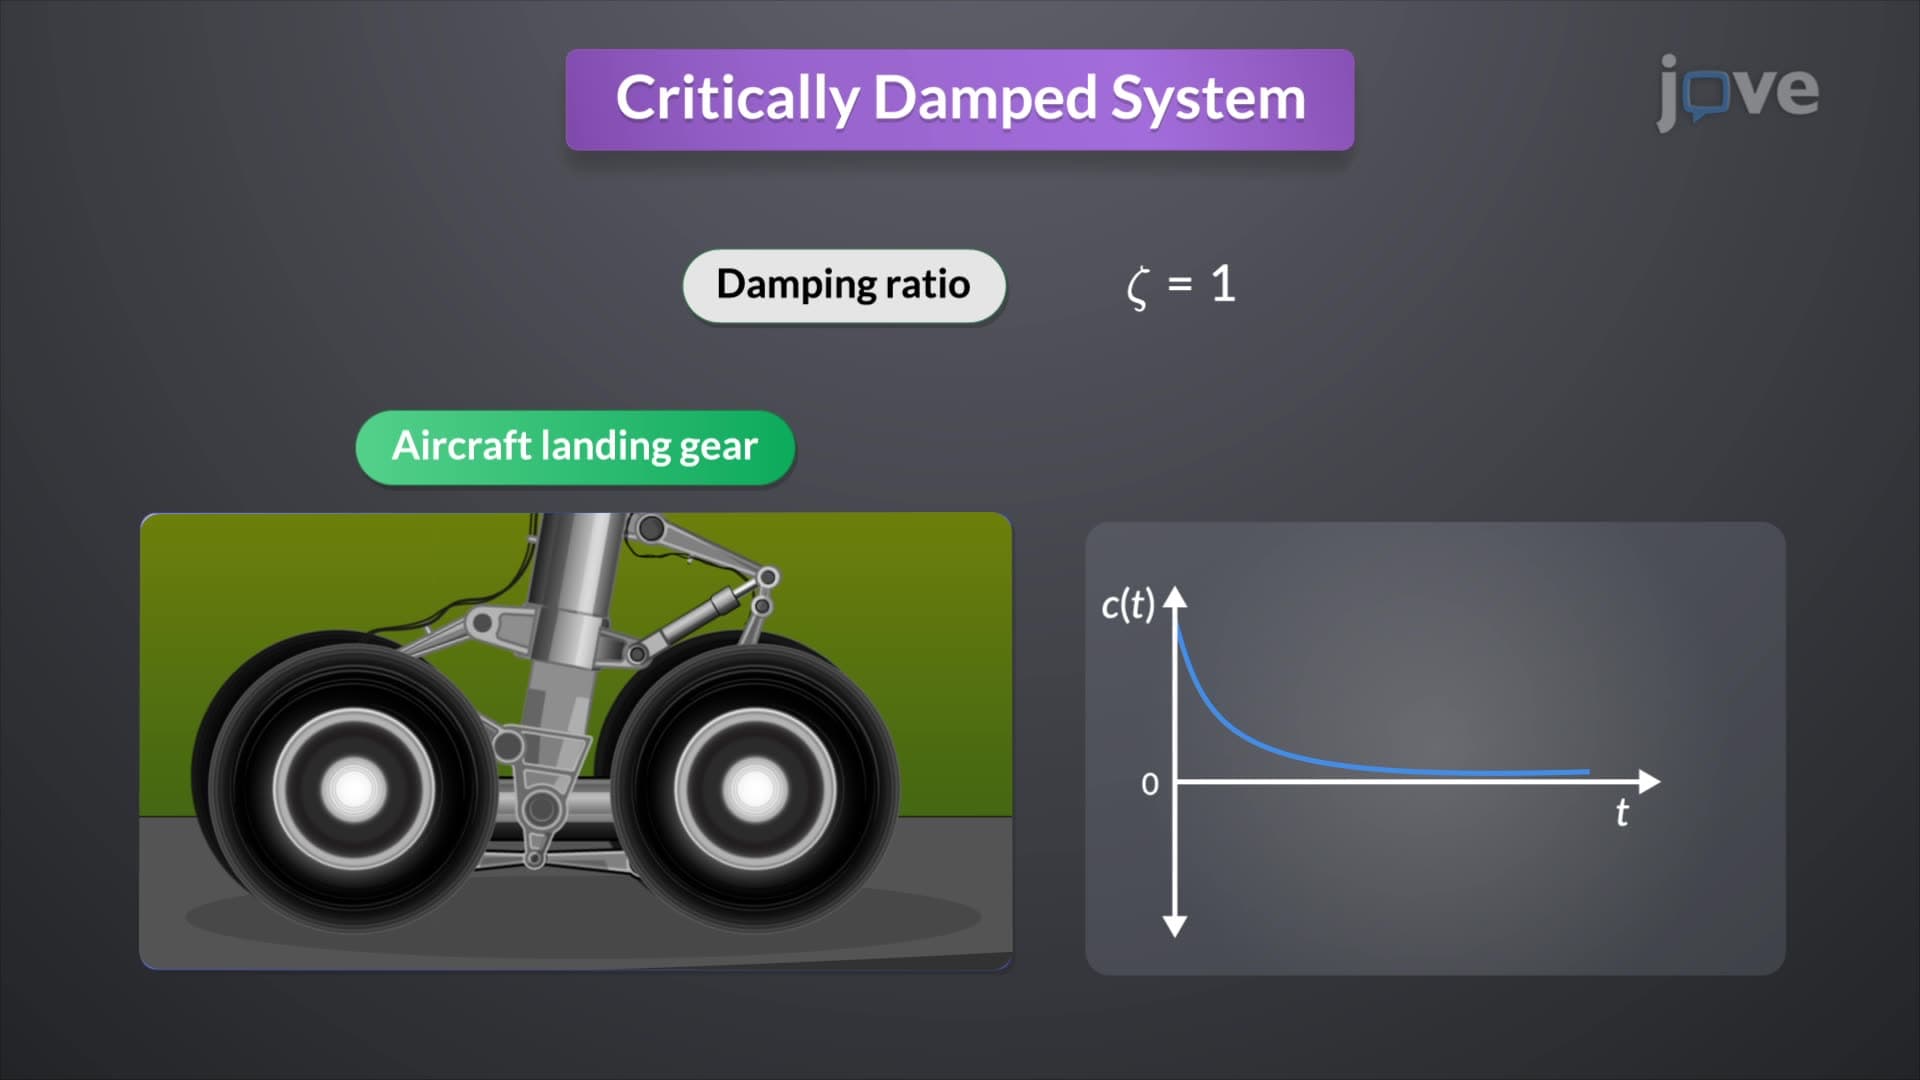
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...