Related Experiment Video
Updated: Jan 20, 2026


Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011
Continuous Collision Detection for Virtual Proxy Haptic Rendering of Deformable Triangular Mesh Models

Abstract:
Most haptic systems suffer from what is known as the "tunneling" problem, which arises when a virtual object moves or deforms largely towards a small virtual tool. This problem occurs because the displacement of the virtual object is not considered during collision detection and can be solved with Continuous Collision Detection (CCD). Originally, haptic rendering with CCD was proposed for applications with 6 Degrees-of-Freedom (DoF) only. However, 3-DoF is simple to use in, and sufficient for, many applications. In this paper, we focus on CCD with a 3-DoF point-object haptic rendering of dynamic and deformable objects. Since we use the virtual proxy method, we propose a triangle-proxy CCD approach with a complementary process called Proxy Pop-Out to solve this problem. The results show that we are able to solve the "tunneling" problem, even for a small proxy against thin and deformable objects with large motions. In addition, we present probing haptic interactions with deformable objects in a multi-rate haptic rendering system. By using Oriented Particles and Position Based Dynamics, our system is efficient and stable.
Related Concept Videos
 02:15
Sternberg's Triangular Theory of Love
 01:04
Types Of Collisions - I
 01:19
Types of Collisions - II
 01:19
Rectangular and Triangular Pulse Function
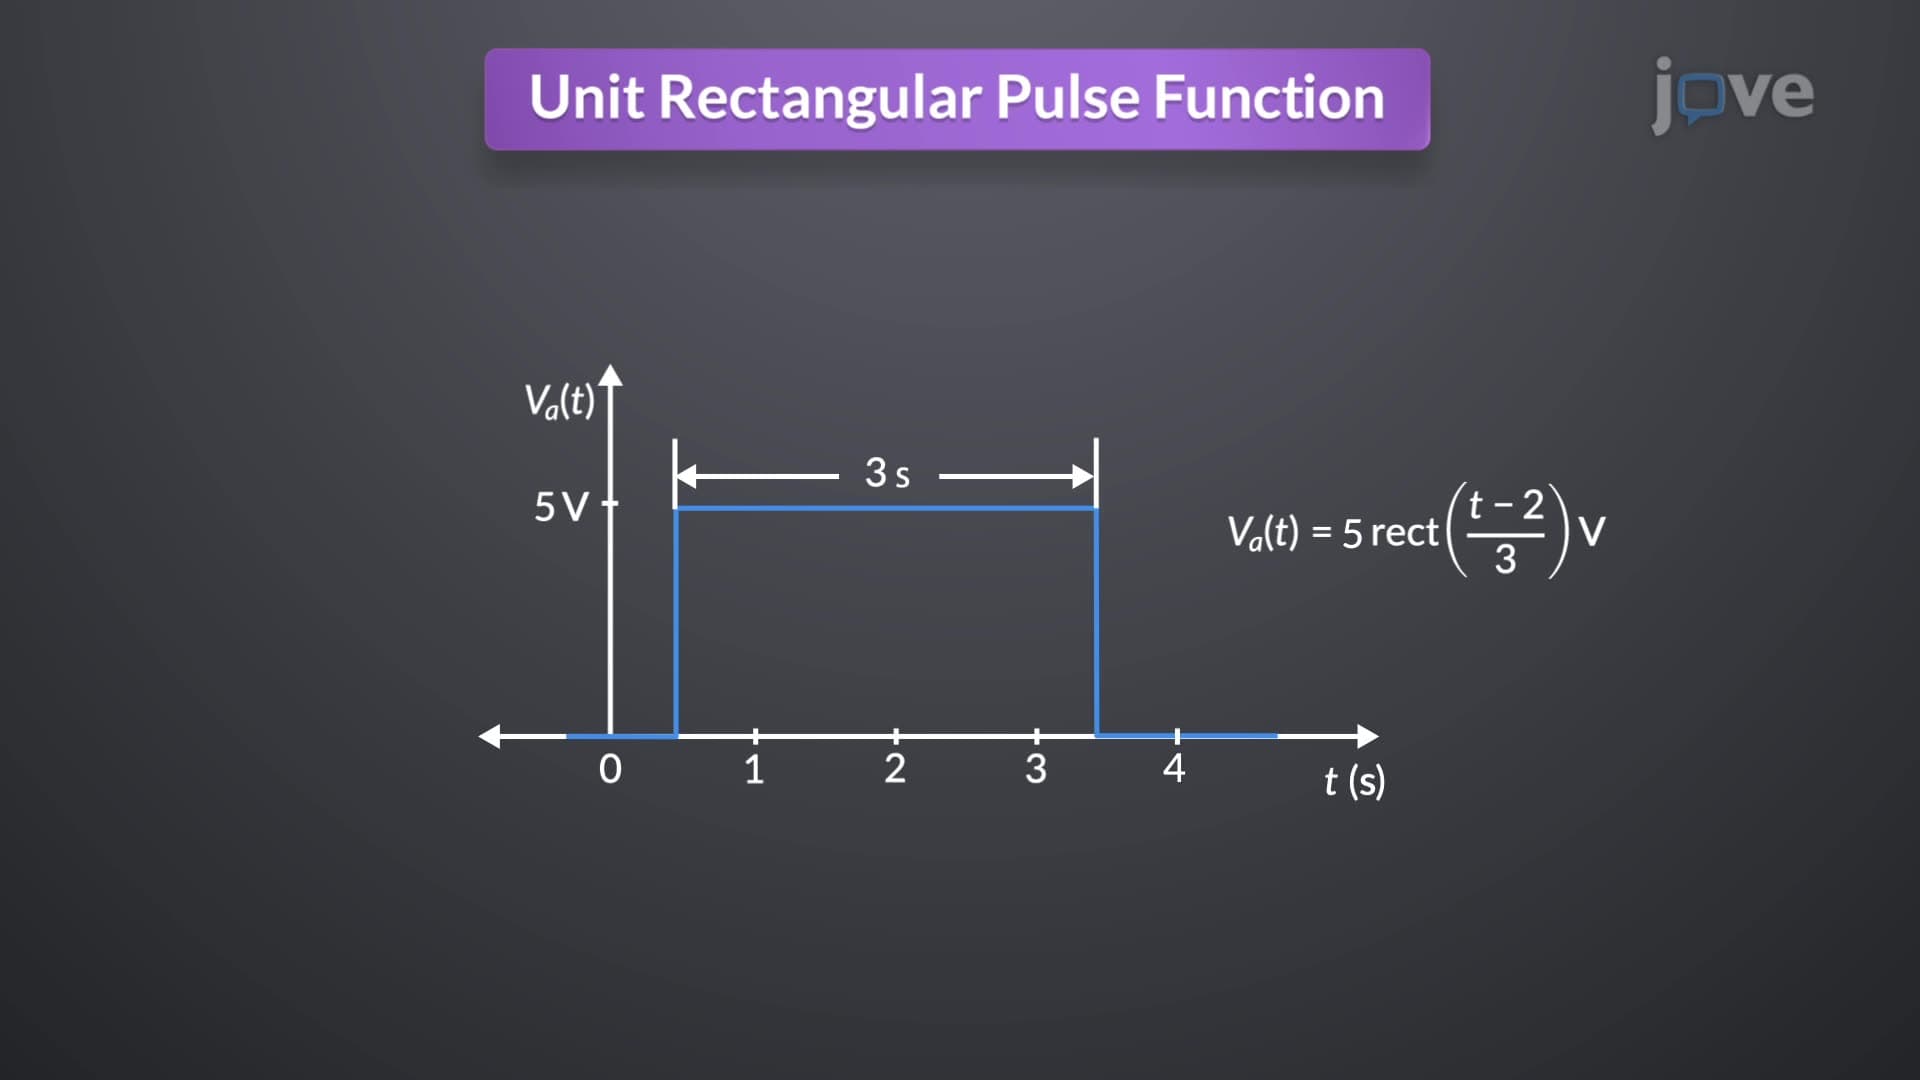
For example, consider a rectangular pulse with a 5V amplitude, a 3-second duration, and centered at t=2 seconds. This pulse can be expressed using the rectangular function, written as,
 01:20
Mesh Analysis
A fundamental concept in mesh analysis is the definition of meshes and mesh currents. A mesh is a closed...
 02:43
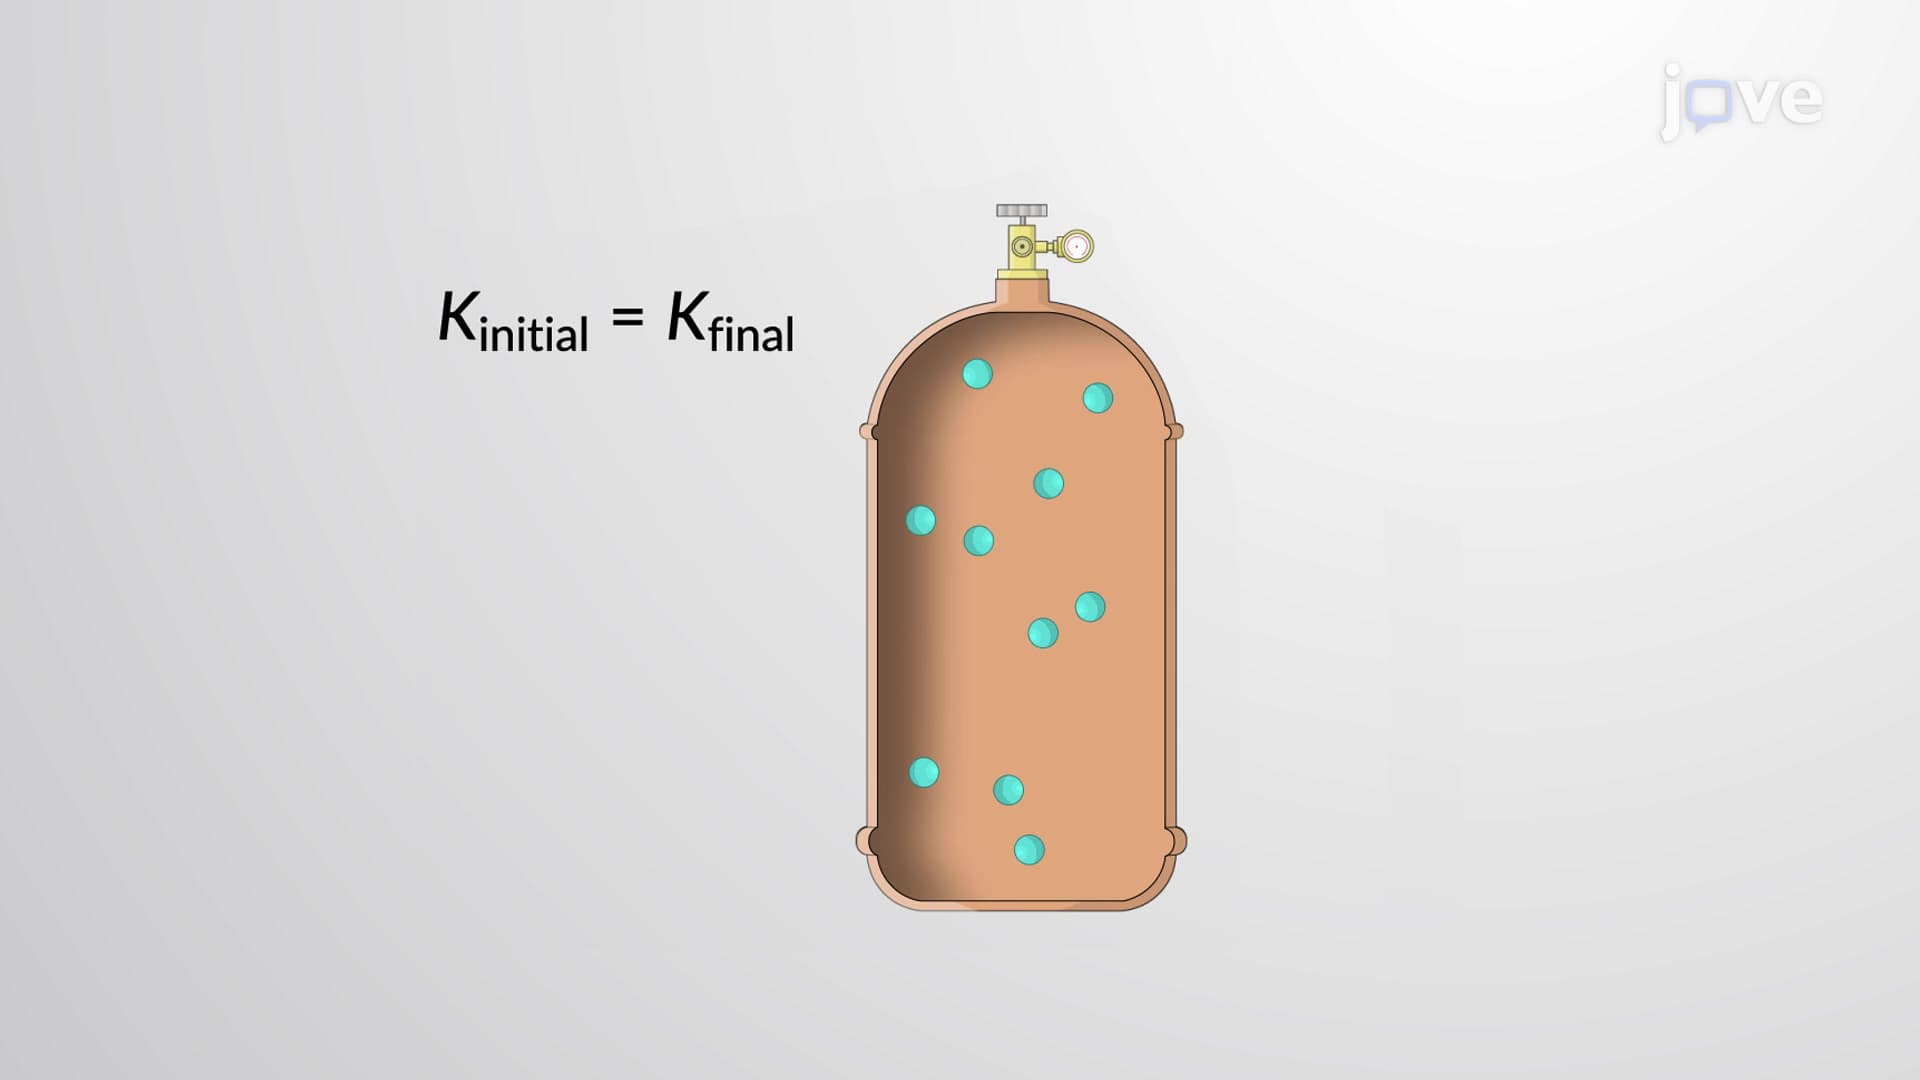
Basic Postulates of Kinetic Molecular Theory: Particle Size, Energy, and Collision