Related Experiment Video
Updated: Jan 20, 2026

A Neural Network-Based Identification of Developmentally Competent or Incompetent Mouse Fully-Grown Oocytes
Published on: March 3, 2018
Towards Model-Free Tool Dynamic Identification and Calibration Using Multi-Layer Neural Network
Hang Su1, Wen Qi2, Yingbai Hu3
1Dipartimento di Elettronica, Informazione e Bioingegneria, Politecnico di Milano, 20133 Milano, Italy.

Abstract:
In robot control with physical interaction, like robot-assisted surgery and bilateral teleoperation, the availability of reliable interaction force information has proved to be capable of increasing the control precision and of dealing with the surrounding complex environments. Usually, force sensors are mounted between the end effector of the robot manipulator and the tool for measuring the interaction forces on the tooltip. In this case, the force acquired from the force sensor includes not only the interaction force but also the gravity force of the tool. Hence the tool dynamic identification is required for accurate dynamic simulation and model-based control. Although model-based techniques have already been widely used in traditional robotic arms control, their accuracy is limited due to the lack of specific dynamic models. This work proposes a model-free technique for dynamic identification using multi-layer neural networks (MNN). It utilizes two types of MNN architectures based on both feed-forward networks (FF-MNN) and cascade-forward networks (CF-MNN) to model the tool dynamics. Compared with the model-based technique, i.e., curve fitting (CF), the accuracy of the tool identification is improved. After the identification and calibration, a further demonstration of bilateral teleoperation is presented using a serial robot (LWR4+, KUKA, Germany) and a haptic manipulator (SIGMA 7, Force Dimension, Switzerland). Results demonstrate the promising performance of the model-free tool identification technique using MNN, improving the results provided by model-based methods.
More Related Videos
 08:28
Assessment of the Effects of Endocrine Disrupting Compounds on the Development of Vertebrate Neural Network Function Using Multi-electrode Arrays
Published on: April 26, 2018
 13:40
Examining Local Network Processing using Multi-contact Laminar Electrode Recording
Published on: September 8, 2011
Related Concept Videos
 01:11
Glassware Calibration
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
 02:26
Protein Networks
These interactions can be represented through maps depicting protein-protein interaction networks, represented as nodes and edges. Nodes are circles that are representative of a protein,...
 02:18
Network Covalent Solids
To break or to melt a covalent network solid, covalent bonds must be broken. Because covalent bonds are relatively strong, covalent network solids are typically...
 01:12
Instrument Calibration
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...
 01:15
Theories of Dissolution: Diffusion Layer Model
This process starts with a thin layer, saturated with the drug, forming at the interface between the solid and liquid. The solute then diffuses from this layer into the main solution. The Noyes-Whitney equation suggests that the rate of dissolution relies on the diffusion...
 01:19
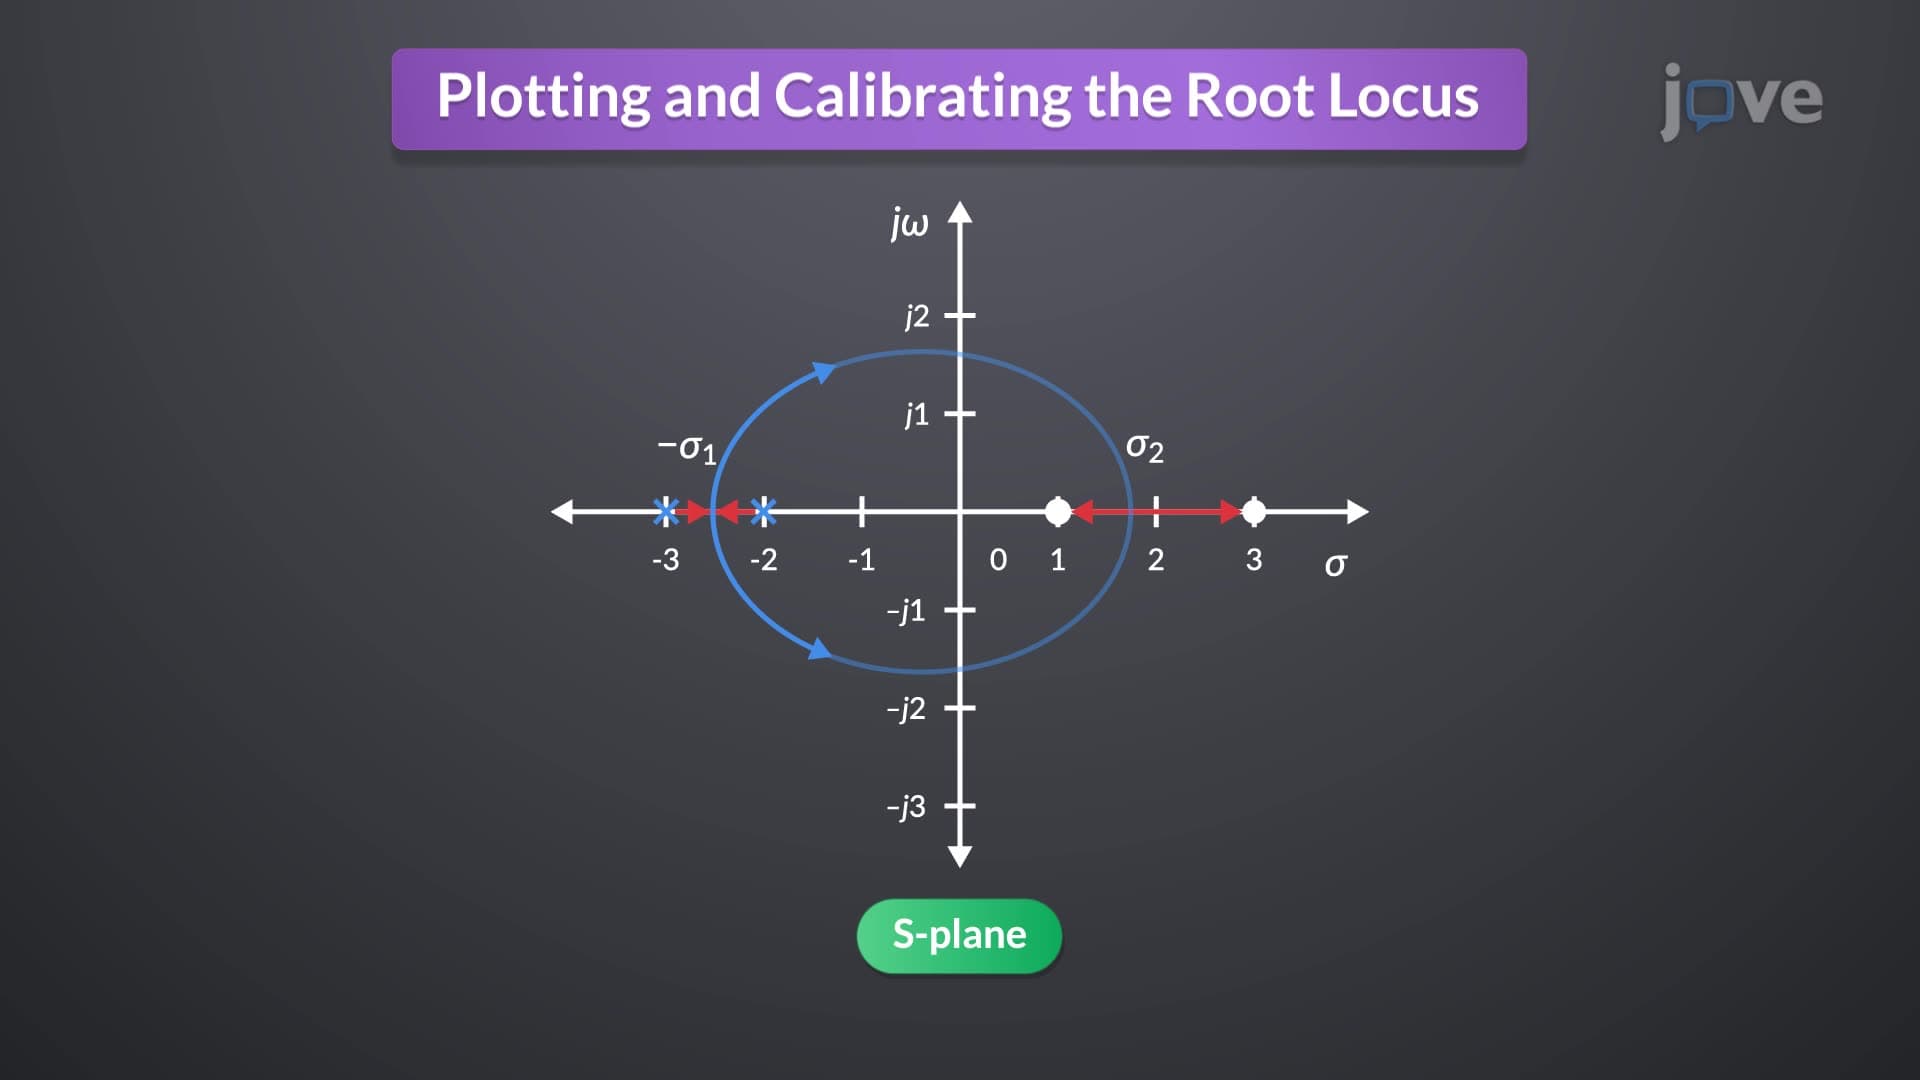
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...