Related Experiment Video
Updated: Jan 20, 2026

Author Spotlight: UAV Remote Sensing for Efficient Invasive Plant Biomass Estimation
Published on: February 9, 2024
Reliable Indoor Pseudolite Positioning Based on a Robust Estimation and Partial Ambiguity Resolution Method
Xin Li1, Guanwen Huang1, Peng Zhang2
1College of Geology Engineering and Geomantic, Chang'an University, Xi'an 710054, China.

Abstract:
The unscented Kalman filter (UKF) can effectively reduce the linearized model error and the dependence on initial coordinate values for indoor pseudolite (PL) positioning unlike the extended Kalman filter (EKF). However, PL observations are prone to various abnormalities because the indoor environment is usually complex. Standard UKF (SUKF) lacks resistance to frequent abnormal observations. This inadequacy brings difficulty in guaranteeing the accuracy and reliability of indoor PL positioning, especially for phase-based high-precision positioning. In this type of positioning, the ambiguity resolution (AR) will be difficult to achieve in the presence of abnormal observations. In this study, a robust UKF (RUKF) and partial AR (PAR) algorithm are introduced and applied in indoor PL positioning. First, the UKF is used for parameter estimation. Then, the anomaly recognition statistics and optimal ambiguity subset of PAR are constructed on the basis of the posterior residuals. The IGGIII scheme is adopted to weaken the influence of abnormal observation, and the PAR strategy is conducted in case of failure of the conventional PL-AR. The superiority of our proposed algorithm is validated using the measured indoor PL data for code-based differential PL (DPL) and phase-based real-time kinematic (RTK) positioning modes. Numerical results indicate that the positioning accuracy of RUKF-based indoor DPL is higher with a decimeter-level improvement compared that of the SUKF, especially in the presence of large gross errors. In terms of high-precision RTK positioning, RUKF can correctly identify centimeter-level anomalous observations and obtain a corresponding positioning accuracy improvement compared with the SUKF. When relatively large gross errors exist, the conventional method cannot easily realize PL-AR. By contrast, the combination of RUKF and the PAR algorithm can achieve PL-AR for the selected ambiguity subset successfully and can improve the positioning accuracy and reliability significantly. In summary, our proposed algorithm has certain resistance ability for abnormal observations. The indoor PL positioning of this algorithm outperforms that of the conventional method. Thus, the algorithm has some practical application value, especially for kinematic positioning.
Related Concept Videos
 01:29
Reliability and Validity
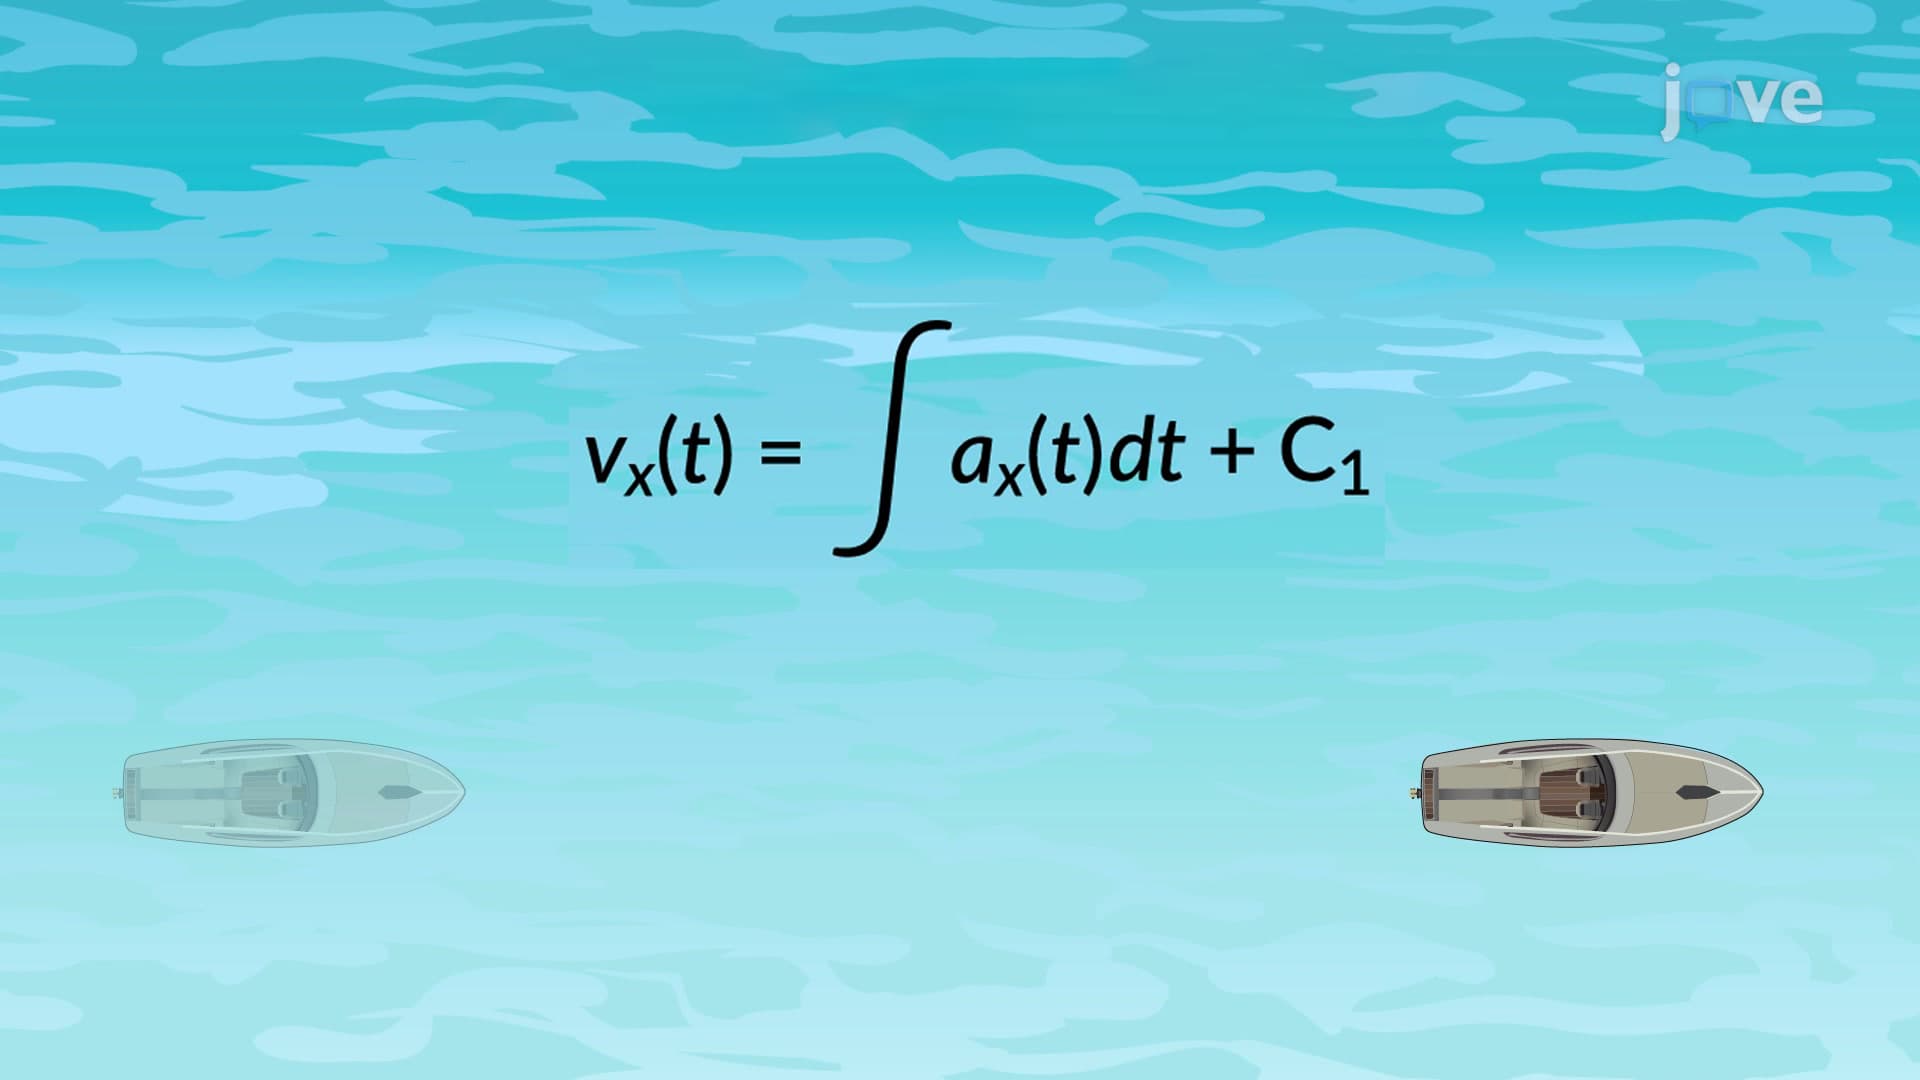 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:34
Velocity and Position by Graphical Method
 02:05
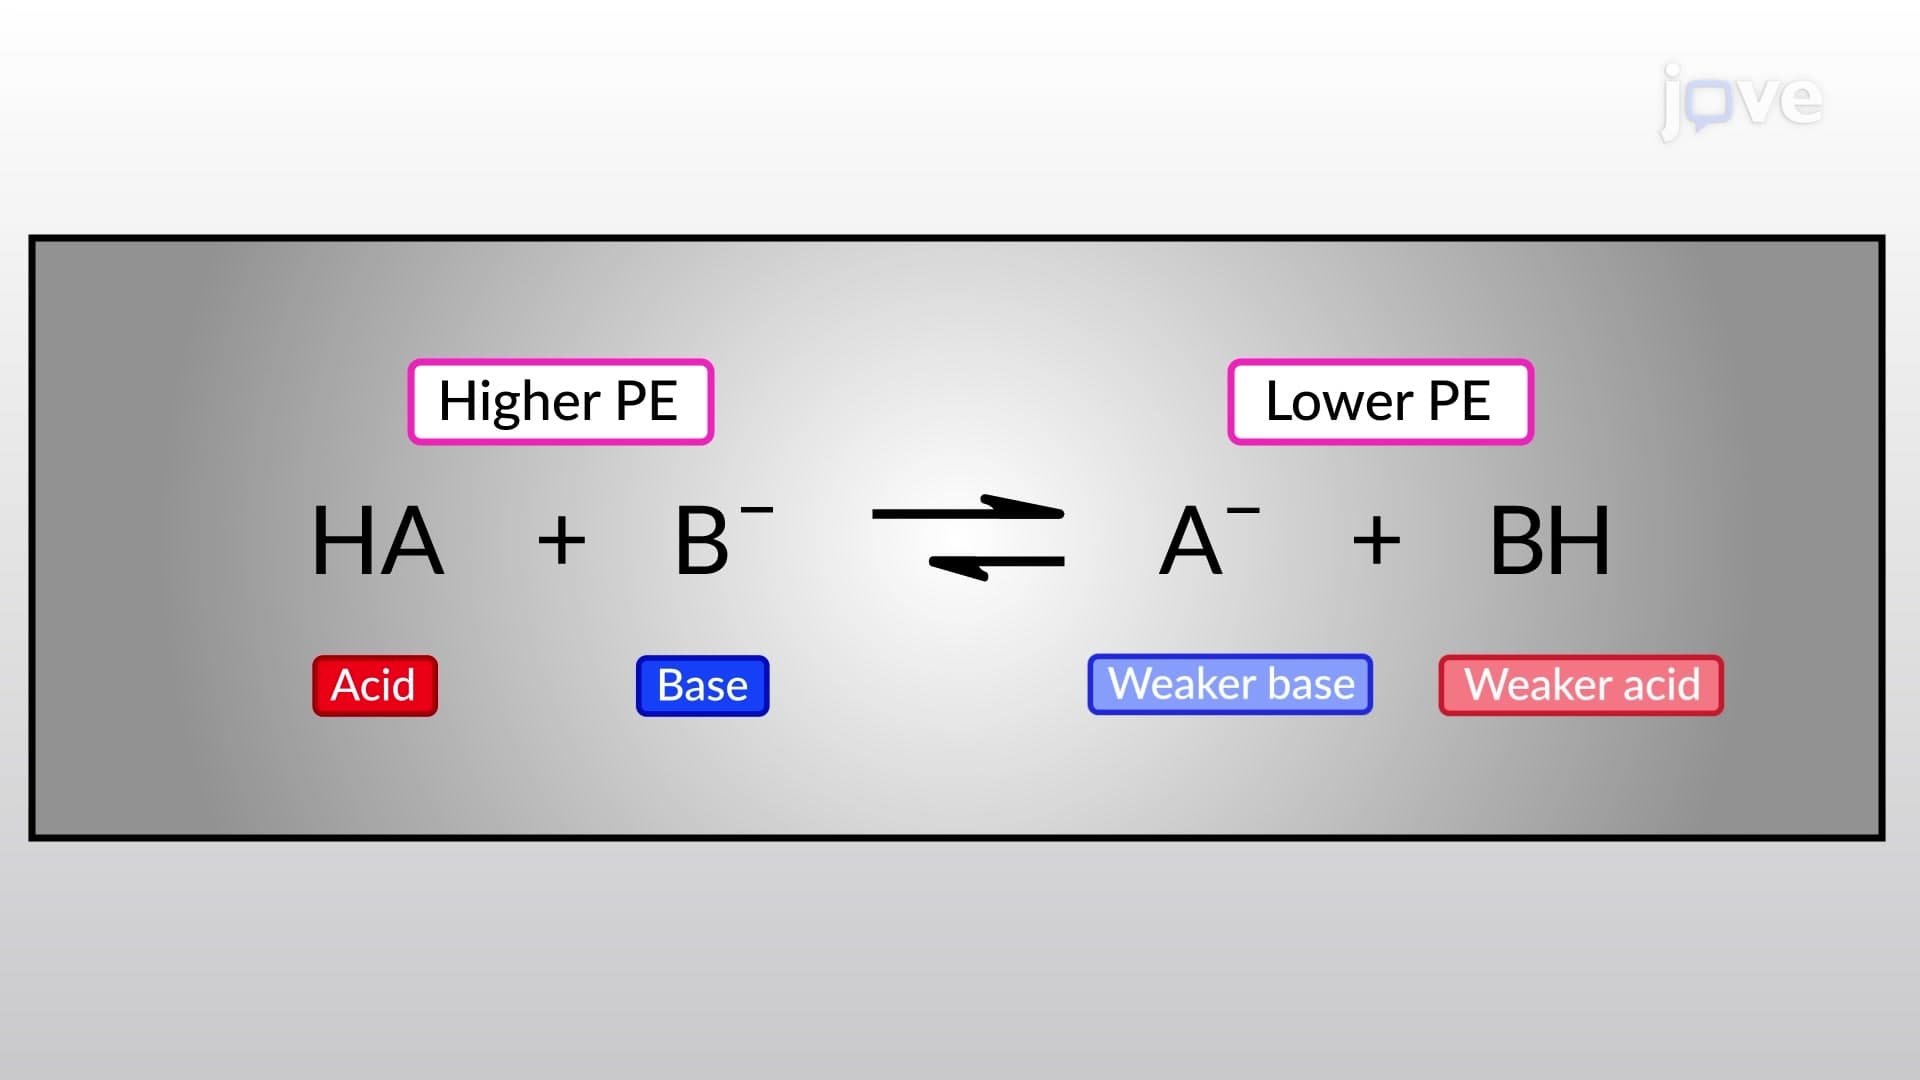
Position of Equilibrium in Acid-Base Reactions
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 02:32
Position-effect Variegation