Related Experiment Video
Updated: Jan 20, 2026

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Stability Control and Turning Algorithm of an Alpine Skiing Robot
Si-Hyun Kim1, Bumjoo Lee2, Young-Dae Hong3
1Department of Electrical and Computer Engineering, Ajou University, Suwon 16499, Korea.

Abstract:
This paper proposes a general stability control method that uses the concept of zero-moment-point (ZMP) and a turning algorithm with a light detection and ranging (LiDAR) sensor for a bipedal alpine skiing robot. There is no elaborate simulator for skiing robots since the snow has complicated characteristics, such as compression and melting. However, real experiments are laborious because of the many varied skiing conditions. The proposed skiing simulator could be used, so that a humanoid robot can track its desired turning radius by modeled forces that are similar to real ones in the snow. Subsequently, the robot will be able to pass through gates with LiDAR sensors. By using ZMP control, the robot can avoid falling down while tracking its desired path. The performance of the proposed stabilization method and autonomous turning algorithm are verified by a dynamics simulation software, Webots, and the simulation results are obtained while using the small humanoid robot platform DARwIn-OP.


Related Concept Videos
 03:18
Nuclear Stability
To hold positively charged protons together...
 01:53
RNA Stability
 01:12
Trial and Error and Algorithm
 01:28
Stability
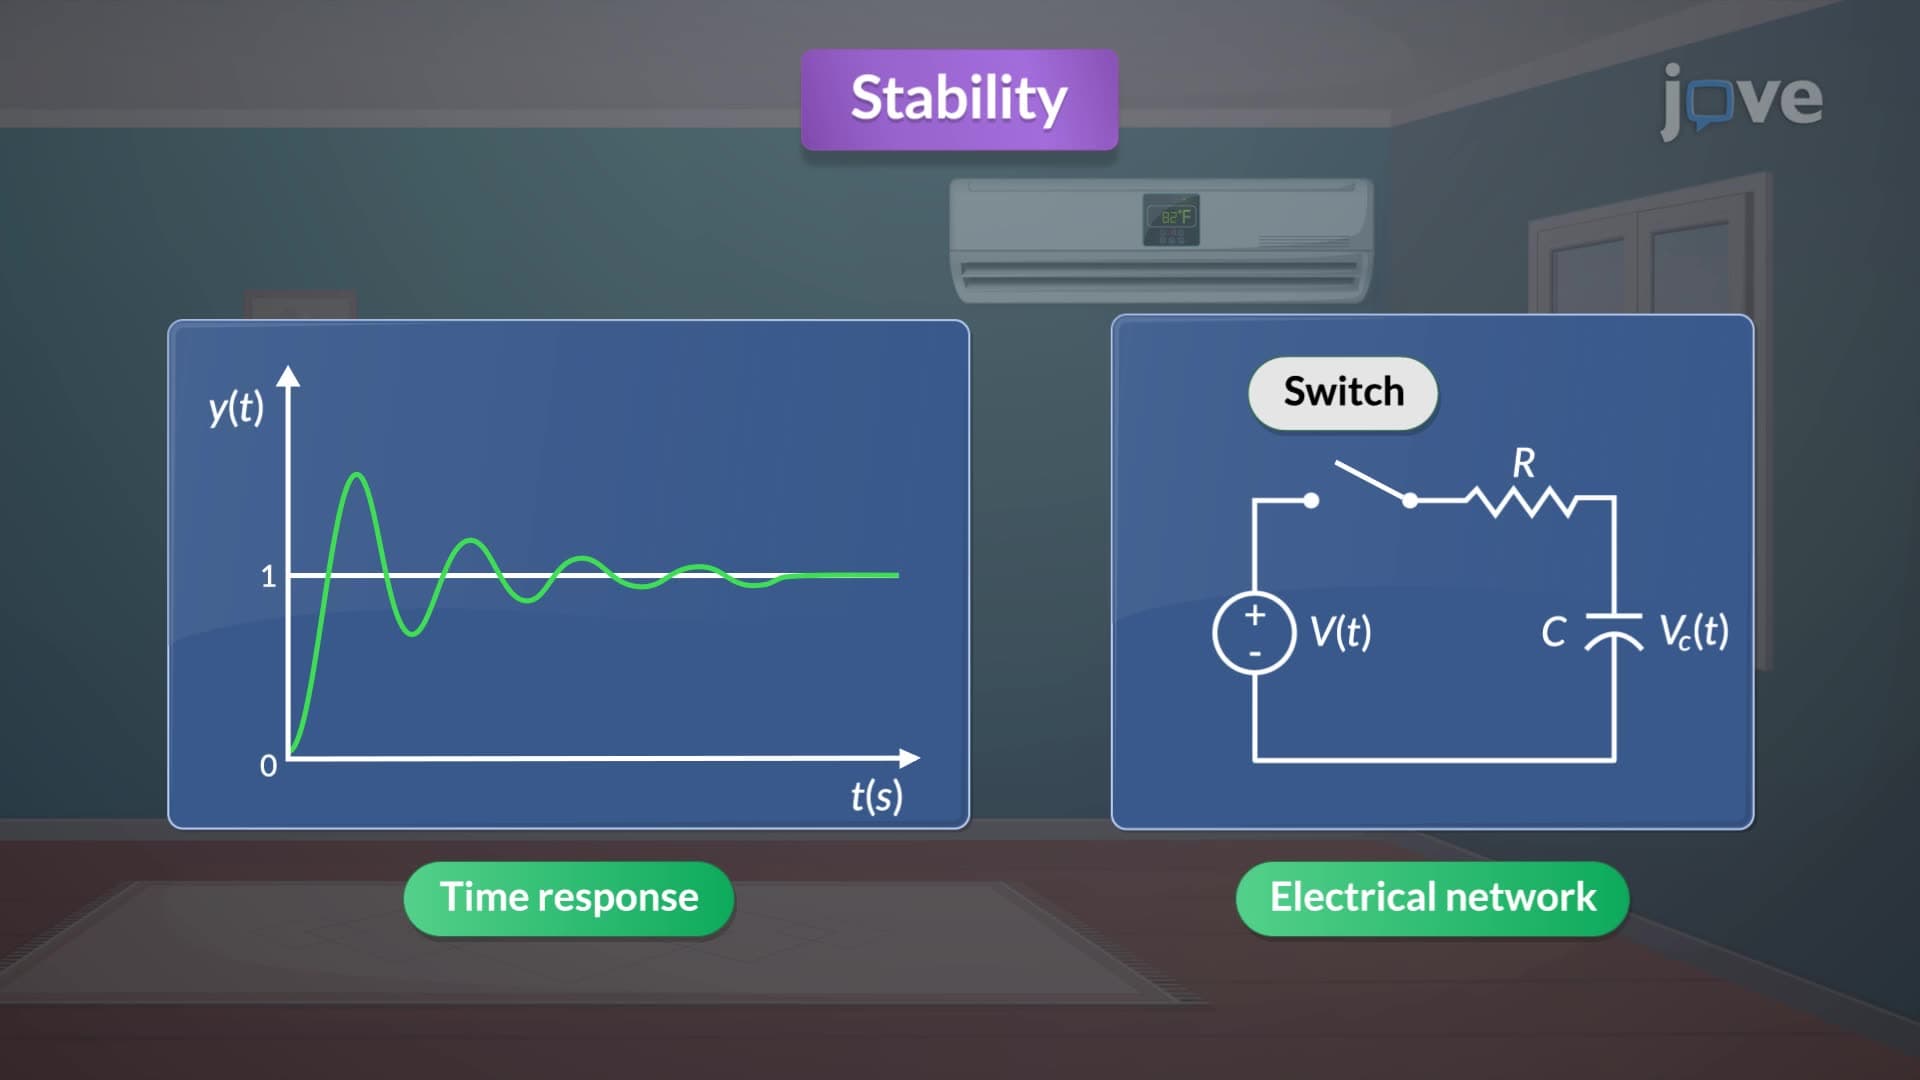
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:14
Stability of structures
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...