Related Experiment Video
Updated: Jan 20, 2026
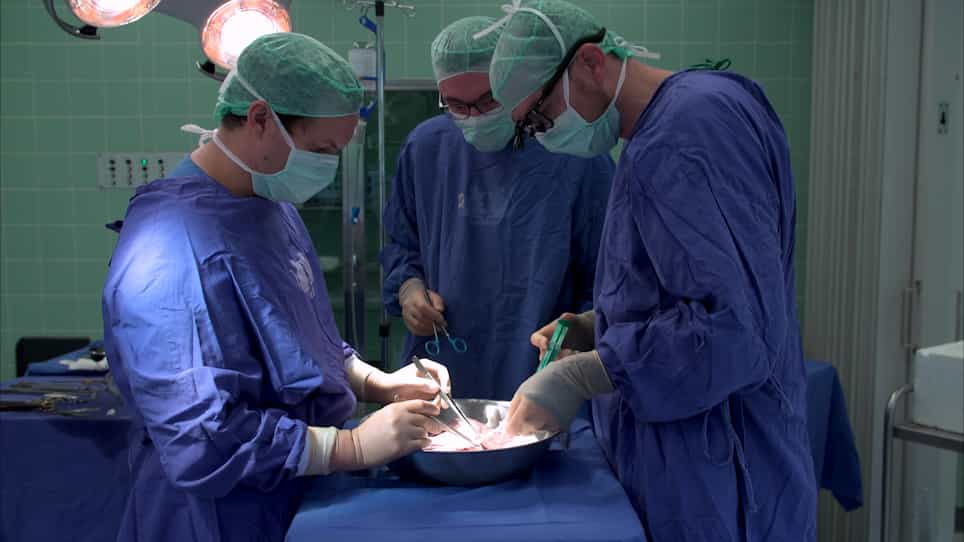

Porcine Liver Transplantation Without Veno-Venous Bypass As an Extended Criteria Donor Model
Published on: August 17, 2022
Simulation and navigation of living donor hepatectomy using a unique three-dimensional printed liver model with soft
Shintaro Kuroda1, Takuya Kihara2, Yurina Akita3
1Department of Gastroenterological and Transplant Surgery, Hiroshima University Hospital, 1-2-3, Kasumi, Hiroshima, 734-8551, Japan. shintarokuroda@hiroshima-u.ac.jp.

Abstract:
Three-dimensional printed liver models have been used for preoperative simulation. Unlike the standard three-dimensional system on a monitor, the three-dimensional printed model can be observed from any angle manually; therefore, surgeons can obtain a clear image directly from the model. We herein report the use of a unique three-dimensional liver model with a soft and transparent liver parenchyma. Through the parenchyma, the surgeons can observe the intrahepatic vessels and perform incisions in the model as a preoperative simulation. In this study, we applied this model to donor hepatectomy, which under most circumstances requires meticulous attention to detail. The actual processes and uses of a three-dimensional liver model in clinical surgery for liver transplantation are presented.
Related Concept Videos
 12:49
Porcine Liver Transplantation Without Veno-Venous Bypass As an Extended Criteria Donor Model
 09:44
Generation of a Rat Model of Acute Liver Failure by Combining 70% Partial Hepatectomy and Acetaminophen
 05:37
Partial Lobular Hepatectomy: A Surgical Model for Morphologic Liver Regeneration
 05:43
Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
 05:27
Laparoscopic Anatomical Hepatectomy Using Takasaki's Approach and Indocyanine Green Fluorescence Navigation
 03:23
Fluorescent Laparoscopic Central Hepatectomy for Liver Cancer Using Indocyanine Green Negative Staining