Related Experiment Video
Updated: Jan 19, 2026

Principle, Conservation and Measurement of Angular Momentum
Published on: April 30, 2023
Circumnavigation on Multiple Circles Around a Nonstationary Target With Desired Angular Spacing

Abstract:
In this article, the objective for a group of nonholonomic agents is to achieve multicircular circumnavigation with any desired angular spacing around a nonstationary target. A cooperative protocol is proposed to achieve this objective and, additionally, generalizes the circumnavigation problem of unicycle vehicles around a target (moving and stationary). Due to the nonholonomic constraints, existing protocols cannot be extended directly to achieve this objective. Thus, the proposed algorithm is worked out from the desired geometry to achieve the objective. A fixed-time consensus estimator is designed under a cyclic digraph to arrive at the desired interagent angular separation in the target-centric frame. The target information and desired formation parameters are assumed to be known to only one agent partially. Due to uncertainty in the target's motion, it is assumed that the target's acceleration and angular velocity are unknown. Fixed-time estimators under a digraph address the lack of information. The tracking controller drives the agents to the desired position around the target, thus making the errors go to zero instead of any finite bounds. The controller guarantees the bounded control effort irrespective of the error magnitude. The numerical examples are presented to show the effectiveness of the algorithm.
Related Concept Videos
 09:33
Angular Momentum
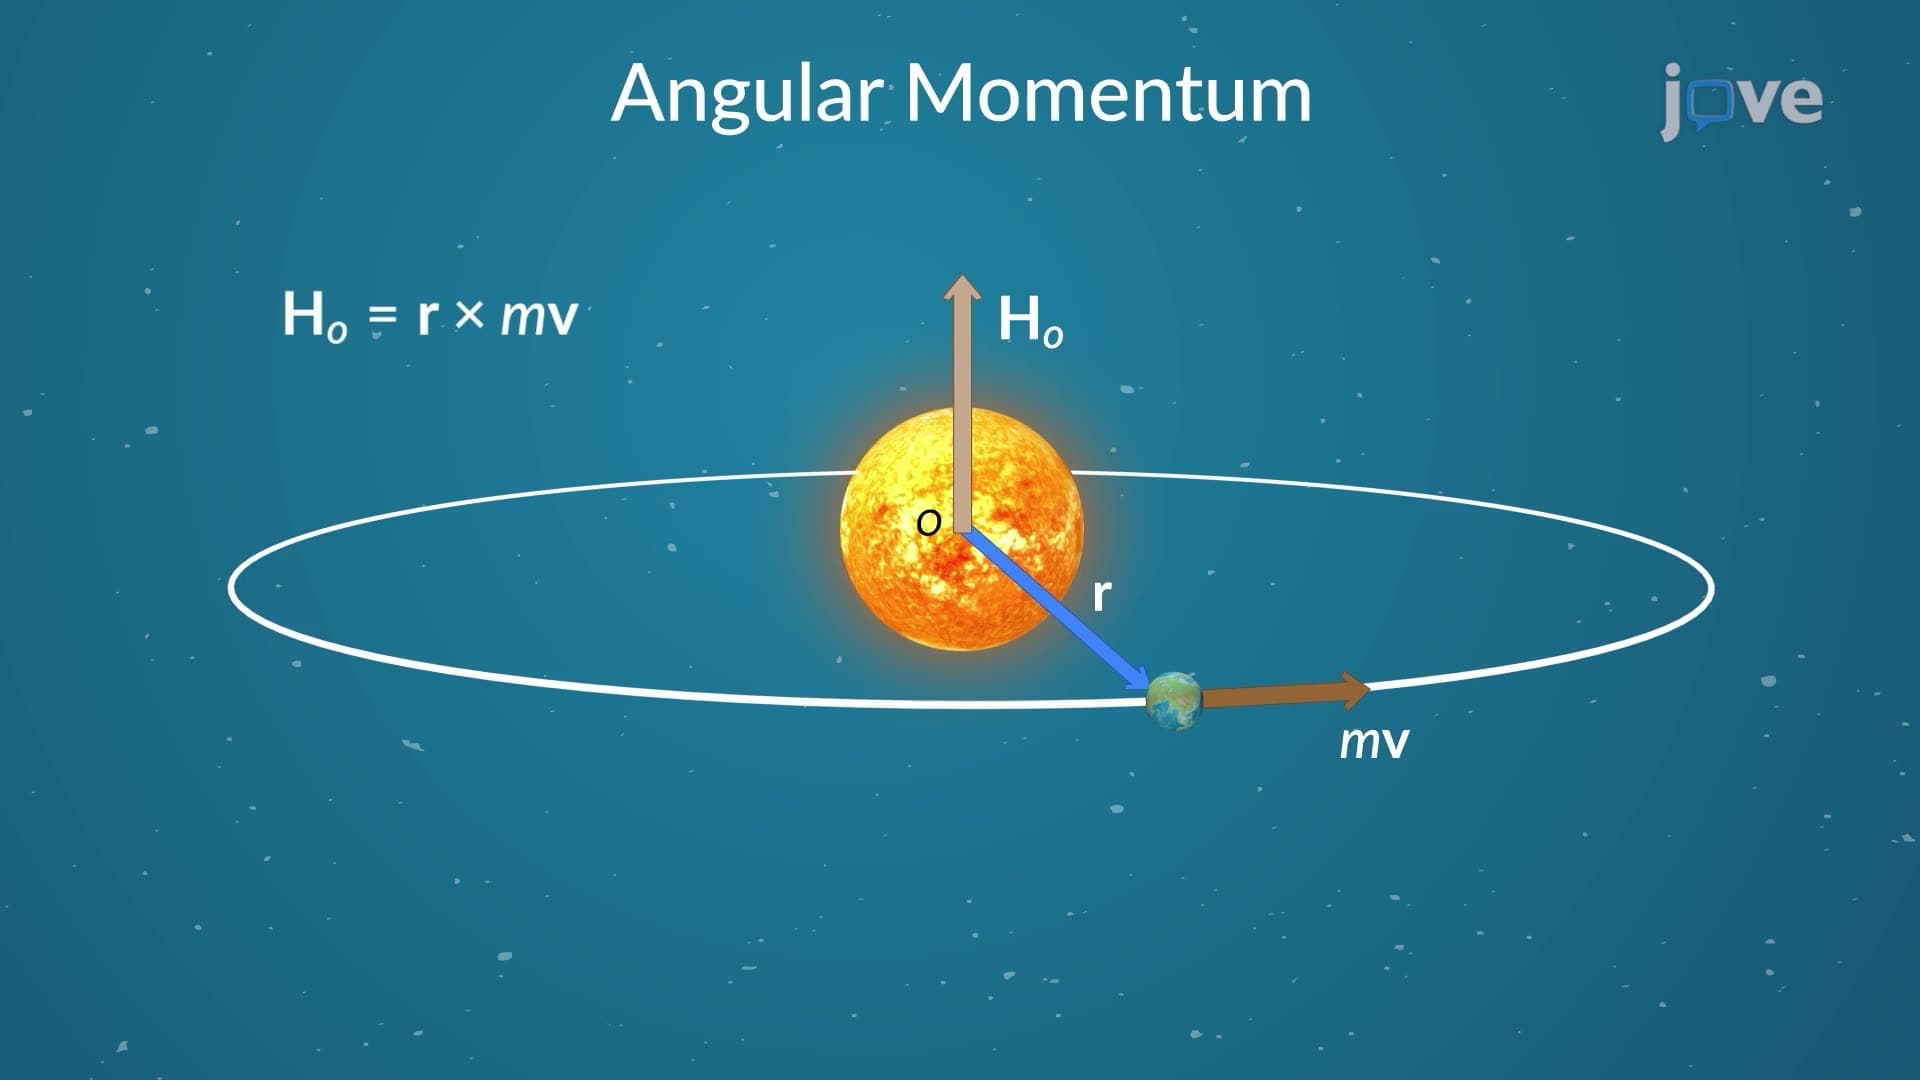 01:21
Angular Momentum
 08:23
CIRCLE-Seq for Interrogation of Off-Target Gene Editing
 01:26
Desirable Characteristics in Others
 01:14
Needs, Wants, Desires
Conversely, wants are the goods or services that individuals require beyond their basic needs. These are shaped by a person's...
 01:08
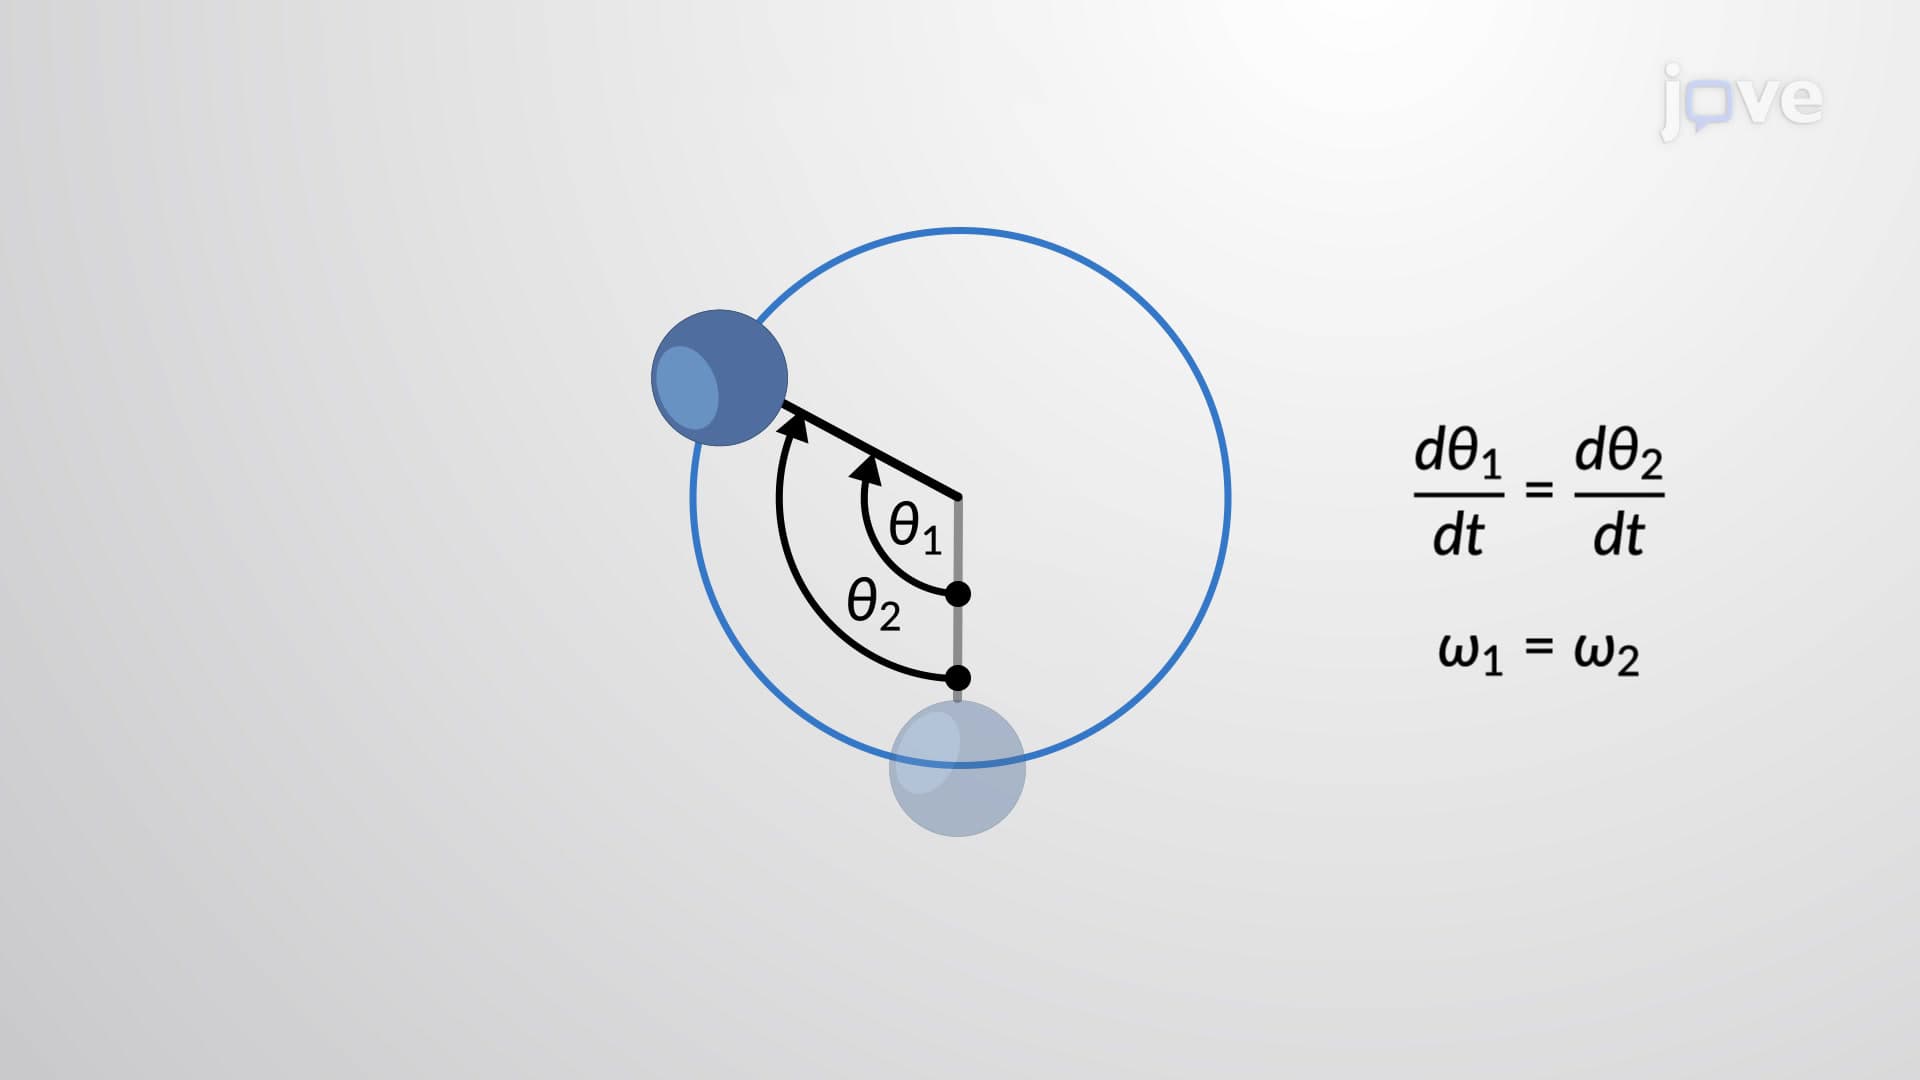
Angular Velocity and Displacement