Related Experiment Video
Updated: Jan 19, 2026
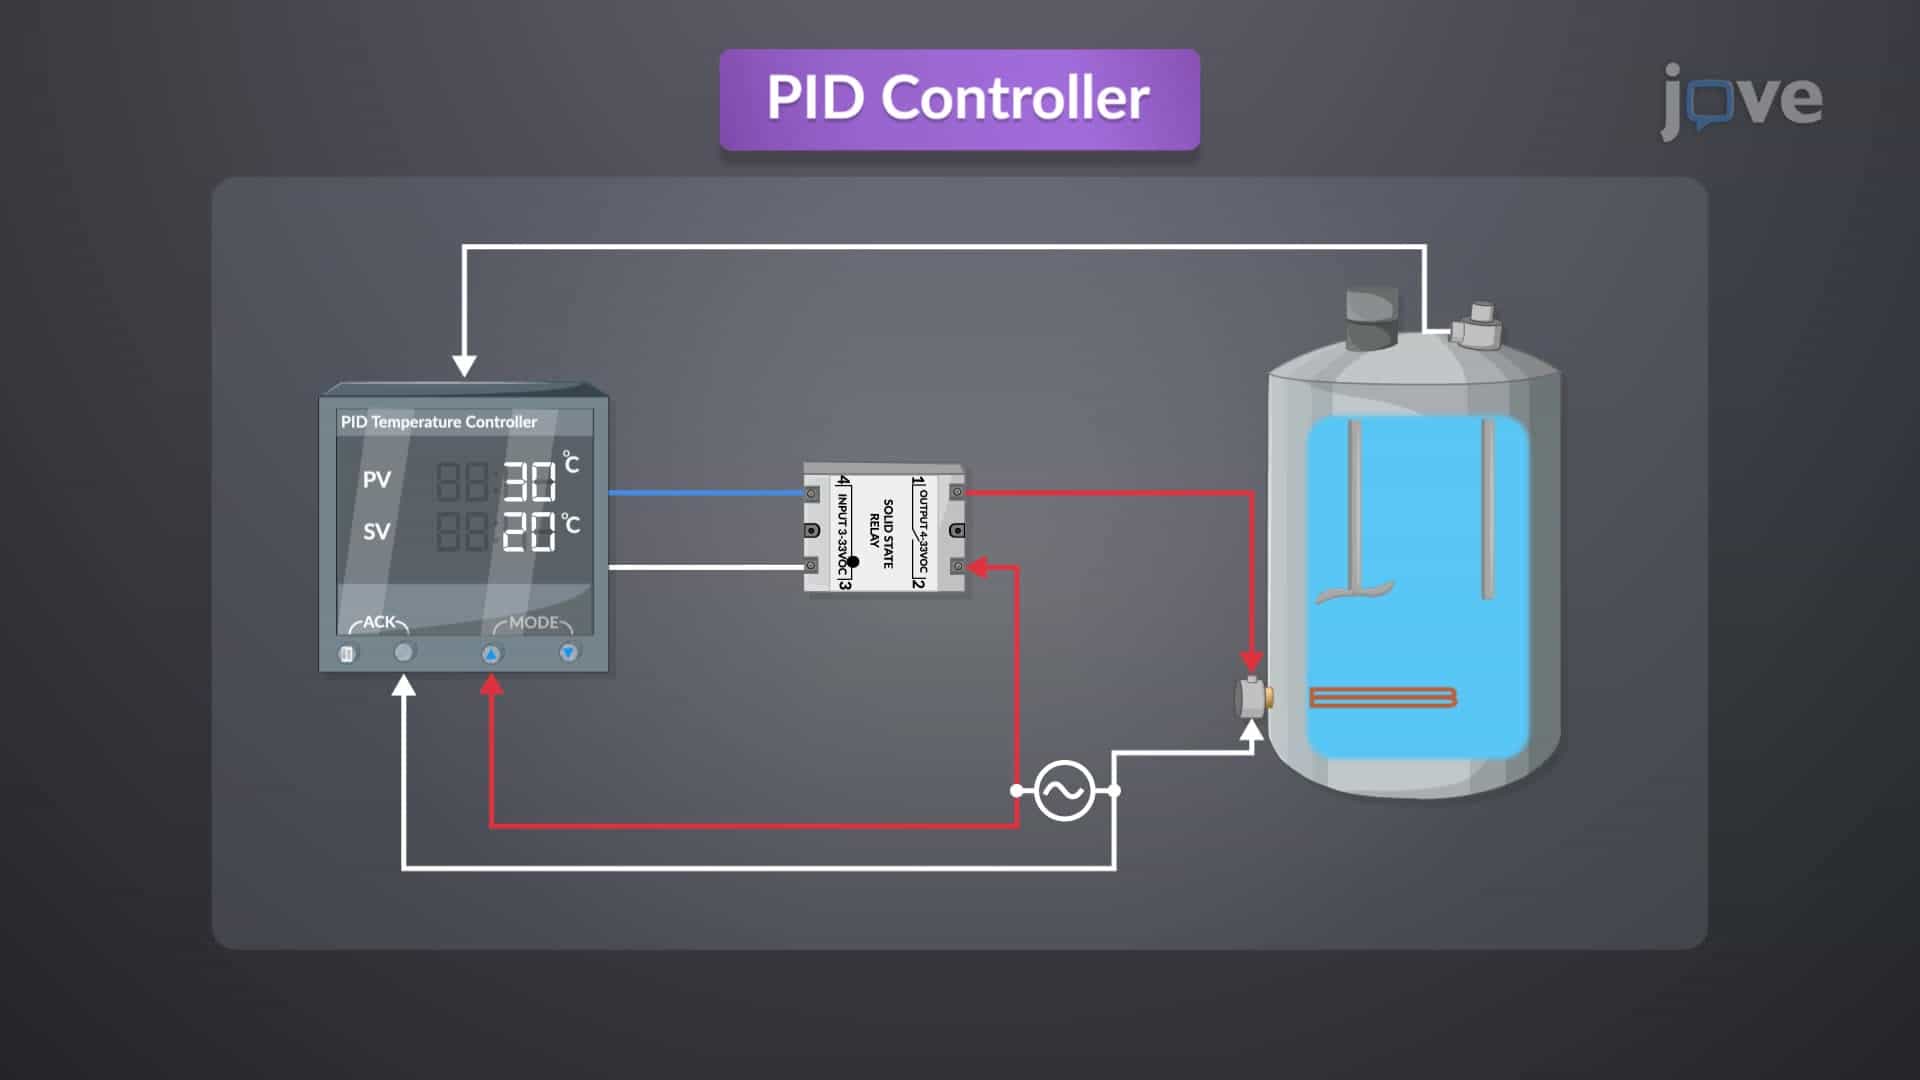

PID Controller
Robust PID control of quadrotors with power reduction analysis
Roger Miranda-Colorado1, Luis T Aguilar2
1CONACyT-Instituto Politécnico Nacional-CITEDI, Av. Instituto Politécnico Nacional No. 1310, Nueva Tijuana, Tijuana, Baja California, 22435, Mexico.

Abstract:
This paper presents a novel robust controller applied to a quadrotor vehicle for regulation and trajectory tracking tasks. In the proposed scheme, the quadrotor position is controlled by a proportional integral derivative (PID) controller, while the orientation control is achieved through a model-based controller. The proposed controller is combined with a power reduction methodology, which includes a controller-gains tuning stage using the cuckoo search algorithm, and a minimum jerk trajectory design stage. The performance of the new controller is assessed in a free-disturbance case and under the effect of parametric uncertainty and aero-dynamical disturbances. The new controller is compared against two linear PID controllers and a nonlinear sliding mode-based controller. Numerical simulations demonstrate the superiority of the proposed scheme as well as its robustness against different types of perturbations. Also, it is proven that the power demanded by any controller is reduced when using the power reduction methodology.

Related Concept Videos
 01:19
PID Controller
 01:30
Control of Power Flow
 08:55
Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
 03:11
Oxidation-Reduction Reactions
 01:08
Power
 10:03
Rapid and Robust Analysis of Cellular and Molecular Polarization Induced by Chemokine Signaling