Related Experiment Video
Updated: Jan 19, 2026
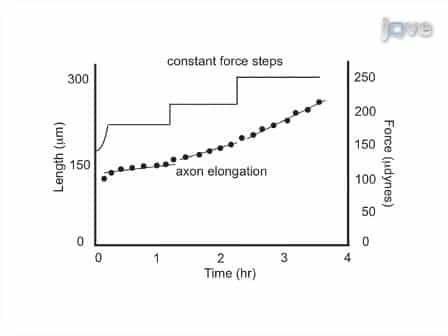

Mechanical Manipulation of Neurons to Control Axonal Development
Published on: April 10, 2011
Model-free continuous nonsingular fast terminal sliding mode control for cable-driven manipulators
Yaoyao Wang1, Kangwu Zhu2, Bai Chen1
1National Key Laboratory of Science and Technology on Helicopter Transmission, Nanjing University of Aeronautics and Astronautics, Nanjing 210016, China.

Abstract:
This work proposes a model-free robust control for cable-driven manipulators with disturbance. To achieve accurate, singularity-free and fast dynamical control performance, we design a new NFTSM surface utilizing a new continuous TSM-type switch element. By replacing the integral power with fractional one for the error dynamics, the designed TSM-type switch element can effectively enhance the dynamical performance of the NFTSM surface. Time-delay estimation (TDE) technique is applied to cancel out complicated nonlinear dynamics guaranteeing an excellent model-free scheme. Thanks to the designed NFTSM surface, adopted reaching law and TDE, our control can provide good comprehensive control performance effectively. Stability and comparisons of control precision and convergence speed have been theoretically analyzed. Finally, comparative experiments were conducted to prove the superiorities of our control.
Related Concept Videos
 01:29
Cable: Problem Solving
 10:02
Mechanical Manipulation of Neurons to Control Axonal Development
 08:13
Microwave-driven Synthesis of Iron Oxide Nanoparticles for Fast Detection of Atherosclerosis
 01:44
Termination of Translation
 06:42
Generation and Coherent Control of Pulsed Quantum Frequency Combs
 13:27
Osteopathic Manipulative Treatment as a Useful Adjunctive Tool for Pneumonia