

Adaptive Fuzzy Tracking Control Design for a Class of Uncertain Nonstrict-Feedback Fractional-Order Nonlinear SISO

Abstract:
In this article, a class of uncertain nonstrict-feedback fractional-order nonlinear single-input-single-output (SISO) systems is investigated. Fuzzy-logic systems (FLSs) are employed to approximate the unknown nonlinear functions and model the uncertain fractional-order nonlinear systems. For the states measurable case, an adaptive fuzzy state-feedback control scheme is developed under the framework of the backstepping technique. For the states unmeasurable case, an observer-based output-feedback control design is proposed by introducing a serial-parallel estimation model and using the dynamic surface control (DSC) technique. Under the drive of the reference signals, the semiglobally uniformly ultimate boundedness for all signals and the tracking errors converging to a small neighborhood of the origin are proved based on the Lyapunov function theory by choosing appropriate design parameters. Two examples with numerical simulations are presented to illustrate the availability of the proposed control approaches.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:18
Second Order systems II
 01:24
PI Controller: Design
 01:21
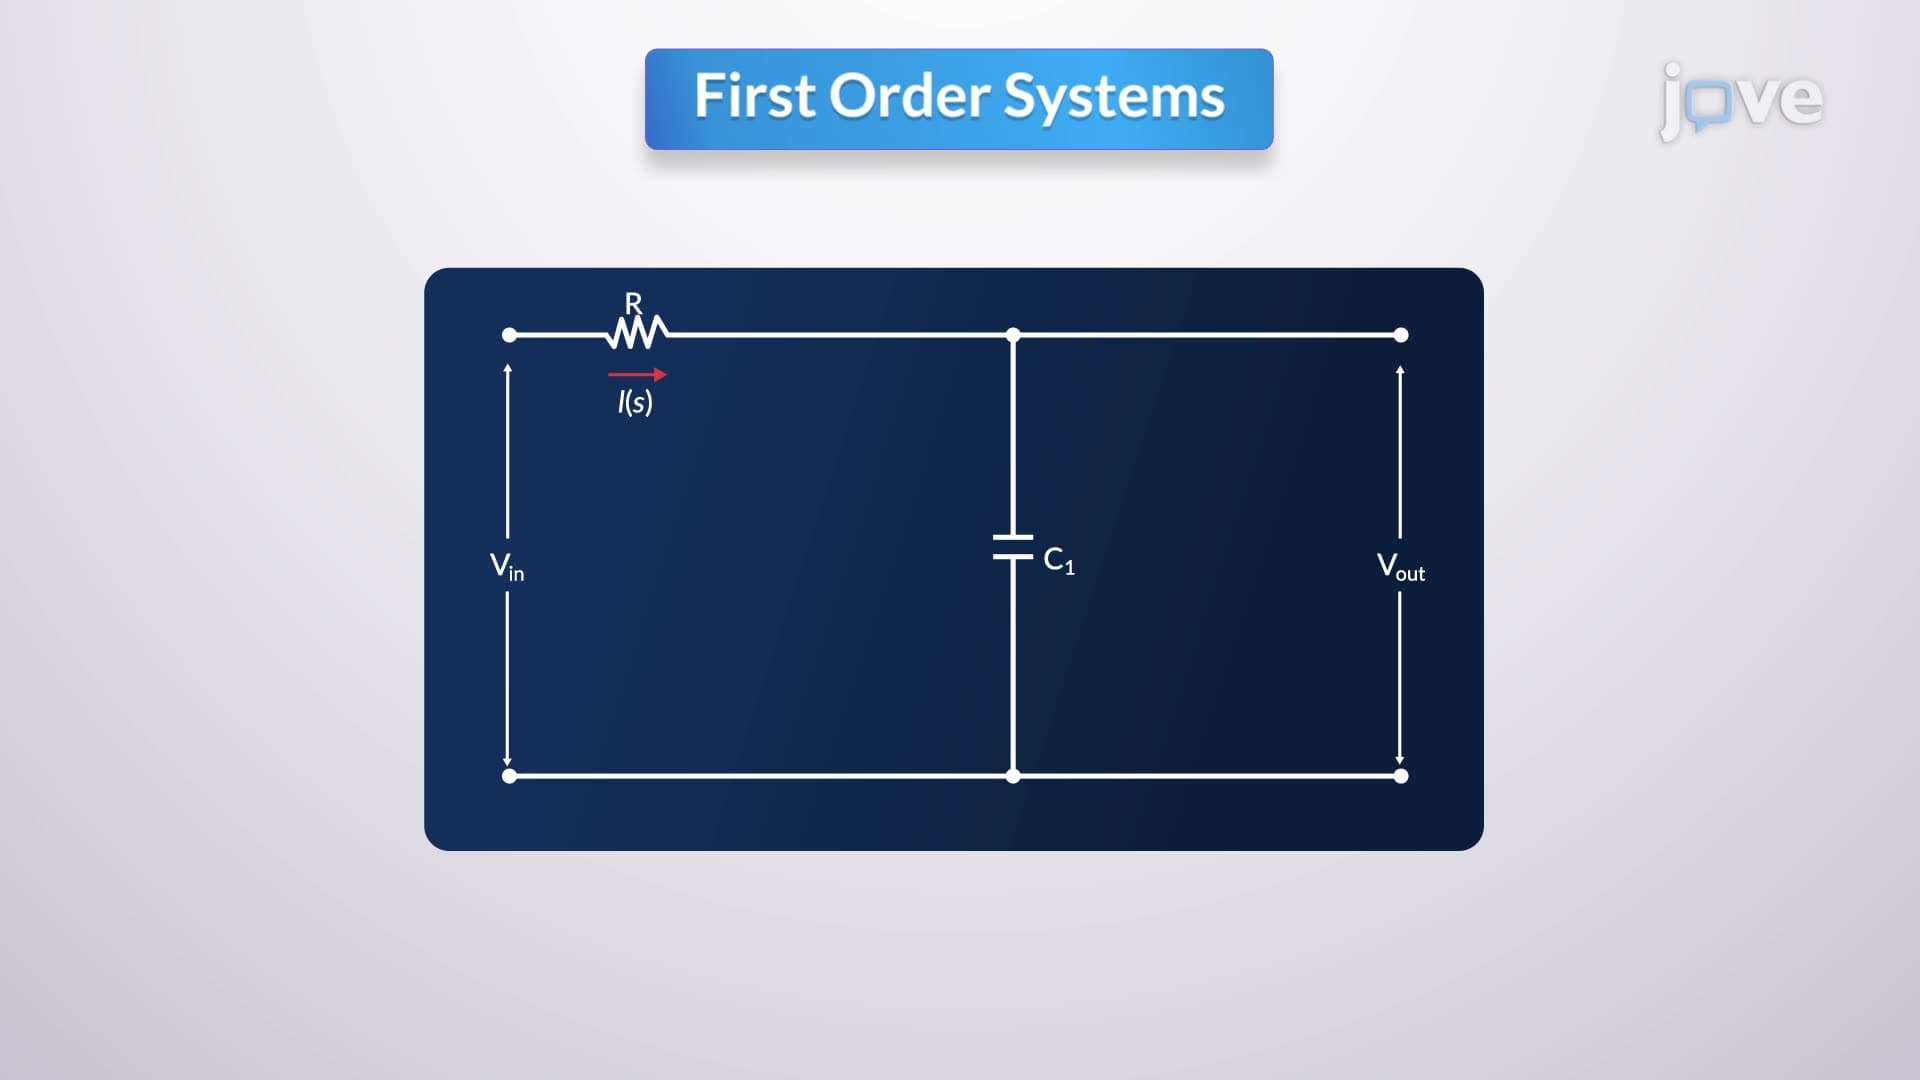
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...