Related Experiment Video
Updated: Jan 18, 2026


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Goal-directed autonomous navigation of mobile robot based on the principle of neuromodulation
Dongshu Wang1, Wenjie Si2, Yong Luo1
1School of Electrical Engineering, Zhengzhou University, Zhengzhou, China.

Abstract:
Autonomous navigation in dynamic environment is aprerequisite of the mobile robot to perform tasks, and numerous approaches have been presented, including the supervised learning. Using supervised learning in robot navigation might meet problems, such as inconsistent and noisy data, and high error in training data. Inspired by the advantages of the reinforcement learning, such as no need for desired outputs, many researchers have applied reinforcement learning to robot navigation. This paper presents anovel method to address the robot navigation in different settings, through integrating supervised learning and analogical reinforcement learning into amotivated developmental network. We focus on the effect of the new learning rate on the robot navigation behavior. Experimentally, we show that the effect of internal neurons on the learning rate allows the agent to approach the target and avoid the obstacle as compounding effects of sequential states in static, dynamic, and complex environments. Further, we compare the performance between the emergent developmental network system and asymbolic system, as well as other four reinforcement learning algorithms. These experiments indicate that the reinforcement learning is beneficial for developing desirable behaviors in this set of robot navigation- staying statistically close to its target and away from obstacle.


Related Concept Videos
 01:37
Neural Regulation
 01:11
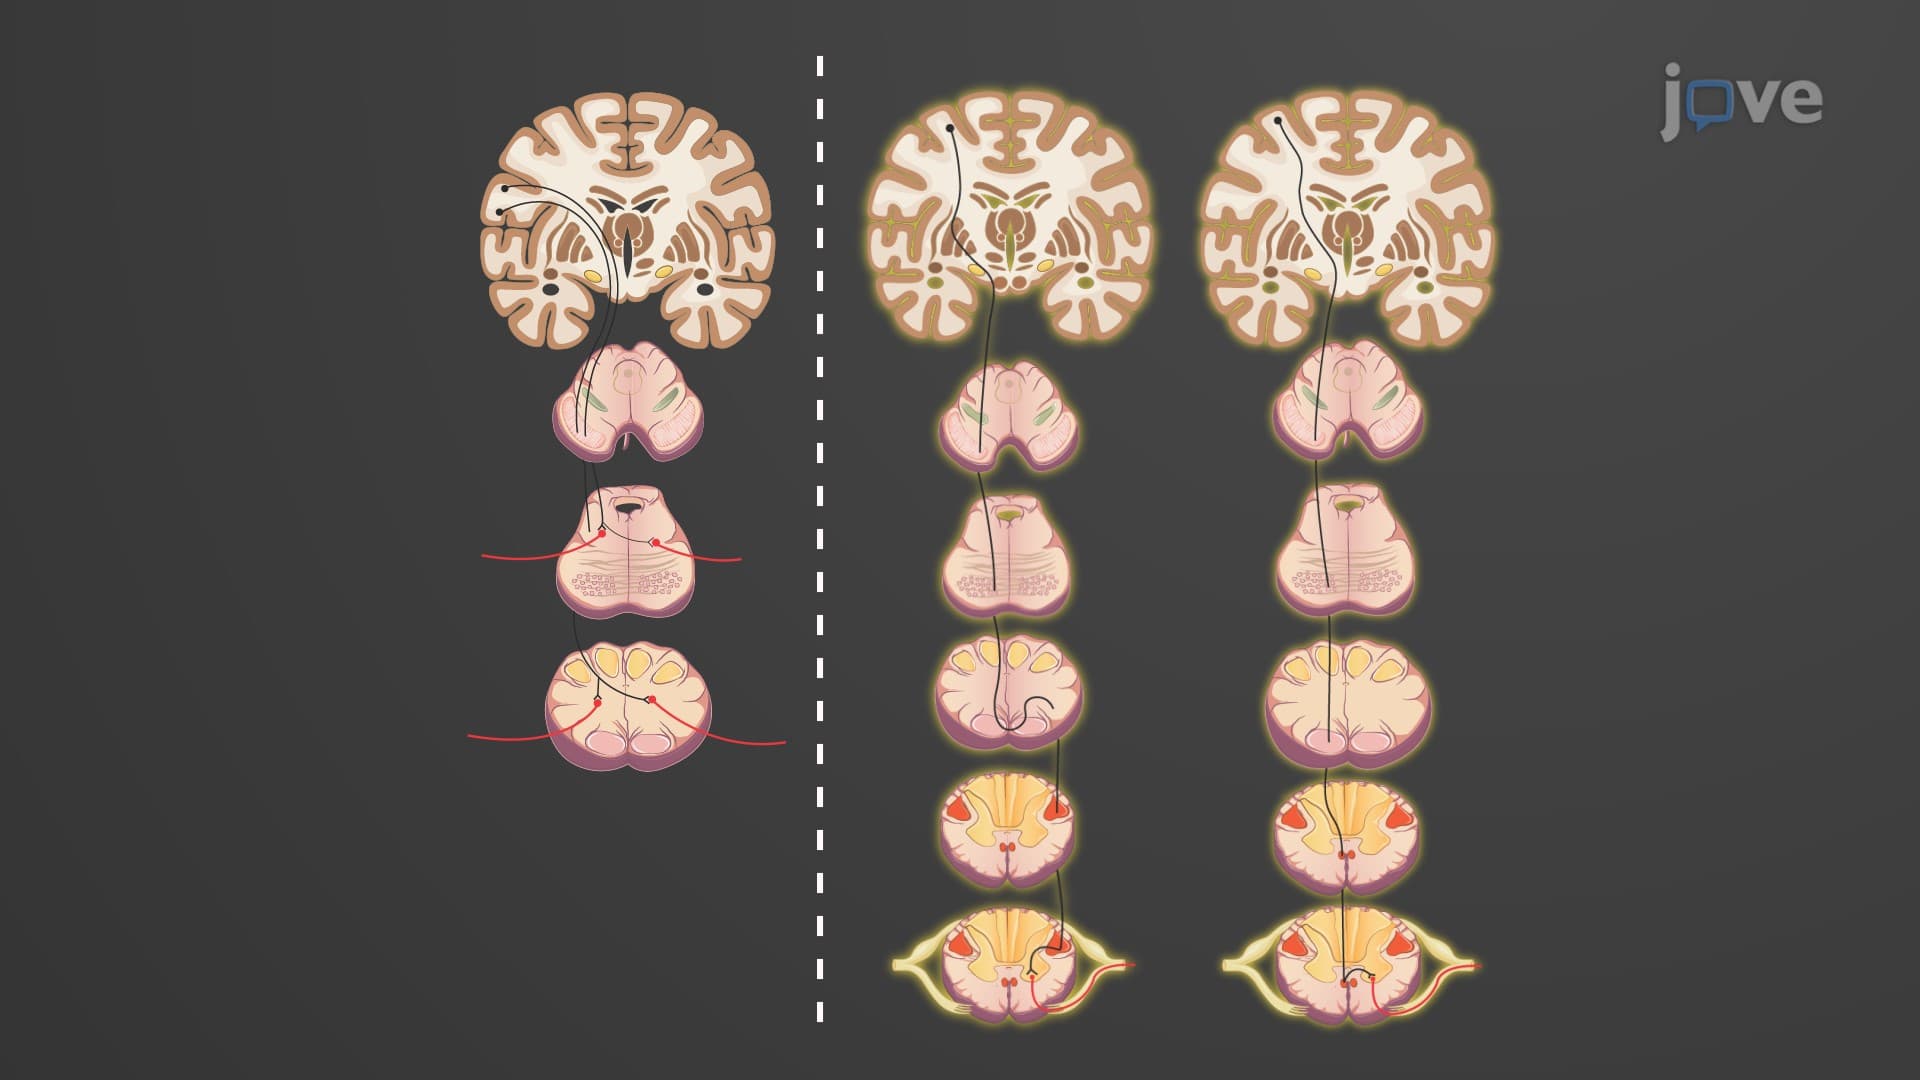
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...