Binocular Light-Field: Imaging Theory and Occlusion-Robust Depth Perception Application
Related Experiment Video
Updated: Jan 18, 2026
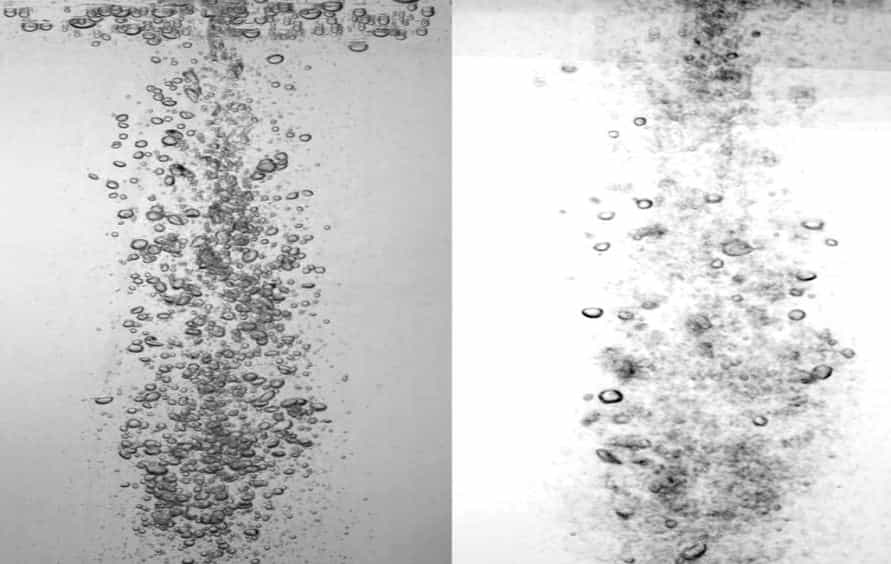
Determining 3D Flow Fields via Multi-camera Light Field Imaging
Published on: March 6, 2013

Abstract:
Binocular stereo vision (SV) has been widely used to reconstruct the depth information, but it is quite vulnerable to scenes with strong occlusions. As an emerging computational photography technology, light-field (LF) imaging brings about a novel solution to passive depth perception by recording multiple angular views in a single exposure. In this paper, we explore binocular SV and LF imaging to form the binocular-LF imaging system. An imaging theory is derived by modeling the imaging process and analyzing disparity properties based on the geometrical optics theory. Then an accurate occlusion-robust depth estimation algorithm is proposed by exploiting multibaseline stereo matching cues and defocus cues. The occlusions caused by binocular SV and LF imaging are detected and handled to eliminate the matching ambiguities and outliers. Finally, we develop a binocular-LF database and capture realworld scenes by our binocular-LF system to test the accuracy and robustness. The experimental results demonstrate that the proposed algorithm definitely recovers high quality depth maps with smooth surfaces and precise geometric shapes, which tackles the drawbacks of binocular SV and LF imaging simultaneously.
More Related Videos
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 02:16
Light Acquisition
 01:16
Focusing of Light in the Eye