Related Experiment Video
Updated: Jan 18, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Phase-Synchronized Assistive Torque Control for the Correction of Kinematic Anomalies in the Gait Cycle

Abstract:
Gait anomalies give rise to several clinical problems in stroke survivors, which restrict their functional mobility and have a negative impact on their quality of life. Robotics-aided gait training post-stroke has proven capable of improving patients' functional walking, but so far it has not performed significantly better than conventional therapy. We hypothesize that an exoskeleton-based training program, aimed at correcting deficits in the leg joints' movement, could produce greater improvements in gait function than conventional therapy. As a first step towards testing this hypothesis, we designed an exoskeleton control to correct a typical kinematic deficit post-stroke, namely, reduced knee flexion on the paretic side during swing. The proposed control attempts to minimize this deficit by delivering assistive torque synchronized with the continuous phase of the patient's gait. Nine healthy male participants walked in a unilateral cable-driven exoskeleton while subject to an artificial knee flexion impairment produced by a custom-made knee brace. The experiments employed a treadmill featuring a variable-velocity control to allow self-selected gait speed. The artificial impairment by itself caused a significant reduction in peak flexion angle (p = 0.000129). Exoskeleton assistance compensated most of the knee flexion deficit, yielding no significant difference with unrestricted flexion (p = 0.3393). No significant changes in self-selected gait speed or stride frequency were detected. The proposed control can be expanded to correct motion deficits in other joints at different stages of the gait cycle.
More Related Videos
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:15
Torque Free Motion
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
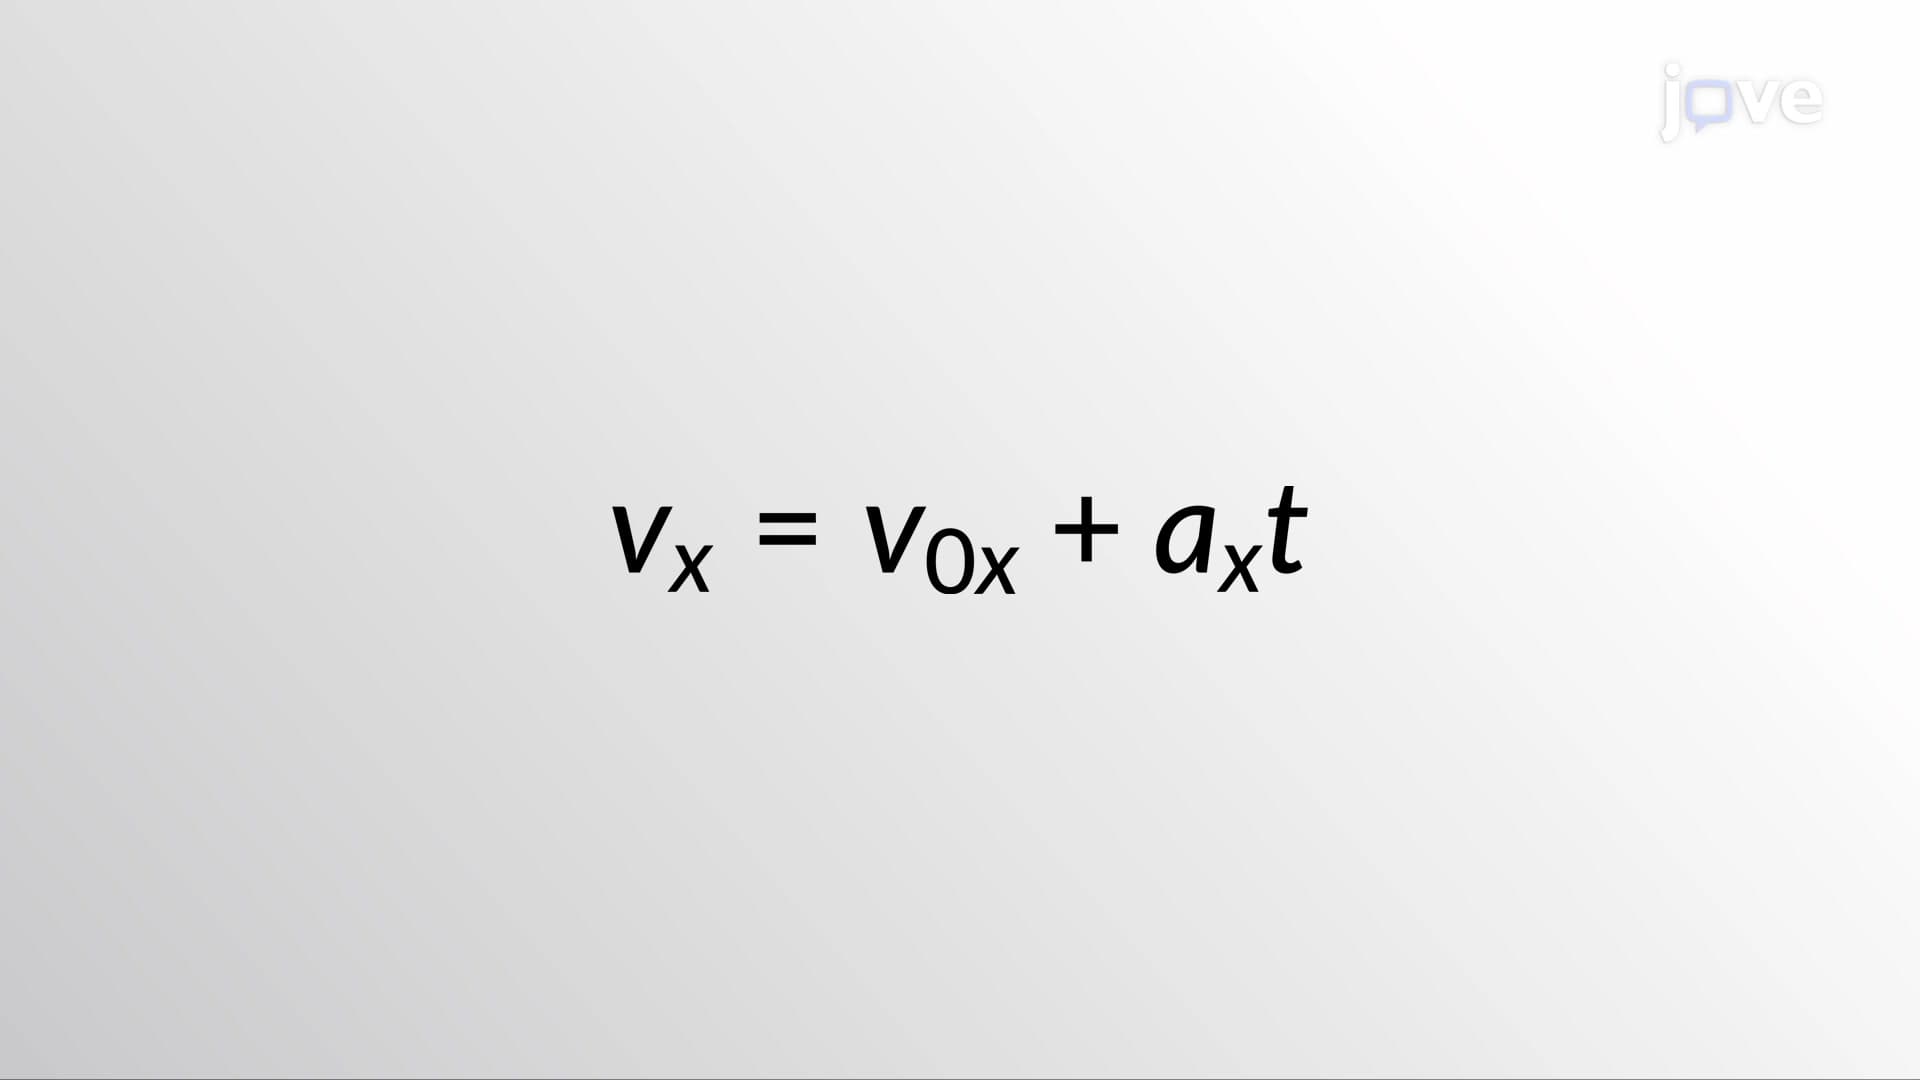 01:26
Kinematic Equations - I
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:18
Kinematic Equations - III
Using the kinematic equations,...