Related Experiment Video
Updated: Jan 6, 2026

Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
A Novel Tendon-Driven Soft Actuator with Self-Pumping Property
Tao Ren1, Yingtian Li2, Menghong Xu2
1Robotics Research Center, Xihua University, Chengdu, China.

Abstract:
Soft actuators and robotics have been widely researched in recent years mainly due to their compliance to environments and safe interaction with humans. However, the need of tether and low energy efficiency of such actuators/robots has limited their practical applications. This article presents a novel tendon-driven soft actuator concept that has the property of self-pumping, called soft self-pumping actuator (SSPA) in this research. A SSPA is designed by assembling two soft pneumatic actuators (SPAs) face-to-face, whose air chambers are connected by two check valves. Actuation of the SSPA is achieved by tendons that allows precise and untethered control compared with traditional SPAs. The two chambers in the proposed actuators are precharged with air to a desired pressure to enlarge self-stiffness and to facilitate bending. When actuated, one chamber will be compressed and serve as a pump to inject its air into the other chamber, resulting in further bending of the actuator. The airflow involves energy transmission to help the intended actuation, thus improving energy efficiency. In experimental studies, differential chamber air pressure is found to reduce the force in initiating actuator bending. Experimental results have also shown that energy efficiency increase of up to 45% has been achieved compared with the same design but without air transmission. We believe that the proposed concept could lead to more novel designs of controllable and energy saving soft robots.
Related Concept Videos
 01:30
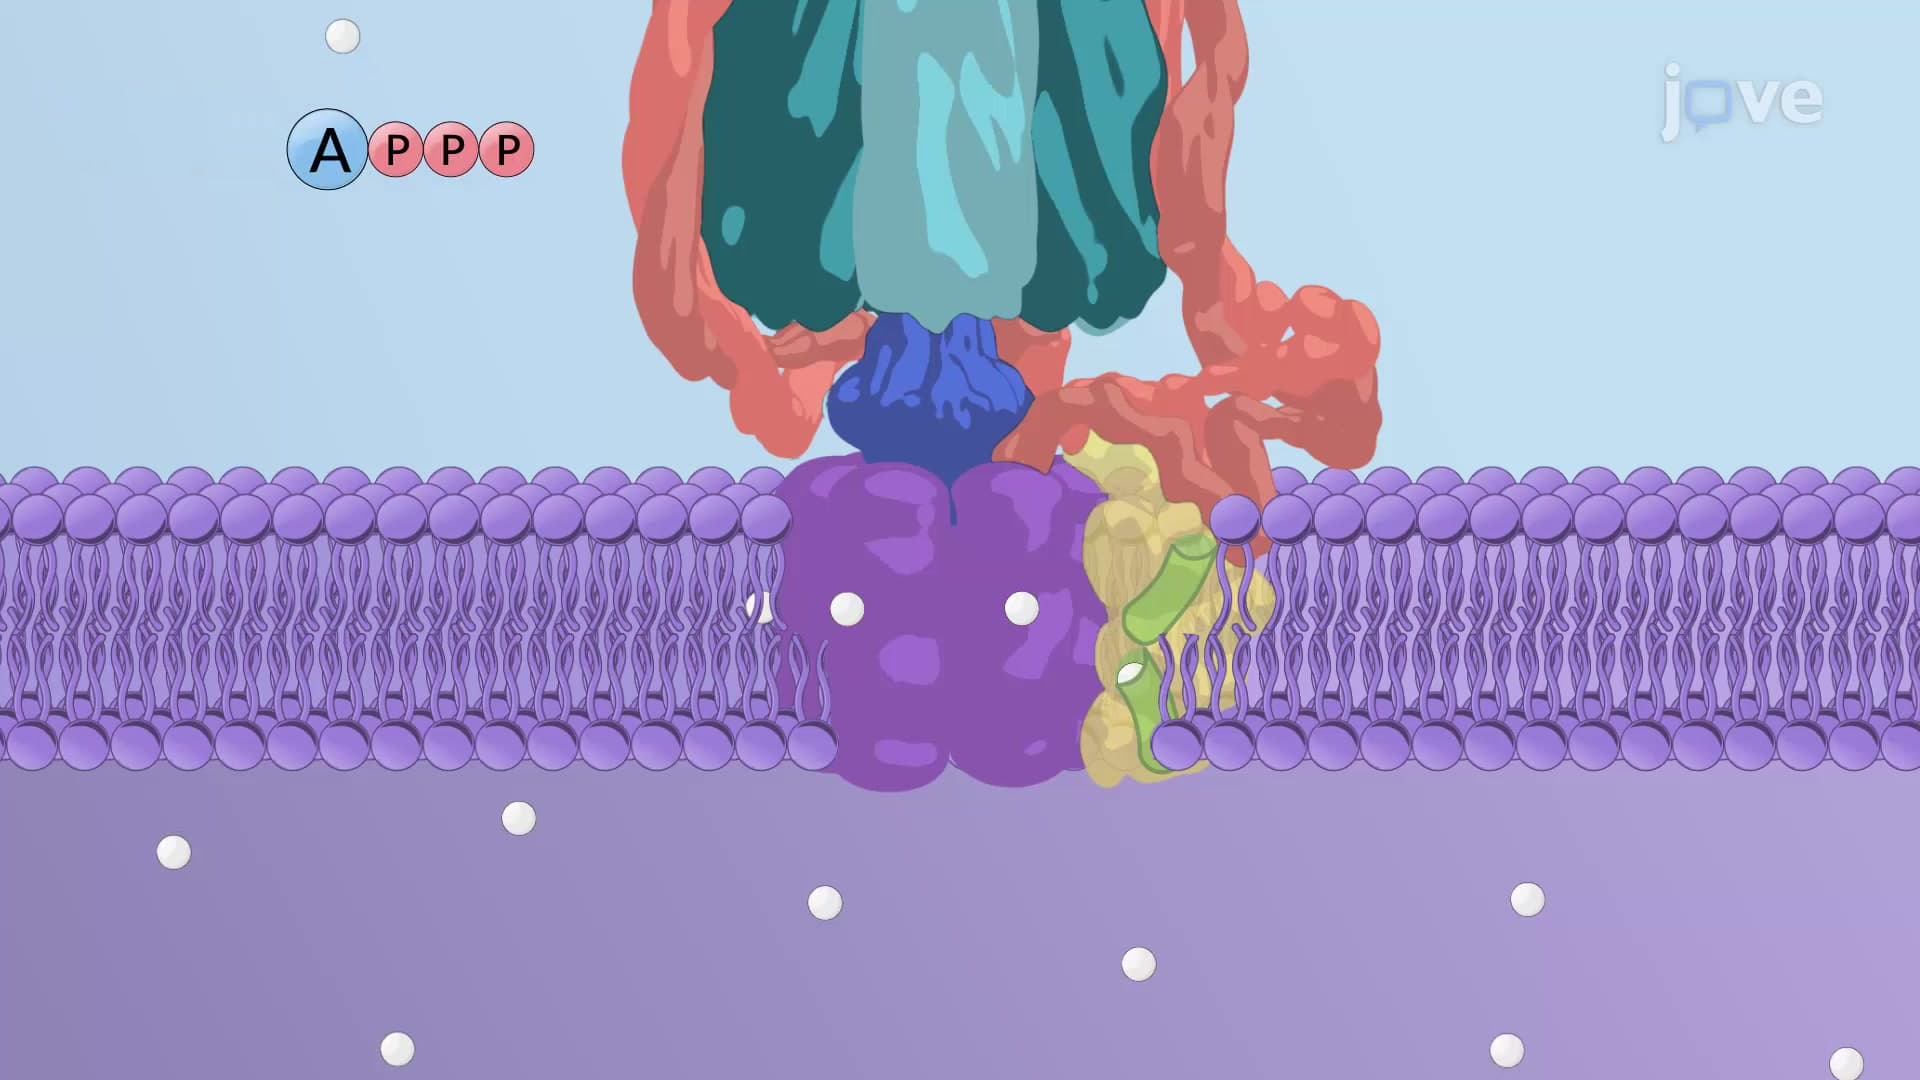
ATP Driven Pumps III: V-type Pumps
The peripheral or cytosolic V1 domain with eight subunits is involved in ATP hydrolysis. The integral or transmembrane V0 domain containing at least five subunits...
 01:34
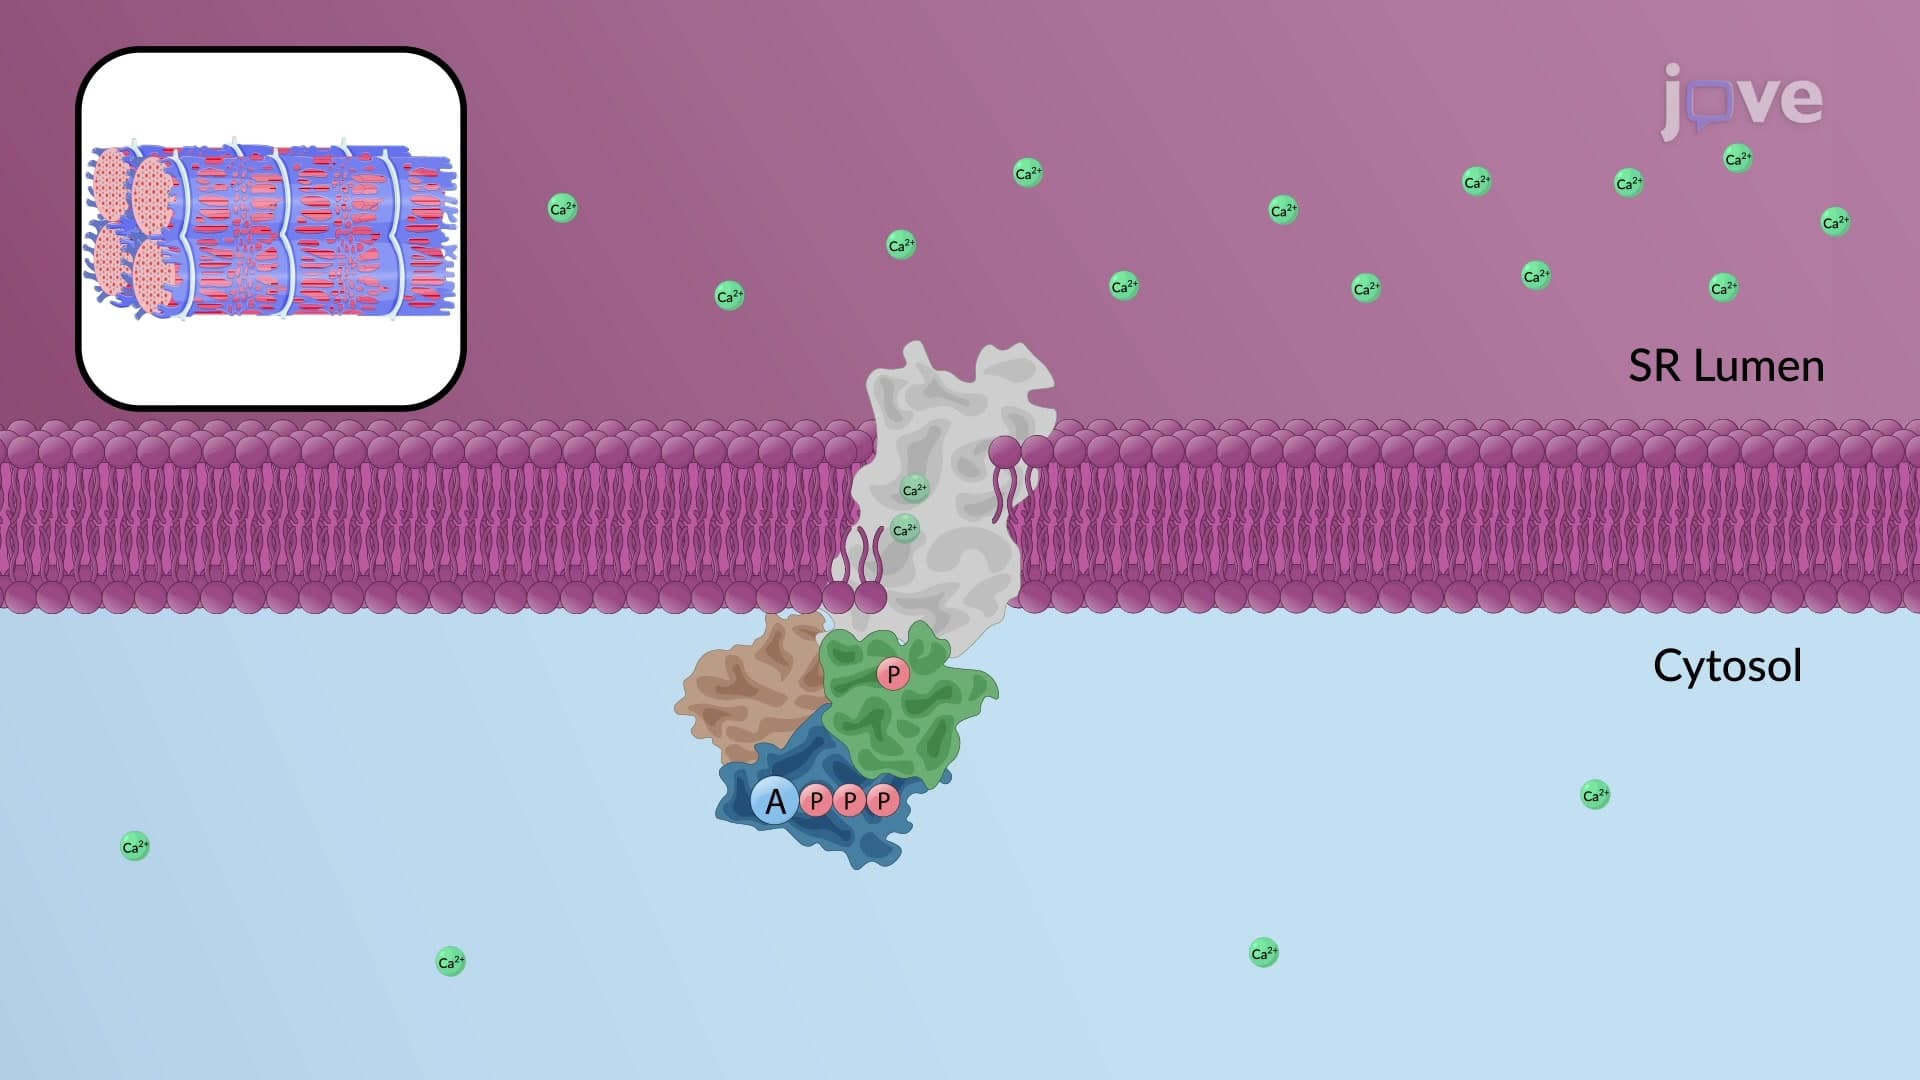
ATP Driven Pumps II: P-type Pumps
A typical P-type pump has three cytosolic domains: nucleotide-binding (N), phosphorylation (P), and activator (A) domains. These domains are connected to the membrane-spanning helices by short amino acid segments. ATP hydrolysis and covalent phosphoenzyme intermediate formation are crucial parts of the catalytic cycle. At the highly...
 01:27
ATP Driven Pumps I: An Overview
There are four main types of ATP-driven pumps - P-type, V-type, F-type, and ABC transporter. All these pumps are of varying complexities and...