Related Experiment Video
Updated: Jan 5, 2026
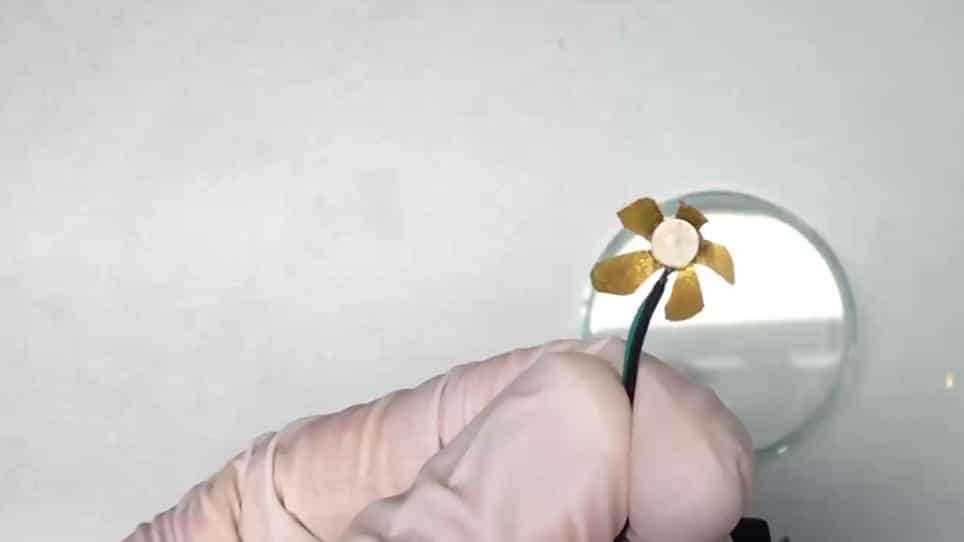
Fabrication of Carbon-Based Ionic Electromechanically Active Soft Actuators
Published on: April 25, 2020
Interfacing Soft and Hard: A Spring Reinforced Actuator
Hing-Choi Fu1, Justin D L Ho1, Kit-Hang Lee1
1Department of Mechanical Engineering, The University of Hong Kong, Hong Kong, China.

Abstract:
Muscular hydrostats have long been a source of inspiration for soft robotic designs. With their inherent compliance, they excel in unpredictable environments and can gently manipulate objects with ease. However, their performance lacks where high force or a fast-dynamic response is needed. In this study, we propose a novel spring reinforced actuator (SRA) that explores the intermediate state between muscular hydrostats and endoskeletal mechanisms. The result is that we dramatically enhance the robot dynamic performance, which is unprecedented in similar kinds of soft robots, while retaining compliant omnidirectional bending. Analytical modeling of the flexible backbone was built and experimentally validated. This is also the first attempt to perform detailed finite element analysis to investigate the strain-stress behavior of the constraining braided bellow tube. The braided interweaving threads are modeled, in which complex thread-to-thread contacts occur. Experimental evaluation of SRAs was performed for actuation force, stiffness, and dynamic response. We showcase the enhanced actuator's performance in several applications such as locomotion and heavy object manipulation.
Related Concept Videos
 01:22
Mechanical Systems
 01:24
Circular Shafts - Elastoplastic Materials
As torque on the...
 01:19
Members Made of Elastoplastic Material
As the bending moment...
 01:23
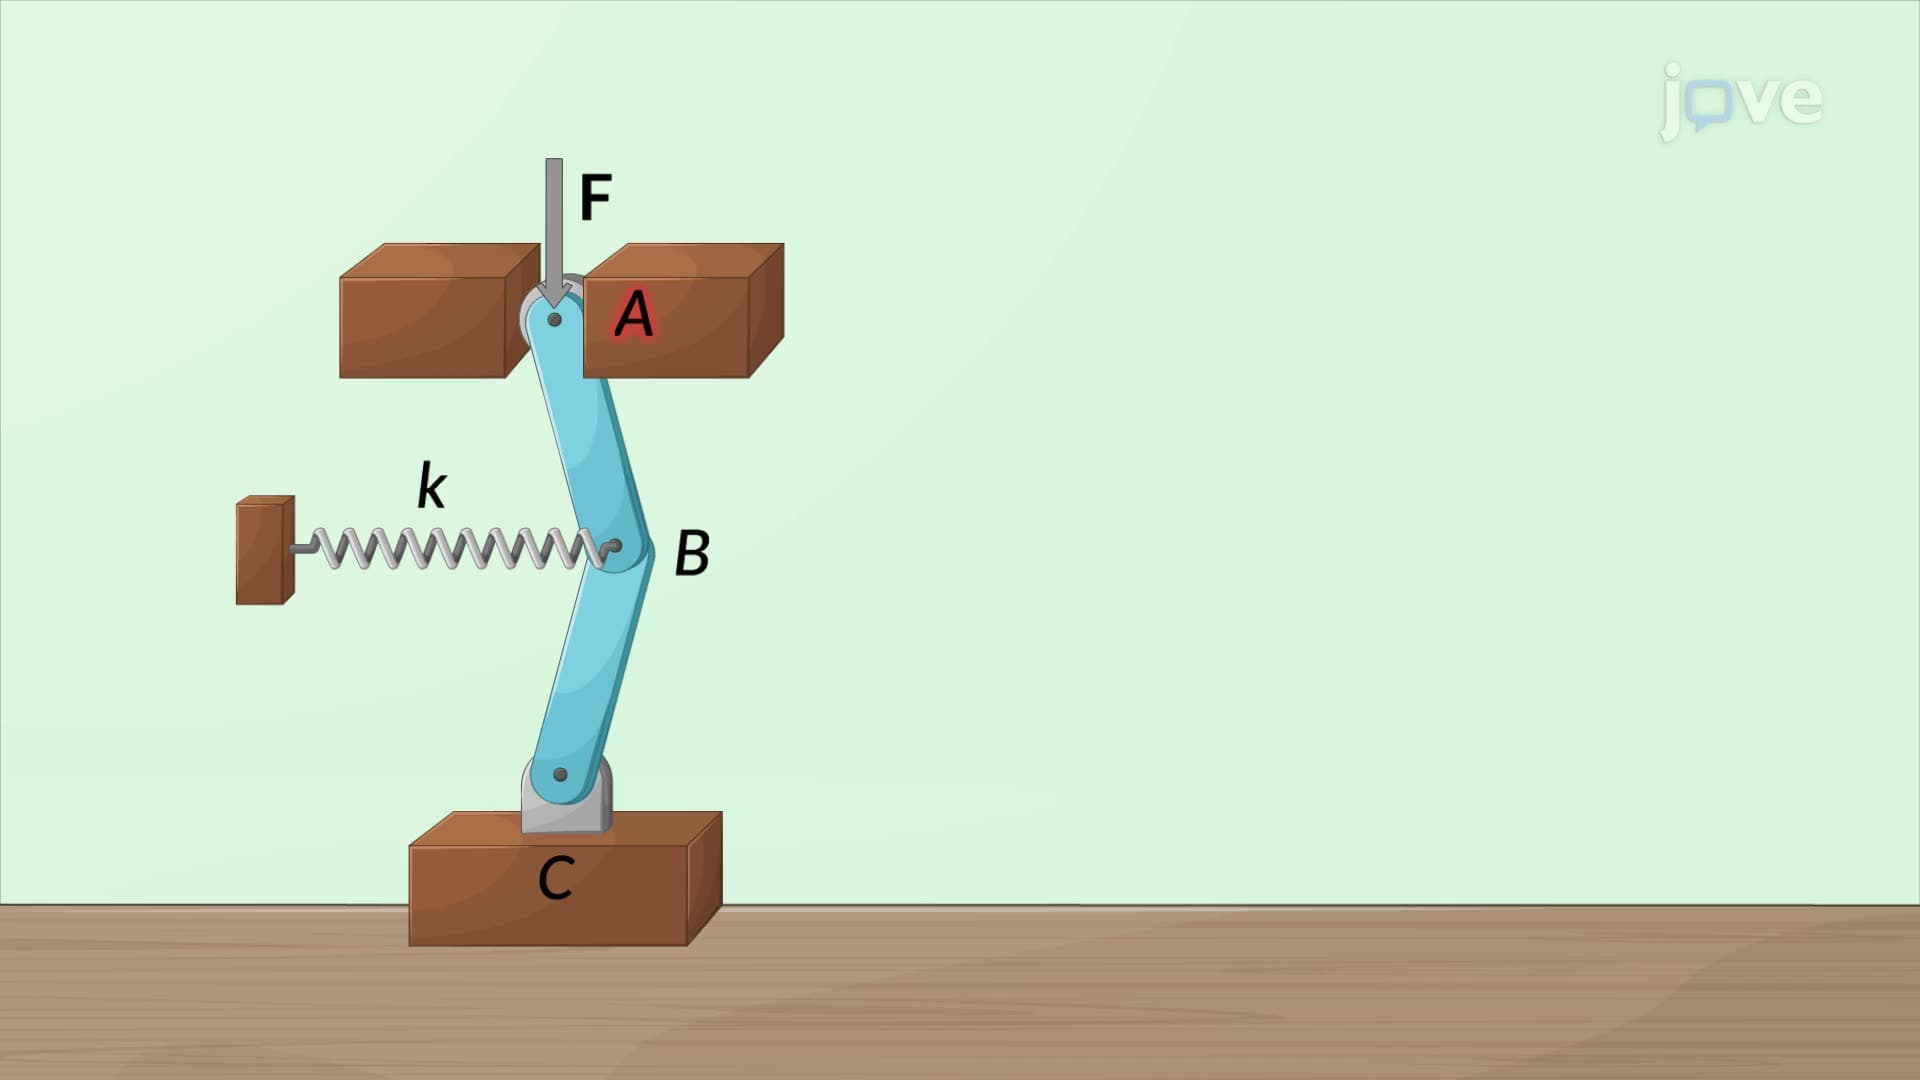
Euler's Formula to Columns: Problem Solving
The system comprises two vertical rigid bars, AB and BC, of...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:23
Design Example: Deciding Thickness of Lubricating Fluid in a Shaft
To calculate the required thickness of the lubricant layer, the tangential velocity at the shaft's surface must first be determined. This velocity is calculated by converting the rotational speed to angular velocity...