Unsupervised Rotation Factorization in Restricted Boltzmann Machines
Related Experiment Video
Updated: Jan 5, 2026
Methods for Measuring the Orientation and Rotation Rate of 3D-printed Particles in Turbulence
Published on: June 24, 2016

Abstract:
Finding suitable image representations for the task at hand is critical in computer vision. Different approaches extending the original Restricted Boltzmann Machine (RBM) model have recently been proposed to offer rotation-invariant feature learning. In this paper, we present an extended novel RBM that learns rotation invariant features by explicitly factorizing for rotation nuisance in 2D image inputs within an unsupervised framework. While the goal is to learn invariant features, our model infers an orientation per input image during training, using information related to the reconstruction error. The training process is regularised by a Kullback-Leibler divergence, offering stability and consistency. We used the γ -score, a measure that calculates the amount of invariance, to mathematically and experimentally demonstrate that our approach indeed learns rotation invariant features. We show that our method outperforms the current state-of-the-art RBM approaches for rotation invariant feature learning on three different benchmark datasets, by measuring the performance with the test accuracy of an SVM classifier. Our implementation is available at https://bitbucket.org/tuttoweb/rotinvrbm.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:11
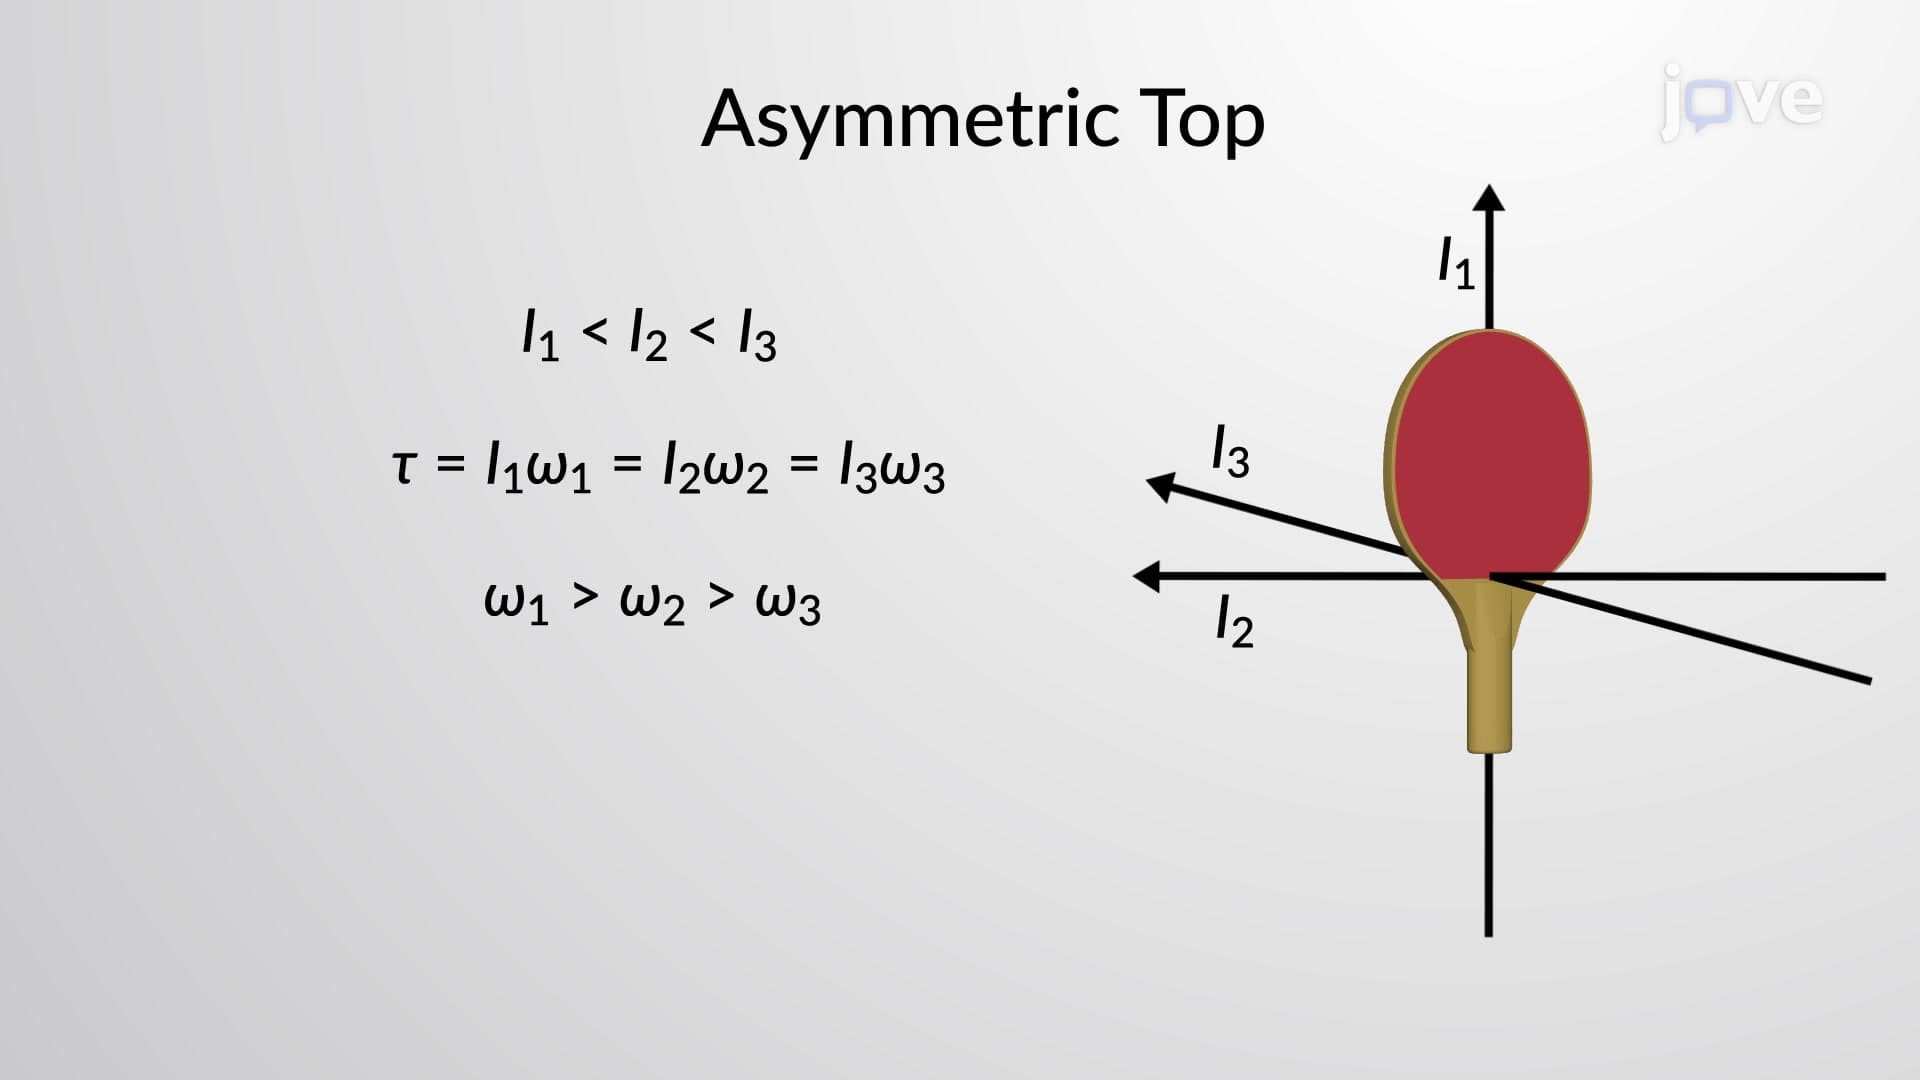
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility