Related Experiment Video
Updated: Jan 5, 2026


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
A Repeatable Motion Scheme for Kinematic Control of Redundant Manipulators
Kong Ying1, Tang Qingqing1, Zhang Ruiyang1
1Department of Information and Electronic Engineering, Zhejiang University of Science and Technology, Hangzhou, China.

Abstract:
To achieve closed trajectory motion planning of redundant manipulators, each joint angle has to be returned to its initial position. Most of the repeatable motion schemes have been proposed to solve kinematic problems considering only the initial desired position of each joint at first. Actually, it is very difficult for various joint angles of the robot arms to be positioned in the expected trajectory before moving. To construct an effective kinematic model, a novel optimal programming index based on a recurrent neural network is designed and analyzed in this paper. The repetitiveness and timeliness are presented and analyzed. Combining the kinematic equation constraint of manipulators, a repeatable motion scheme is formulated. In addition, the Lagrange multiplier theorem is introduced to prove that such a repeatable motion scheme can be converted into a time-varying linear equation. A finite-time neural network solver is constructed for the solution of the motion scheme. Simulation results for two different trajectories illustrate the accuracy and timeliness of the proposed motion scheme. Finally, two different repetitive schemes are compared and verified the optimal time for the novelty of the proposed kinematic scheme.


Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:10
Relative Motion Analysis - Acceleration
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:23
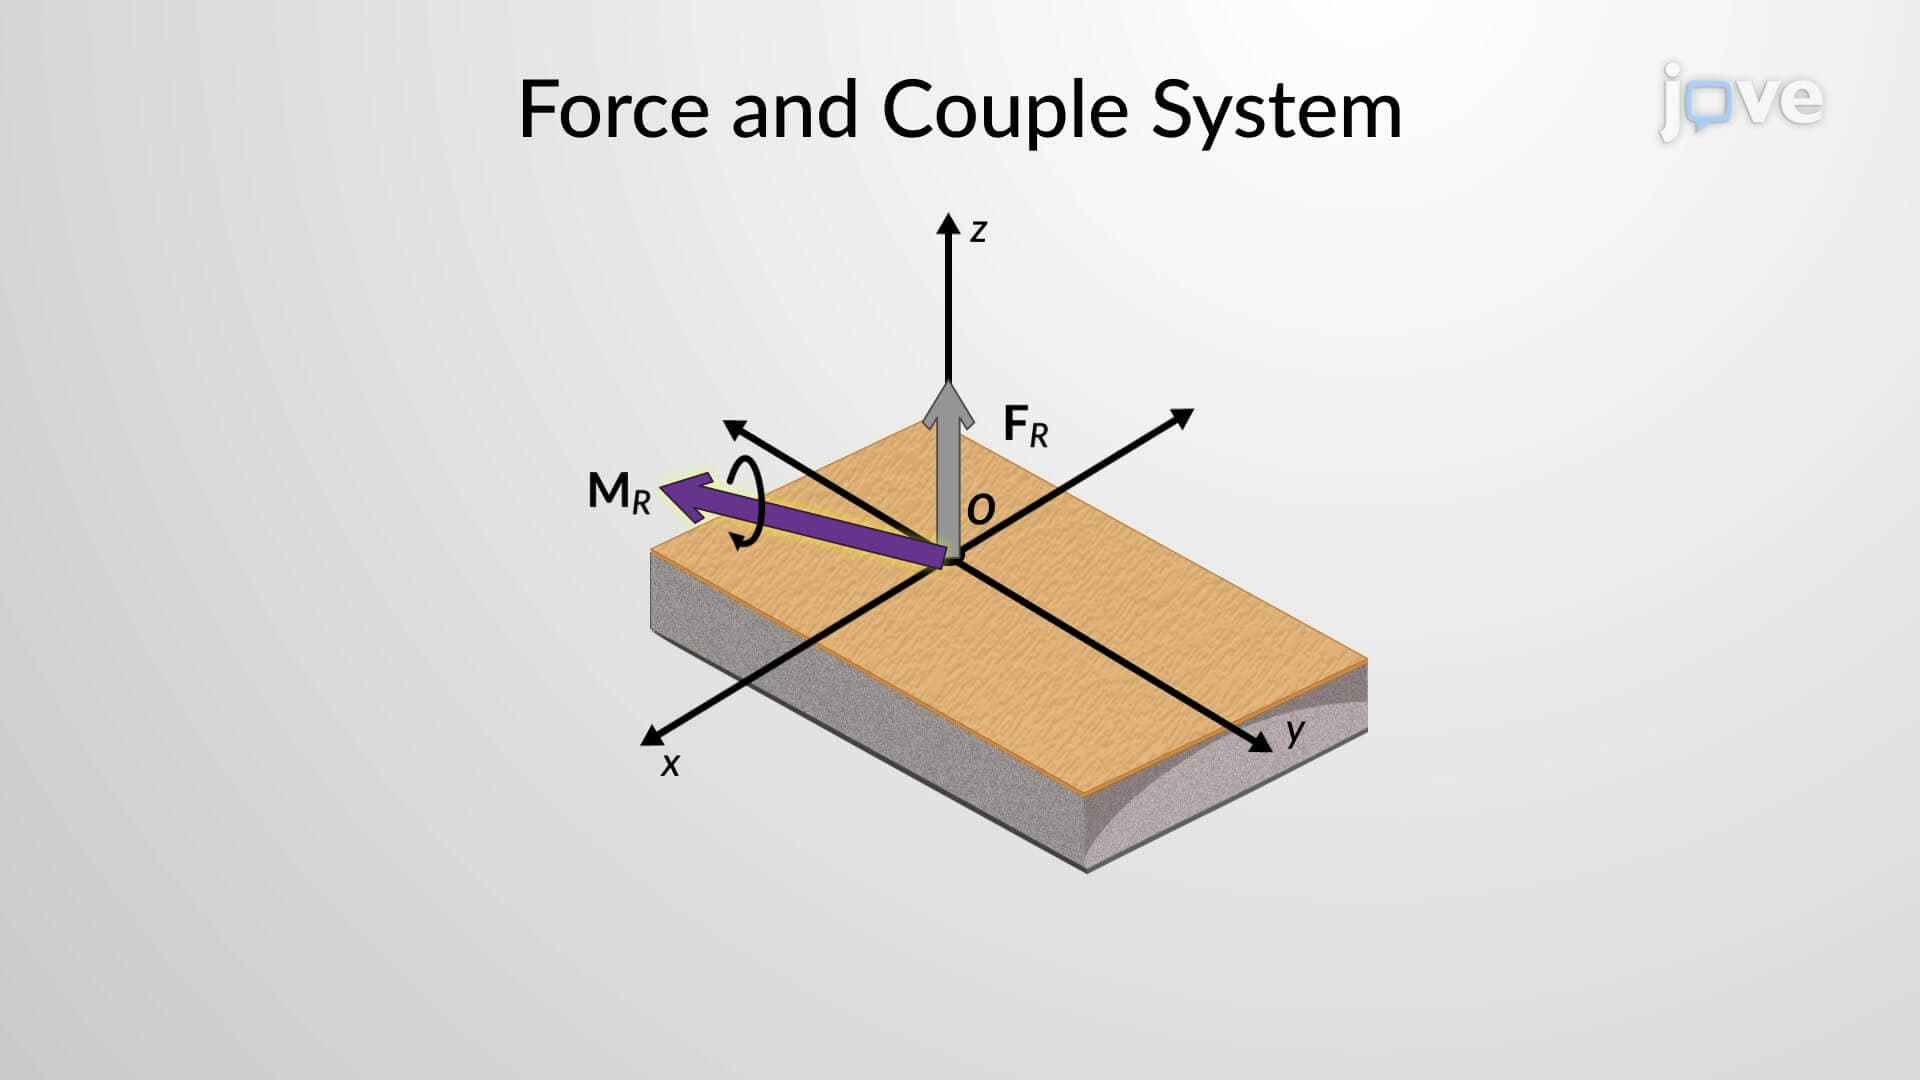
Simplification of a Force and Couple System: II