Related Experiment Video
Updated: Jan 5, 2026
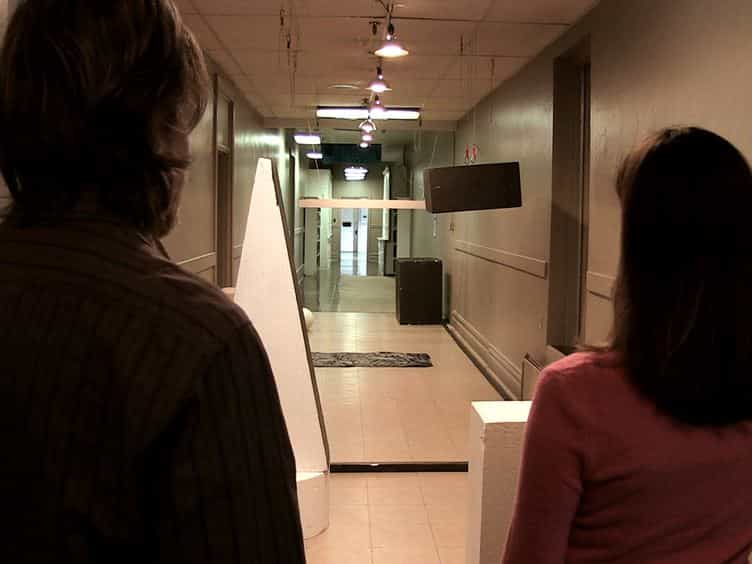

A Standardized Obstacle Course for Assessment of Visual Function in Ultra Low Vision and Artificial Vision
Published on: February 11, 2014
Overview obstacle maps for obstacle-aware navigation of autonomous drones
Jesús Pestana1, Michael Maurer1, Daniel Muschick2
1Institute for Computer Graphics and Vision (ICG) Graz University of Technology (TU Graz) Graz Austria.

Abstract:
Achieving the autonomous deployment of aerial robots in unknown outdoor environments using only onboard computation is a challenging task. In this study, we have developed a solution to demonstrate the feasibility of autonomously deploying drones in unknown outdoor environments, with the main capability of providing an obstacle map of the area of interest in a short period of time. We focus on use cases where no obstacle maps are available beforehand, for instance, in search and rescue scenarios, and on increasing the autonomy of drones in such situations. Our vision-based mapping approach consists of two separate steps. First, the drone performs an overview flight at a safe altitude acquiring overlapping nadir images, while creating a high-quality sparse map of the environment by using a state-of-the-art photogrammetry method. Second, this map is georeferenced, densified by fitting a mesh model and converted into an Octomap obstacle map, which can be continuously updated while performing a task of interest near the ground or in the vicinity of objects. The generation of the overview obstacle map is performed in almost real time on the onboard computer of the drone, a map of size is created in , therefore, with enough time remaining for the drone to execute other tasks inside the area of interest during the same flight. We evaluate quantitatively the accuracy of the acquired map and the characteristics of the planned trajectories. We further demonstrate experimentally the safe navigation of the drone in an area mapped with our proposed approach.

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
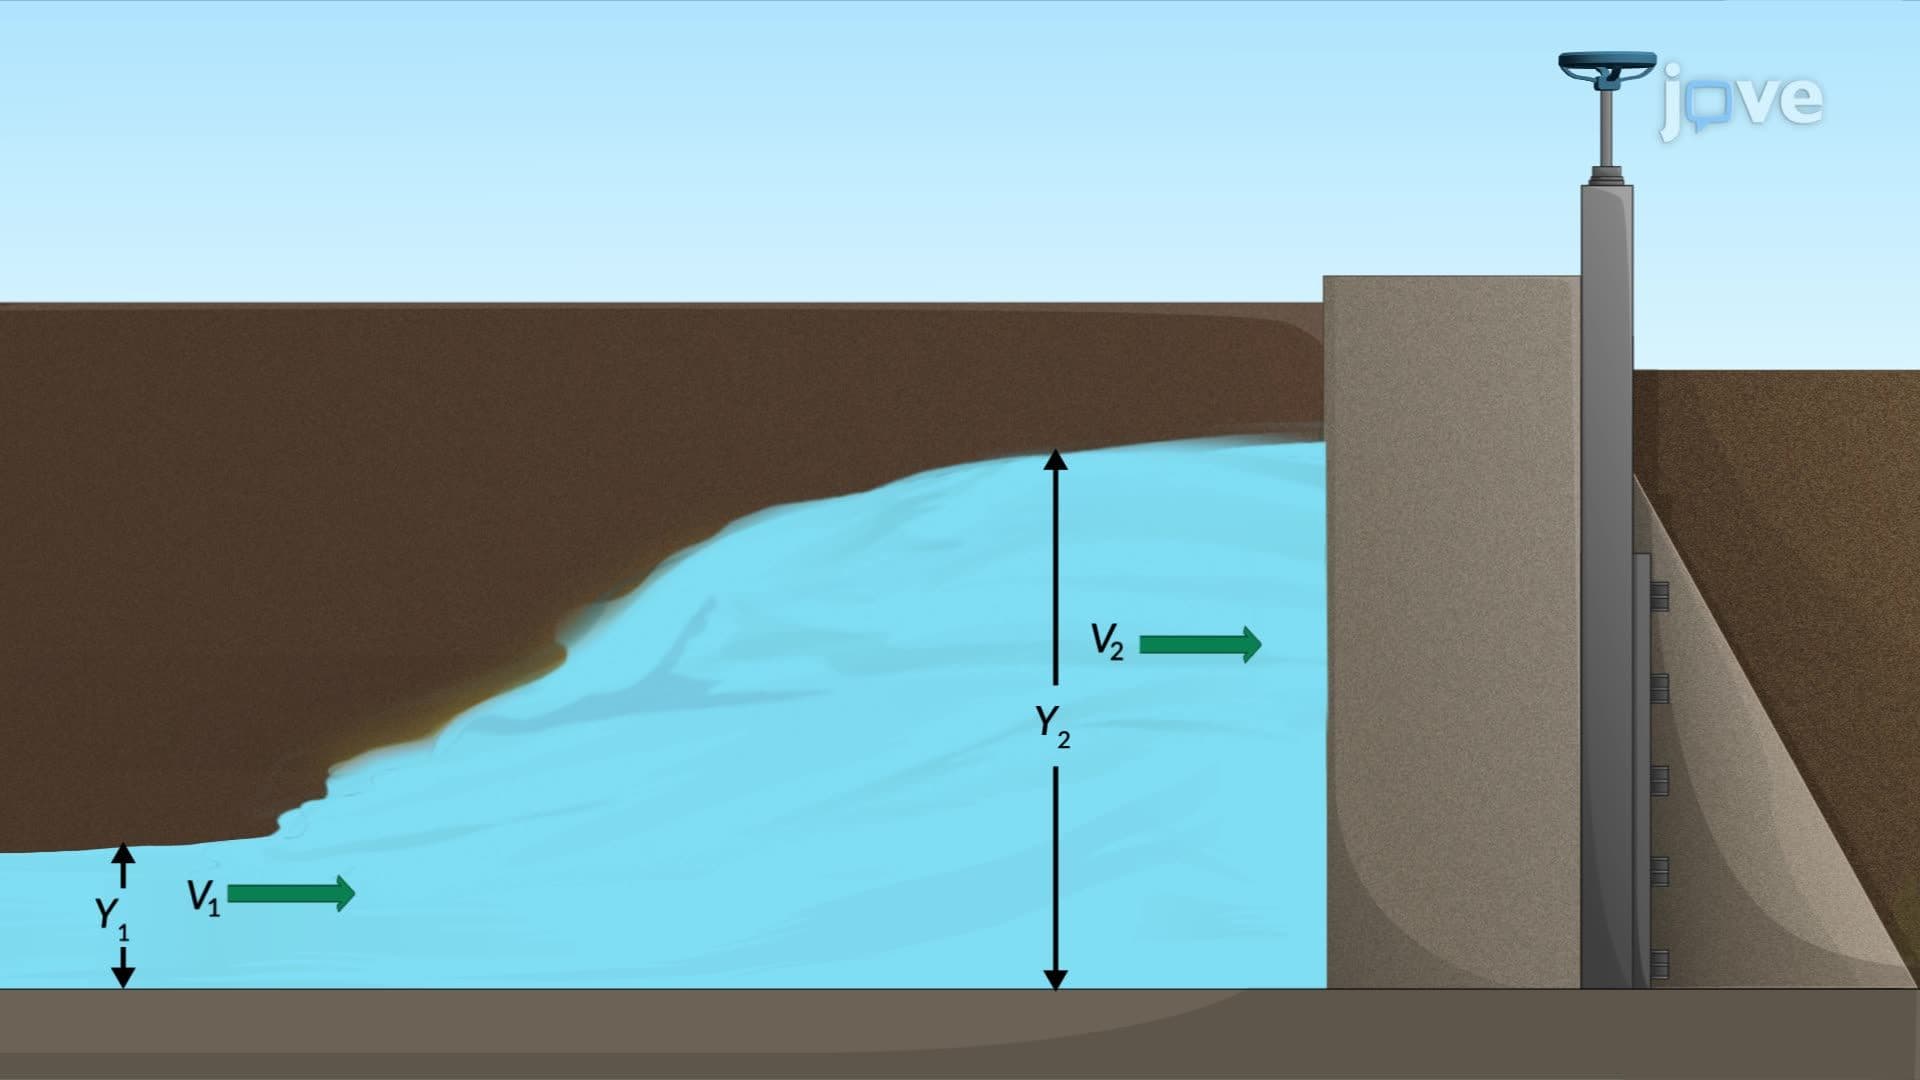 01:16
Hydraulic Jump: Problem Solving
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...