Related Experiment Video
Updated: Jan 5, 2026
Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
Traversability Assessment and Trajectory Planning of Unmanned Ground Vehicles with Suspension Systems on Rough
Kai Zhang1, Yi Yang2, Mengyin Fu3,4
1School of Automation, Beijing Institute of Technology, Beijing 100081, China. kaizhangbit@gmail.com.

Abstract:
This paper presents a traversability assessment method and a trajectory planning method. They are key features for the navigation of an unmanned ground vehicle (UGV) in a non-planar environment. In this work, a 3D light detection and ranging (LiDAR) sensor is used to obtain the geometric information about a rough terrain surface. For a given SE(2) pose of the vehicle and a specific vehicle model, the SE(3) pose of the vehicle is estimated based on LiDAR points, and then a traversability is computed. The traversability tells the vehicle the effects of its interaction with the rough terrain. Note that the traversability is computed on demand during trajectory planning, so there is not any explicit terrain discretization. The proposed trajectory planner finds an initial path through the non-holonomic A*, which is a modified form of the conventional A* planner. A path is a sequence of poses without timestamps. Then, the initial path is optimized in terms of the traversability, using the method of Lagrange multipliers. The optimization accounts for the model of the vehicle's suspension system. Therefore, the optimized trajectory is dynamically feasible, and the trajectory tracking error is small. The proposed methods were tested in both the simulation and the real-world experiments. The simulation experiments were conducted in a simulator called Gazebo, which uses a physics engine to compute the vehicle motion. The experiments were conducted in various non-planar experiments. The results indicate that the proposed methods could accurately estimate the SE(3) pose of the vehicle. Besides, the trajectory cost of the proposed planner was lower than the trajectory costs of other state-of-the-art trajectory planners.
Related Concept Videos
 01:29
Topographic Surveying and Contours
 01:17
Rolling Resistance: Problem Solving
 01:26
Impact: Problem Solving
By designating the launch point as the origin and utilizing kinematic equations, the vertical component of the projectile's velocity at the point of impact is...
 01:26
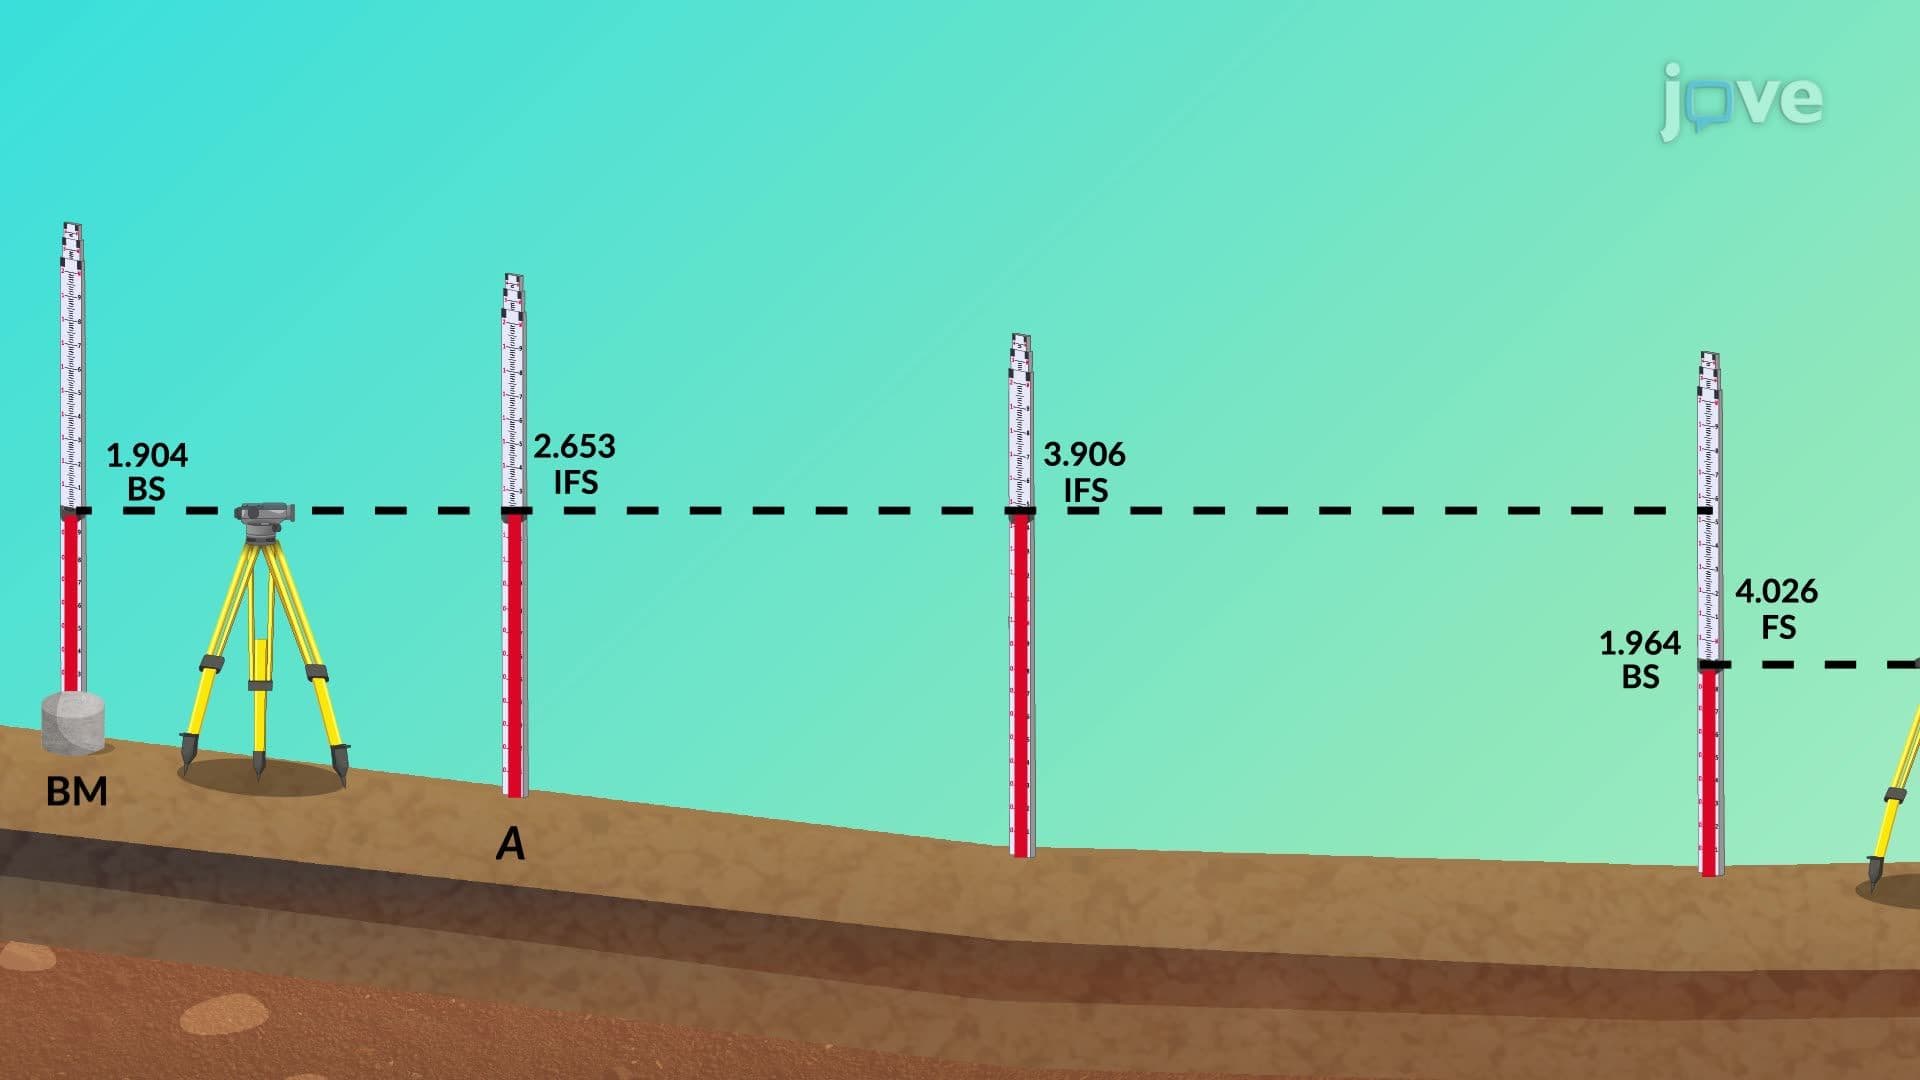
Profile Leveling and Cross Sections
 01:30
Types of Global Positioning System Surveys
 01:19
Design Example: Maintaining Level of an Embankment