Magnetic-Map-Matching-Aided Pedestrian Navigation Using Outlier Mitigation Based on Multiple Sensors and Roughness Weighting
Related Experiment Video
Updated: Jan 4, 2026
High-Throughput Analysis of Optical Mapping Data Using ElectroMap
Published on: June 4, 2019
Yong Hun Kim1, Min Jun Choi2, Eung Ju Kim3
1Department of Software Convergence, Sejong University, 209 Neungdong-ro, Gwangjin-gu, Seoul 05006, Korea. yhkim@sju.ac.kr.

Abstract:
This research proposes an algorithm that improves the position accuracy of indoor pedestrian dead reckoning, by compensating the position error with a magnetic field map-matching technique, using multiple magnetic sensors and an outlier mitigation technique based on roughness weighting factors. Since pedestrian dead reckoning using a zero velocity update (ZUPT) does not use position measurements but zero velocity measurements in a stance phase, the position error cannot be compensated, which results in the divergence of the position error. Therefore, more accurate pedestrian dead reckoning is achievable when the position measurements are used for position error compensation. Unfortunately, the position information cannot be easily obtained for indoor navigation, unlike in outdoor navigation cases. In this paper, we propose a method to determine the position based on the magnetic field map matching by using the importance sampling method and multiple magnetic sensors. The proposed method does not simply integrate multiple sensors but uses the normalization and roughness weighting method for outlier mitigation. To implement the indoor pedestrian navigation algorithm more accurately than in existing indoor pedestrian navigation, a 15th-order error model and an importance-sampling extended Kalman filter was utilized to correct the error of the map-matching-aided pedestrian dead reckoning (MAPDR). To verify the performance of the proposed indoor MAPDR algorithm, many experiments were conducted and compared with conventional pedestrian dead reckoning. The experimental results show that the proposed magnetic field MAPDR algorithm provides clear performance improvement in all indoor environments.
More Related Videos
Related Concept Videos
 01:22
Local Attraction
 01:26
Errors in Global Positioning System
 01:31
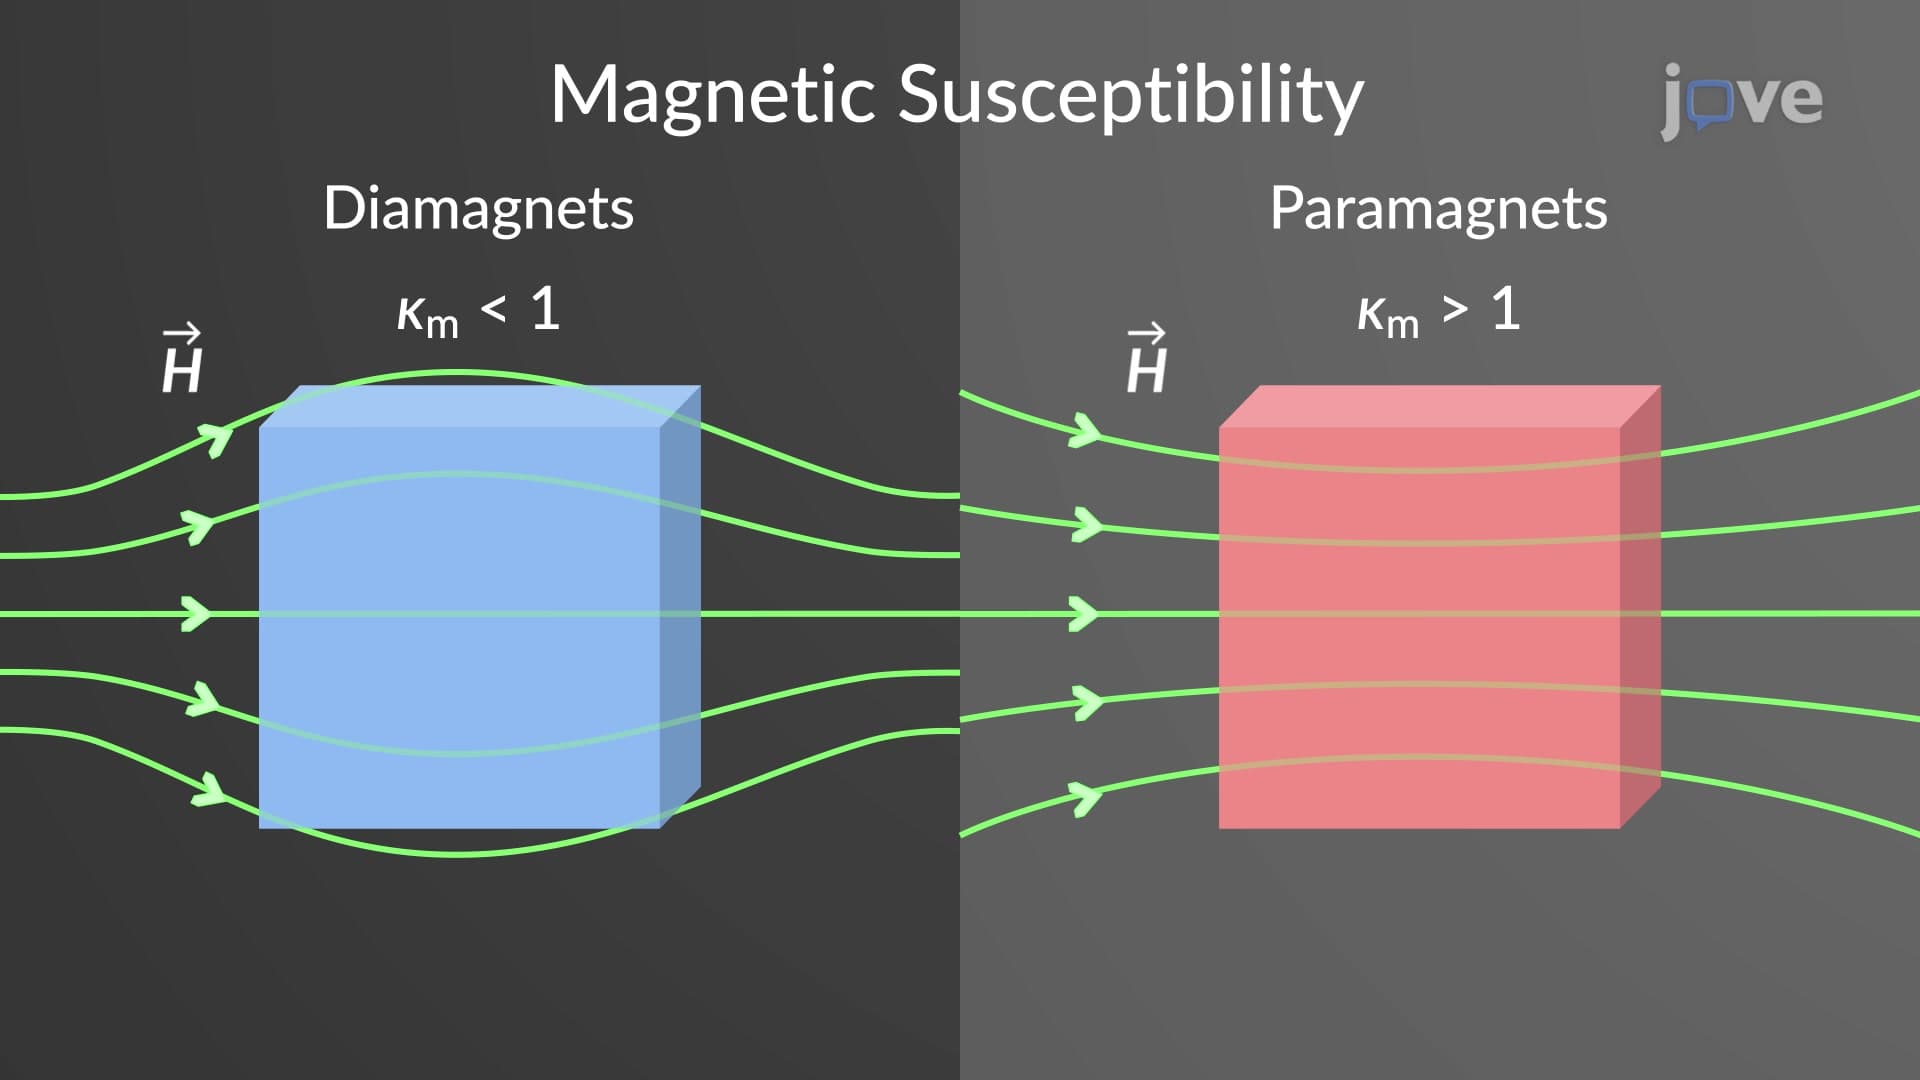
Magnetic Susceptibility and Permeability
When diamagnetic materials are placed under an external magnetic field, the moments opposite to the field are induced. Hence, the susceptibility for diamagnets has a minimal negative value of 10-5–10-6. Since...
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 01:15
Magnetic Vector Potential
Consider an ideal solenoid with n turns per unit length and radius R. If I is the current through the solenoid, the magnetic field inside the solenoid is expressed as the product of vacuum...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...