Related Experiment Video
Updated: Jan 4, 2026

Image-based Lagrangian Particle Tracking in Bed-load Experiments
Published on: July 20, 2017
Model-Independent Formation Tracking of Multiple Euler-Lagrange Systems via Bounded Inputs

Abstract:
This article addresses two kinds of formation tracking problems, namely: 1) the practical formation tracking (PFT) problem and 2) the zero-error formation tracking (ZEFT) problem for multiple Euler-Lagrange systems with input disturbances and unknown models. In these problems, the bounded input constraint, which can be possibly caused by actuator saturation and power limitations, is taken into consideration. Then, the two classes of model-independent distributed control approaches, in which the prior information (i.e., the structures and features) of the system model is not used, are proposed correspondingly. Based on the nonsmooth analysis and Lyapunov stability theory, several novel criteria for achieving PFT and ZEFT of multiple Euler-Lagrange systems are derived. Finally, numerical simulations and comparisons are presented to verify the validity and effectiveness of the proposed control approaches.


Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:19
Euler Equations of Motion
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:28
Euler's Equations of Motion
 01:22
Eulerian and Lagrangian Flow Descriptions
The Eulerian method focuses on fixed points in space where fluid properties, such as velocity, pressure, and temperature, are observed as the fluid moves between these...
 01:21
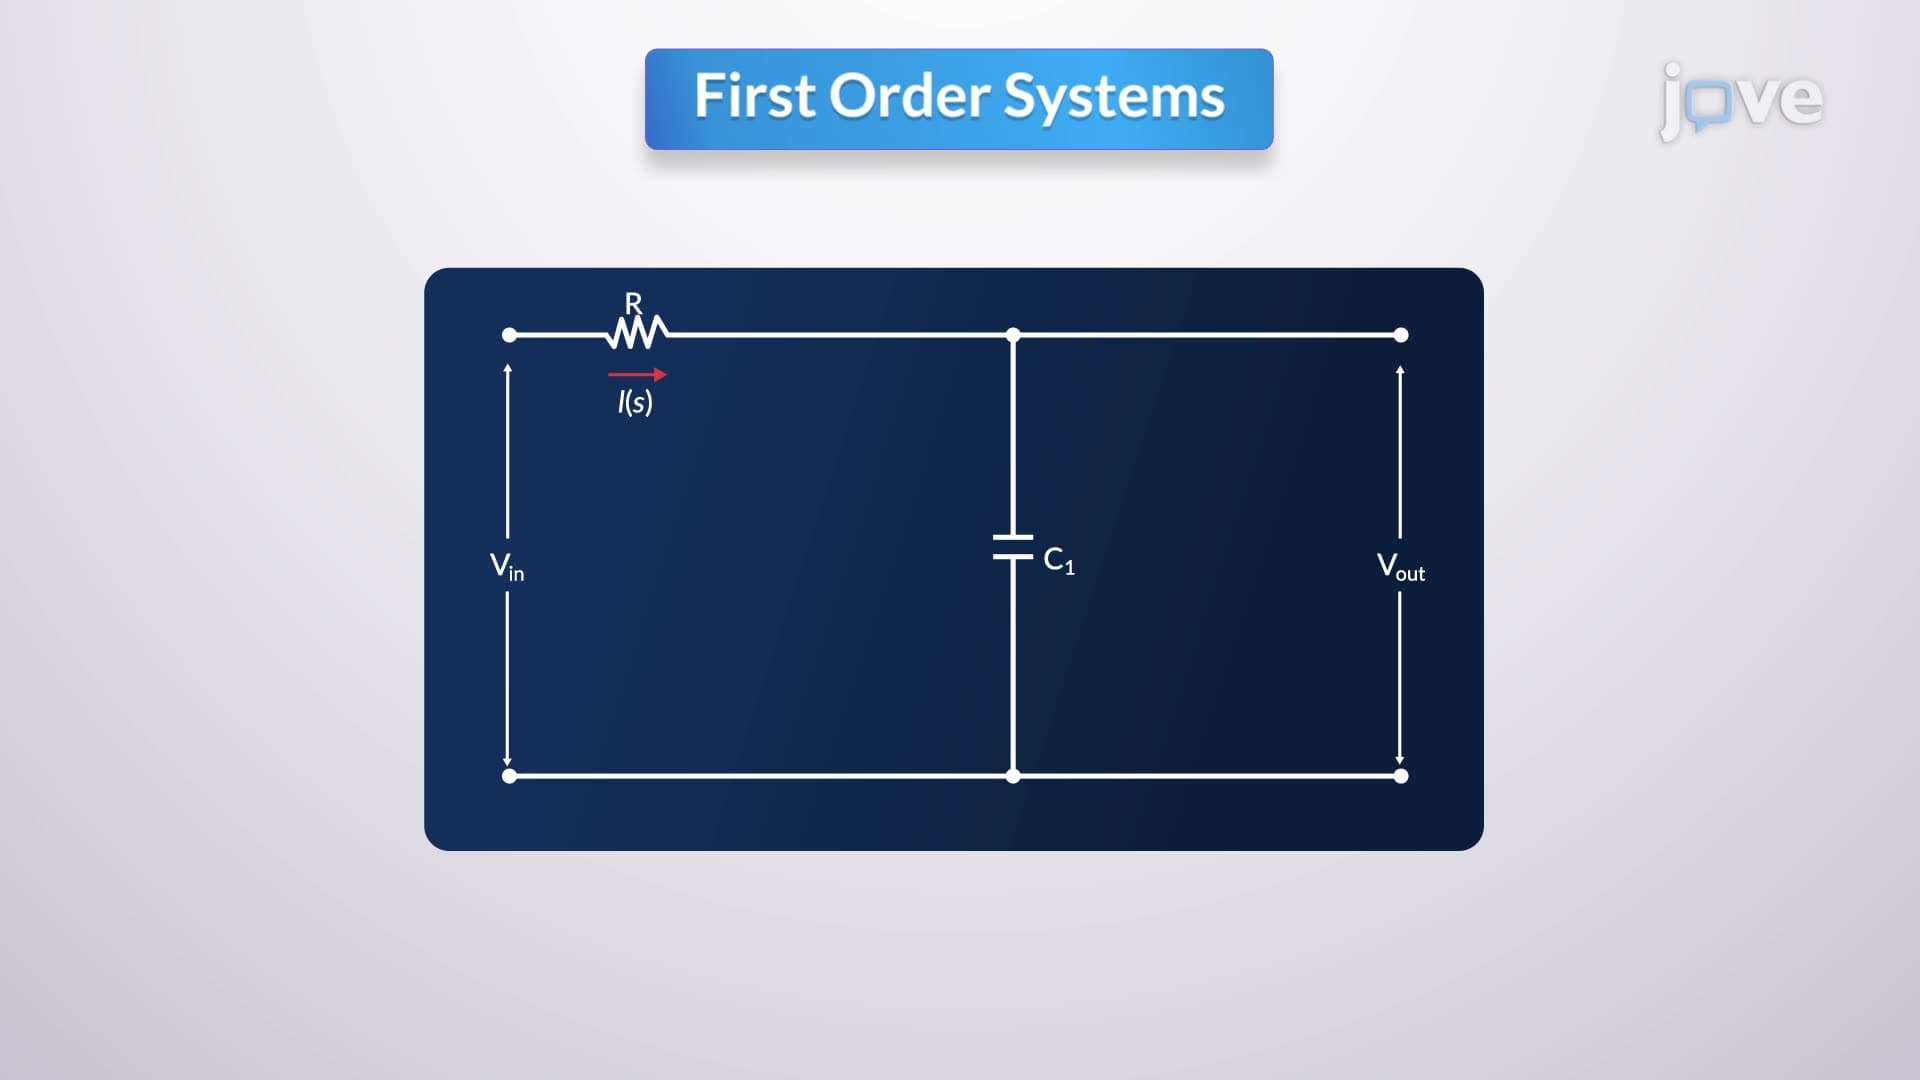
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...