Related Experiment Video
Updated: Jan 4, 2026
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Time-dependent saddle-node bifurcation: Breaking time and the point of no return in a non-autonomous model of
Jeremiah H Li1, Felix X-F Ye2, Hong Qian1
1Department of Applied Mathematics, University of Washington, Seattle, WA 98195-3925, USA.

Abstract:
There is a growing awareness that catastrophic phenomena in biology and medicine can be mathematically represented in terms of saddle-node bifurcations. In particular, the term "tipping", or critical transition has in recent years entered the discourse of the general public in relation to ecology, medicine, and public health. The saddle-node bifurcation and its associated theory of catastrophe as put forth by Thom and Zeeman has seen applications in a wide range of fields including molecular biophysics, mesoscopic physics, and climate science. In this paper, we investigate a simple model of a non-autonomous system with a time-dependent parameter p(τ) and its corresponding "dynamic" (time-dependent) saddle-node bifurcation by the modern theory of non-autonomous dynamical systems. We show that the actual point of no return for a system undergoing tipping can be significantly delayed in comparison to the breaking time at which the corresponding autonomous system with a time-independent parameter undergoes a bifurcation. A dimensionless parameter is introduced, in which λ is the curvature of the autonomous saddle-node bifurcation according to parameter p(τ), which has an initial value of p 0 and a constant rate of change V. We find that the breaking time is always less than the actual point of no return τ ∗ after which the critical transition is irreversible; specifically, the relation is analytically obtained. For a system with a small λV, there exists a significant window of opportunity ( , τ ∗) during which rapid reversal of the environment can save the system from catastrophe.
More Related Videos
 06:55
Kinematic History of a Salient-recess Junction Explored through a Combined Approach of Field Data and Analog Sandbox Modeling
Published on: August 5, 2016
 09:26
In Situ Time-dependent Dielectric Breakdown in the Transmission Electron Microscope: A Possibility to Understand the Failure Mechanism in Microelectronic Devices
Published on: June 26, 2015
Related Concept Videos
 01:19
Limits with Oscillating Discontinuities
 01:28
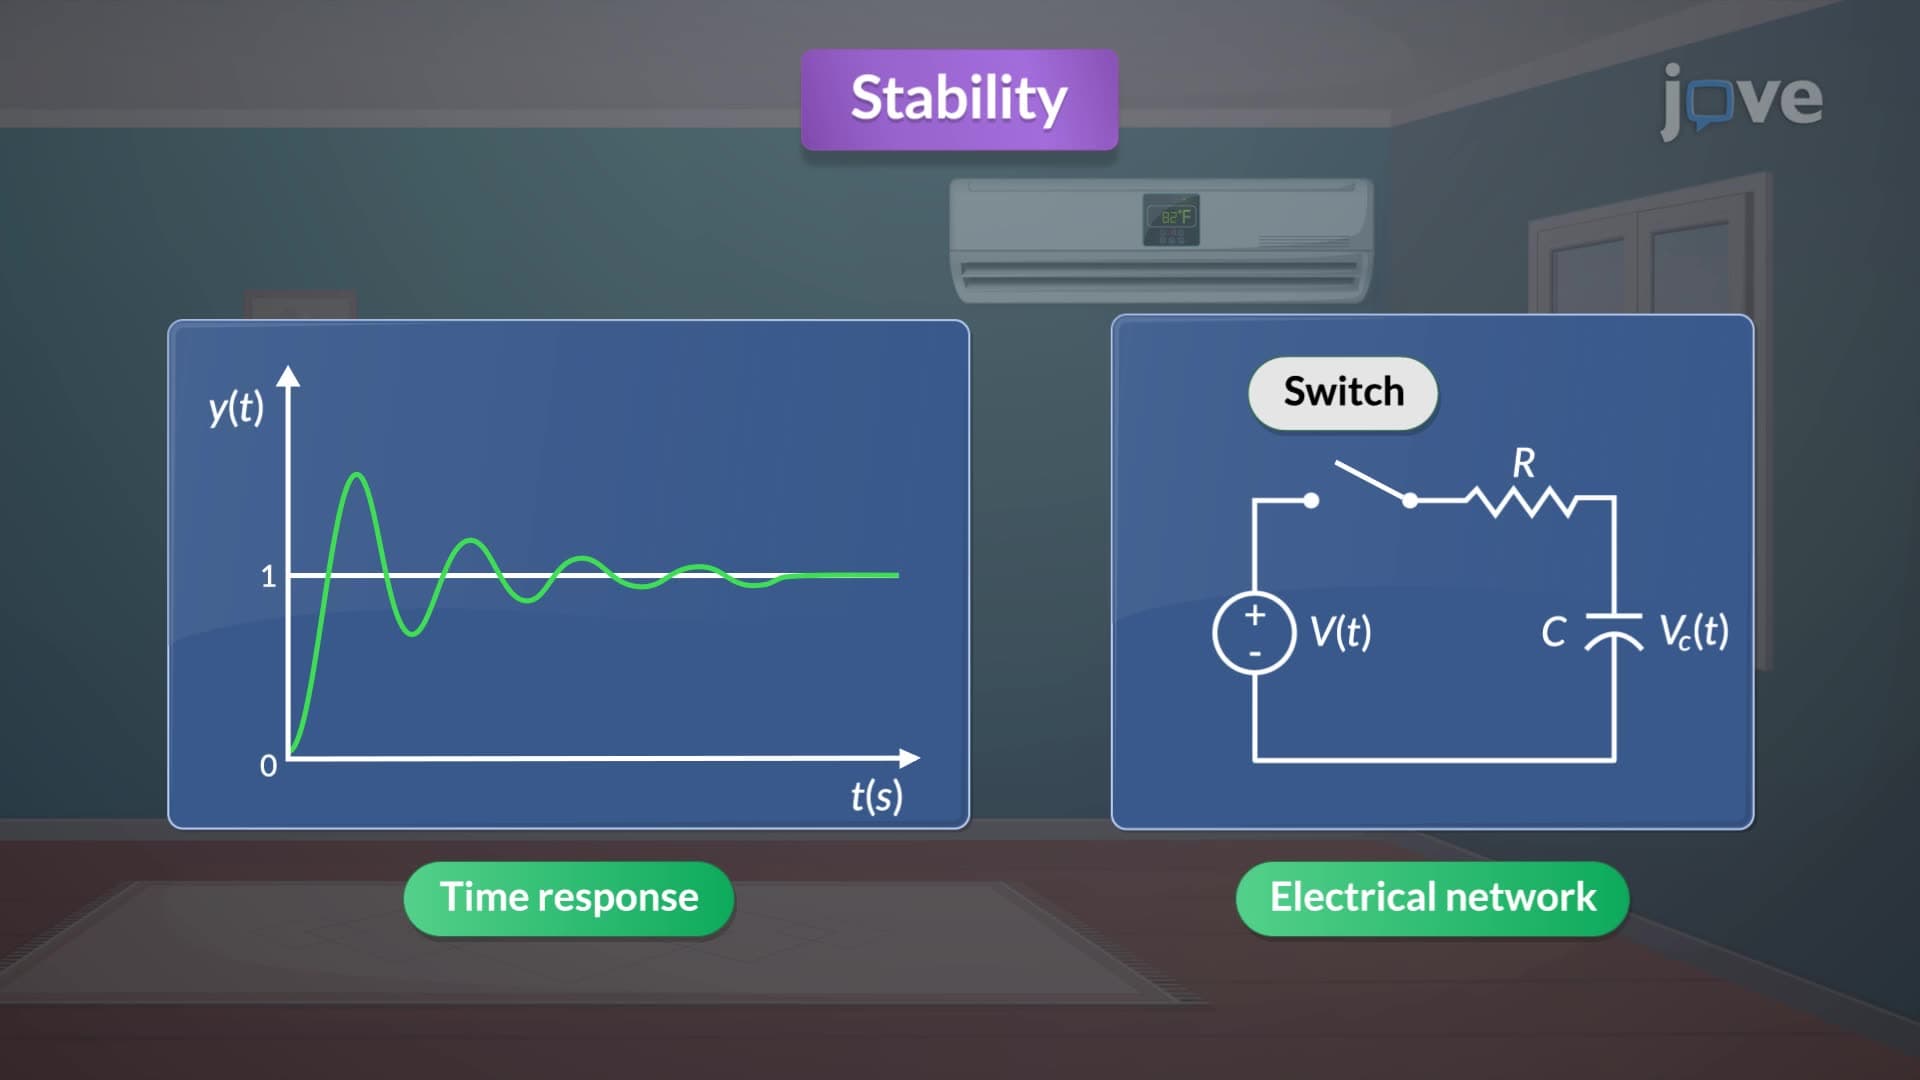
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:18
Second Order systems II
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by: