Related Experiment Video
Updated: Jan 4, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Kinematic Analysis of Postural Stability During Ballet Turns (pirouettes) in Experienced and Novice Dancers
Chai-Wei Lin1,2, Fong-Chin Su1,3, Cheng-Feng Lin3,4,5
1Department of Biomedical Engineering, College of Engineering, National Cheng Kung University, Tainan, Taiwan.

Abstract:
Turning is an important but difficult movement, often performed in ballet choreography. Understanding the postural sway during ballet turns is beneficial to both dancers and dance teachers alike. Accordingly, this study evaluated the postural sway angle during ballet turns in female novice and experienced ballet dancers by means of the inclination angle, determined from the center of mass (COM) and center of pressure (COP). Thirteen experienced dancers and 13 novice dancers performed ballet turns (pirouettes). The COM-COP inclination angle was measured during the preparatory, double-leg support, and single-leg support phases of the turn. The novice dancers exhibited significantly greater ranges of the COM-COP inclination angle in the anterior-posterior (AP) and medial-lateral (ML) directions during the preparatory (AP direction, p < 0.001; ML direction p = 0.035), double-leg support (AP direction p < 0.038; ML direction p = 0.011), and ending phases (AP direction p < 0.001; ML direction p = 0.024). Moreover, during the preparatory phase, the novice dancers failed to adjust their posture in a timely manner, and therefore showed overshooting errors. Finally, during the ending phase, the novice dancers showed a greater standard deviation of the COM-COP inclination angles and performed continual postural adjustments, leading to a less smooth movement than the experienced dancers. In conclusion, the novice dancers were suggested to focus on the COM-COP adjustment during both preparatory and ending phases.
More Related Videos
 07:52
Evaluating Postural Control and Lower-extremity Muscle Activation in Individuals with Chronic Ankle Instability
Published on: September 18, 2020
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
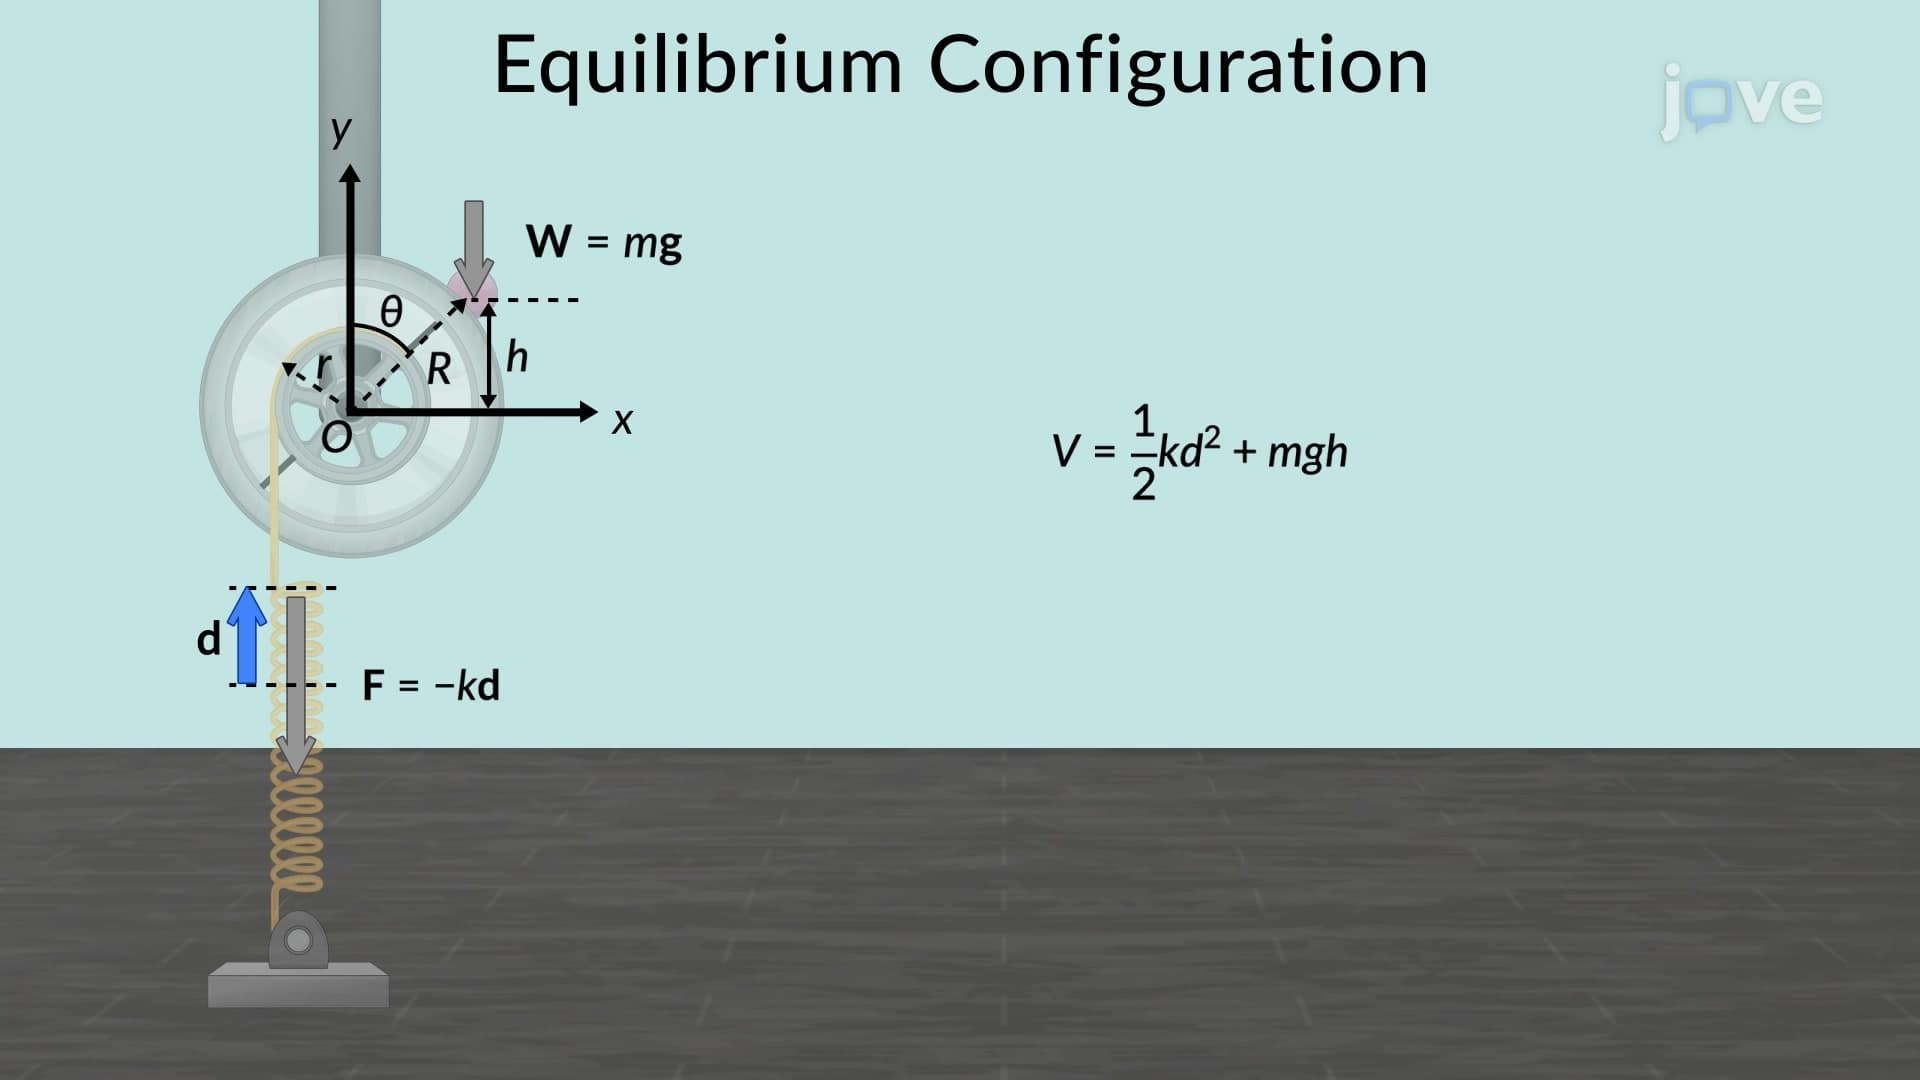 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
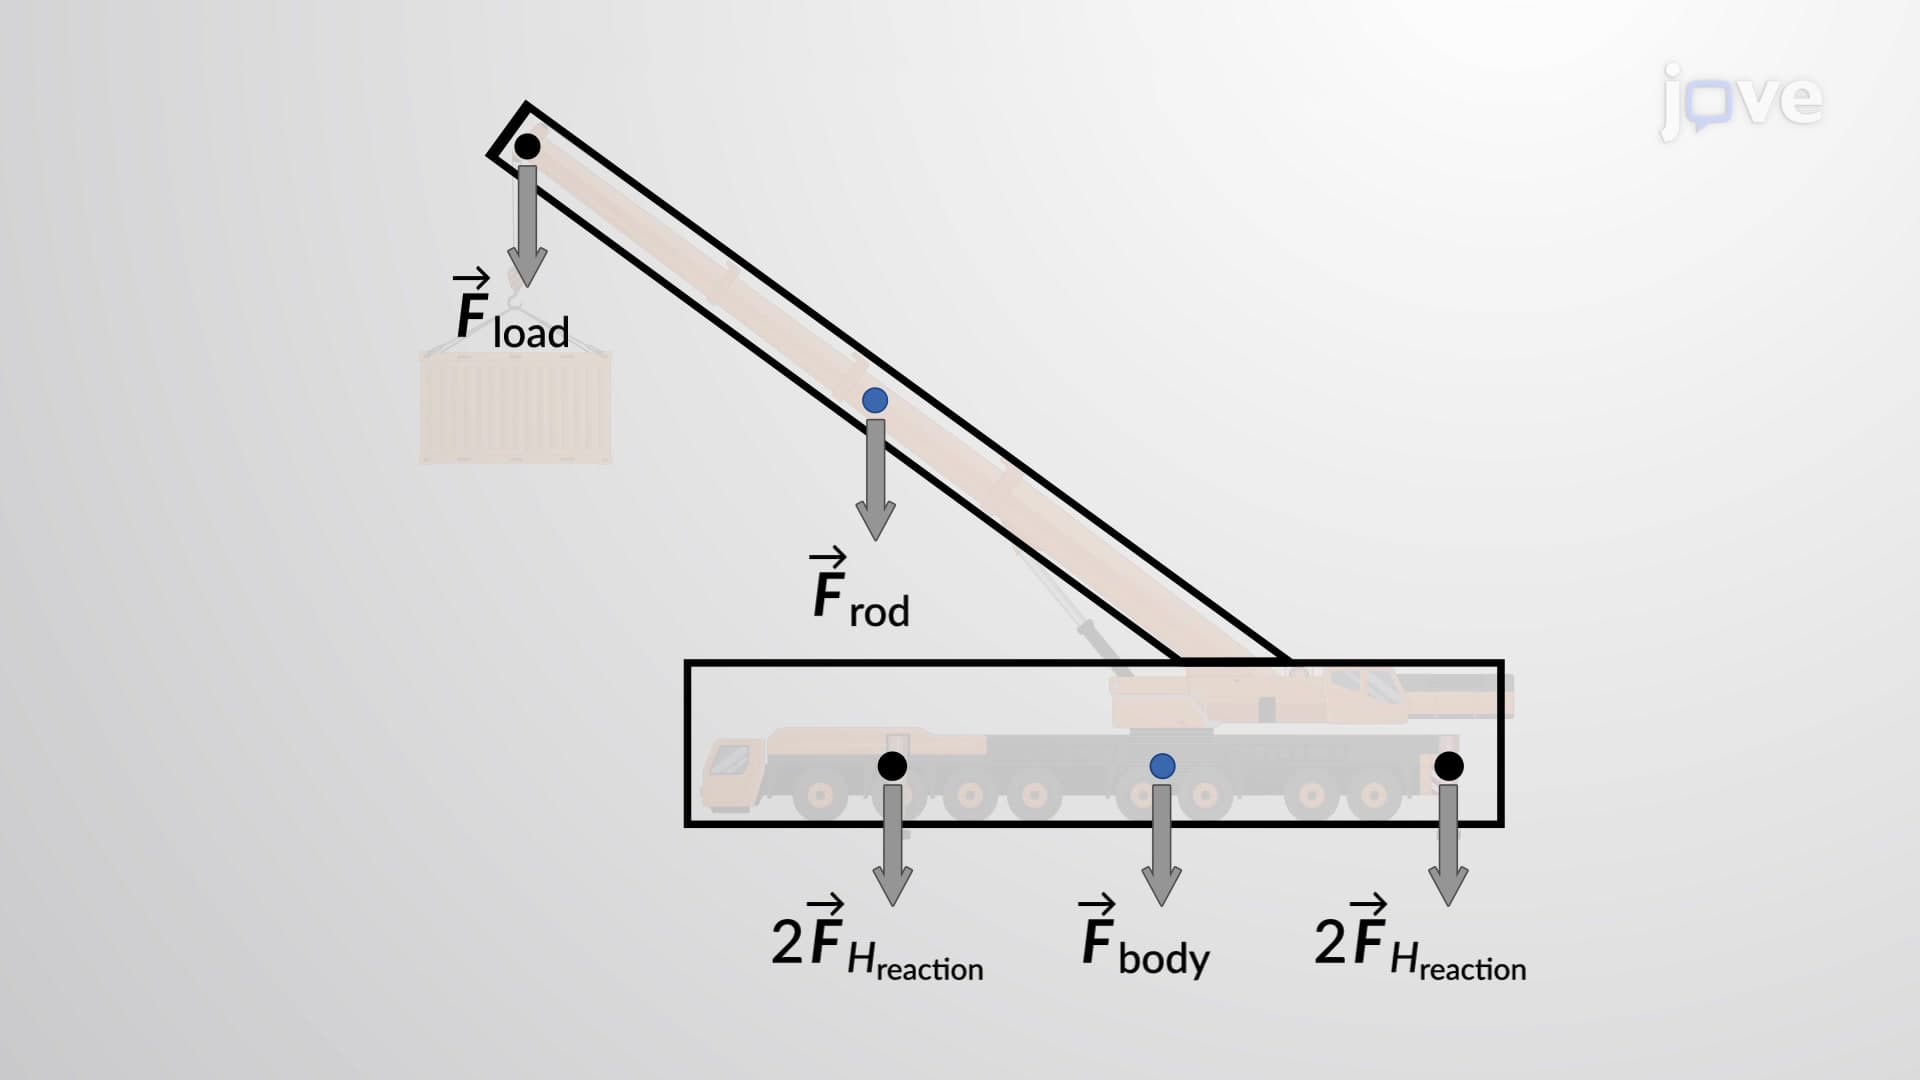 00:49
Rigid Body Equilibrium Problems - I
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...