Related Experiment Video
Updated: Jan 3, 2026

A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Artificial intelligence and robotic surgery: current perspective and future directions
Mahendra Bhandari1, Trevor Zeffiro, Madhu Reddiboina
1Vattikuti Urology Institute, Henry Ford Hospital, Detroit Rediminds, Southfield, Michigan, USA.

Purpose Of Review:
This review aims to draw a road-map to the use of artificial intelligence in an era of robotic surgery and highlight the challenges inherent to this process.
Recent Findings:
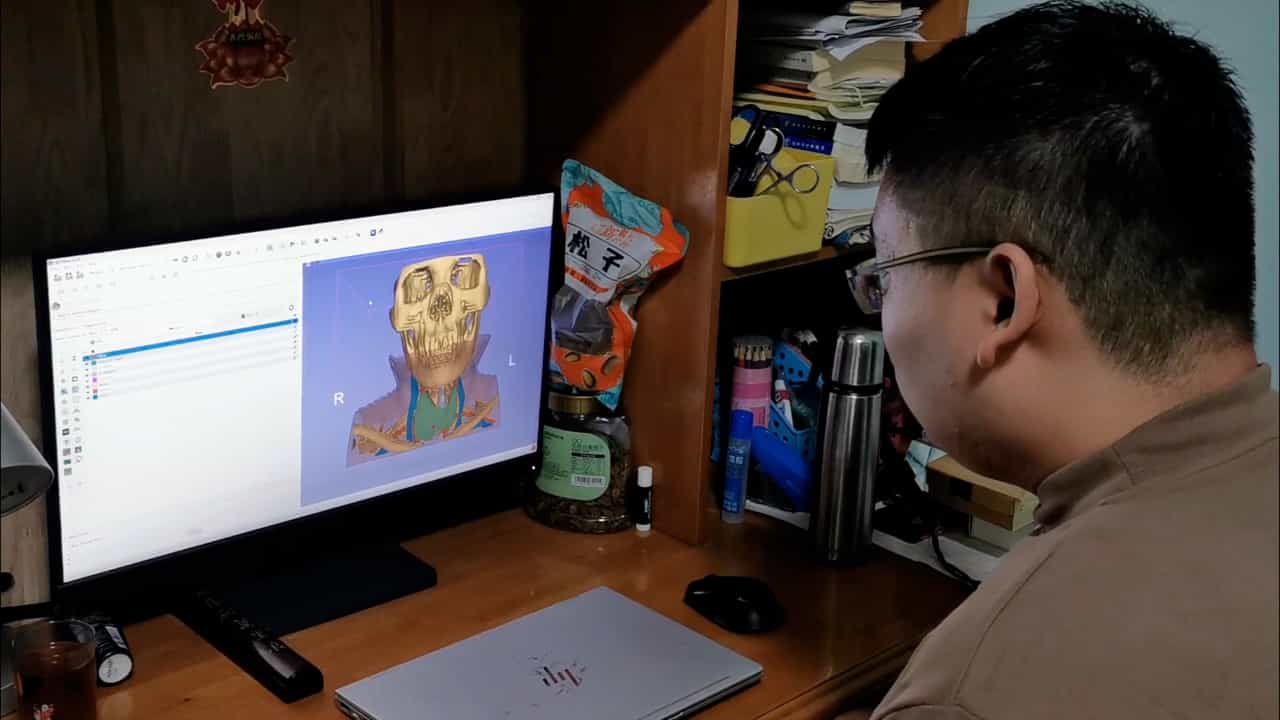
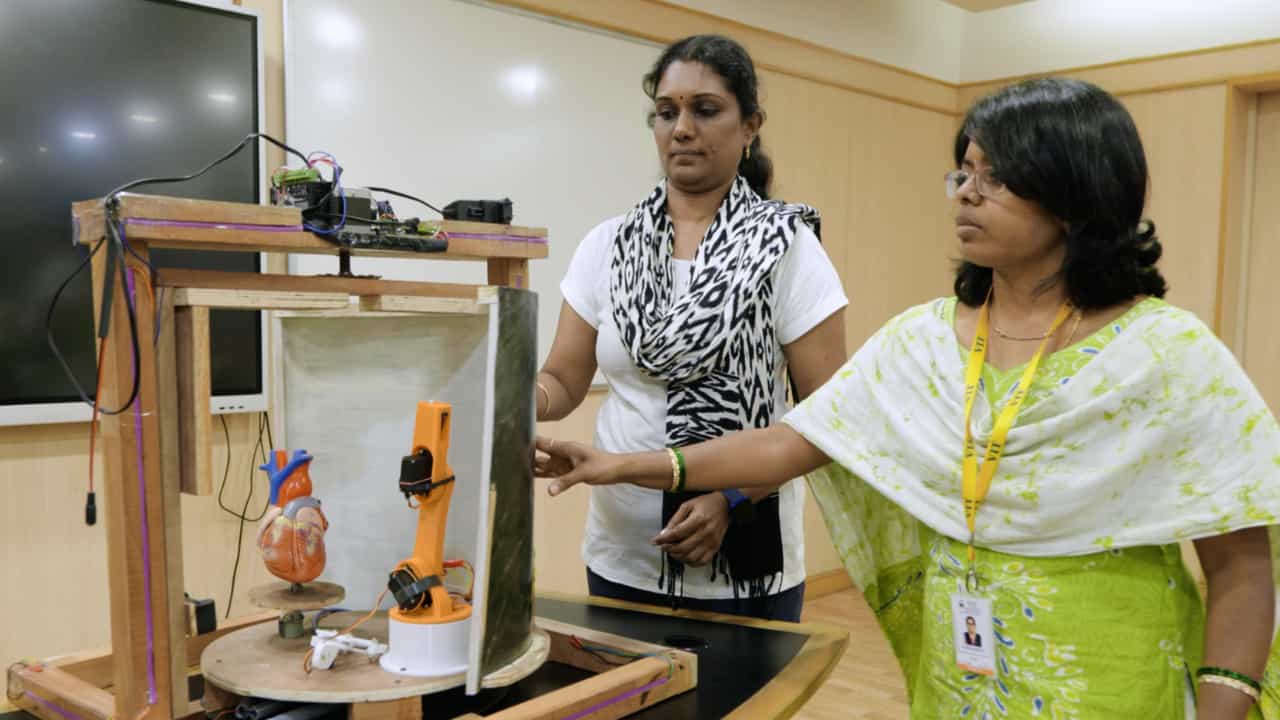
Conventional mechanical robots function by transmitting actions of the surgeon's hands to the surgical target through the tremor-filtered movements of surgical instruments. Similarly, the next iteration of surgical robots conform human-initiated actions to a personalized surgical plan leveraging 3D digital segmentation generated prior to surgery. The advancements in cloud computing, big data analytics, and artificial intelligence have led to increased research and development of intelligent robots in all walks of human life. Inspired by the successful application of deep learning, several surgical companies are joining hands with tech giants to develop intelligent surgical robots. We, hereby, highlight key steps in the handling and analysis of big data to build, define, and deploy deep-learning models for building autonomous robots.
Summary:
Despite tremendous growth of autonomous robotics, their entry into the operating room remains elusive. It is time that surgeons actively collaborate for the development of the next generation of intelligent robotic surgery.
Related Concept Videos
 01:29
Issues And Trends In Healthcare Delivery System
Cost Containment
Payment for healthcare services has historically promoted adoption of costly and often unnecessary or inefficient...
 01:30
Current Trends in Nursing II
 01:30
Psychosurgery
Historical Development of Psychosurgery
In the 1930s, Portuguese neurologist Antonio Egas Moniz introduced a surgical procedure designed...