Related Experiment Video
Updated: Jan 3, 2026
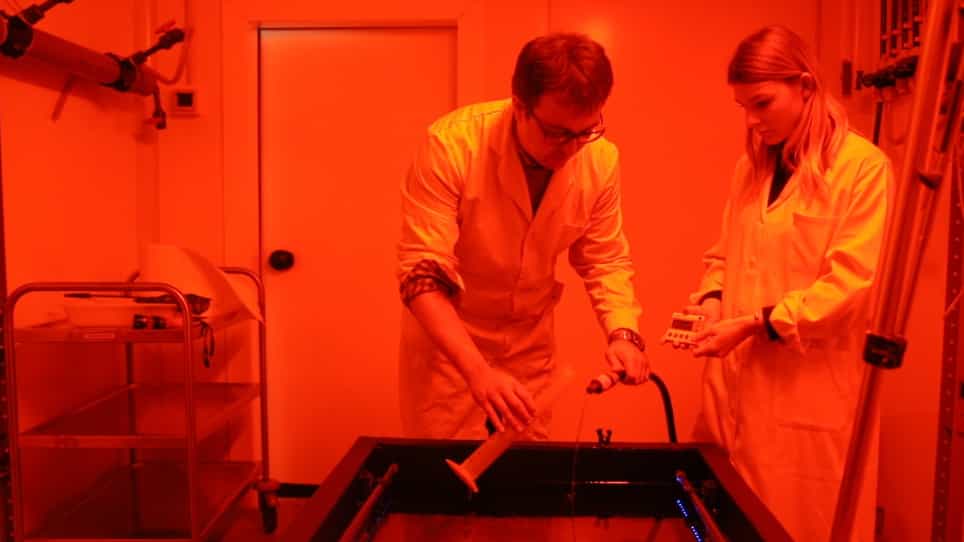

Long-term Video Tracking of Cohoused Aquatic Animals: A Case Study of the Daily Locomotor Activity of the Norway Lobster Nephrops norvegicus
Published on: April 8, 2019
Object Tracking Based On Huber Loss Function
Yong Wang1, Shiqiang Hu2, Shandong Wu3
1School of Electrical and Computer Science, University of Ottawa, Ottawa Canada.

Abstract:
In this paper we present a novel visual tracking algorithm, in which object tracking is achieved by using subspace learning and Huber loss regularization in a particle filter framework. The changing appearance of tracked target is modeled by Principle Component Analysis (PCA) basis vectors and row group sparsity. This method takes advantage of the strengths of sub-space representation and explicitly takes the underlying relationship between particle candidates into consideration in the tracker. The representation of each particle is learned via the multi-task sparse learning method. Huber loss function is employed to model the error between candidates and templates, yielding robust tracking. We utilize the Alternating Direction Method of Multipliers (ADMM) to solve the proposed representation model. In experiments we tested sixty representative video sequences that reflect the specific challenges of tracking and used both qualitative and quantitative metrics to evaluate the performance of our tracker. The experiment results demonstrated that the proposed tracking algorithm achieves superior performance compared to nine state-of-the-art tracking methods.
Related Concept Videos
 01:18
Reducing Line Loss
With a step-up transformer at the source, the voltage is increased, thereby reducing the current in the transmission lines since power loss in...
 01:10
Detection of Black Holes
Their closest cousins are neutron stars, which are composed almost entirely of neutrons packed against each other, making them extremely dense. A neutron star has the same mass as the Sun but its diameter is only a few kilometers. Therefore, the escape velocity from their surface is close to the speed of light.
Not until the 1960s, when the first neutron...
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...