Related Experiment Video
Updated: Jan 2, 2026
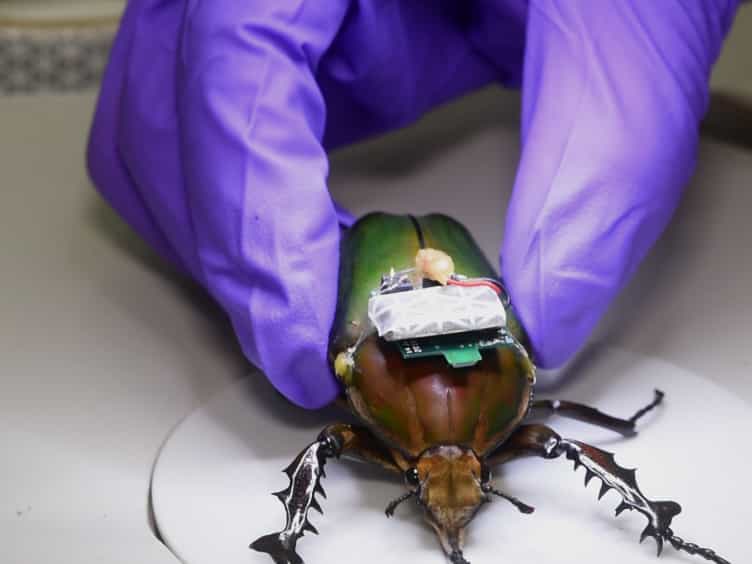

Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Motor output and control input in flapping flight: a compact model of the deforming wing kinematics of manoeuvring
Indira Nagesh1, Simon M Walker2, Graham K Taylor1
1Department of Zoology, University of Oxford, 11a Mansfield Road, Oxford OX1 3SZ, UK.

Abstract:
Insects are conventionally modelled as controlling flight by varying a few summary kinematic parameters that are defined on a per-wingbeat basis, such as the stroke amplitude, mean stroke angle and mean wing pitch angle. Nevertheless, as insects have tens of flight muscles and vary their kinematics continuously, the true dimension of their control input space is likely to be much higher. Here, we present a compact description of the deforming wing kinematics of 36 manoeuvring Eristalis hoverflies, applying functional principal components analysis to Fourier series fits of the wingtip position and wing twist measured over 26 541 wingbeats. This analysis offers a high degree of data reduction, in addition to insight into the natural kinematic couplings. We used statistical resampling techniques to verify that the principal components (PCs) were repeatable features of the data, and analysed their coefficient vectors to provide insight into the form of these natural couplings. Conceptually, the dominant PCs provide a natural set of control input variables that span the control input subspace utilized by this species, but they can also be thought of as output states of the flight motor. This functional description of the wing kinematics is appropriate to modelling insect flight as a form of limit cycle control.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:23
Lift
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:54
Convergent Evolution
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...